News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4147 storiesStability Boundaries and Motor Performance in Delayed Robot-Mediated Dyadic Interactions
arXiv:2510.14511v3 Announce Type: replace Abstract: This paper establishes analytical stability boundaries for robot-mediated human-human (dyadic) interaction s…
Sim2Swim: Zero-Shot Velocity Control for Agile AUV Maneuvering in 3 Minutes
arXiv:2512.08656v2 Announce Type: replace Abstract: Holonomic autonomous underwater vehicles (AUVs) have the hardware ability for agile maneuvering in both tran…
CORE: Common Outcome Regularities from Action-Free Visual Demonstrations for Robot Manipulation
arXiv:2606.29517v1 Announce Type: new Abstract: Robot imitation learning often relies on costly robot demonstrations, while abundant action-free visual demonstr…
KYON: Semi-Modular Wheel-Legged Quadruped With Agile Bimanual Capability
arXiv:2606.30243v1 Announce Type: new Abstract: This paper presents KYON, a hybrid wheel-legged quadruped robot equipped with a bimanual upper body for loco-man…
Vision-Language Models for Deployable Social Robot Navigation: Bridging Semantic Reasoning and Low-Level Control
arXiv:2606.28760v1 Announce Type: new Abstract: Social robot navigation (SRN) requires more than geometric path planning; it demands understanding human intenti…
When May I Help You? On The Effect of Proactivity on Group Human-Robot Collaboration
arXiv:2606.28469v1 Announce Type: new Abstract: Robot initiative is a central challenge in multi-party human-robot collaboration. A robot that contributes witho…
Empowering a Single-Frequency GNSS Receiver to Achieve High-Precision Positioning with Relative Observations
arXiv:2606.29192v1 Announce Type: new Abstract: Global Navigation Satellite System (GNSS) navigation is widely used to provide absolute, outdoor positioning in …
MoPe: Motion Permanence for Robust Monocular Gaussian Mapping in Dynamic Environments
arXiv:2606.29237v1 Announce Type: new Abstract: Robust robot autonomy depends on scene representations that remain stable enough to support localization, naviga…
RIPA: Sensory-Vector Prompt Injection Attacks on LLM-Controlled ROS 2 Robots
arXiv:2606.28649v1 Announce Type: cross Abstract: We present RIPA, the first systematic multi-channel empirical study of prompt injection attacks delivered thro…
Embodiment Meets Environment: Toward Context-Aware, Safe Physical Caregiving Robots
arXiv:2606.28592v1 Announce Type: new Abstract: Physical caregiving robots need to assist different users with different tasks in diverse environments, and they…
Motion planning for hundreds of floating robots
arXiv:2606.09620v2 Announce Type: replace Abstract: Planning collision-free motion for large robot fleets is difficult because collision avoidance induces stron…
MOAR Planner: Multi-Objective and Adaptive Risk-Aware Path Planning for Infrastructure Inspection with a UAV
arXiv:2606.30575v1 Announce Type: new Abstract: The problem of autonomous navigation for UAV inspection remains challenging as it requires effectively navigatin…
Understanding LLM Intervention Explanations in Multi-Party Human-Robot Interaction
arXiv:2606.29460v1 Announce Type: new Abstract: Large Language Models (LLMs) are increasingly embedded in social robots to support natural group interactions, y…
He3-Seeker: Robotic Information Planning for Lunar Helium-3 Distribution Mapping
arXiv:2606.28746v1 Announce Type: new Abstract: Lunar helium-3 is a highly valuable strategic resource, pivotal to the advancement of both deep-space exploratio…
AsyncMDE: Real-Time Monocular Depth Estimation via Asynchronous Spatial Memory
arXiv:2603.10438v2 Announce Type: replace Abstract: Foundation-model-based monocular depth estimation offers a viable alternative to active sensors for robot pe…
X-Morph: Human Motion Priors for Scalable Robot Learning Across Morphologies
arXiv:2606.30290v1 Announce Type: new Abstract: Recent progress in humanoid behavior models has been driven in large part by abundant human motion data, but com…
The Speedup Paradox: Rethinking Inference Speed-Quality Trade-off in Embodied Tasks
arXiv:2606.28529v1 Announce Type: new Abstract: Embodied foundation models have recently been widely used to improve robot generalization and task success rates…
You Only Touch Once: 6-DoF Object Pose Estimation from Single Tactile Contact
arXiv:2606.28899v1 Announce Type: new Abstract: Accurate 6-DoF object pose estimation is fundamental to robotic manipulation, yet vision-based methods often fai…
Insights behind Kinisi’s acquisition by Bear Robotics
Brennand Pierce, founder and CEO of Kinisi Robotics, discusses the company's approach to physical AI and its acquisition by Bear Robotics. The post Insights beh…
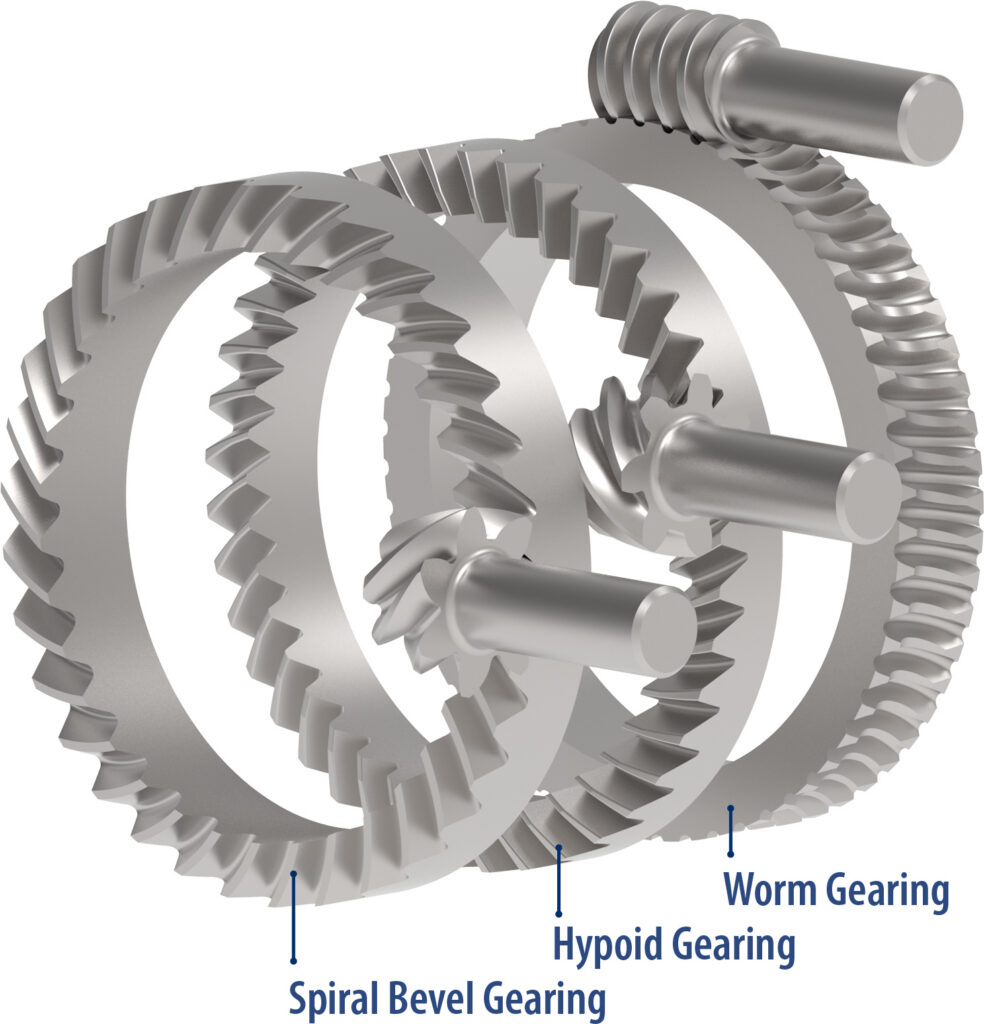
Advantages of hypoid gearing over worm, bevel and bevel-planetary
Right-angle gearing often requires engineers to compromise between torque capacity and mechanical efficiency. Hypoid gearing offers a balance of mechanical effi…

MBody AI expands service robotics operations to eleven states and Canada
MBody AI has deployed its hardware-agnostic Orchestrator platform to Florida and California, with a pilot in Ontario. The post MBody AI expands service robotics…
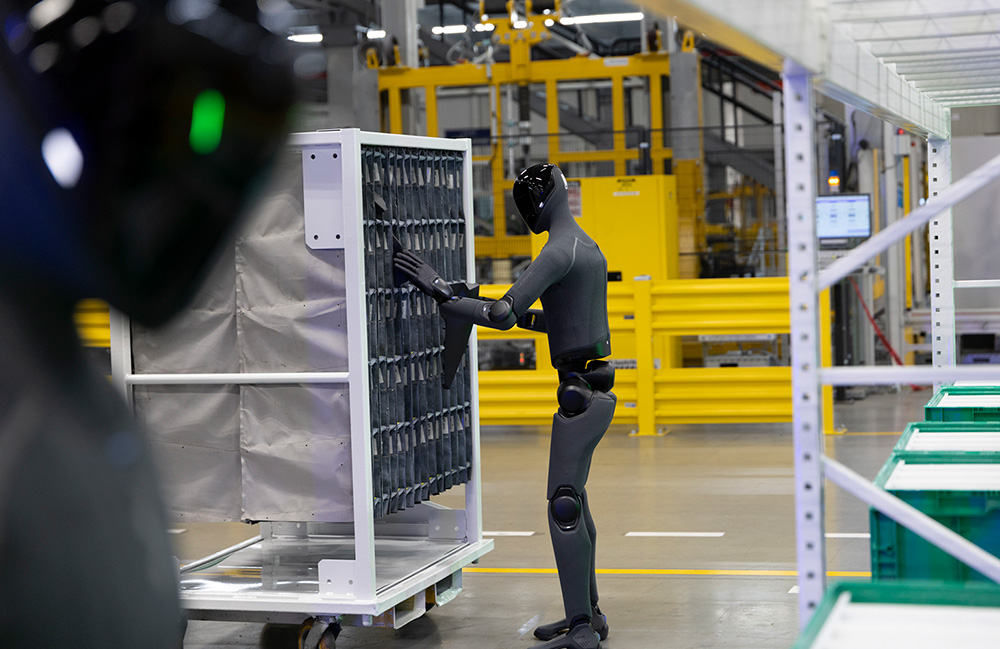
BMW Group deploys Figure 03 humanoid after tests with previous version
The Figure 02 robot supported the production of more than 30,000 BMW X3 vehicles over 11 months in South Carolina. The post BMW Group deploys Figure 03 humanoid…
PPO-EAL: Exact Augmented Lagrangian Proximal Policy Optimization for Safe Robotic Control
arXiv:2606.27861v1 Announce Type: new Abstract: Reinforcement learning (RL) has emerged as a promising solution to accomplish complex robotic control tasks; how…
AI-Driven Synthesis for High-Tech System Design: Automating Innovation
arXiv:2606.28126v1 Announce Type: cross Abstract: This article addresses the combinatorial complexity inherent in modern high-tech system design by presenting a…
FailSafe: Reasoning and Recovery from Failures in Vision-Language-Action Models
arXiv:2510.01642v3 Announce Type: replace Abstract: Recent advances in robotic manipulation have integrated low-level robotic control into Vision-Language Model…
Translation as a Bridging Action: Transferring Manipulation Skills from Humans to Robots
arXiv:2606.28133v1 Announce Type: new Abstract: We study whether we can learn novel manipulation skills from human actions to a bi-manual robot with parallel gr…
CWI: Composite Humanoid Whole-Body Imitation System for Loco-manipulation
arXiv:2606.27676v1 Announce Type: new Abstract: Achieving everyday tasks with humanoid robots requires coordinating stable locomotion with versatile manipulatio…
KISS-IMU: Self-supervised Inertial Odometry with Motion-balanced Learning and Uncertainty-aware Inference
arXiv:2603.06205v2 Announce Type: replace Abstract: Inertial measurement units (IMUs), which provide high-frequency linear acceleration and angular velocity mea…
Unleashing Infinite Motion: Scaling Expressive Quadrupedal Motion via Generative Video Priors
arXiv:2606.28237v1 Announce Type: new Abstract: Quadruped robots have achieved remarkable locomotion, yet their behavioral repertoire remains confined to a few …
Data Scaling Laws in Imitation Learning for Robotic Manipulation
arXiv:2410.18647v4 Announce Type: replace Abstract: Data scaling has revolutionized fields like natural language processing and computer vision, providing model…