Research
Frontier robotics research: arXiv cs.RO papers, embodied AI, VLA models, manipulation, navigation and learning systems.
Frontier robotics research: arXiv cs.RO papers, embodied AI, VLA models, manipulation, navigation and learning systems.
Latest in Research
6273 storiesCoCoBench: A Cooperative Coordination Benchmark for Embodied Multi-Agent Task Planning
arXiv:2608.28266v1 Announce Type: new Abstract: Agent systems powered by multimodal large language models (MLLMs) have advanced rapidly in recent years, yet exi…
PAMoR: Parameterized Affective Motion Generation in Real Time for Humanoid Robots
arXiv:2608.28213v1 Announce Type: new Abstract: People read a humanoid robot's motion in social settings not only for the action performed but for the affect co…
From Small Talk to Rapport: Exploring Robot Self-Disclosure in Collaborative Tasks
arXiv:2608.28154v1 Announce Type: new Abstract: People naturally chat while collaborating and share personal information (i.e., self-disclose) to build rapport …
PHR-VLA: Planning Horizon Reasoning for Vision-Language-Action Models
arXiv:2608.27609v1 Announce Type: new Abstract: Vision-language-action models (VLAs) have shown strong promise for general-purpose robotic manipulation by mappi…
EXL acquires physical AI model developer iMerit
The EXL and iMerit executives explain how their companies' combined expertise and platforms will help developers with reliable physical AI. The post EXL acquire…
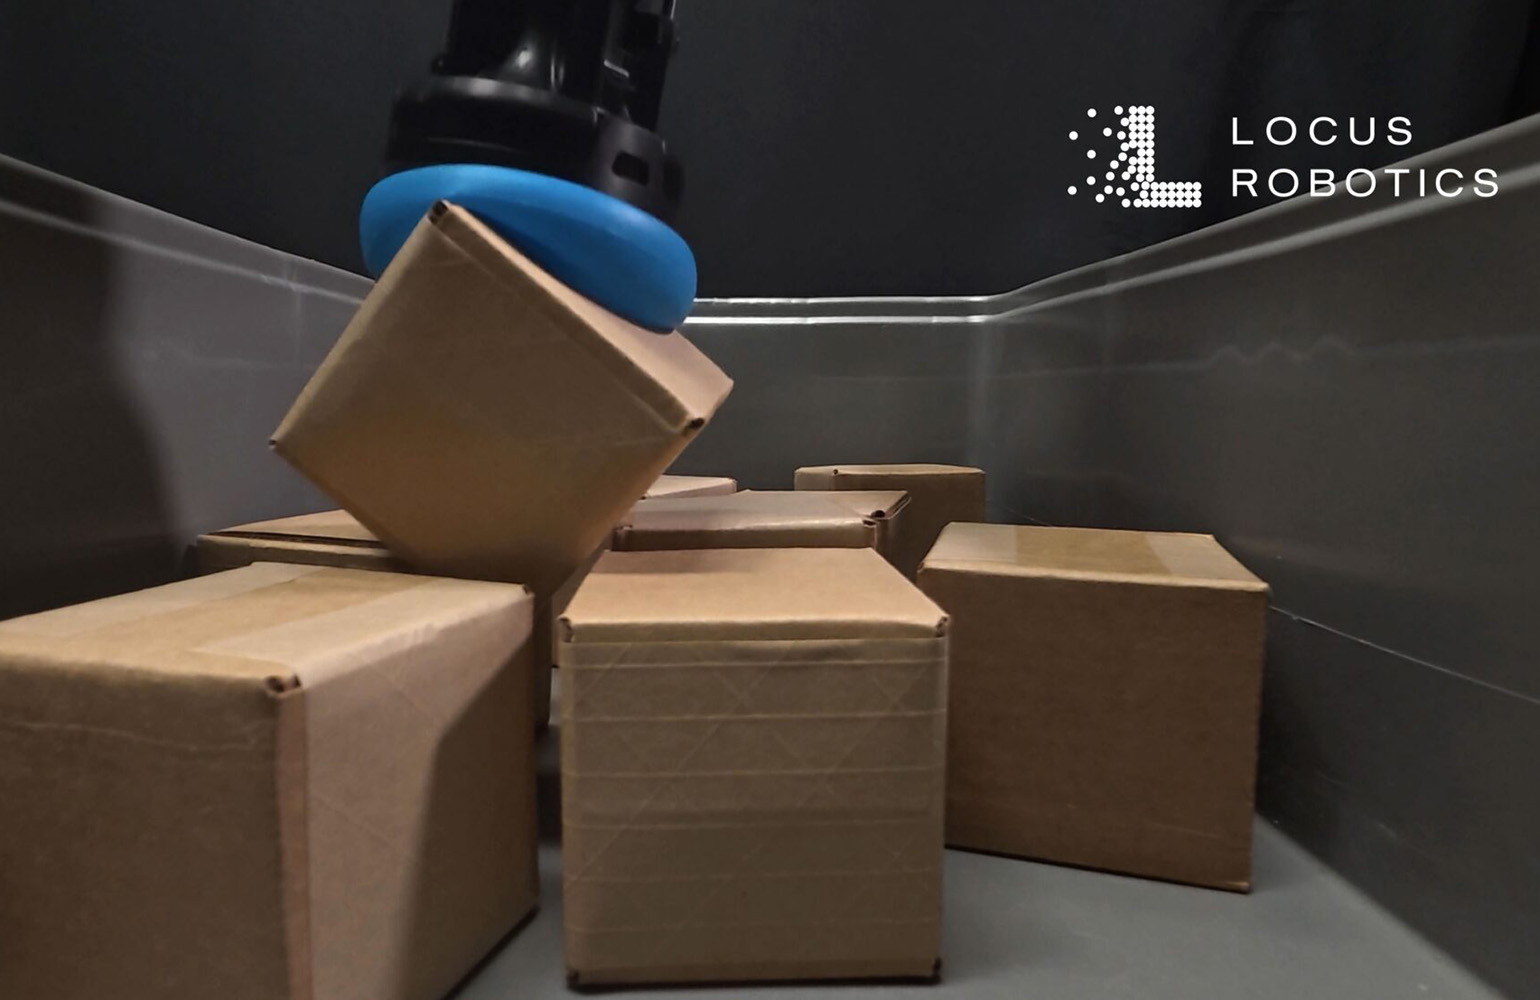
How Locus is getting a grasp on one of robotics biggest challenges: manipulation
Locus Robotics recently acquired Nexera Robotics, which create unique soft picking technology, bolstering its manipulation capabilities. The post How Locus is g…
MeshPriorDiT: Hierarchical Modeling for Action-Conditioned Cloth Dynamics
arXiv:2608.26766v1 Announce Type: new Abstract: Action-conditioned cloth dynamics prediction requires both locally plausible deformation and long-range coordina…
Online Joint Calibration of Steering Offset and Planar LiDAR Extrinsics for Wheeled Mobile Robots
arXiv:2608.26789v1 Announce Type: new Abstract: Accurate steering sensing and LiDAR-to-vehicle extrinsics are crucial for reliable path tracking in warehouse mo…
CLIPPER: Replayable Shortlisted Optimization for Repeated Spatial Coverage Planning
arXiv:2608.26819v1 Announce Type: new Abstract: Operational requirements developed with the City of Braunschweig frame municipal micromobility planning under ge…
Contact-Aided Factor-Graph Localization for Underwater Sampling
arXiv:2608.26932v1 Announce Type: new Abstract: Accurate state estimation for autonomous underwater vehicles performing close-range seafloor sampling remains ch…
Arbitrary-Order Hermite Interpolation of Rigid-Motion Jets via Hyper-Multidual Quaternions
arXiv:2608.27000v1 Announce Type: new Abstract: We study bilateral interpolation of finite-order rigid-motion jets represented by unit dual quaternions. An orde…
GRAFT: Grounded and Efficient Online Reinforcement Adaptation for Fine-Grained Robot Manipulation
arXiv:2608.27079v1 Announce Type: new Abstract: Pretrained vision-language-action (VLA) policies provide strong priors for robot manipulation, yet adapting them…
Task-space model-based control of pneumatic soft actuators
arXiv:2608.27186v1 Announce Type: new Abstract: Soft actuators enable dexterous and compliant interaction, but closed-loop task-space control remains challengin…
STEP: State-Aware Task Estimation and Planning with Multi-Modal LLMs for Human-Robot Collaboration
arXiv:2608.27225v1 Announce Type: new Abstract: Effective human-robot collaboration in industrial settings requires robots to understand human intentions and as…
FlashVLA: Streaming Action Decoding for Fast and Asynchronous VLA Inference
arXiv:2608.27384v1 Announce Type: new Abstract: Vision-Language-Action (VLA) models are increasingly promising for robotic manipulation, yet their real-world de…
Decoupling Planning and Control for Instructable Agents
arXiv:2608.26788v1 Announce Type: cross Abstract: Recent work shows that pre-trained, instruction-tuned vision-language models (VLMs) perform well at mapping fr…
Dynamic Haven Selection for Multi-Agent Pickup and Delivery in Constrained Warehouses
arXiv:2608.26939v1 Announce Type: cross Abstract: Space-efficient warehouse layouts often contain single-agent-width aisles and dead-end workstations where robo…
TADP: Task-Aware Deformable Prediction for Single-Stage 3D Object Detection
arXiv:2608.27282v1 Announce Type: cross Abstract: Most single-stage 3D object detectors complete different tasks with the same extracted features. Nevertheless,…
A Mechanistic Model for Collective Motion from Sensorimotor Regularities
arXiv:2605.16522v2 Announce Type: replace Abstract: Collective behavior in animals has long been modeled through self-propelled particle models, which reproduce…
No Plan, Yet Human: A Reactive Robotics Model Predicts Human Planning Failures on a Clinical Task
arXiv:2605.16514v2 Announce Type: replace Abstract: Understanding why some sequential planning problems are harder than others requires models that go beyond av…
MOMO: A framework for seamless physical, verbal, and graphical robot skill learning and adaptation
arXiv:2604.20468v3 Announce Type: replace Abstract: Industrial robot applications require increasingly flexible systems that non-expert users can easily adapt f…
Using VLM Reasoning to Constrain Task and Motion Planning
arXiv:2510.25548v3 Announce Type: replace Abstract: In task and motion planning, high-level task planning is done over an abstraction of the world to enable eff…
SpatialCrafter: Single Image World Modeling with Generative 3D Proxies
arXiv:2608.27073v1 Announce Type: cross Abstract: Explorable image-to-scene generation is essential for applications in gaming, robotics, and virtual reality. E…
CGS-SLAM: Collaborative Gaussian Splatting based SLAM for Multi-Agent Reconstruction
arXiv:2608.26868v1 Announce Type: cross Abstract: Recent advances in SLAM have leveraged 3DGS for photorealistic reconstruction and novel view synthesis. Howeve…
Fixed-Haven Reservation for Online Multi-Agent Pickup and Delivery in Dense Warehouses
arXiv:2608.26759v1 Announce Type: cross Abstract: Dense warehouses often contain single-lane aisles, dead ends, and tree-like guidepaths that leave little room …
Arrive and Survive: Scaling Safe Goal-Conditioned Policy Learning from One-Bit Failure Signals
arXiv:2608.26571v1 Announce Type: cross Abstract: Contrastive reinforcement learning (CRL) scales effectively in goal-conditioned tasks by casting policy learni…
Barrier Function Conformal Safety Clearance Certification with CVaR for Driving Trajectory Selection
arXiv:2608.26533v1 Announce Type: cross Abstract: Autonomous driving motion planners generate and select candidate trajectories while accounting for interaction…
Why did My Robot Just Change Personality? Prompting Guidelines for a Grounded Robot Persona in LLM-Based HRI
arXiv:2608.26182v1 Announce Type: cross Abstract: Large language models (LLMs) are increasingly used for verbal interaction in social robots, yet prompt design …
Pass the Bucket: Efficient, Robust, Local Load Balancing for Teams of Heterogeneous Robots
arXiv:2608.27085v1 Announce Type: new Abstract: We study the problem of decentralized, self-organized task sharing for a swarm of heterogeneous robots that coll…
Tensegrity Continuum Robots Enable Task-Adaptive Morphologies for Cooperative Behaviors
arXiv:2608.27221v1 Announce Type: new Abstract: Robots that can change their morphologies and behaviors for different tasks and environments hold great promise …