Research
Frontier robotics research: arXiv cs.RO papers, embodied AI, VLA models, manipulation, navigation and learning systems.
Frontier robotics research: arXiv cs.RO papers, embodied AI, VLA models, manipulation, navigation and learning systems.
Latest in Research
6273 storiesWALL-SS: Scaling Long-horizon World Models via Next-Scale Autoregression
arXiv:2608.26239v1 Announce Type: new Abstract: Generative world models provide robots with predictive models of how the world evolves under interaction, with g…
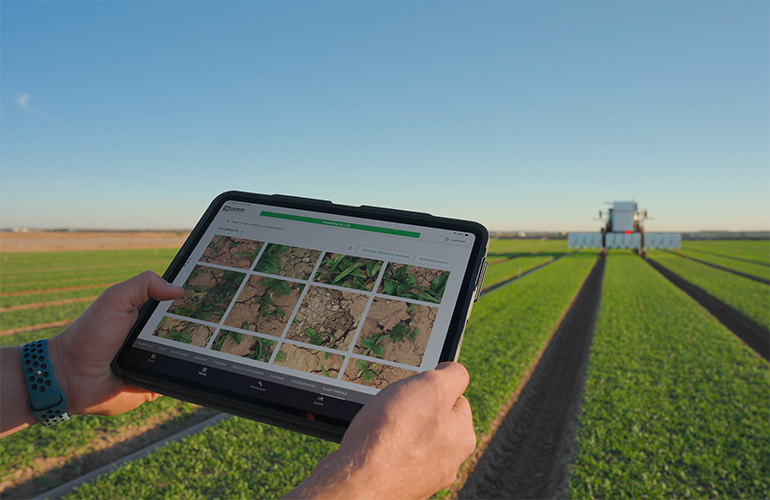
Carbon Robotics partners with iMerit to power instant in-field AI customization
Carbon Robotics introduced a plant foundation AI model and tractor kit, enabling farmers to customize laser weeding. The post Carbon Robotics partners with iMer…
GaussVLA: Geometry-Aware Spatial Reasoning for Vision-Language-Action Model
arXiv:2608.24959v1 Announce Type: new Abstract: Vision-Language-Action (VLA) models encode visual observations as flat 2D patch tokens that carry no intrinsic g…
Generative Action-Chunk Sampling for Adaptive Stiffness Control in Physical Human-Robot Collaboration
arXiv:2608.25284v1 Announce Type: new Abstract: Physical human-robot collaboration requires a robot to provide assistance when human intention is clear while re…
A Tendon-Driven Five-Fingered Hand with Distributed Tactile Perception for Dexterous Manipulation
arXiv:2608.25547v1 Announce Type: new Abstract: To apply the techniques of embodied artificial intelligence to human-oid robots for complex manipulations, dexte…
Leveraging Inter-object Affordances for Efficient Planning in Contact-rich Tasks
arXiv:2608.25641v1 Announce Type: new Abstract: Traditional task-and-motion planning (TAMP) approaches primarily focus on defining sequences of actions along wi…
EgoNav: Bridging Learned Waypoints and Geometry-Aware Local Control for Robust Indoor Navigation
arXiv:2608.25642v1 Announce Type: new Abstract: Image-goal navigation using lightweight topological maps is a practical paradigm for indoor robot deployment: th…
Opportunities of Self Supervised Learning for GNSS: Evaluation of a Deep Learning-Enhanced PVT Algorithm
arXiv:2608.25674v1 Announce Type: new Abstract: This work proposes a Deep Learning Enhanced PVT algorithm to mitigate multipath interference in dense urban area…
Low-Resolution Perception for Robotic Packing
arXiv:2608.25874v1 Announce Type: new Abstract: This work tackles the problem of scalable perception for robotic packing with low-cost, low-resolution depth sen…
DESCENT: Directed Edge Scene Encoding for Airport Surface Movement Prediction
arXiv:2608.26002v1 Announce Type: new Abstract: Advanced automation is a key technology for enhancing the safety of ground operations amidst the increasing dens…
$R^3$: Training Robots to Reason in Natural Language via Reinforcement Learning
arXiv:2608.26053v1 Announce Type: new Abstract: Reasoning in language allows foundation models to spend more test-time compute on hard problems, such as those r…
VirTooS: A ROS 2 - Unity Virtualization Toolkit for Fleet Management of Autonomous Mobile Robots
arXiv:2608.26066v1 Announce Type: new Abstract: In this paper, we present VirTooS, a Python/C# toolkit designed to implement fleet-management tasks on teams of …
Gating Before Commitment: Anticipating Intent Divergence to Prevent Post-Interaction Decision Failures in Autonomous Driving
arXiv:2608.26074v1 Announce Type: new Abstract: Intent misinterpretation during vehicle interactions causes recurring planning failures. We study a decision lay…
PARAssist: A Framework for Personalized and Adaptive Robotic Assistance from Ambiguous User Requests
arXiv:2608.24905v1 Announce Type: cross Abstract: Service robots may encounter ambiguous user requests that require context-aware inference. Users may also have…
Beyond Pairwise Feedback: Listwise Vision-Language Supervision for Preference-Based Reward Learning
arXiv:2608.25350v1 Announce Type: cross Abstract: Vision-language models (VLMs) have emerged as a powerful source of supervision for reinforcement learning, ena…
Trust-Aware Sequential Decision Making and Rollout Planning for Resilient Multi-Robot Systems
arXiv:2608.25690v1 Announce Type: cross Abstract: Sequential decision-making in multi-robot systems typically assumes that planning information is reliable and …
Multi-Touch and Bending Sensing Using Electrical Impedance Tomography for Robotics
arXiv:2503.13048v4 Announce Type: replace Abstract: Electrical Impedance Tomography (EIT) offers a promising solution for distributed tactile sensing with minim…
Performance-guided Task-specific Optimization for Multirotor Design
arXiv:2510.04724v2 Announce Type: replace Abstract: This paper introduces a methodology for task-specific design optimization of multirotor Micro Aerial Vehicle…
Dynamically-Consistent Trajectory Optimization for Legged Robots via Contact Point Decomposition
arXiv:2510.24069v2 Announce Type: replace Abstract: To generate reliable motion for legged robots through trajectory optimization, it is crucial to simultaneous…
Learning to Accelerate Vision-Language-Action Models through Adaptive Visual Token Caching
arXiv:2602.00686v2 Announce Type: replace Abstract: Vision-Language-Action (VLA) models have demonstrated remarkable generalization capabilities in robotic mani…
Tutorial on Aided Inertial Navigation Systems: A Modern Treatment Using Lie-Group Theoretical Methods
arXiv:2603.07143v2 Announce Type: replace Abstract: This tutorial presents a control-oriented introduction to aided inertial navigation systems using a Lie-grou…
Symmetries Here and There, Combined Everywhere: Cross-space Symmetry Compositions in Robotics
arXiv:2605.22639v3 Announce Type: replace Abstract: Robots exhibit a rich variety of symmetries arising from their mechanical structure and the properties of th…
Point2Pose: Occlusion-Recovering 6D Pose Tracking and 3D Reconstruction for Multiple Unknown Objects Via 2D Point Trackers
arXiv:2604.10415v2 Announce Type: replace-cross Abstract: We present Point2Pose, a model-free method for causal 6D pose tracking of multiple rigid objects from …
Three-Way Open-Set Detection for Robust Autonomous Navigation
arXiv:2511.15343v2 Announce Type: replace-cross Abstract: Autonomous navigation in complex scenes requires reliable perception across scenarios that the model d…
Model-Agnostic Open-Set Air-to-Air Visual Object Detection for Reliable UAV Perception
arXiv:2509.09297v2 Announce Type: replace-cross Abstract: Open-set detection is crucial for robust UAV autonomy in air-to-air object detection under real-world …
ScaRF-SLAM: Scale-Consistent Reconstruction with Feed-Forward Models and Classical Visual SLAM
arXiv:2606.00307v2 Announce Type: replace Abstract: Recent works have explored unifying SLAM with geometric foundation models (GFMs). However, directly using GF…
Human vs. Teleoperated Robots in Vineyard Management: A Simulation-Based Analysis of Travel Speed, Routing, and Task Performance
arXiv:2507.04167v2 Announce Type: replace Abstract: Rising labor costs and narrow treatment windows have made teleoperated robots a proposed tool for vineyard s…
VBVR-Pro: A Scalable and Verifiable Suite for Native Visual Reasoning
arXiv:2608.26105v1 Announce Type: cross Abstract: Native visual reasoning treats visual generation as the medium of reasoning itself: visual states (i.e. images…
SonicNudge: Controlled Displacement of Hovering UAVs via Estimator-Controller Coupling
arXiv:2608.25319v1 Announce Type: cross Abstract: UAV displacement attacks have traditionally relied on spoofing sensors that directly report position or transl…
One Policy, Many Embodiments: Unified Camera-Centric Action Geometry Pre-training for Heterogeneous Embodied Manipulation
arXiv:2608.26058v1 Announce Type: new Abstract: Scaling generalist vision-language-action (VLA) policies is severely bottlenecked by the inherent heterogeneity …