Research
Frontier robotics research: arXiv cs.RO papers, embodied AI, VLA models, manipulation, navigation and learning systems.
Frontier robotics research: arXiv cs.RO papers, embodied AI, VLA models, manipulation, navigation and learning systems.
Latest in Research
6273 storiesSystematic Lightweight Method for Robotics Based on Strain Energy Distribution Optimization
arXiv:2608.29146v1 Announce Type: new Abstract: Service robots work with people and are highly expected to be lightweight for safety, agility and energy conserv…
A Cognitive Architecture for Shared Autonomy in AUV Operations
arXiv:2608.29347v1 Announce Type: new Abstract: Operators remain essential to Remotely Operated Vehicle (ROV) operation, yet often suffer from low situational a…
Toward Trustworthy Robot-Assisted Sliding Palpation for Shallow Vessel Localisation with a Calibrated Digital Twin
arXiv:2608.29396v1 Announce Type: new Abstract: Reliable localisation of shallow subsurface vessels is important for safe robot-assisted venous access and vesse…
HybridWorldSim: A Scalable and Controllable High-fidelity Simulator for Autonomous Driving
arXiv:2511.22187v4 Announce Type: replace-cross Abstract: Realistic and controllable simulation is critical for advancing end-to-end autonomous driving, yet exi…
Constrained Group Relative Policy Optimization
arXiv:2602.05863v3 Announce Type: replace-cross Abstract: Group Relative Policy Optimization (GRPO) remains the dominant critic-free approach for fine-tuning LL…
RoboTrustBench: Benchmarking the Trustworthiness of Video World Models for Robotic Manipulation
arXiv:2606.01600v2 Announce Type: replace-cross Abstract: Video world models are increasingly used in robotic manipulation, yet existing benchmarks mostly evalu…
A Kinematic Framework for Screening Candidate Pinch Configurations in Robotic Hand Design without Object or Contact Models
arXiv:2604.20692v2 Announce Type: replace Abstract: Evaluating the pinch capability of a robotic hand is important for understanding its functional dexterity. H…
The Structure of Merging Turbulent Jets Beneath a Small Quadrotor
arXiv:2608.30900v1 Announce Type: cross Abstract: The downwash wake of a hovering quadrotor governs both the vehicle's own performance and the safe spacing of m…
VeloBins: Learning Velocity and Its Uncertainty via Bins and Error-Conditioned Gaussian Labels for Aerial Inertial Odometry
arXiv:2608.29720v1 Announce Type: new Abstract: Inertial odometry (IO) is critical for aerial robots, where aggressive maneuvers and poor lighting degrade visua…
Learning Agile Perceptive Traversal of Sparse 3D Structures for Humanoids
arXiv:2608.29769v1 Announce Type: new Abstract: Traversing sparse 3D structures requires humanoid robots to perceive thin, overhanging geometry while executing …
System Identification of Admittance Models for Large Real-World Objects
arXiv:2608.29935v1 Announce Type: new Abstract: Simulation of admittance-type models requires physically consistent dynamic models that are rarely available for…
MiBOT: A head-worn robot that modulates cardiovascular responses through human-like soft massage
arXiv:2608.30055v1 Announce Type: new Abstract: Massage therapy is helpful for the rehabilitation of various diseases, such as headaches caused by migraines and…
Optimized Modular Design and Development of a Tilt-Rotor Bicopter Drone
arXiv:2608.30222v1 Announce Type: new Abstract: Hybrid systems like tilt-rotor bicopter drones combine the beneficial characteristics of both fixed-wing and rot…
CanonNav: Disentangling Navigation Behavior from Camera Geometry in Cross-Platform Visual Navigation
arXiv:2608.30242v1 Announce Type: new Abstract: While visual navigation has advanced through imitation learning from cross-platform demonstrations, fully levera…
CometVLA: Co-Training on an Embodied Data Pyramid towards Physical Understanding
arXiv:2608.30289v1 Announce Type: new Abstract: Vision-language-action (VLA) models remain brittle in manipulation tasks that require physical commonsense. Curr…
Data-Centric Neuromotor Interfaces for Portable Human-Machine Interaction
arXiv:2608.30301v1 Announce Type: new Abstract: Dexterous human-machine interaction requires intuitive and expressive interfaces that can be efficiently deploye…
AGRICAM: A Track-Mounted Crop Pollination Monitoring Robot
arXiv:2608.29237v1 Announce Type: cross Abstract: Insect pollination is critical for global food production, yet monitoring pollinators at commercial farm scale…
Fully Distributed GNE Algorithms for Multi-Robot Placement without Consensus on Multipliers
arXiv:2608.29388v1 Announce Type: cross Abstract: Recent machine learning research has increasingly focused on equilibrium analysis in non-cooperative games rat…
Feelium: A Touchable Blimp Body for Aerial Telepresence
arXiv:2608.29391v1 Announce Type: cross Abstract: Floating things invite touch. We present Feelium, a blimp-based telepresence platform that enables visual embo…
Calibration and Comparative Analysis of Forward-Looking Sonar and 3D Sonar for Enhanced Underwater Object Recognition
arXiv:2608.29433v1 Announce Type: cross Abstract: Sonars generate a significant amount of noise. With the advent of new technology capable of producing full 3D …
Event-triggered Control and Online Learning for Networked Systems under Computational Delays
arXiv:2608.29576v1 Announce Type: cross Abstract: Online learning-based control is a promising approach to control uncertain systems, where unknown components a…
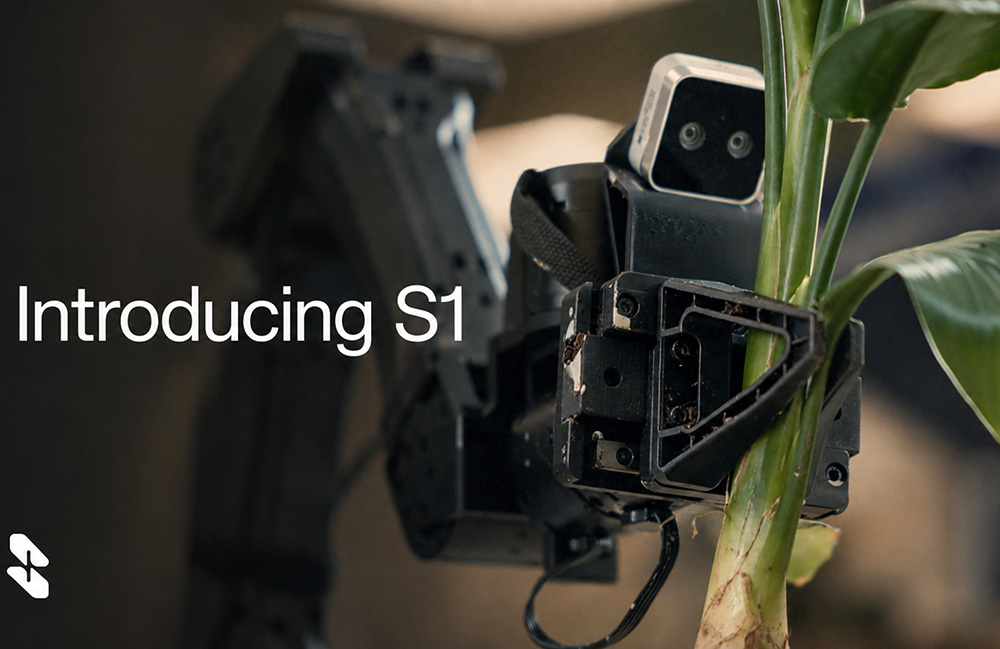
Skild AI unveils S1 flagship robot foundation model
Skild AI says its S1 robot foundation model enables robots to learn new tasks just by seeing a video of it being performed. The post Skild AI unveils S1 flagshi…
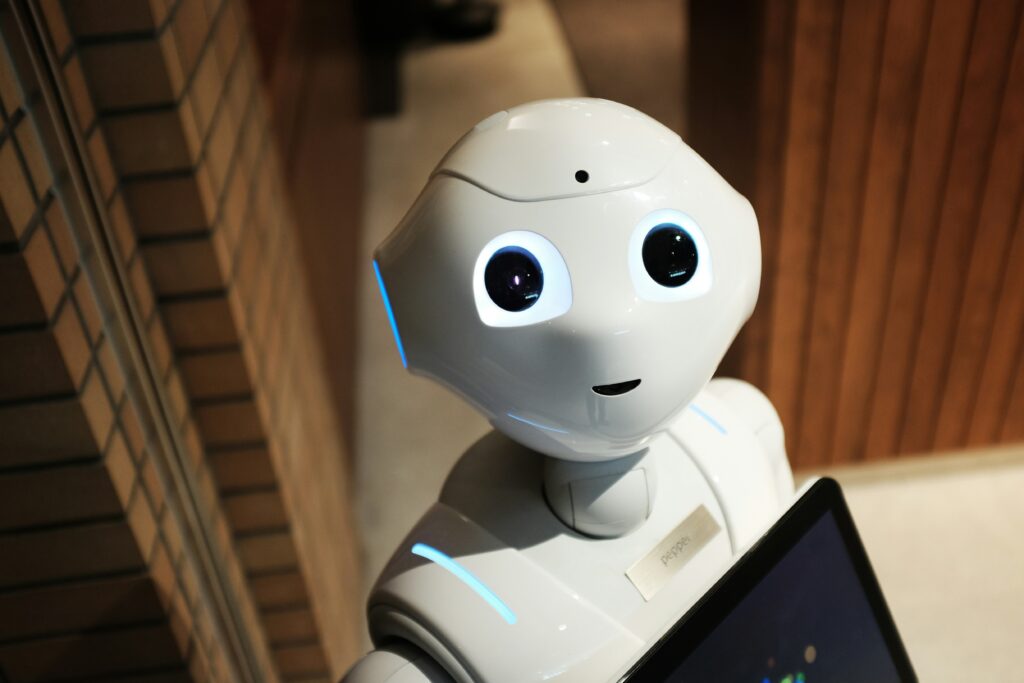
When expressive humanoid robots are awkward, people become wary – new brain study
Photo by Alex Knight on Unsplash. By Hasan Ayaz, Drexel University; Ewart J. de Visser, United States Air Force Academy; Frank Krueger, George Mason University,…
Beyond Relative Geometry: Metric-Aware Geometry Perception for Robotics
arXiv:2608.27497v1 Announce Type: new Abstract: Recent embodied models increasingly leverage geometric representations to improve spatial reasoning and robotic …
Remote Human and Robot Interaction for Greenhouse Gardening Using Virtual Reality
arXiv:2608.27545v1 Announce Type: new Abstract: This study evaluates the effectiveness of remote human-robot interaction using virtual reality for leaf inspecti…
Beyond Data Scaling: Representation-Centric Continued Pre-training for Vision-Language-Action Models
arXiv:2608.27550v1 Announce Type: new Abstract: Scaling robot data is crucial for building generalist Vision-Language-Action (VLA) models, yet robot trajectorie…
Distributed Model-Based Diffusion: Finite Horizon Contraction under Bounded Delay
arXiv:2608.27685v1 Announce Type: new Abstract: Simultaneously optimizing the trajectories of multiple agents is a challenging problem plagued by nonlinearity, …
Plan Along the Way: Event-Triggered Foundation-Model Planning for TAMP Execution in Partially Observable Manipulation
arXiv:2608.28075v1 Announce Type: new Abstract: Manipulation in partially observable environments requires planning under incomplete scene information. In such …
Stay Seated: Learning Omnidirectional Humanoid Locomotion on a Passive Mobile Chair with Casters
arXiv:2608.28090v1 Announce Type: new Abstract: Humanoid robots with quasi-direct-drive actuators continuously generate joint torque while standing, whereas sea…
Contact-Guided Exploration for Non-Prehensile Locomanipulation with Multi-Critic RL
arXiv:2608.28140v1 Announce Type: new Abstract: Non-prehensile manipulation offers versatile skills for moving and rearranging heavy or bulky objects, particula…