News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4147 storiesSemantic Haptic Feedback Enhances Dexterous Robotic Teleoperation
arXiv:2608.02780v1 Announce Type: new Abstract: In robot teleoperation, haptic feedback can be used to help human operators accomplish dexterous manipulation ta…
Electrostatic Clutch-Based Mechanical Multiplexer with Increased Force Capability
arXiv:2501.08469v5 Announce Type: replace Abstract: As robotic systems become increasingly articulated, conventional actuation still dedicates one motor to each…
ETA: A New Agentic Paradigm for Embodied Tasks
arXiv:2608.03924v1 Announce Type: new Abstract: When will robots have their ChatGPT moment? Such a breakthrough requires a general-purpose robot that can handle…
POMDPs for Autonomous Science Exploration
arXiv:2608.03155v1 Announce Type: new Abstract: Autonomous exploration missions require decision-making under sensor uncertainty and computational constraints, …
PFM-HR: Pose Flow Matching for Humanoid Robots
arXiv:2608.03227v1 Announce Type: new Abstract: Motion priors improve reinforcement learning for physics-based humanoid tracking, but temporal priors require or…
RoboReact: Agentic Skill Distillation from Generated Egocentric Videos for Generalizable Whole-Body Manipulation
arXiv:2608.03387v1 Announce Type: new Abstract: Humanoid robots have the potential to perform dexterous manipulation in human environments, yet acquiring divers…
DigitCode: Symbolic Tokenization of Hand Motion by Anatomical Units
arXiv:2608.03127v1 Announce Type: new Abstract: Hand motion carries the finest-grained information in human activity, yet the representations behind hand genera…
Structure-Aware Robust Fine-Tuning: Defending Vision-Language-Action Robots Against Physical Attention Hijacking
arXiv:2608.03231v1 Announce Type: new Abstract: Vision-Language-Action (VLA) policies promise general robotic manipulation, but their robustness against physica…
Light-Loco-Parkour: Versatile Perceptive Whole-Body Locomotion via Multi-Skill Distillation
arXiv:2608.02653v1 Announce Type: new Abstract: Existing humanoid whole-body control systems still fall short of the way humans move through cluttered terrain: …
DeRP: An Algorithm for Self-Assembly of Power-Delivery Networks using Recursive Branching in Information-Limited Environments
arXiv:2608.02904v1 Announce Type: new Abstract: Delivering sustained power to distributed equipment in unstructured field environments using pre-planned wired n…
Principles of Robot Autonomy
arXiv:2608.03496v1 Announce Type: new Abstract: Autonomous robots are moving rapidly from research labs into everyday life - on roads, in the air, in warehouses…
Forbidden Region Dynamic Active Constraints in Robot-Assisted Minimally Invasive Surgery
arXiv:2608.03010v1 Announce Type: new Abstract: In robot-assisted surgery, Forbidden Region Active Constraints (FRAC) represent a control strategy that helps ma…
Lightweight 3D Object Detection via Mamba-Based Knowledge Distillation
arXiv:2608.03490v1 Announce Type: new Abstract: 3D object detection using light detection and ranging (LiDAR) sensors requires a balance between accuracy and co…
Accelerating Human-Aware Robot Trajectory Generation via Diffusion and Consistency Distillation
arXiv:2608.03159v1 Announce Type: new Abstract: This research proposes a constrained motion planning framework for robot manipulators in human-robot interaction…
Design and Evaluation of an AI-Enabled Cloud-Edge Architecture for Connected Precision Agriculture Farms
arXiv:2608.03816v1 Announce Type: new Abstract: Plant diseases cause significant yield losses worldwide, with tomato crops particularly susceptible to early bli…
Active Stiffness Control of a Supportive Continuum Robot
arXiv:2608.03677v1 Announce Type: new Abstract: Supportive continuum robots (SCRs) enhance the load-bearing capability of an operative continuum robot by mechan…
Staying on Spec: Real-Time Monitoring under Uncertainty with a Maritime Case Study
arXiv:2608.02811v1 Announce Type: new Abstract: Robotic systems must operate under uncertainty while satisfying complex task and safety specifications. Monitori…
Track4Action: Distilling World-Centric 3D Tracker into Vision-Language-Action Policies
arXiv:2608.03727v1 Announce Type: new Abstract: Action labels tell a vision-language-action (VLA) policy which robot commands to imitate, but not how those comm…
FGGS-LiDAR: Ultra-Fast, GPU-Accelerated Simulation from General 3DGS Models to LiDAR
arXiv:2509.17390v3 Announce Type: replace Abstract: While 3D Gaussian Splatting (3DGS) has emerged as a strong representation for photorealistic rendering, its …
GEM-4D: Geometry-Enhanced Video World Models for Robot Manipulation
arXiv:2605.22882v4 Announce Type: replace-cross Abstract: Video world models can generate realistic futures from a single instruction, but they often fail to tr…
Contact-Driven Localization in a Freeform Robotic Self-Assembled Structure
arXiv:2608.02895v1 Announce Type: new Abstract: Accurate localization remains a key challenge in swarm robotics, particularly for self-reconfigurable systems th…
Gated Memory Policy: In-Context Memorization and Adaptation
arXiv:2604.18933v2 Announce Type: replace Abstract: Robotic manipulation tasks exhibit varying memory requirements, ranging from Markovian tasks that require no…
On-the-fly hand-eye calibration for the da Vinci surgical robot
arXiv:2601.14871v3 Announce Type: replace Abstract: In Robot-Assisted Minimally Invasive Surgery (RMIS), accurate tool localization is crucial to ensure patient…
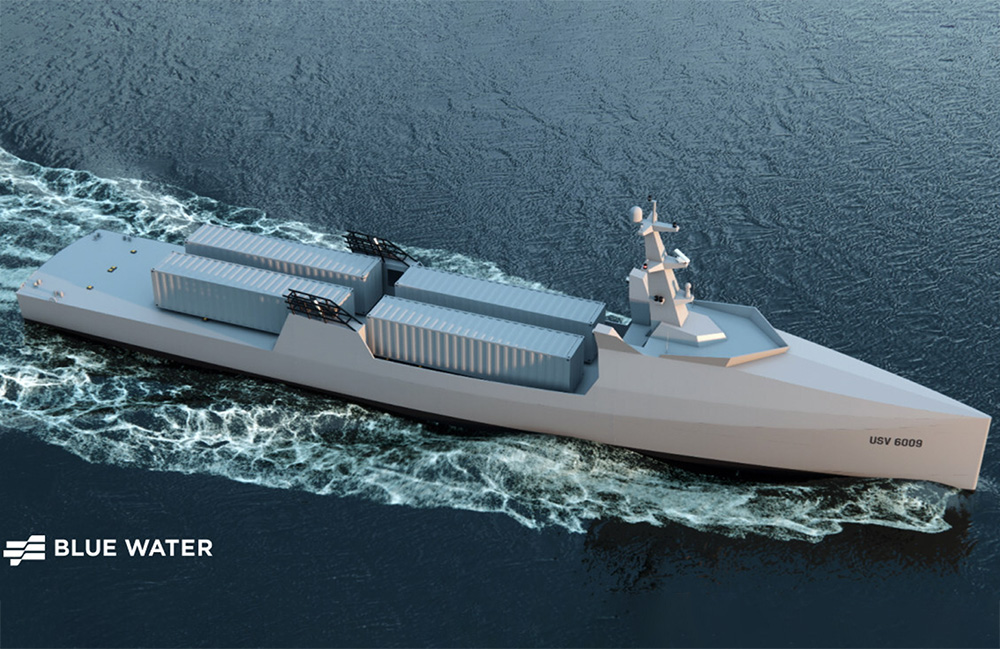
U.S. Navy picks Blue Water Autonomy to use autonomous vessels for deep ocean surveys
Blue Water Autonomy creates unmanned ships that can operate autonomously on the open ocean for months a time. The post U.S. Navy picks Blue Water Autonomy to us…
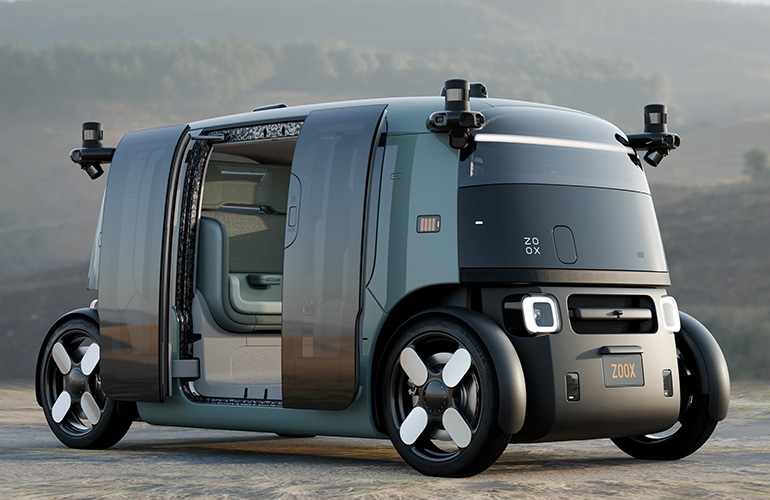
Zoox unveils production-ready robotaxi for U.S. expansion
Amazon subsidiary Zoox unveiled its final production-ready robotaxi design and expanded testing following a subtle redesign to improve rider comfort. The post Z…
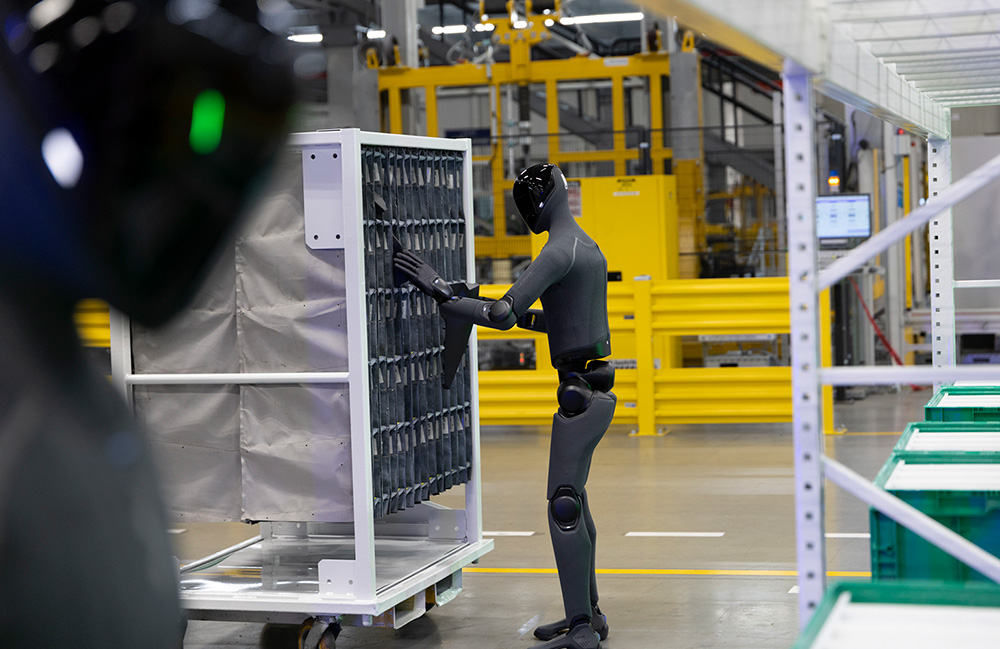
Humanoids won’t scale on factory floors until costs drop
The race to commercialize humanoids is on. What’s left to prove is that humanoid robots can beat the economics of the automation manufacturers are already runni…
VertiAKD: Adaptive Off-Road Kinodynamics on Vertically Challenging Terrain
arXiv:2608.00945v1 Announce Type: new Abstract: Off-road mobility requires autonomous mobile robots to generalize across heterogeneous vehicle fleets and contin…
3D-CovDiffusion: 3D-Aware Diffusion Policy for Coverage Path Planning
arXiv:2510.03011v2 Announce Type: replace Abstract: Diffusion models have shown strong potential for robot skill learning, yet their role in coverage path plann…
DreamTrajectory: Trajectory-Guided Action Generation with World Model Alignment for Mobile Manipulation
arXiv:2608.01381v1 Announce Type: new Abstract: Mobile manipulation requires a robot to coordinate base and arm motion under continuously changing viewpoints an…
Multi-View Unified Camera Fields: Geometry-Shaped Action-Facing Representations for RGB-Only Multi-Camera VLA Policies
arXiv:2608.01826v1 Announce Type: new Abstract: Vision-Language-Action (VLA) models have shown strong generalization in robotic manipulation, yet complex contac…