News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4147 storiesSuppression Sticks, Locality Is Fragile: A Closed-Loop Target-and-Control Audit of Task-Vector Negation in VLA Policies
arXiv:2608.04692v1 Announce Type: new Abstract: Task-vector arithmetic offers a closed-form way to modify a model, yet its behavioral locality remains unclear i…
SiMDex: Mining Similar Egocentric Videos for Cross-Embodiment Dexterous Manipulation
arXiv:2608.04196v1 Announce Type: new Abstract: Recent years have witnessed an explosive trend of scaling ego-centric human videos for robot manipulation, yet i…
AI-based single-shot structured-light depth reconstruction for real-time laparoscopic surgical guidance
arXiv:2608.05109v1 Announce Type: cross Abstract: Significance. Accurate intraoperative depth perception is important for autonomous and semi-autonomous robotic…
SafeLand: Safe Autonomous Landing in Unknown Environments with Bayesian Semantic Mapping
arXiv:2603.17430v2 Announce Type: replace Abstract: Autonomous landing of uncrewed aerial vehicles (UAVs) in unknown, dynamic environments poses significant saf…
Learning Direct Control Policies with Flow Matching for Autonomous Driving
arXiv:2605.14832v2 Announce Type: replace Abstract: We present a flow-matching planner for autonomous driving that directly outputs actionable control trajector…
A Vision-based Control Framework for Real-time Autonomous UUV Operations
arXiv:2608.04723v1 Announce Type: new Abstract: This paper presents a fully integrated vision-based framework for real-time and robust localization, autonomous …
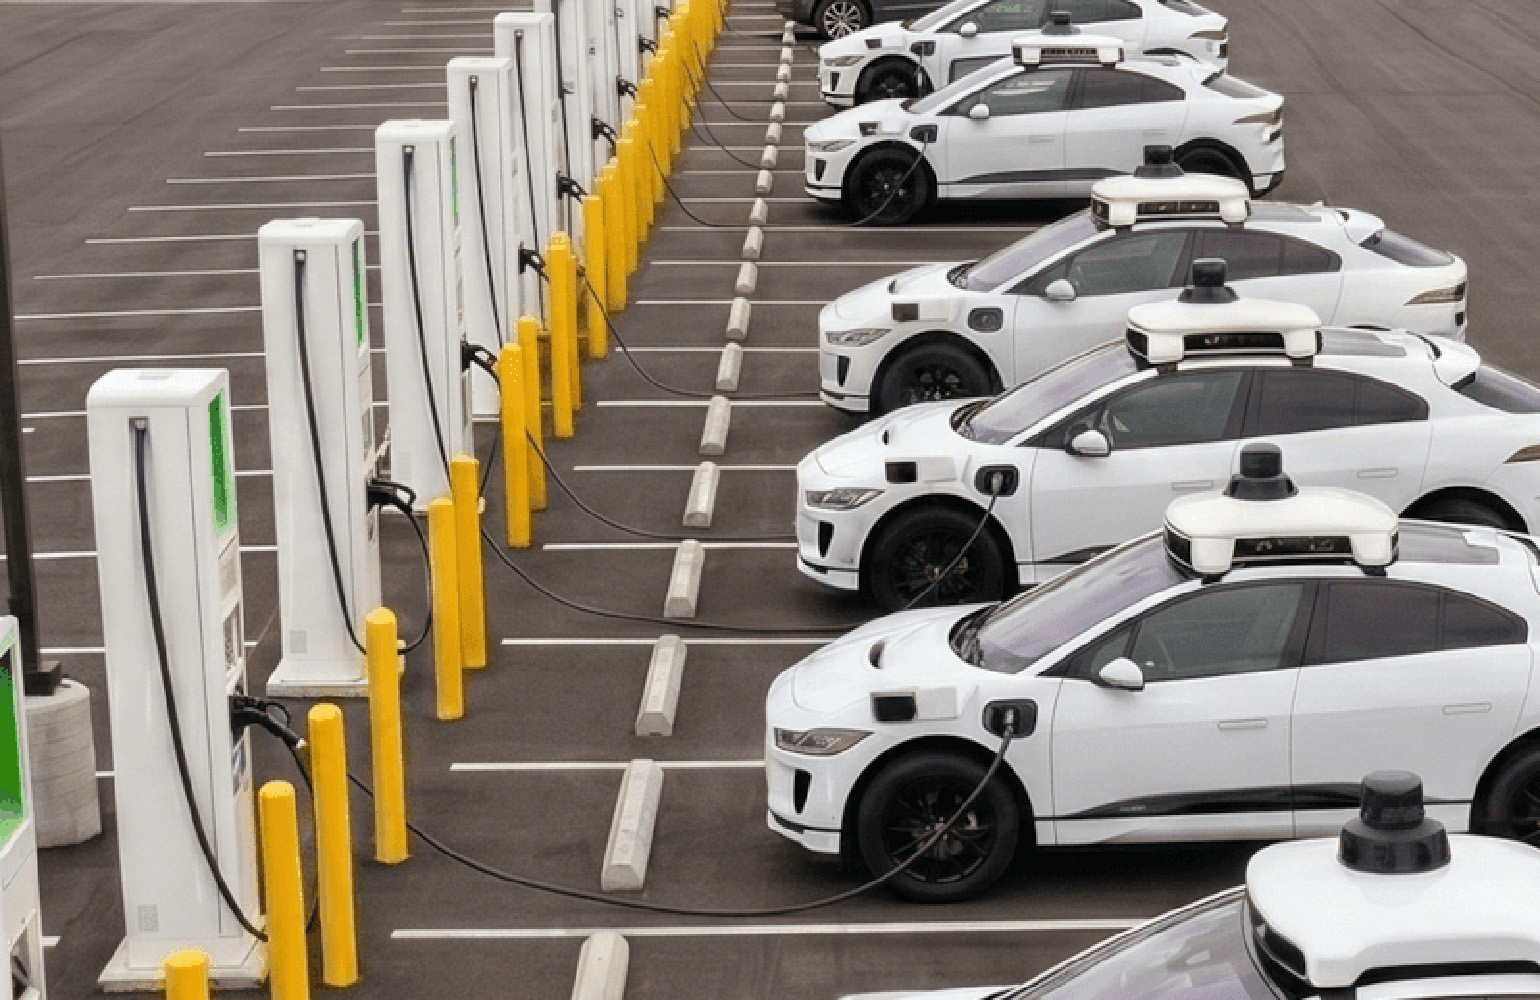
Moove raises $250M to build infrastructure for autonomous vehicles
The funding will support Moove's expansion of its autonomous fleet ownership and robotics-first depot infrastructure “Nests.” The post Moove raises $250M to bui…

University of Florida opens new robotics lab dedicated to industrialized construction
Fueled by Autodesk, UF opened a robotics lab for industrialized construction to fight housing shortages and labor declines. The post University of Florida opens…

GAM Enterprises to produce Schaeffler’s PSC gear reducers
Acquiring the IP from this core supplier allows GAM to vertically integrate its supply chain and expand its manufacturing capabilities. The post GAM Enterprises…
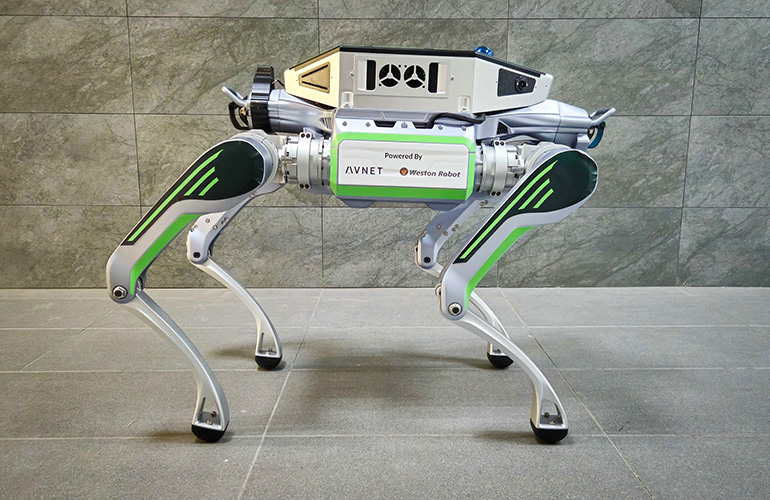
Avnet and Weston Robot partner to launch edge AI inspection platform
Avnet and Weston Robot have partnered to launch an AI-powered autonomous inspection platform for complex industrial environments. The post Avnet and Weston Robo…
Why perception is the key to scaling industrial autonomy
Autonomy is no longer just about robotic motor skills. It encompasses machine awareness, dynamic decision-making, multi-vehicle coordination, and spatial precis…
Pivot-Centric Trajectory Prediction: Bridging Long Horizons via Dynamical Guidance
arXiv:2608.03521v1 Announce Type: new Abstract: Forecasting precise future motion of surrounding agents is essential for reliable autonomous vehicles. However, …
LiLa-WAM: Lightweight Latent Reasoning World-Action Model for Robotic Manipulation
arXiv:2608.03701v1 Announce Type: new Abstract: World-action modeling has emerged as a promising paradigm for robotic control, as it empowers models to go beyon…
How Should Vision-Language-Action Models Use Proprioceptive State?
arXiv:2608.03052v1 Announce Type: new Abstract: Recent Vision-Language-Action (VLA) models almost universally take robot proprioceptive state as input, yet wire…
Learning Context-Aware Motion Priors for Humanoid Control
arXiv:2608.03234v1 Announce Type: new Abstract: Motion priors provide powerful guidance for learning naturalistic humanoid behaviors. However, existing methods …
PACE: Physics Augmentation for Coordinated End-to-end Reinforcement Learning toward Versatile Humanoid Table Tennis
arXiv:2509.21690v5 Announce Type: replace Abstract: Humanoid table tennis (TT) demands rapid perception, proactive whole-body motion, and agile footwork under s…
Toward Certified Functional Safety for Industrial Humanoid Robots: The Fail-Passive Gap and a Feasibility Study
arXiv:2608.02809v1 Announce Type: new Abstract: Industrial humanoid robots are constrained less by locomotion or manipulation capability than by the immaturity …
Passively Safe Convex Guidance for Cislunar Rendezvous and Proximity Operations
arXiv:2608.03060v1 Announce Type: new Abstract: This paper presents purely convex programs for passively safe impulsive rendezvous and proximity operations in c…
PhyAI: Real-Time Physical AI at the Edge, Scalable Rollouts in the Cloud
arXiv:2608.03682v1 Announce Type: cross Abstract: Physical AI policies require inference throughout their lifecycle, including model evaluation, cloud reinforce…
Multimodal Plant Root Phenotyping with Integration of 3D Skeleton Extraction and Language Analysis
arXiv:2608.03109v1 Announce Type: cross Abstract: Plant root phenotyping is fundamental to understanding below-ground structures, optimizing crop management, an…
GORDON: Graph-based Object-centric Rewards for Decomposition of Long-Horizon Manipulation
arXiv:2608.03753v1 Announce Type: new Abstract: Learning long-horizon manipulation skills with reinforcement learning remains challenging due to the complexity …
A Hierarchical Approach to Imitation Learning for Manipulation Tasks Requiring Time Varying Forces
arXiv:2608.03103v1 Announce Type: new Abstract: Diffusion policies have shown strong performance in learning complex, multi-modal behaviors for robotic manipula…
Bridging Online and Offline Handwriting via Differentiable Physical Rendering
arXiv:2608.03198v1 Announce Type: cross Abstract: Realistic handwritten text generation plays an important role in numerous applications, such as font design, b…
Unified Visuomotor Targets: Supervising VLAs Beyond Physical Actions
arXiv:2608.03563v1 Announce Type: new Abstract: VLA models are trained to predict robot actions from visual and language observations. This is a natural choice,…
ValueFormer: A Causal Transformer Value Function with Stage-Aware Labels for Semi-Autonomous Vision-Language-Action Policies
arXiv:2608.02958v1 Announce Type: new Abstract: Vision-Language-Action (VLA) policies trained by behavior cloning fail silently: from the action stream alone, a…
Mixed-Initiative Human-Robot Teaming under Suboptimality with Online Bayesian Adaptation
arXiv:2403.16178v2 Announce Type: replace Abstract: For effective human-agent teaming, robots and other artificial intelligence (AI) agents must infer their hum…
Stiffness Copilot: An Impedance Policy for Contact-Rich Teleoperation
arXiv:2603.14068v2 Announce Type: replace Abstract: In teleoperation of contact-rich manipulation tasks, selecting robot impedance is critical but difficult. Th…
PLS-Calib: A Partial Least Squares Framework for Event Camera and Odometry Calibration under Ground Motion Constraints
arXiv:2608.03296v1 Announce Type: new Abstract: Accurate extrinsic rotation calibration between sensors is fundamental to the performance of robotic perception …
Graph Neural Planning and Predictive Control for Multi-Robot Communication-Constrained Unlabeled Motion Planning
arXiv:2605.19209v2 Announce Type: replace Abstract: The multi-robot unlabeled motion planning problem of concurrently assigning robots to goals and generating s…
GS-Playground: A High-Throughput Photorealistic Simulator for Vision-Informed Robot Learning
arXiv:2604.25459v2 Announce Type: replace Abstract: Embodied AI research is undergoing a shift toward vision-centric perceptual paradigms. While massively paral…