News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4147 storiesA Disturbance in the Force: Force Actuation on the RAVEN II Surgical Robot with Parallel Motor-Cable Units
arXiv:2608.06488v1 Announce Type: new Abstract: Difficulty in haptic feedback for surgical robots has been a long-term problem for decades. In recent years, lea…
SyncSBC: Decentralized Swarm Behavior Prediction for Synchronized Autonomous Control
arXiv:2608.06587v1 Announce Type: new Abstract: Robot swarms utilize many independent limited-sensing agents to produce complex emergent behaviors without requi…
SoRoMoX: Fast, Differentiable, and Parallelizable Soft Robot Models
arXiv:2608.06650v1 Announce Type: new Abstract: Reduced-order models based on Cosserat-rod theory are now well established, and modeling theory is no longer the…
Hoverflie: An empirical investigation of rotor shrouds to transform micro air vehicles into multi-modal hovercraft
arXiv:2608.06707v1 Announce Type: new Abstract: Small rotorcraft intended for use indoors or around the built environment have extremely limited flight duration…
R2S-EGO: Dual-Proxy Refinement for Sparse-Capture Real-to-Sim
arXiv:2608.06827v1 Announce Type: new Abstract: Real-to-sim (R2S) depends on scene representations that render observations along robot ego trajectories, yet de…
When Coordination Becomes a Threat: Communication Attacks in LLM-Controlled Multi-Robot Systems
arXiv:2608.06830v1 Announce Type: new Abstract: Large Language Models (LLMs) are increasingly used as high-level planners in embodied multi-robot systems, enabl…
Cross-View Action Consistency for Camera-Robust Vision-Language-Action Policies
arXiv:2608.06965v1 Announce Type: new Abstract: Vision-language-action (VLA) policies fine-tuned from a fixed scene camera can fail when the camera is moved, ev…
Representation Handoffs for OpenArm-Based Laboratory Mobile Manipulation
arXiv:2608.07154v1 Announce Type: new Abstract: Open-source robotics and foundation models have lowered the barrier to embodied AI, yet language-guided laborato…
Ising Acceleration for Multi-Robot Multi-Target Planning
arXiv:2608.06803v1 Announce Type: cross Abstract: Ising machines are emerging as promising hardware for combinatorial optimization. With recent advances in CMOS…
Accurate Trajectory Tracking with Model Predictive Contouring Control for Bird-Scale Flapping-Wing MAVs
arXiv:2605.06042v3 Announce Type: replace Abstract: Flapping-wing micro aerial vehicles offer quieter and safer operation than rotary-wing drones, yet achieving…
EchoVLA: Robotic Vision-Language-Action Model with Synergistic Declarative Memory for Mobile Manipulation
arXiv:2511.18112v3 Announce Type: replace Abstract: Recent progress in Vision-Language-Action (VLA) models has enabled embodied agents to interpret multimodal i…
Rigid-Covert GNSS Spoofing of UAV Swarms: A Structural Blind Spot, Its Detection Limit, and Absolute-Anchor Defenses
arXiv:2608.06885v1 Announce Type: cross Abstract: Cooperative UAV-swarm defenses commonly cross-check GNSS positions against measured inter-drone geometry. We s…
Detection and Ranging of Transient Extrinsic Contacts Based on 6D Dynamic Tactile Sensing
arXiv:2608.07075v1 Announce Type: new Abstract: Delicate manipulation often involves transient and subtle collisions between a grasped object and the environmen…
AutoIntervene: Calibrated Intervention for Action-Chunking Imitation Learning Policies
arXiv:2608.07065v1 Announce Type: new Abstract: Action-chunking visuomotor policies learn from demonstrations and improve temporal consistency by predicting sho…
C2Dex: Contact-Consistent Reconstruction and Retargeting for Dexterous Manipulation from Monocular Video
arXiv:2608.07045v1 Announce Type: new Abstract: High-quality demonstrations for dexterous robot manipulation are costly and difficult to collect, whereas monocu…
A Haptic Robot Finger Designed for Guqin Instrument Playing
arXiv:2608.07002v1 Announce Type: new Abstract: With the rapid advancement of humanoid robotics and embodied intelligence technologies, numerous musical instrum…
How Should I Pick a Foundation Model for My Robot? In Favor of a Community Evaluation Framework for Social Robots
arXiv:2608.06898v1 Announce Type: new Abstract: Researchers who seek to build social robot applications on foundation models are faced with a difficult question…
Panoramic Multimodal Semantic Occupancy Prediction for Quadruped Robots
arXiv:2603.13108v2 Announce Type: replace Abstract: Panoramic imagery provides holistic 360{\deg} visual coverage for environmental perception in quadruped robo…
Robot guide with multi-agent control and automatic scenario generation with LLM
arXiv:2509.10317v2 Announce Type: replace Abstract: The article describes the development of a hybrid social robot control architecture to overcome the limitati…
Beyond Visibility: Real-Time Surface Accessibility Fields from Sparse LiDAR
arXiv:2608.06412v1 Announce Type: cross Abstract: Understanding which surfaces in a scene are physically accessible to a given tool is fundamental for robotic i…
Unordered Landmark Visual Navigation
arXiv:2608.06833v1 Announce Type: new Abstract: Image-goal navigation is a fundamental capability for embodied AI, yet its practical deployment is strained by s…
Is Forward Prediction Enough? Physical State Grounding for JEPA World Models
arXiv:2608.06799v1 Announce Type: new Abstract: Learning structured and control-relevant latent representations remains a key challenge for world models. Recent…
AtlasVLA: Persistent World-Ego State Modeling for Vision-Language-Action Models
arXiv:2608.06729v1 Announce Type: new Abstract: While Vision-Language-Action (VLA) models have advanced embodied AI, their fundamentally reactive paradigm sever…
CrossTracer: Cross-Embodiment Navigation via VLA Model Reasoning and Trace Residuals Adapting
arXiv:2608.06688v1 Announce Type: new Abstract: Vision-language-action (VLA) models provide strong semantic priors for robot navigation, but they often ignore e…
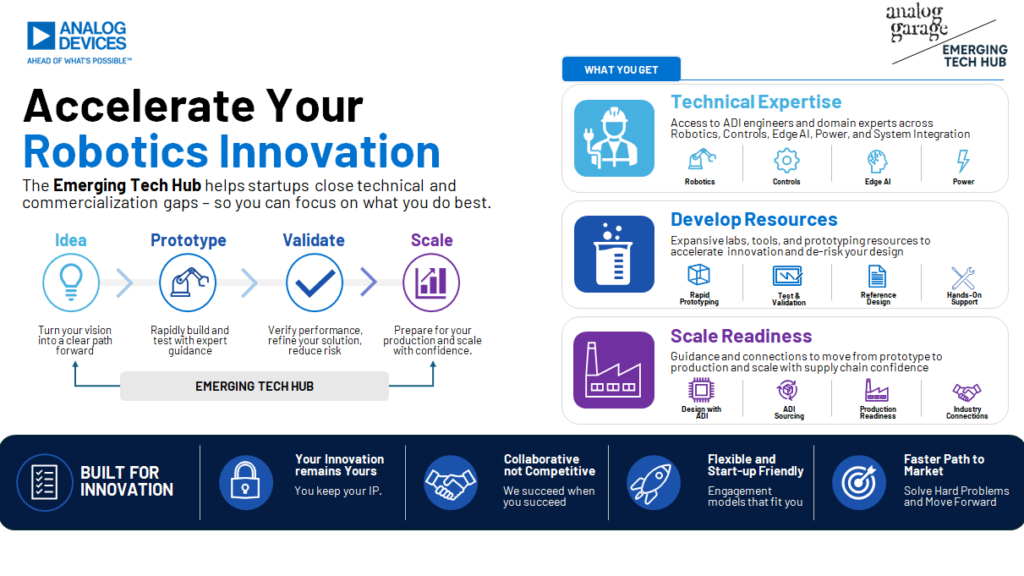
Analog Devices returns as strategic sponsor to aid MassRobotics startups
Analog Devices Inc. is supporting MassRobotics startups with Analog Garage and participating in events including RoboBusiness. The post Analog Devices returns a…
Experts look ahead at the next 20 years of robotics at RoboBusiness
At Robobusiness, leaders in robotics will explore the technologies, opportunities, and challenges that will shape the next twenty years. The post Experts look a…
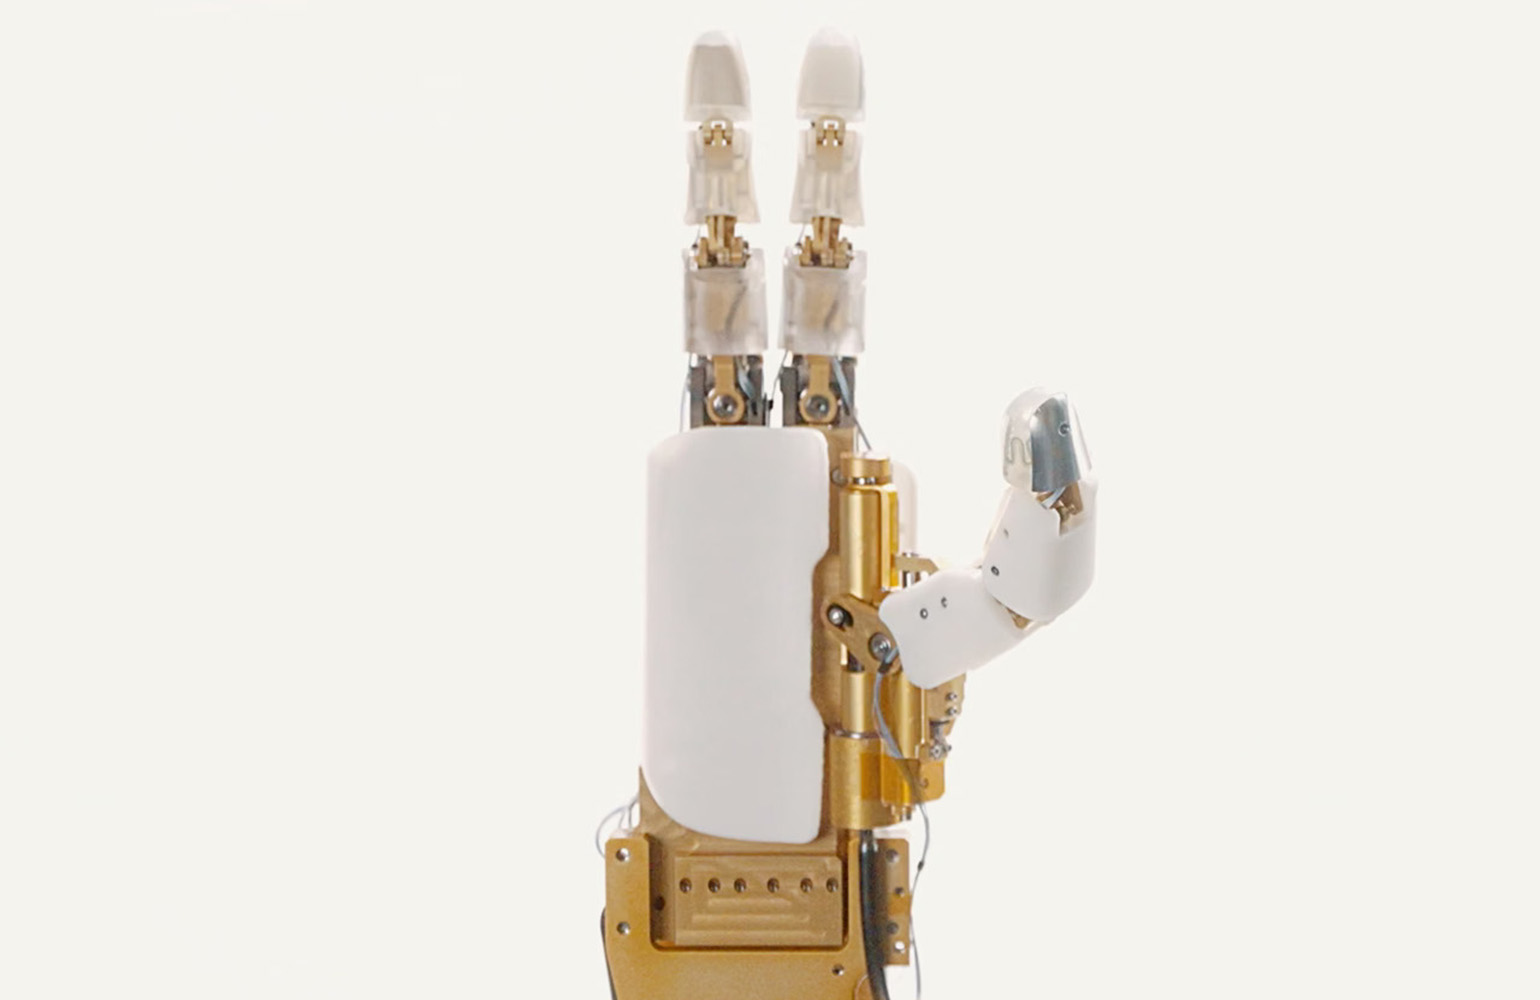
Tacta Systems takes aim at high-skilled manufacturing work with TactaBot
Tacta Systems unveiled a three-part system, including its robotic hand, that enables users to teach its robot new dexterous skills. The post Tacta Systems takes…
Building robots that survive the warehouse
Nomagic says its real moat is production data, because the messiness of real warehouses is where robots either prove themselves or fail. The post Building robot…
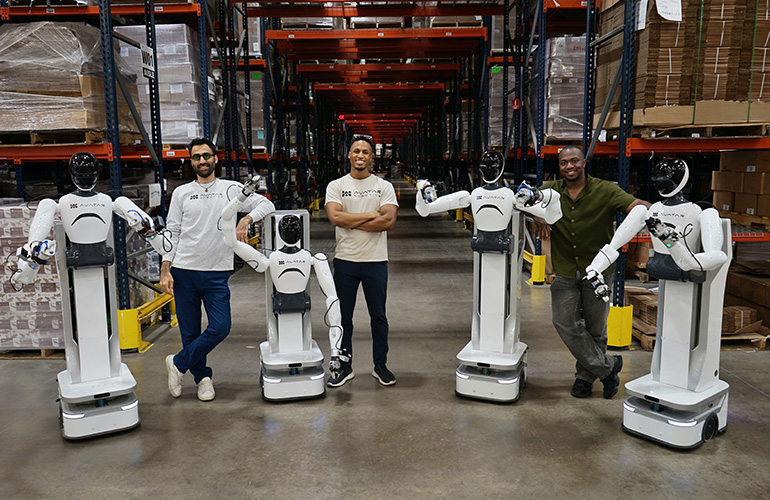
Avatar Robotics raises seed round to address industrial labor constraints
Avatar Robotics raised $6.5 million in funding to scale humanoid robots and remote teleoperation across industrial supply chains. The post Avatar Robotics raise…
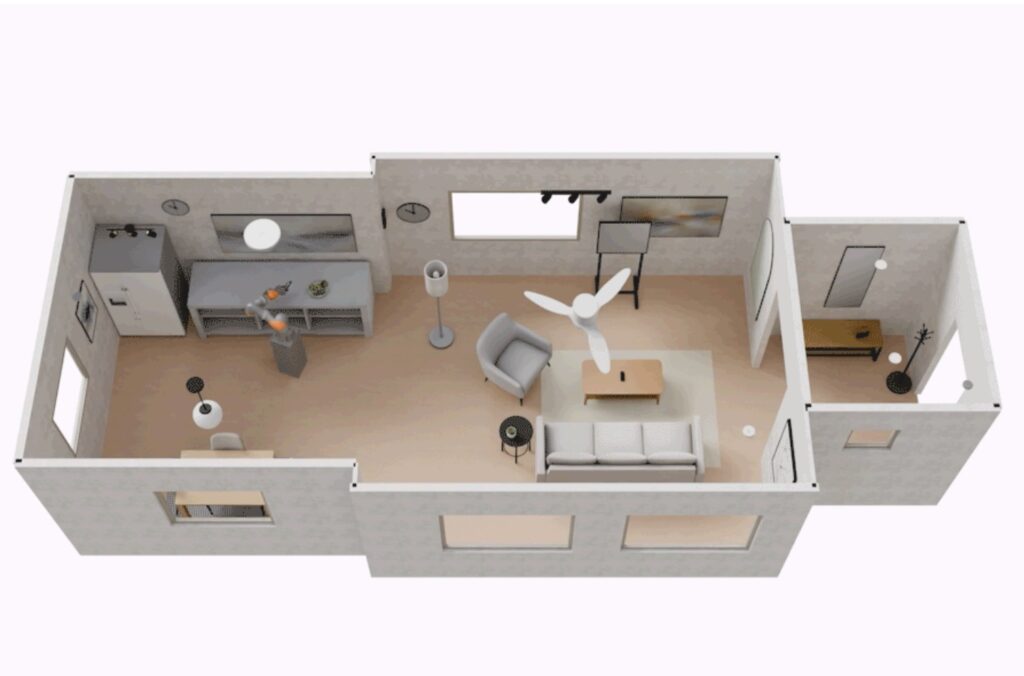
AI agents create virtual playgrounds to help robots get crucial training data
A new system developed at MIT uses three agents to piece together the objects, walls, and overall look of a 3D scene. Its realistic recreations of indoor spaces…