News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4147 storiesPreview-Based Relative-Motion Control of an Insertion Tool for Neural-Thread Placement in Pulsating Tissue
arXiv:2608.08860v1 Announce Type: cross Abstract: Robotic neural-thread placement requires regulating the insertion-tool tip relative to tissue that moves with …
Real-Time Nonlinear MPC via Sequential Quadratic Programming with Structure-Exploiting ADMM and Interior-Point Methods for Underactuated Double-Pendulum Swing-Up
arXiv:2608.09272v1 Announce Type: cross Abstract: The 4th "AI Olympics with RealAIGym" competition, to be held at IJCAI-ECAI 2026 in Bremen, challenges particip…
A Height-Constrained 2-Point Minimal Solver for Pose Estimation from Active LED Markers with Event Cameras
arXiv:2608.09520v1 Announce Type: cross Abstract: In many autonomous applications requiring real-time localization, active marker-based systems are preferred du…
A Semantic Communication Approach to Fiducial Marker Processing in 5G-Enabled Edge SLAM
arXiv:2608.09620v1 Announce Type: cross Abstract: Autonomous robots increasingly rely on edge computing to offload computationally intensive perception tasks wh…
REMAC: Self-Reflective and Self-Evolving Multi-Agent Collaboration for Long-Horizon Robot Manipulation
arXiv:2503.22122v2 Announce Type: replace Abstract: Vision-language models (VLMs) have demonstrated remarkable capabilities in robotic planning, particularly fo…
X2C: A Dataset Featuring Nuanced Facial Expressions for Realistic Humanoid Imitation
arXiv:2505.11146v3 Announce Type: replace Abstract: Fine-grained facial expression transfer from humans to humanoid agents presents a unique pattern recognition…
Calib3R: Hand-Eye Calibration and 3D Metric-Scaled Scene Reconstruction with 3D Foundation Models
arXiv:2509.08813v2 Announce Type: replace Abstract: Robots often rely on RGB images for tasks like manipulation. However, reliable interaction typically require…
CLEAR: A Semantic-Geometric Terrain Abstraction for Large-Scale Unstructured Environments
arXiv:2601.13361v2 Announce Type: replace Abstract: Long-horizon navigation in unstructured environments demands terrain abstractions that scale to tens of squa…
HyperDet: 3D Object Detection with Hyper 4D Radar Point Clouds
arXiv:2602.11554v4 Announce Type: replace Abstract: How far can 3D object detection go using 4D radar alone? Despite offering weather-robust and velocity-aware …
AnyCamVLA: Zero-Shot Camera Adaptation for Viewpoint Robust Vision-Language-Action Models
arXiv:2603.05868v2 Announce Type: replace Abstract: Despite remarkable progress in Vision-Language-Action models (VLAs) for robot manipulation, these large pre-…
Knowing When to Ask: Resolving Uncertainty in Human-Robot Joint Planning via Explicit Dialogue and Implicit Intent Cues
arXiv:2603.07822v2 Announce Type: replace Abstract: Effective human-robot collaboration in open-world environments requires joint planning under uncertainty abo…
Learning When to See and When to Feel: Adaptive Vision-Torque Fusion for Contact-Aware Manipulation
arXiv:2604.01414v2 Announce Type: replace Abstract: Vision-based policies have achieved a good performance in robotic manipulation due to the accessibility and …
Optimizing Trajectory-Trees in Belief Space: An Application from Model Predictive Control to Task and Motion Planning
arXiv:2605.01860v2 Announce Type: replace Abstract: This paper explores the benefits of computing arborescent trajectories (trajectory-trees) instead of commonl…
Anomaly-Informed Confidence Calibration for Vision-Based Safety Prediction
arXiv:2605.21109v2 Announce Type: replace Abstract: Reliable confidence estimates are important for safely deploying vision-based controllers in autonomous raci…
Global-Local Attention Decomposition for Terrain Encoding in Humanoid Perceptive Locomotion
arXiv:2606.00637v3 Announce Type: replace Abstract: Although reinforcement learning has significantly advanced humanoid locomotion, perceptive policies still st…
DiSCo: Diffusion Sequence Copilots for Shared Autonomy
arXiv:2603.22787v2 Announce Type: replace-cross Abstract: Shared autonomy combines human user and AI copilot actions to control complex systems such as robotic …
RynnValue: Scaling Robotic Value Foundation Models with Temporal Distance
arXiv:2608.09853v1 Announce Type: new Abstract: General-purpose reward models are increasingly the bottleneck for scaling robot learning, yet the recipe for lea…
GWM-VLA: Geometry-Aware Latent World Modeling for Vision-Language-Action Learning
arXiv:2608.07619v1 Announce Type: new Abstract: Vision-Language-Action (VLA) models achieve strong robotic manipulation performance but often degrade under visu…
Unsupervised Point Cloud Registration with Self-Distillation
arXiv:2409.07558v2 Announce Type: replace-cross Abstract: Rigid point cloud registration is a fundamental problem and highly relevant in robotics and autonomous…
Epically Powerful: An open-source software and mechatronics infrastructure for wearable robotic systems
arXiv:2511.05033v2 Announce Type: replace Abstract: Epically Powerful is an open-source robotics infrastructure that streamlines the underlying framework of wea…
DAP-Pose: Deep Temporal Alignment and Physics-aware Cross-modal Sensor Fusion for Robust Pose Estimation
arXiv:2607.23755v1 Announce Type: cross Abstract: Robust and accurate pose estimation with multi-modal sensors is fundamental for autonomous vehicles and mobile…
Entanglement-Free Trajectory Planning for Tethered Mobile Robots with a Slack Tether
arXiv:2608.09860v1 Announce Type: new Abstract: In motion planning algorithms for tethered mobile robots, the entanglement state of the tether is a critical asp…
Removing Infrastructure Barriers in Human-Robot Collaboration Through Wireless Reconfigurable Cells
arXiv:2608.09658v1 Announce Type: new Abstract: Human-Robot Collaboration (HRC) plays a vital role in dynamic, high mix, low volume industrial scenarios such as…
Anchor-Based AI Approach for Pre-Crash Object Detection Utilizing Micro-Doppler Signatures in Automotive Radar
arXiv:2608.08701v1 Announce Type: new Abstract: Advanced automated driving presents significant potential to improve modern automotive safety systems, but it de…
PhysX-CoT: Structured Physical Reasoning from a Single Image to Simulation-Ready 3D Assets
arXiv:2608.08053v1 Announce Type: new Abstract: Simulation-ready 3D assets are central to robotics and embodied AI. Generating them from a single image is usual…
Hadrian raises $1.37B to accelerate U.S. defense, aerospace manufacturing
The raise values Hadrian at $7.87 billion. It is Hadrian's second funding round this year, following a round in January 2026. The post Hadrian raises $1.37B to …
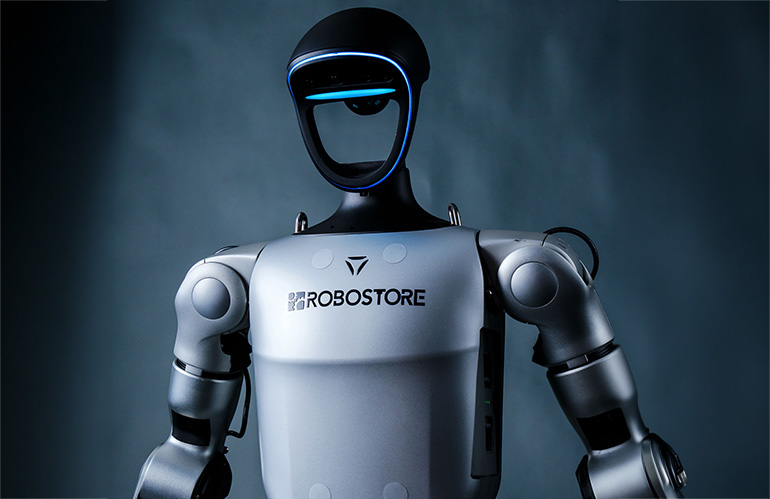
RoboStore launches Robo Inc. to help U.S. organizations deploy robots
RoboStore, a distributor of Unitree's legged robots, has launched Robo Inc. to serve as a U.S.-based manufacturer and integrator. The post RoboStore launches Ro…
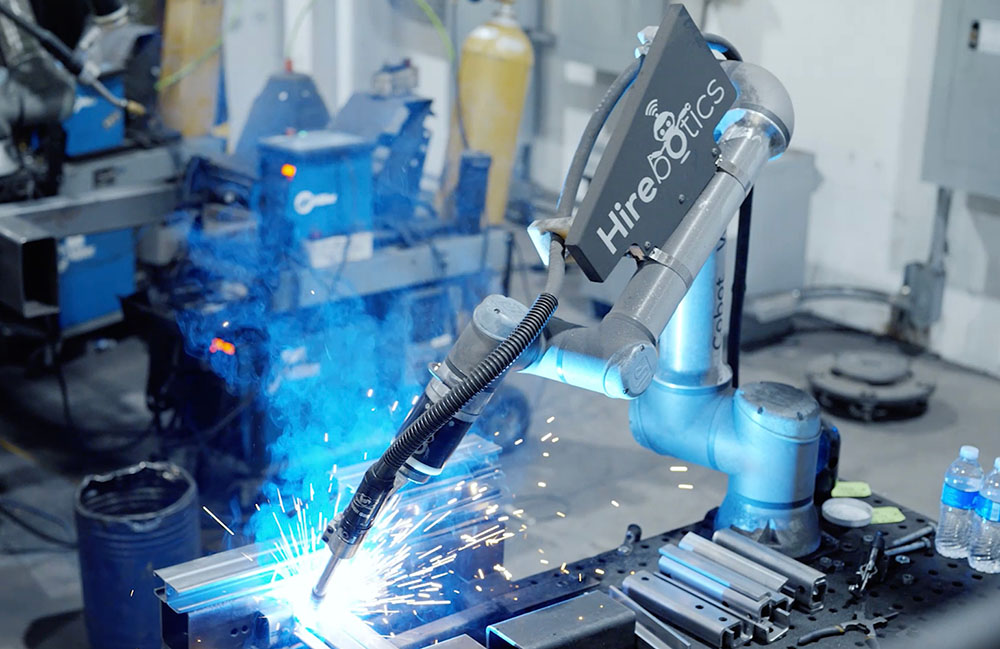
Tate deploys 58 Hirebotics cobot welders across multiple facilities
Tate decided to move from traditional hand welding to an agile, cloud-connected automation network powered by Hirebotics. The post Tate deploys 58 Hirebotics co…
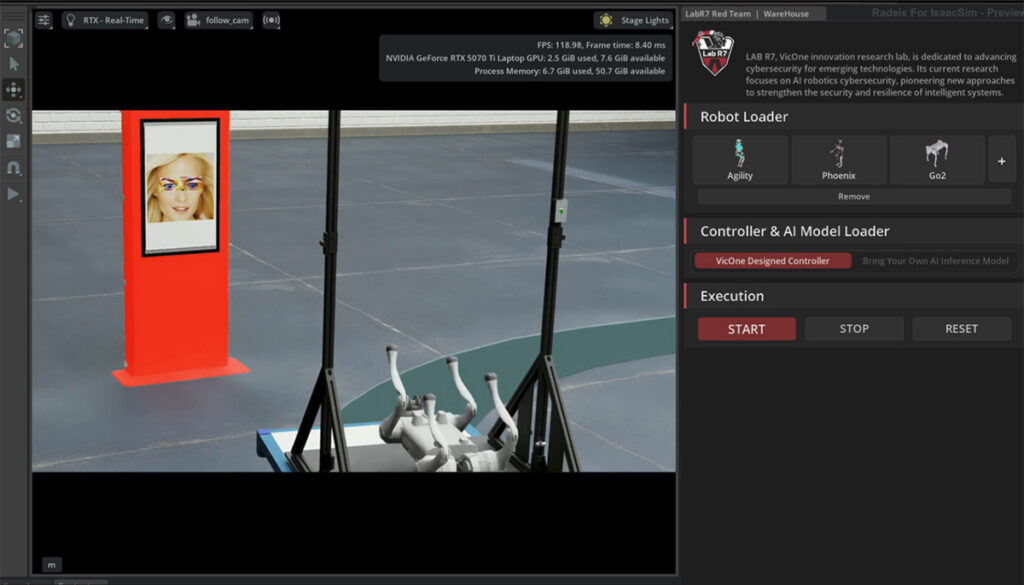
VicOne releases free NVIDIA Isaac Sim cybersecurity extension based on DEF CON 34 research
VicOne says its free Radeis Extension for NVIDIA Isaac Sim enables developers to test robot cyber safety before deployment. The post VicOne releases free NVIDIA…
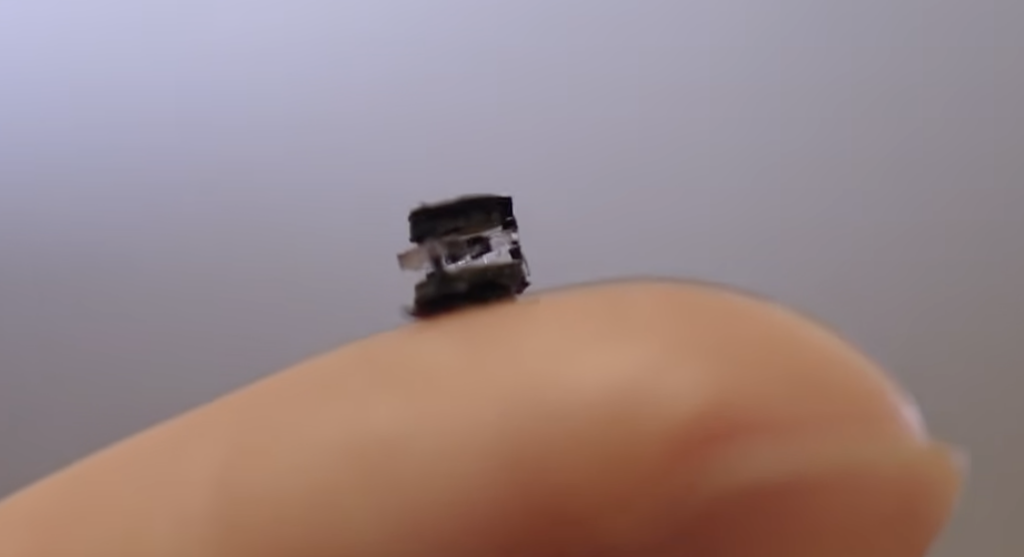
A ‘5-in-1’ seed-sized surgical robot
Scientists from Nanyang Technological University, Singapore (NTU Singapore) have developed a tiny seed-sized robot that can navigate across soft and uneven surf…