News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4147 storiesLook as You Leap: Planning Simultaneous Motion and Perception for High-DOF Robots
arXiv:2509.19610v3 Announce Type: replace Abstract: Most common tasks for robots in dynamic spaces require that the environment is regularly and actively percei…
Design and Evaluation of a Compliant Quasi Direct Drive End-effector for Safe Robotic Ultrasound Imaging
arXiv:2410.03086v2 Announce Type: replace Abstract: Robot-assisted ultrasound scanning promises to advance autonomous and accessible medical imaging. However, e…
GaussianWAM: Distilling Geometry and Semantics from 3D Gaussian Fields into World-Action Models
arXiv:2608.24714v1 Announce Type: new Abstract: World-Action Models (WAMs) jointly learn future visual prediction and action generation, using video dynamics as…
VIP: Variation-based Iterative-learning Planning for Robotic Navigation
arXiv:2608.24618v1 Announce Type: new Abstract: Over the past decade, autonomous robotic systems have been increasingly deployed in applications such as surveyi…
Gripper-aware Vision Language Action Models
arXiv:2608.24603v1 Announce Type: new Abstract: Vision language action models (VLAs) have advanced general purpose robotic grasping and manipulation by enabling…
TrAct: Bridging Robot Control and Visual Prediction with Visual Tracks
arXiv:2608.24101v1 Announce Type: new Abstract: Robot actions are inherently embodiment-specific and only weakly aligned with image-space visual changes, limiti…
Pattern-Derived Visual Swarm Games: Multi-Scale Drone-Vision States for Interception and Sustainability Audits
arXiv:2608.23575v1 Announce Type: new Abstract: We convert drone-vision annotation streams into virtual swarm-game states without controlling physical drones. V…
Robust Slip Detection and Material Classification via Spatiotemporal Transformers on a Uniformly-Illuminated Visuo-Tactile Sensor
arXiv:2608.24162v1 Announce Type: new Abstract: Tactile sensing is central to robotic manipulation, among which slip detection stands out as a quintessential an…
Dynamical System-Based Imitation Learning and Neuroadaptive Control for Trajectory Recovery in Autonomous Ships
arXiv:2608.23924v1 Announce Type: cross Abstract: Repetitive maritime operations can be effectively learned using the Imitation Learning (IL) paradigm, which tr…
A Durable Vision-Based Tactile Fingertip for Robotic Manipulation
arXiv:2608.24242v1 Announce Type: new Abstract: Currently available commercial vision-based tactile sensors provide rich contact information but remain vulnerab…
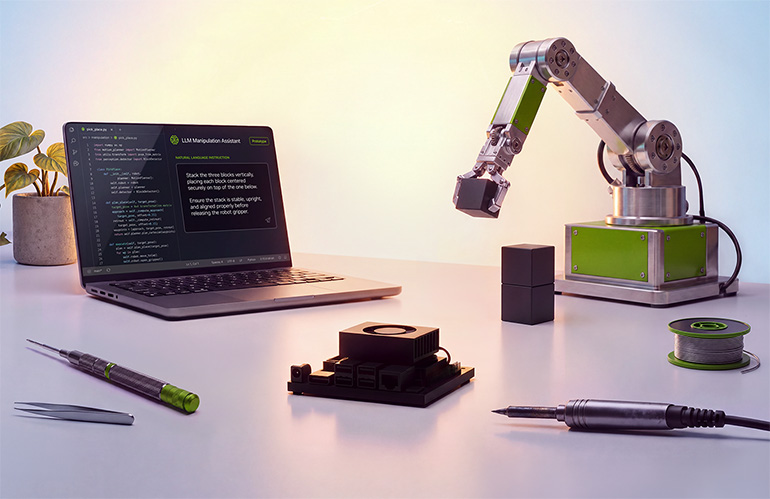
Jetson Orin Nano 2 doubles inference performance for robotics on the edge, says NVIDIA
With Jetson Orin Nano 2, NVIDIA says that frontier intelligence has reached the edge and can now run in real time. The post Jetson Orin Nano 2 doubles inference…
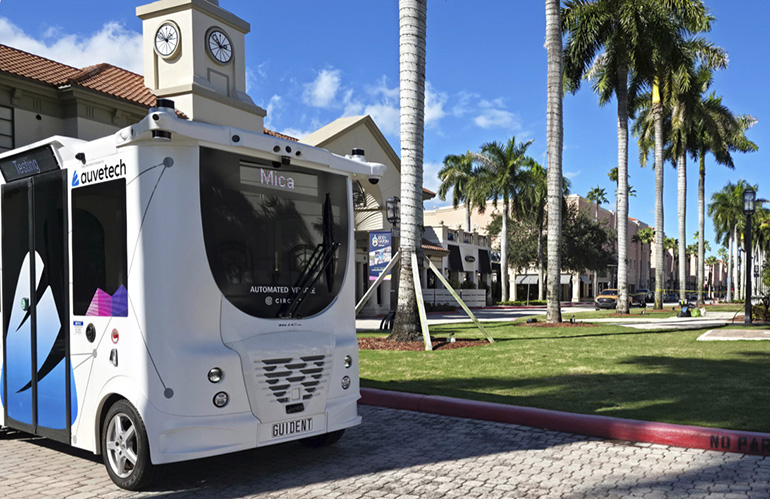
Humans in the loop are still needed for robotaxi fleet safety, says Guident
As fleets of autonomous vehicles scale, AI and human oversight remain critical for safety, explains Guident's CEO. The post Humans in the loop are still needed …
Early bird pricing for RoboBusiness 2026 ends August 31
Early bird pricing for RoboBusiness 2026, which saves attendees $200 on full conference passes, will end Aug. 31. The post Early bird pricing for RoboBusiness 2…
RoboShape: Information-Theoretic Point Cloud Representations for Privacy-Aware Robot Perception
arXiv:2608.21380v1 Announce Type: new Abstract: With the increased adoption of robotic agents operating in human environments by scanning and sharing 3D represe…
Multimodal-Language-Model-Driven Interaction and Companionship for Service Robots in Elderly-Care Facilities
arXiv:2608.21387v1 Announce Type: new Abstract: Service robots are increasingly deployed in elderly-care facilities to alleviate caregiver workload and enhance …
Gimbal-Based Human Tracking for Companion Robots Using Continual Learning
arXiv:2608.21388v1 Announce Type: new Abstract: Reliable and continuous human tracking is essential for natural human-robot interaction, particularly for compan…
On the Optimized Use of Non-Orthonormality Constraints for the Quasi-Static INS Alignment of Autonomous Underwater and Surface Vehicles
arXiv:2608.21390v1 Announce Type: new Abstract: Inertial navigation systems are specialized navigation apparatuses that equip almost all autonomous underwater a…
Selective Cross-View Consistency for World Action Models: Held-Out Viewpoint Robustness Without Test-Time Camera Information
arXiv:2608.21402v1 Announce Type: new Abstract: World action models (WAMs) jointly denoise future video frames and robot actions, and the video prior is expecte…
Mamba-based Selective State Space Modeling Improves the Accuracy-Complexity Tradeoff of SmolVLA Vision-Language-Action Experts
arXiv:2608.21407v1 Announce Type: new Abstract: Vision-language-action (VLA) models face a crucial tradeoff between their task success rate and the policy-call …
Social Graph Mamba: Forecasting Pedestrian Movements Based on Social Context
arXiv:2608.21411v1 Announce Type: new Abstract: Forecasting pedestrian motion has always been fundamental for autonomous navigation in crowded environments. Whi…
Operational digital twin clinics enable task-based evaluation of embodied AI
arXiv:2608.21416v1 Announce Type: new Abstract: Embodied artificial intelligence (AI) must be tested in the clinical environments where it will operate, but bui…
Evaluating Human and LLM-Generated Thematic Analysis in HRI for Vulnerable Populations: A Comparative and Ethical Analysis
arXiv:2608.21420v1 Announce Type: new Abstract: Thematic analysis (TA) has long been regarded as an inherently human, reflexive, and interpretive process. Howev…
Geo-VLA: Geometry-Aware Vision-Language-Action Planning via Internalization of Map Semantics
arXiv:2608.21440v1 Announce Type: new Abstract: Vision-language-action (VLA) models have advanced end-to-end autonomous driving by leveraging foundation models …
Constructing Predictive Surgical Path for AI-based Capsulorhexis Skill Transfer
arXiv:2608.21441v1 Announce Type: new Abstract: Automated training of surgeons is one of the most crucial factors that significantly minimize surgical training …
Model-Free Adaptive Parameter Tuning for Efficient Multi-Robot Warehouse Operations
arXiv:2608.21533v1 Announce Type: new Abstract: Robotic Fulfillment Centers (FCs) store inventory on shelves (pods) arranged in dense blocks. Retrieving a targe…
GOLEM: Modular Humanoid Autonomy Towards Electric Vehicle Battery Disassembly
arXiv:2608.21550v1 Announce Type: new Abstract: Disassembling end-of-life electric vehicle (EV) battery packs is dull and dangerous work, performed almost entir…
Model-Based Reinforcement Learning for Heterogeneous Multi-Robot Task Assignment Under Distribution Shifts
arXiv:2608.21554v1 Announce Type: new Abstract: Heterogeneous multi-robot service systems must assign requests to compatible robots, construct feasible schedule…
Force/Torque-Based Kinematic Adaptation for Robotic Manipulation Tasks
arXiv:2608.21592v1 Announce Type: new Abstract: Contact-rich robotic manipulation requires an accurate model of the kinematic relationship between a robot's joi…
Why Personalization Matters: Cross-Subject Challenges in EMG-IMU-based HRI Activity Recognition
arXiv:2608.21620v1 Announce Type: new Abstract: This paper investigates wearable-based recognition of human activities and gestures to support Human-Robot Inter…
OpenSCvx: An Open-Source Modular and Extensible Nonlinear Trajectory Planning Package
arXiv:2608.21631v1 Announce Type: new Abstract: Trajectory optimization computes dynamically feasible motions that enable autonomous systems to accomplish compl…