News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4147 storiesDevelopment of a Humanoid Robot Prototype for Multimodal Human-Robot Interaction
arXiv:2609.05361v1 Announce Type: new Abstract: Human-robot interaction (HRI) enables intuitive and intelligent collaboration between humans and robots in real-…
Adaptation Needs in Robotic Systems: Assessing Behavior Trees and Their Enhancement
arXiv:2609.05331v1 Announce Type: new Abstract: Robotic systems increasingly operate in dynamic, uncertain, and open-ended environments, where design-time assum…
Reasoning Without Inference Cost: Latent Semantic Scaffolding for Robot VLA Policies
arXiv:2609.04893v1 Announce Type: new Abstract: Vision-language-action (VLA) models are trained by imitation and capture what action to take but not why; adding…
CoLMIN: LLM-based Multi-Decision Path Negotiation for Cooperative Autonomous Driving
arXiv:2609.04807v1 Announce Type: new Abstract: Multi-vehicle cooperative autonomous driving enhances the safety and reliability of autonomous driving systems t…
FailureSpot: Label-Efficient Timestamp-Level Failure Detection for Vision-Language-Action Models
arXiv:2609.04277v1 Announce Type: new Abstract: Vision-language-action (VLA) policies have shown strong potential for general-purpose robotic manipulation, but …
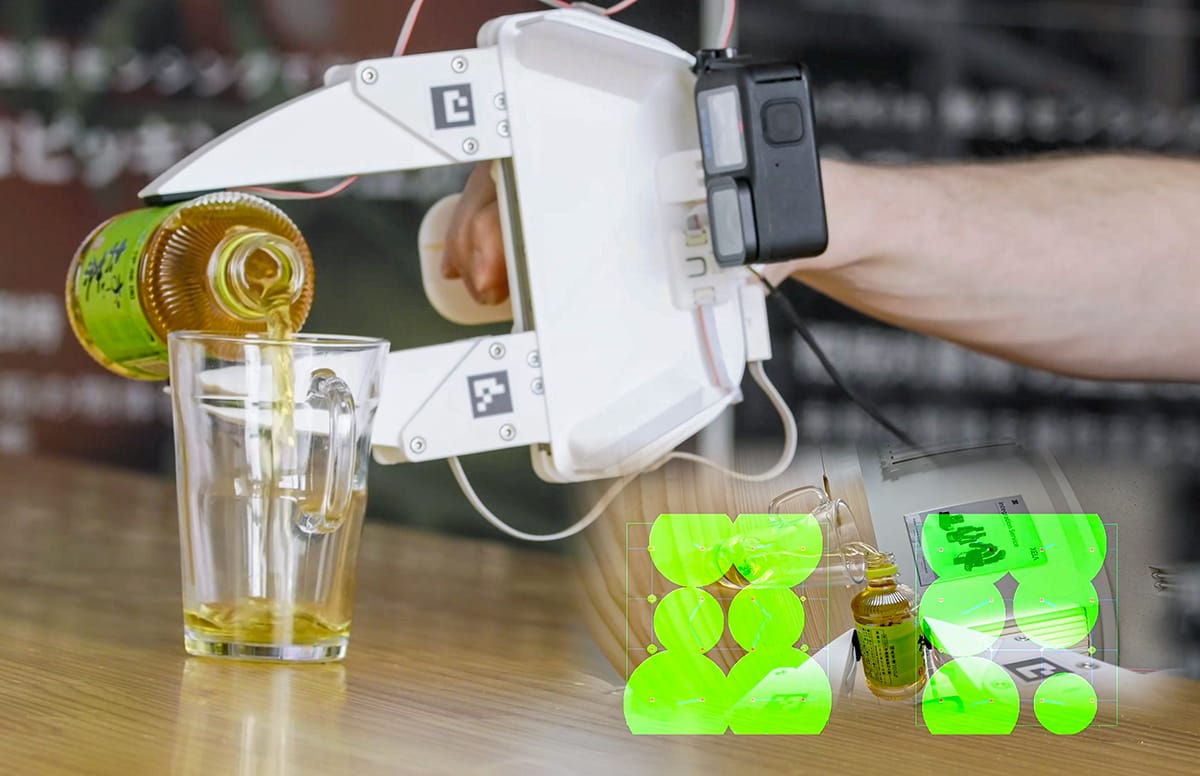
Pressure sensors can help improve robotic gripping accuracy
From first contact through surface deformation, load distribution, and final stable hold, pressure sensors can improve robotic bin picking. The post Pressure se…
Eric Sivertson discusses FPGAs and robot security
An interview with Eric Sivertson of Lattice Semiconductor about FPGAs and how they can improve robot safety and security. The post Eric Sivertson discusses FPGA…
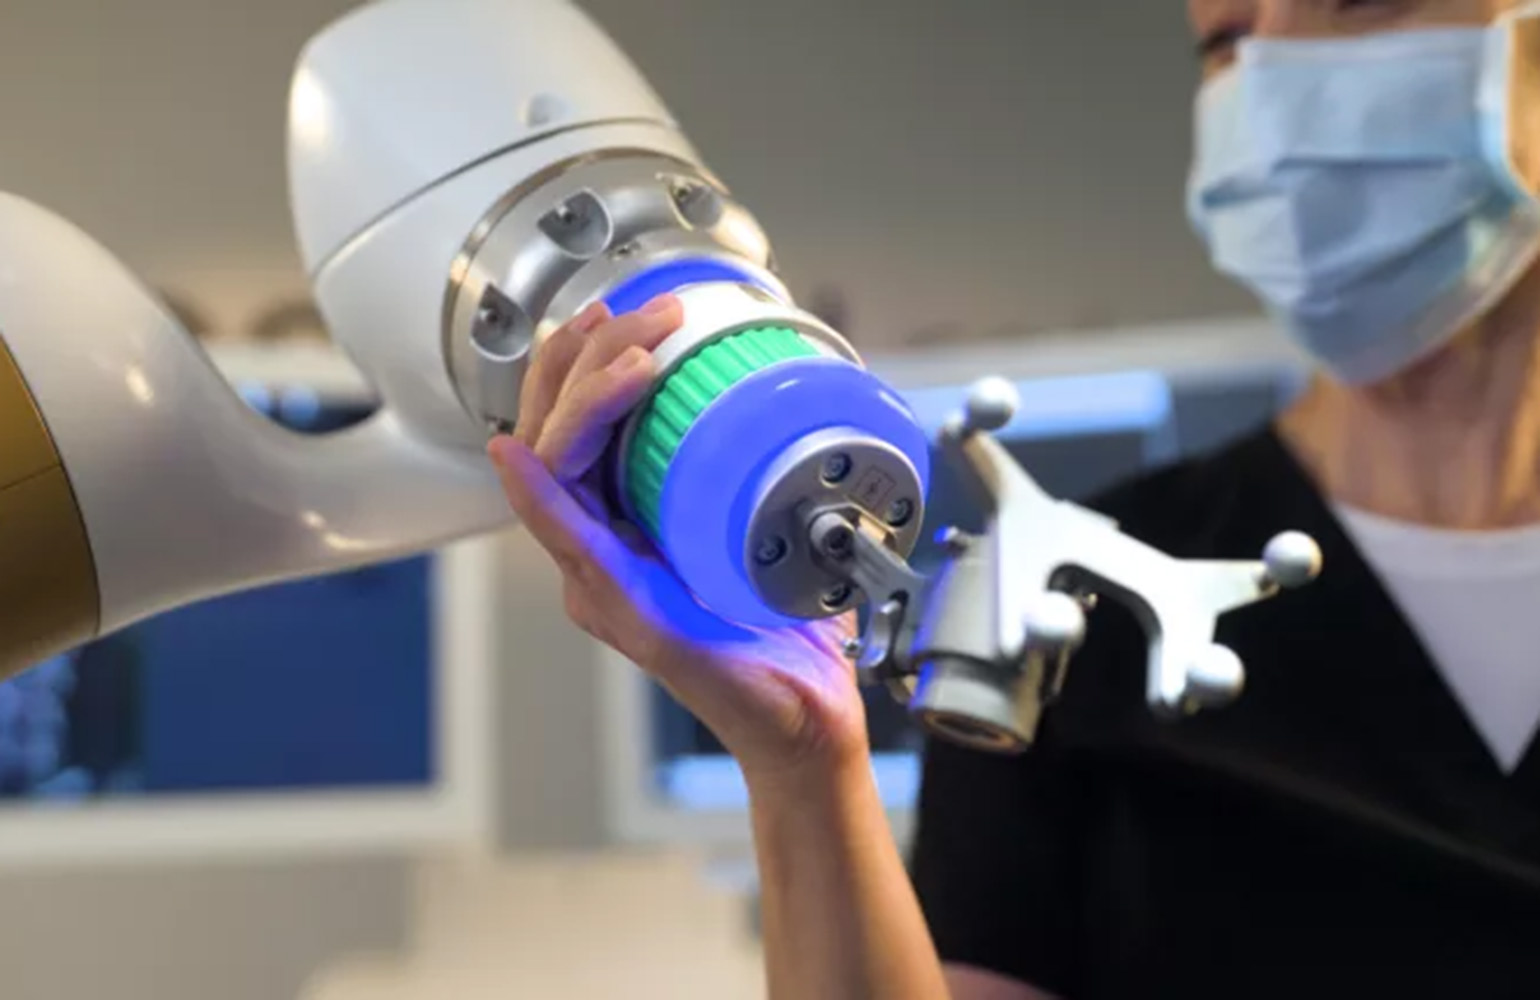
Enovis to acquire surgical tech provider eCential Robotics for $180M
Enovis said it plans to bring a robotic system targeting the knee within the next two years, followed by a system focusing on the shoulder. The post Enovis to a…
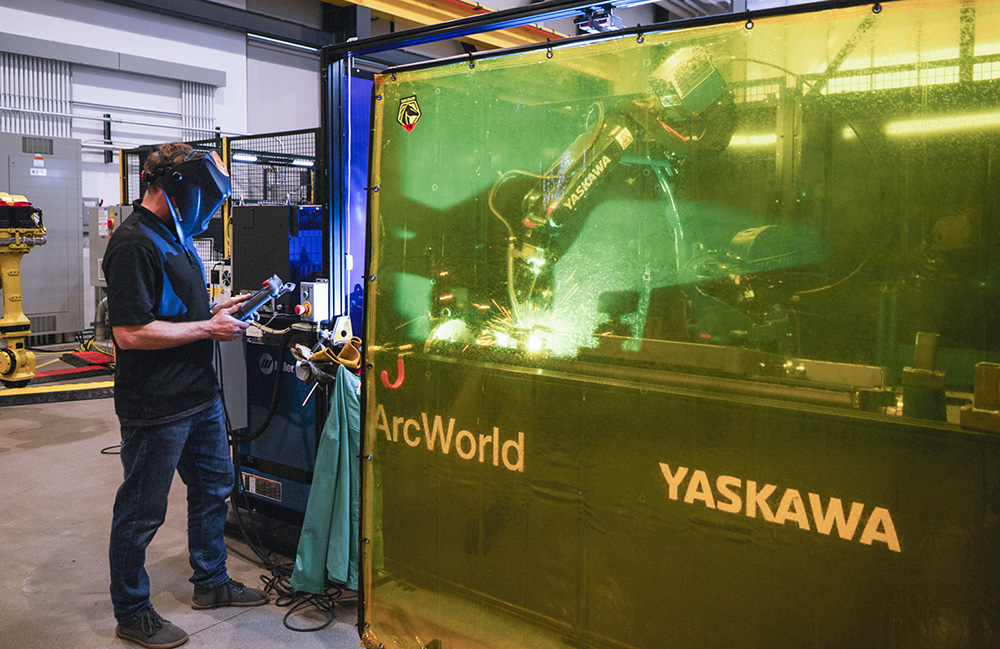
ARM Institute gets $90M for 10 projects to modernize military manufacturing
Fifteen member organizations will deliver viable working solutions within a two-year timeframe, the ARM Institute said. The post ARM Institute gets $90M for 10 …
Calling robotics startups: Apply now to be part of the 2026 Robotics Startup Radar
Submit now to be part of the Robotics Startup Radar, which brings together some of the most promising robotics startups. The post Calling robotics startups: App…
How FPGAs become the gatekeepers of physical AI security
Eric Sivertson, vice president of security business at Lattice Semiconductor, explains how FPGAs can act as deterministic guardrails for robotic systems. The po…
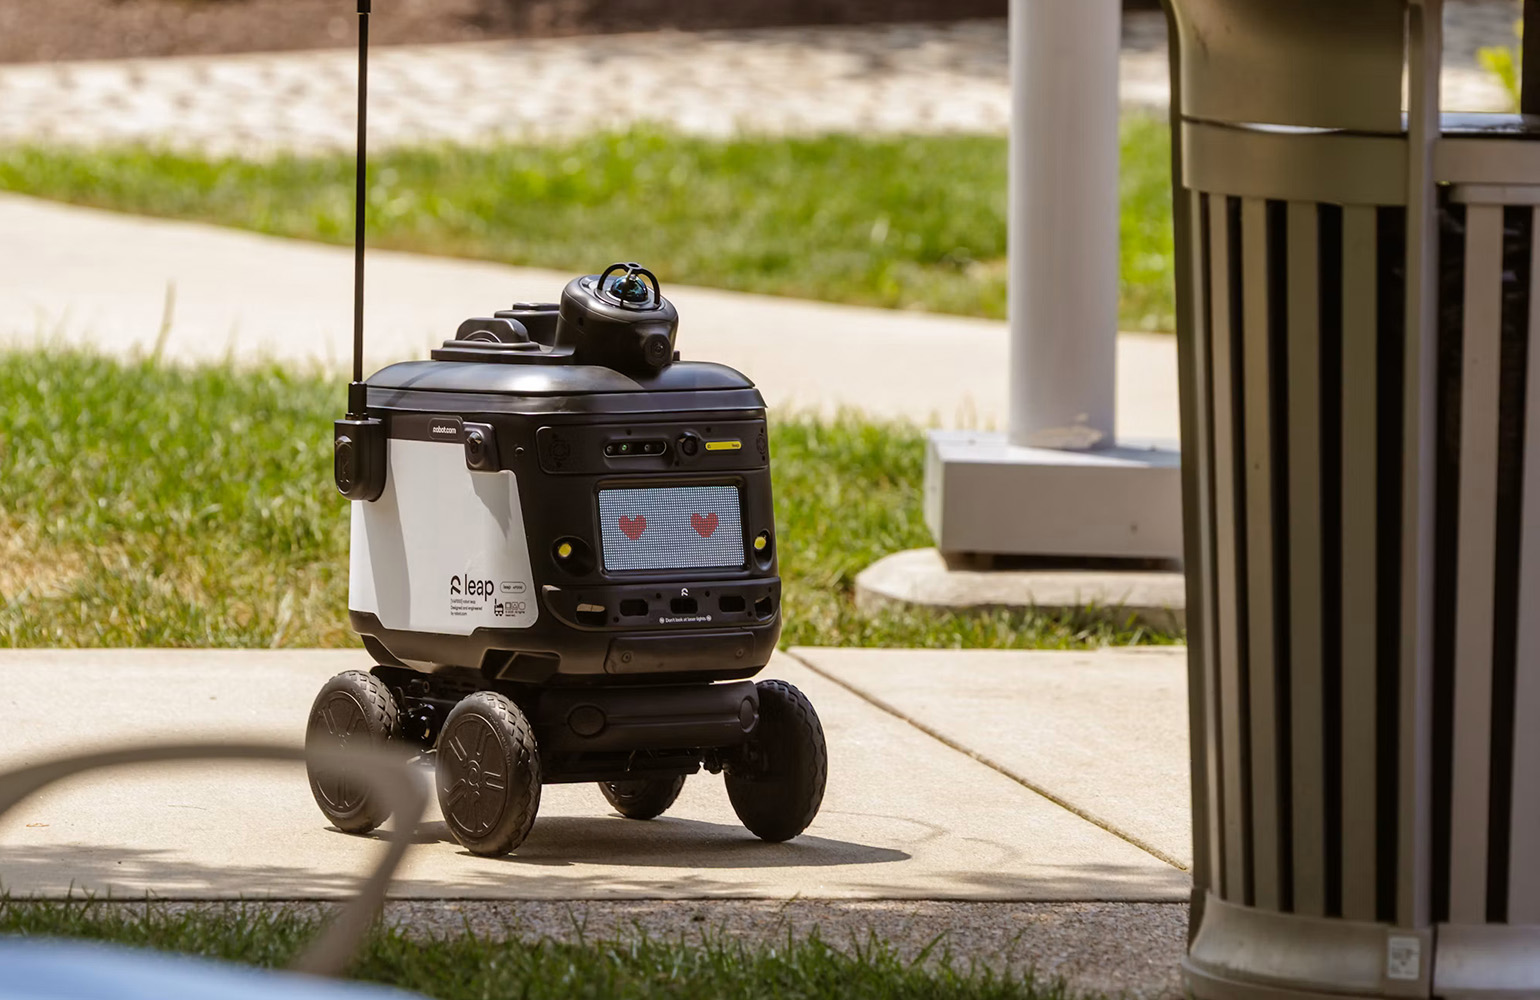
Robot.com partners with Sodexo to roll out more sidewalk delivery robots
Robot.com says college campuses will continue to be an important part of its strategy as it scales sidewalk delivery robots. The post Robot.com partners with So…
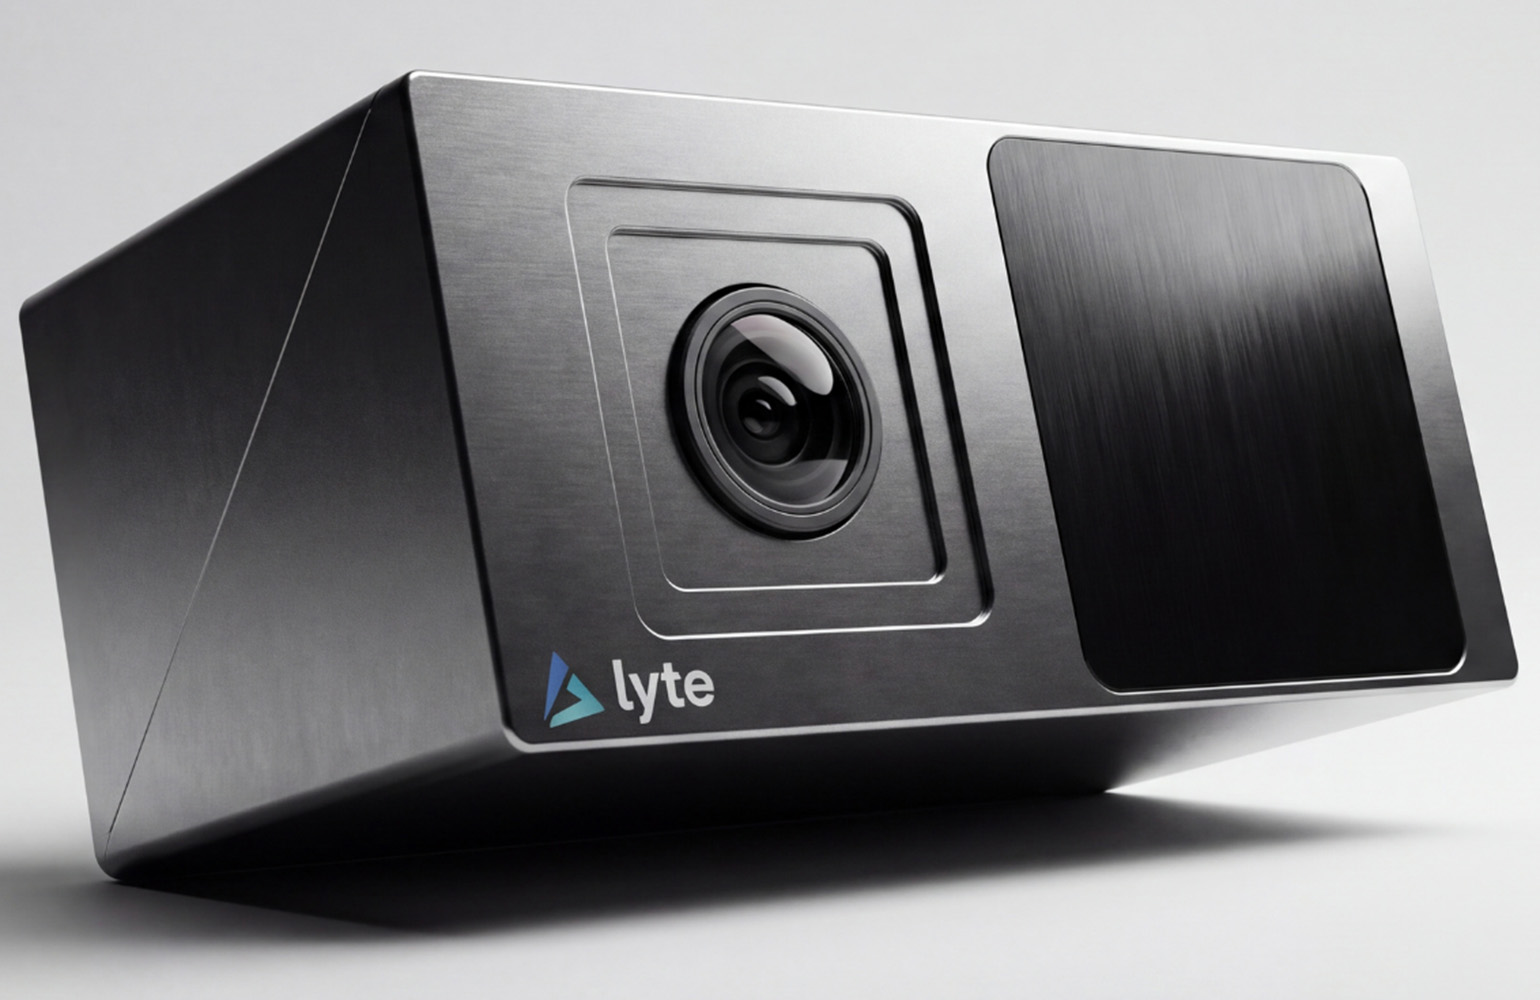
Lyte raises $165M to help robots better sense their surroundings
Lyte AI plans to use its second round of funding this year to scale production of its AI and perception capabilities. The post Lyte raises $165M to help robots …
Exploring the Moon will require rovers that can think for themselves – an upcoming NASA mission will test whether they can
By Wanjiku Chebet Kanjumba, University of Florida NASA is planning to send three small rovers to the Moon with a single instruction: Work out among yourselves h…
Programming and execution of skill-based human-robot-crane collaborative tasks
arXiv:2609.03392v1 Announce Type: new Abstract: Highly varying production sets increasing challenges for robotic manufacturing and indoor logistics. New capabil…
BRIDGE: An Open-Source Humanoid Platform via Morphology-Control Co-Design for Physical AI
arXiv:2609.03497v1 Announce Type: new Abstract: Developing humanoid robots capable of leveraging human behavioral data is essential for general-purpose embodime…
QLAUN: A Research-Oriented, Robust, Agile, Modular, and Affordable Torque-Controlled Quadruped Robot
arXiv:2609.03623v1 Announce Type: new Abstract: QLAUN Bot (Quad-Legged Adaptive Unmanned Navigator Robot) is a torque-controlled quadruped robot that is researc…
RoughSense: Lightweight Terrain-Induced Rover Vibration Prediction Using Point Clouds and IMU Feedback
arXiv:2609.03720v1 Announce Type: new Abstract: Autonomous navigation in space requires reliable terrain assessment for safe operations, especially in undergrou…
A comparative study on the accuracy & repeatability of mobile robotic platforms for the delivery of precision NDE measurement
arXiv:2609.03794v1 Announce Type: new Abstract: Mobile robotic platforms offer a flexible alternative to fixed manipulators for non-destructive evaluation (NDE)…
Corner Cases: Headland Coverage Path Planning for Autonomous Driving in Arable Farming
arXiv:2609.04103v1 Announce Type: new Abstract: This paper presents a new method for headland coverage path planning for arable fields. Several earlier approach…
Understanding Autonomous Driving Datasets by Describing Differences between Image Subsets in Natural Language
arXiv:2609.03677v1 Announce Type: cross Abstract: Understanding the composition of large-scale autonomous driving datasets is essential for safety, robustness, …
DropClick: Semi-Automated One-Click Segmentation for Agricultural Robotic Data
arXiv:2609.03680v1 Announce Type: cross Abstract: Labelling vision datasets, especially for segmentation tasks, is a laborious and costly process that stymies n…
A Low-Cost, Open Platform for End-to-End Autonomous Driving on a Miniature Ackermann Vehicle
arXiv:2609.04147v1 Announce Type: cross Abstract: This paper presents a low-cost, open experimental platform for research in end-to-end autonomous driving with …
Formation Matrix and Energy-based Control of Multi-Agent Systems
arXiv:2609.04158v1 Announce Type: cross Abstract: This paper presents an energy-based controller for a multiagent robotic system designed to achieve and maintai…
Decentralized Vision-Based Autonomous Aerial Wildlife Monitoring
arXiv:2508.15038v2 Announce Type: replace Abstract: Wildlife field operations demand efficient parallel deployment methods to identify and interact with specifi…
SPARC: Spine with Prismatic And Revolute Compliance for Faster Quadrupedal Bounding
arXiv:2510.01984v4 Announce Type: replace Abstract: Quadruped mammals coordinate sagittal spinal bending with axial extension and compression during dynamic loc…
Continuous Actions from Discrete Minds: Latent-Aligned Planning for End-to-End Autonomous Driving
arXiv:2609.04070v1 Announce Type: cross Abstract: Bridging the gap between the discrete reasoning of Vision-Language Models and the continuous, physics-constrai…
Adaptive Vision-Language Grasping via Composable Foundation Priors and Generalizable Grasp Synthesis
arXiv:2609.04096v1 Announce Type: new Abstract: This paper proposes AdaRoboVLG, a task-adaptive Vision-Language-Grasp (VLG) framework that supports generalizabl…
Toward Unified Robot Learning: Bridging Representation, Vision-Language-Action, and World Models
arXiv:2609.03927v1 Announce Type: new Abstract: For robots to operate reliably in real-world environments, they need to perceive their surroundings, act, and re…
A hybrid pipeline for dynamic ontology-based semantic mapping
arXiv:2609.03891v1 Announce Type: new Abstract: Semantic mapping plays a crucial role in the ability of a robot to interact with objects, operate and navigate a…