News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4147 storiesFWBC-VLA: Force-Aware Whole-Body Compensation for Contact-Rich Loco-Manipulation
arXiv:2609.03889v1 Announce Type: new Abstract: Contact-rich loco-manipulation requires a bridge between semantic action generation and physical interaction con…
A Multi-Vine Soft Robot Enabling Accessible Working Channel and Steering
arXiv:2609.03758v1 Announce Type: new Abstract: Soft eversion robots, also known as vine robots, have attracted growing interest for navigation and inspection t…
MINERVA: How Small Can a Manipulation Policy Be and Still Solve LIBERO?
arXiv:2609.03715v1 Announce Type: new Abstract: Vision-language-action (VLA) models with billions of parameters now dominate the LIBERO manipulation benchmark, …
Local Path Planning and Obstacle Avoidance for an Omnicopter Platform
arXiv:2609.03630v1 Announce Type: new Abstract: Autonomous unmanned aerial vehicles (UAVs) increasingly operate in cluttered environments where global planners …
Establishing a Dynamic Multimodal HRI Dataset for Engagement Analysis with a Humanoid Robot
arXiv:2609.03255v1 Announce Type: new Abstract: This paper presents an experimental design for constructing a multimodal dataset to analyze user engagement in h…
Long-Horizon Consistent and Interaction-Aware World Models for Multi-Style End-to-End Driving
arXiv:2609.03225v1 Announce Type: new Abstract: End-to-end autonomous driving has increasingly adopted world model-based reinforcement learning frameworks to im…
Sensing Which Modality Matters: Evidence-Gated Regularization for Robust VLA Policies
arXiv:2609.03142v1 Announce Type: new Abstract: Vision-Language-Action (VLA) policies fuse multimodal sensory inputs, but training on limited and homogeneous ro…
Real-Time Shape Control of Multi-Segment Soft Robotic Arms Using Koopman Operators with Global and Local Observables
arXiv:2609.03175v1 Announce Type: new Abstract: Multi-segment soft robotic arms can continuously reconfigure their body shapes for safe interaction, but tip con…
R2S-Eval: Robot Evaluation with Real-to-Sim Calibration via Vision-Language Models
arXiv:2609.03276v1 Announce Type: new Abstract: Evaluating robot manipulation policies is becoming increasingly important as generalist models, particularly vis…
GIFT: Guided Intermediate Feature Training via Action-Oriented Structural Supervision for Robotic Manipulation
arXiv:2609.04193v1 Announce Type: new Abstract: Vision-language pre-training and predictive world modeling provide robot policies with rich semantic and dynamic…
One Demonstration, Many Objects: Generalizing Manipulation via Local Contact Geometry
arXiv:2609.01938v2 Announce Type: replace Abstract: Dexterous manipulation with multi-fingered robot hands promises human-level dexterity, but collecting large-…
Highly Deformable Proprioceptive Membrane for Real-Time 3D Shape Reconstruction
arXiv:2601.13574v3 Announce Type: replace Abstract: Reconstructing the three-dimensional (3D) geometry of object surfaces is essential for robot perception, yet…
A Quantitative Comparison of Centralised and Distributed Reinforcement Learning-Based Control for Soft Robotic Arms
arXiv:2511.02192v3 Announce Type: replace Abstract: This paper presents a quantitative comparison between centralised and distributed multi-agent reinforcement …
LightEMMA: A Longitudinal Evaluation of Vision-Language Models for Autonomous Driving
arXiv:2505.00284v3 Announce Type: replace Abstract: Rapid advances in vision-language models (VLMs) have generated growing interest in their application to auto…
Dancing with REEM-C: A robot-to-human physical-social communication study
arXiv:2408.05301v3 Announce Type: replace Abstract: Humans often work closely together and relay a wealth of information through physical interaction. Robots, o…
RoboTok: An Internet-Scale Data Engine for Human Demonstration Retrieval and Dexterous Manipulation Learning
arXiv:2609.03199v1 Announce Type: cross Abstract: Robot learning increasingly depends on broad and diverse demonstrations, yet collecting robot data remains exp…
SV-WAM: An Efficient Surround-View World-Action Model for End-to-End Autonomous Driving
arXiv:2609.03602v1 Announce Type: cross Abstract: World models (WMs) have demonstrated strong potential for end-to-end autonomous driving by learning predictive…
MulDP: Multimodal Diffusion Policy for Autonomous Quadruped Parkour Navigation across Complex Terrains
arXiv:2609.03984v1 Announce Type: new Abstract: Quadruped robots have demonstrated impressive agility in parkour locomotion across complex terrains. However, mo…
Automated Weld Seam Recognition and 3D Mapping for Robotic Post Processing Using Photogrammetry and Semantic Segmentation
arXiv:2609.03970v1 Announce Type: new Abstract: Accurate identification of weld seam geometries is essential for automated robotic post processing operations su…
Robot Aware Computational Design of Object Specific Passive Grippers for Additive Manufacturing
arXiv:2609.03761v1 Announce Type: new Abstract: This paper presents an end-to-end computational pipeline that converts a selected object mesh, a measured object…
FailBench: How Reliable are VLMs at Judging Robot Task Success?
arXiv:2609.03611v1 Announce Type: new Abstract: Vision-Language Models (VLMs) are increasingly used to evaluate robot manipulation outcomes, but existing benchm…
Toward Physically Grounded JEPA World Models for Goal-Conditioned Robotic Planning
arXiv:2609.03565v1 Announce Type: new Abstract: Action-conditioned JEPA world models enable planning toward visually specified goals without reconstructing futu…
ARTiS: An Adaptive Robotic Gripper for Enhanced Tool Manipulation in Disassembly Applications
arXiv:2609.03362v1 Announce Type: new Abstract: Grasping and holding tools while using them presents a considerable challenge not only for robots but also for h…
Seeing Less Is Not Seeing Safely: Privacy Leakage from Task-Scoped Robot Perception Exports
arXiv:2609.03055v1 Announce Type: new Abstract: Domestic robots rely on rich perception to operate in private homes, but privacy risk persists even when raw sen…
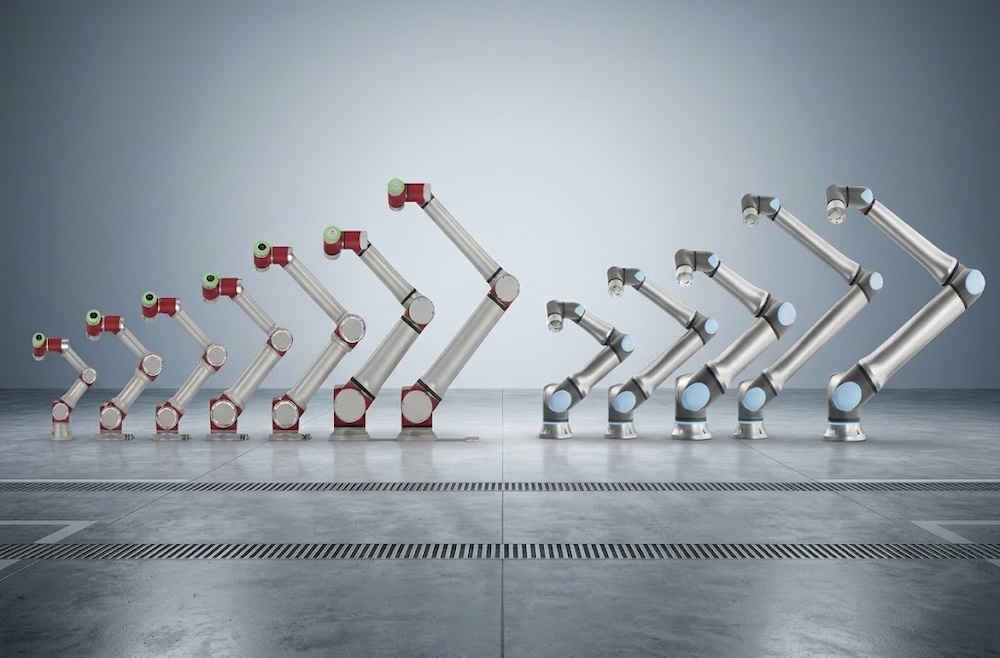
JAKA hits Teradyne Robotics back over patent dispute
JAKA is now taking legal action against Teradyne Robotics to end public dissemination of statements it considers "false, misleading and damaging." The post JAKA…
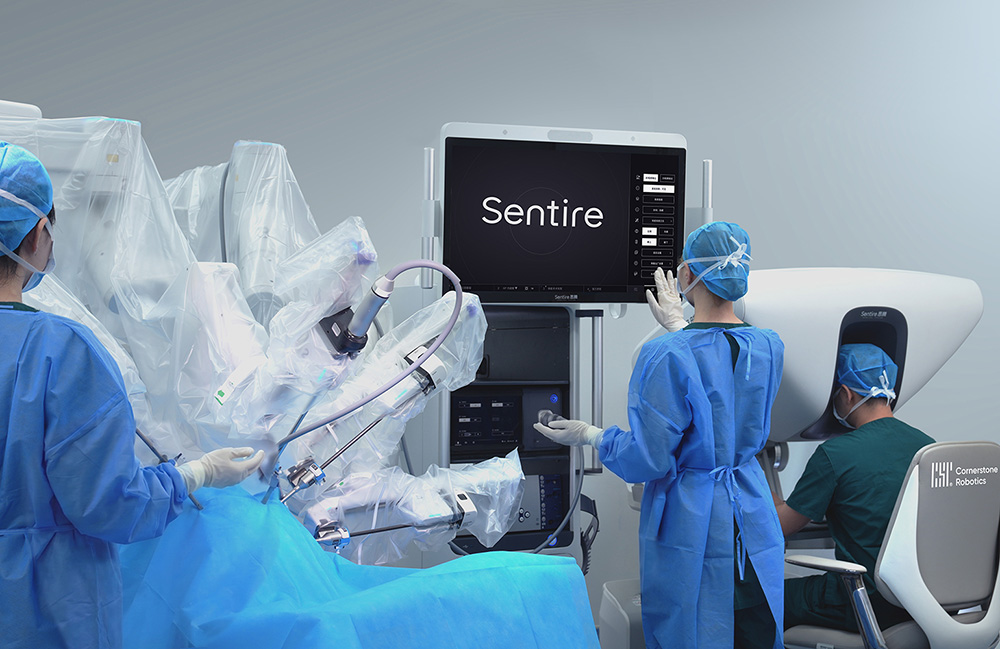
Medtronic invests $700M in surgical partner Cornerstone Robotics
Medtronic and Cornerstone Robotics are building a multi-port portfolio anchored by the Hugo surgical system and expanded by Sentire. The post Medtronic invests …
NVIDIA plans to acquire Hugging Face and keep AI development platform open
NVIDIA is already a major model contributor to Hugging Face, which recently surpassed 1 million datasets. The post NVIDIA plans to acquire Hugging Face and keep…
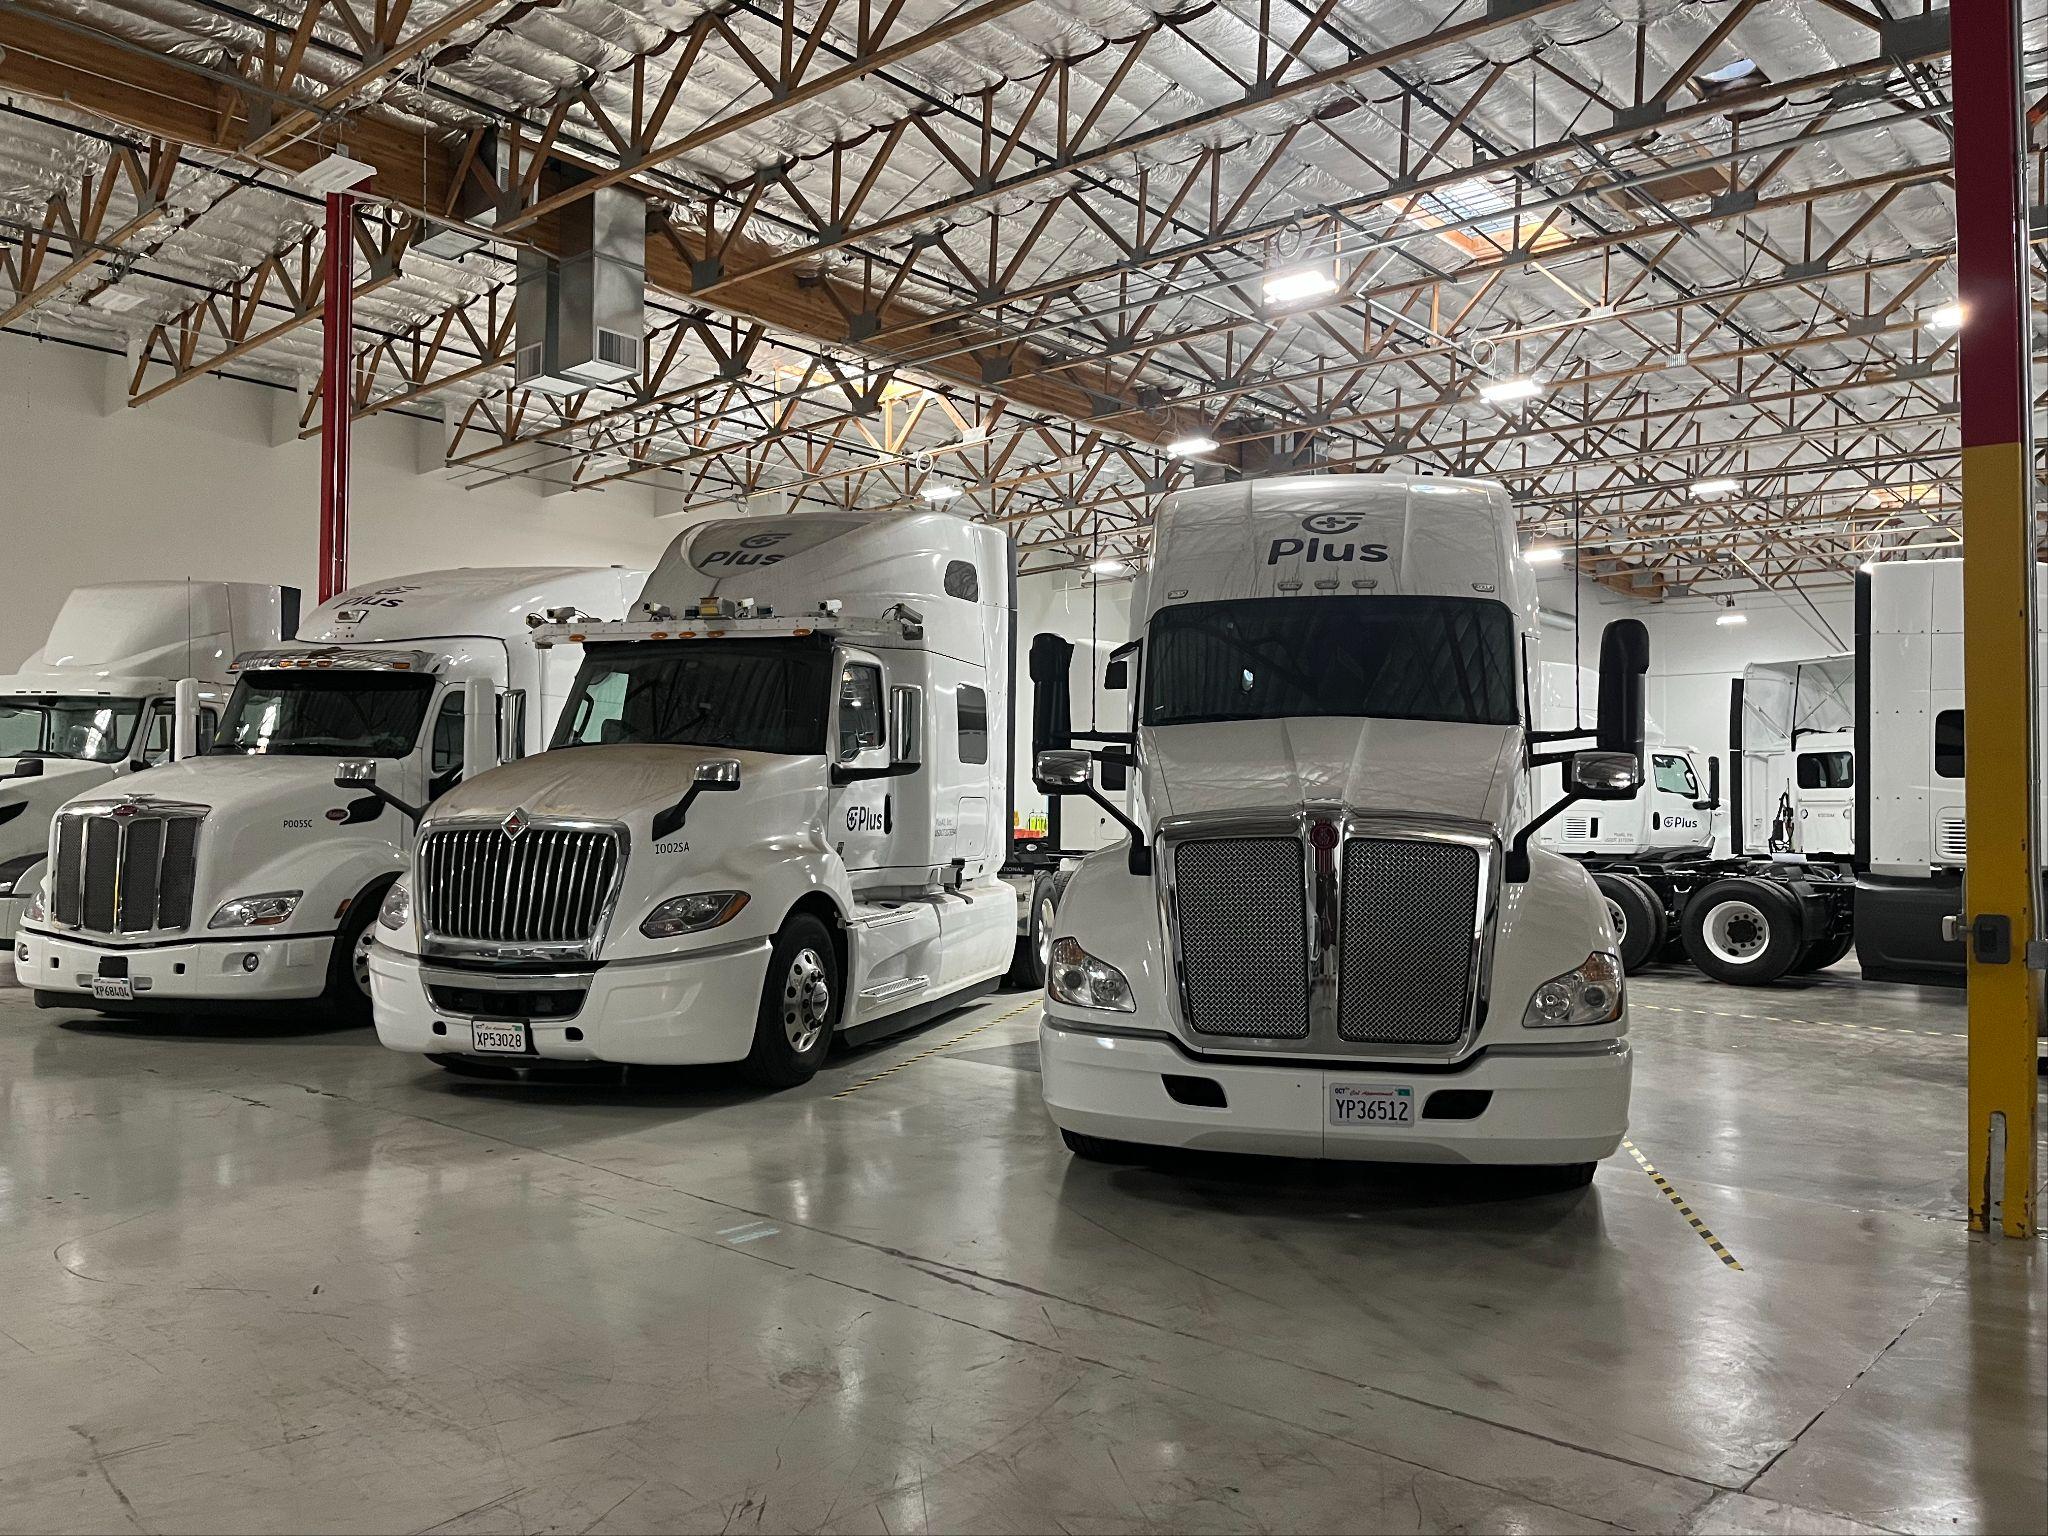
PlusAI to take autonomous trucking public via a SPAC deal
The SPAC transaction puts PlusAI, whose self-driving trucking software is already generating revenue, at about $800 million. The post PlusAI to take autonomous …
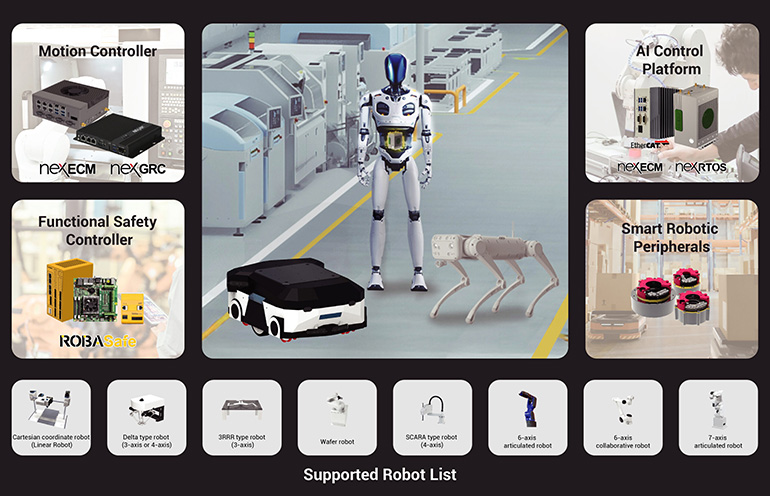
NexCOBOT discusses physical AI market hurdles and acceleration
NexCOBOT, which provides functional safety and motion controllers, discusses how physical AI benefits from 'Big Tech' and where it will grow. The post NexCOBOT …
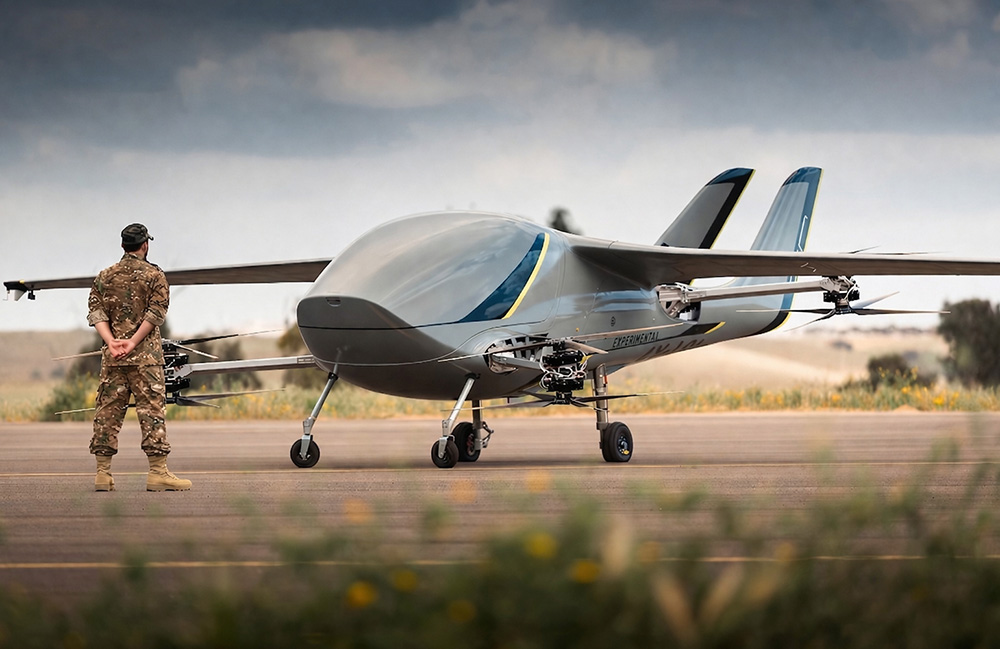
AIR to use Elmo Motion Control technology in uncrewed cargo aircraft
The partnership brings together Elmo's compact, high-power density servo drives and AIR's electric aviation design. The post AIR to use Elmo Motion Control tech…