News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4147 stories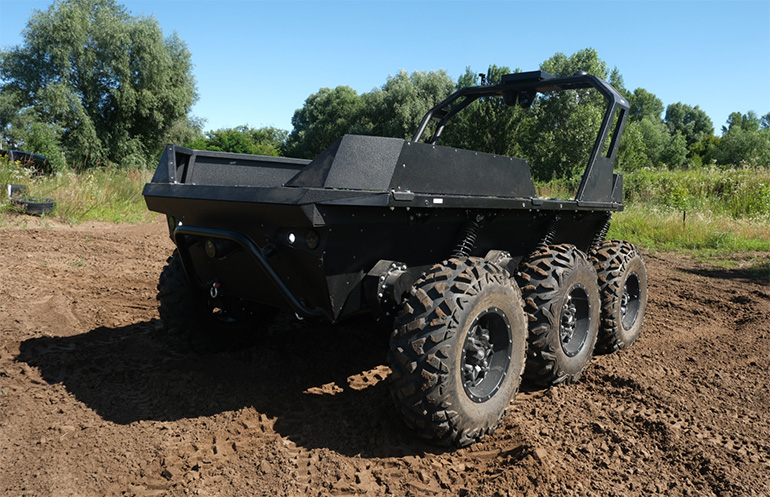
Swarmer to acquire Ukrainian UGV maker Ratel Robotics for up to $224M
Swarmer, which has developed swarm software, plans to work with Ratel Robotics' unmanned ground vehicles in Ukraine. The post Swarmer to acquire Ukrainian UGV m…
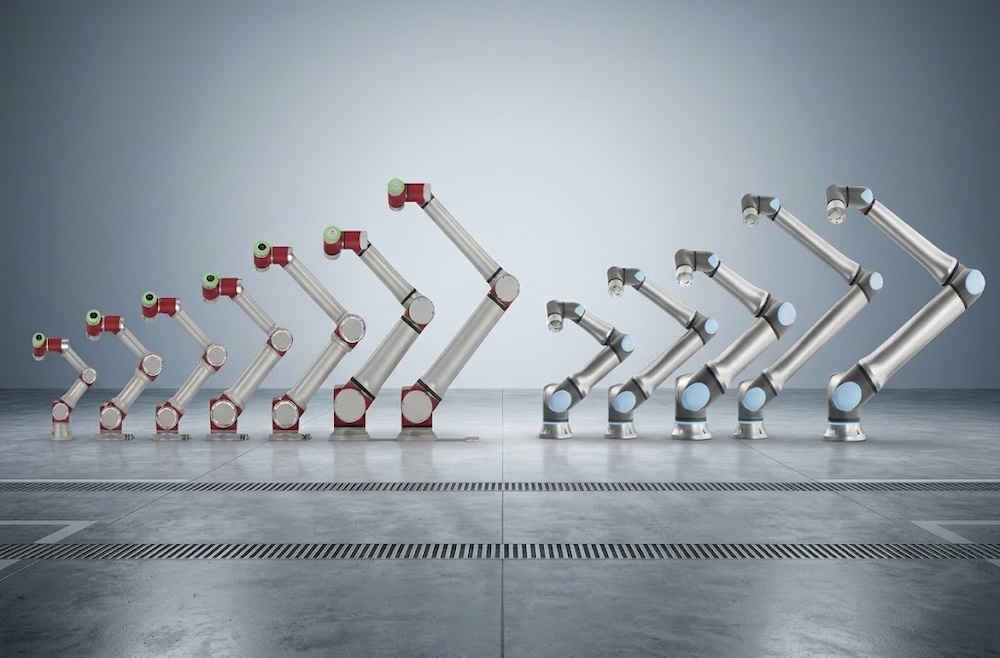
Teradyne Robotics sues JAKA over 3 Universal Robots patents
New details reveal the lawsuit involves three Universal Robots patents about robot interfaces, safety brakes, and joints. The post Teradyne Robotics sues JAKA o…
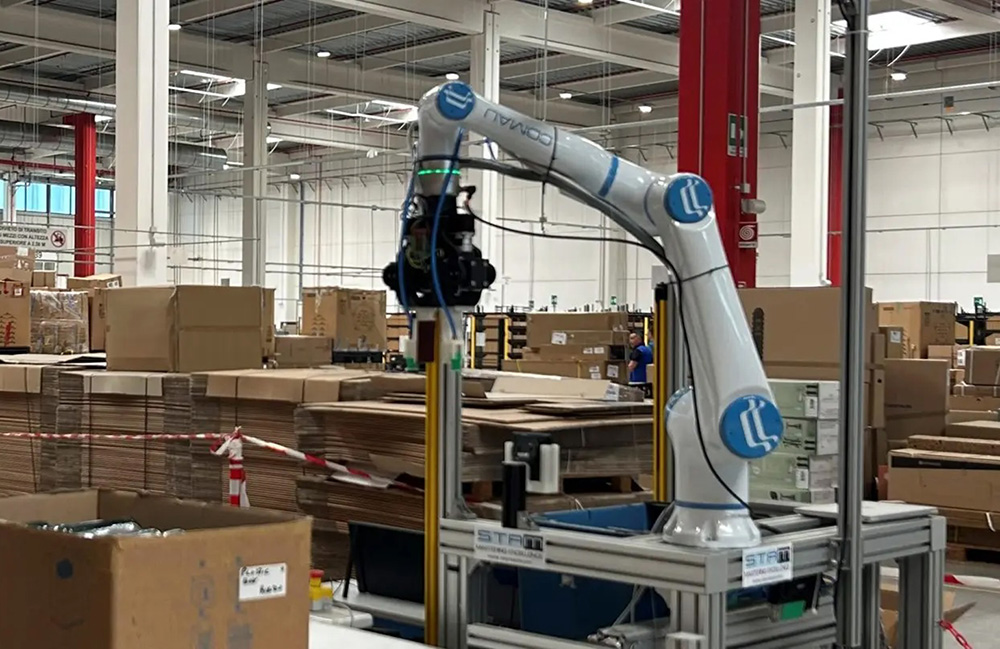
Comau automates picking, handling, and palletizing for Decathlon
Comau's system incorporates its MyCo cobot, ROS2 software architecture, AI-powered vision systems, and a modular gripper. The post Comau automates picking, hand…
No Free Checker: A Survey of Verifiers for Robot Policies
arXiv:2609.09250v1 Announce Type: new Abstract: A verifier for robot policies reads a candidate behavior and returns a score for how well it did, used both to e…
Design and Attitude Control of an Underwater Quadruped Robot
arXiv:2609.09217v1 Announce Type: new Abstract: Legged robots are versatile on land, but their use in underwater environments remains limited. Extending quadrup…
Coastal Environment Generation with HoloOcean
arXiv:2609.10484v1 Announce Type: new Abstract: Marine robotic simulation provides a safe and inexpensive method of developing and testing algorithms for unmann…
Compact Visuotactile World Models for Lifting: Prediction, Reward Alignment, and Force Constraints
arXiv:2609.09597v1 Announce Type: new Abstract: Accurate contact prediction is useful for robotic manipulation only if it supports effective decisions. We inves…
CT-SAFR: Safe and Interpretable Chain-of-Thought Reasoning for Autonomous Robots: A Multi-Layered Verification Framework for Trustworthy AI-Driven Robotic Decision Making
arXiv:2609.09692v1 Announce Type: new Abstract: Chain-of-Thought (CoT) prompting enables LLMs to perform explicit, step-by-step reasoning, creating opportunitie…
A Confidence-Aware Multimodal Fusion Framework for Industrial Human-Robot Collaboration
arXiv:2609.10339v1 Announce Type: new Abstract: A confidence-aware multimodal fusion framework (CAMF) is proposed to realize reliable human intention prediction…
AccelMPC: High-Rate, Low-Power FPGA-Accelerated Model Predictive Control for Tiny Drones
arXiv:2609.09380v1 Announce Type: new Abstract: Unlocking the potential of tiny aerial robots requires order of magnitude improvements in the performance of emb…
Show-Harness: Just a VLM Agent Can Play Robots
arXiv:2609.10522v1 Announce Type: new Abstract: Foundation vision-language models (VLMs) exhibit broad intelligence about the world, yet translating this intell…
DUET-DINO: Simultaneous Cross-View World Modeling for Latent Planning in Robot Manipulation
arXiv:2609.10506v1 Announce Type: new Abstract: Action-conditioned latent world models predict future visual representations, enabling zero-shot goal-conditione…
A Decade of Bayesian Optimization for Controller Tuning and Robot Learning: Tutorial, Review, and Future Prospects
arXiv:2609.09403v1 Announce Type: new Abstract: In the past decade, Bayesian optimization (BO) has emerged as a powerful and adaptable framework for automatic c…
Actuator Dynamics Curricula for Narrow-Viability Tasks in Legged Robot Learning
arXiv:2609.09492v1 Announce Type: new Abstract: Reinforcement learning has produced capable controllers across a broad range of legged-robot tasks, but a subset…
Tactile Memory with Soft Robot: Robust Object Insertion via Masked Encoding and Soft Wrist
arXiv:2601.19275v2 Announce Type: replace Abstract: Tactile memory, the ability to store and retrieve touch-based experience, is critical for contact-rich tasks…
Tracing Energy Flow: Learning Tactile-based Grasping Force Control to Reduce Slippage in Dynamic Object Interaction
arXiv:2512.21043v2 Announce Type: replace Abstract: Regulating grasping force to reduce slippage during dynamic object interaction remains a fundamental challen…
GTA-2: A Multi-VLM Framework for Synthesizing Robot Manipulation Skills via Grounded Task Axes
arXiv:2609.09808v1 Announce Type: new Abstract: Robotic manipulation tasks are often decomposed into behaviors or skills. However, one often needs to predefine …
Agentic AI-enabled Semantic Commissioning of a Cognitive Digital Twin for Reconfigurable Manufacturing
arXiv:2609.09503v1 Announce Type: new Abstract: Rapid bespoke commissioning of the Cognitive Digital Twin (CDT) is a major challenge in reconfigurable manufactu…
Kino-PAX$^+$: Near-Optimal Massively Parallel Kinodynamic Sampling-based Motion Planner
arXiv:2602.02846v2 Announce Type: replace Abstract: Sampling-based motion planners (SBMPs) are widely used for robot motion planning with complex kinodynamic co…
A Minimum-Energy Control Approach for Redundant Mobile Manipulators in Physical Human-Robot Interaction Applications
arXiv:2603.25259v2 Announce Type: replace Abstract: Research on mobile manipulation systems that physically interact with humans has expanded rapidly in recent …
Decision-Focused Active Learning for Scale-Aware Critical-Materials Recovery
arXiv:2609.09413v1 Announce Type: cross Abstract: Choosing a recovery process for scale-up requires connecting laboratory results with product requirements, pro…
Frequency-Conditioned Flow Matching for Vision-Language-Action Models
arXiv:2609.10405v1 Announce Type: new Abstract: Robot actions are temporally correlated trajectories whose frequency components encode motion at different scale…
Data-Driven Risk Fields for Safer End-to-End Autonomous Driving
arXiv:2609.10377v1 Announce Type: new Abstract: Safety is a fundamental requirement for autonomous driving, yet existing end-to-end driving models still lack ex…
Identifying Habit, Physics, and Nuisance in Robot World Models
arXiv:2609.09210v1 Announce Type: new Abstract: Teleoperated demonstrations are often multimodal even when the underlying dynamics are nearly deterministic give…
AXON: A ROS 2 RMW with Shared-Memory/QUIC Transport and QKD/ML-KEM Key Establishment
arXiv:2609.10024v1 Announce Type: new Abstract: Robot Operating System 2 (ROS 2) standardizes application code against a middleware interface (RMW) whose refere…
Learning Terrain-Adaptive Humanoid Locomotion on Granular Terrain
arXiv:2609.10286v1 Announce Type: new Abstract: Humanoid locomotion on granular terrain remains a significant challenge due to its complex foot-terrain interact…
Multi-Agent Reinforcement Learning for Autonomous UAV Exploration in Wildfire Response
arXiv:2609.10433v1 Announce Type: new Abstract: This study develops a deep reinforcement learning framework for training Unmanned Aerial Vehicle (UAV) agents to…
Proxy Policy Steering
arXiv:2609.09148v2 Announce Type: replace Abstract: Generalist robot policies carry broad manipulation priors from large-scale data, but specializing them to a …
Monkey See, Can Monkey Do? A Benchmark for Evaluating Robot Skill Learning by Observation
arXiv:2609.08209v2 Announce Type: replace Abstract: Learning from Observation (LfO) is a fundamental robotic capability that replicates how humans and animals s…
Dex-X: Learning Visual-Tactile Dexterous Manipulation From Human Videos with Simulated Interaction
arXiv:2609.07747v2 Announce Type: replace Abstract: Human videos are an abundant source of dexterous manipulation behaviors, but they lack tactile information t…