News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4147 storiesPelican-Sim 1.0: A General World Model Simulator for Embodied Intelligence
arXiv:2609.12036v1 Announce Type: new Abstract: In this technical report, we propose Pelican-Sim 1.0, a general world model simulator for embodied intelligence …
A Physics-Based Closed-Loop Robotic Bioprinting Framework Towards Volumetric Muscle Loss Treatment
arXiv:2609.12159v1 Announce Type: new Abstract: Robotic bioprinting and Direct Ink Writing (DIW) are being explored towards the treatment of Volumetric Muscle L…
Pneumatic neurons for soft robots enable inflate-and-fire networks for rhythmic motion
arXiv:2609.12258v1 Announce Type: new Abstract: Animals coordinate their movements through distributed neural circuits, but soft robots still typically depend o…
Breaking the Vision-Action Shortcut: Latent Interface Training for Generalizable Robotics Foundation Models
arXiv:2609.12641v1 Announce Type: new Abstract: Robot foundation models achieve strong in-distribution performance but often degrade under visual distribution s…
Driving Context-guided Model Predictive Planning and Control for Autonomous Car Racing at the Limit and Beyond
arXiv:2609.12660v1 Announce Type: new Abstract: This paper presents a Model Predictive Control-based motion planning and control pipeline for autonomous car rac…
ARC: Autonomous Robotics Compliance A Three-Layer Governance Architecture for Deployed Autonomous Systems
arXiv:2609.12932v1 Announce Type: new Abstract: Proposed governance framework for autonomous robotic systems, introducing a three-layer compliance architecture …
DropVLA: An Action-Level Backdoor Attack on Vision-Language-Action Models
arXiv:2510.10932v5 Announce Type: replace-cross Abstract: Vision-Language-Action (VLA) models map multimodal perception and language instructions to executable …
RoboDreamer: Anticipatory Humanoid Locomotion with Predictive State-Space Models
arXiv:2609.07096v2 Announce Type: replace Abstract: Humanoid locomotion requires control policies that remain stable under imperfect sensing while exploiting te…
SkillX: Unified Multi-Skill Policy Learning for Humanoid Soccer
arXiv:2609.06718v2 Announce Type: replace Abstract: Humanoid soccer is a challenging testbed for dynamic whole-body control, requiring robots to coordinate bala…
Decentralized Evolution of Hexapod Gaits with Independent Leg Controllers
arXiv:2609.12400v1 Announce Type: cross Abstract: This paper presents a novel approach to hexapod locomotion by evolving each leg's gait independently through a…
Dynin-Robotics: Omnimodal Unified Diffusion Vision-Language-Action Model
arXiv:2609.13053v1 Announce Type: new Abstract: Visual goal and dynamics prediction can provide language-conditioned robot policies with both a target outcome a…
Tuning ROS 2 for Energy-Efficient Navigation: Empirical Insights from Costmap 2D Configurations
arXiv:2609.12971v1 Announce Type: new Abstract: Robots are increasingly used in diverse application areas, where autonomous navigation plays a central role. As …
A Robot Among People:From Social Imitation to the Social Becoming of Human Groups
arXiv:2609.12937v1 Announce Type: new Abstract: Robots designed to mediate human groups often fall into the solutionist trap: they are framed as sociable agents…
Parameter Sensitivity Analysis for Aerial LiDAR-Inertial Odometries in low-altitude flights
arXiv:2609.12837v1 Announce Type: new Abstract: LiDAR-based SLAM (Simultaneous Localization and Mapping) and LIO (LiDAR-inertial odometry) algorithms are often …
VertexCBF: Improving Neural Control Barrier Functions via Vertex-Restricted Control Search
arXiv:2609.12831v1 Announce Type: new Abstract: As the number of autonomous robots continues to grow, safety becomes increasingly important. Control barrier fun…
ProClosure: Hierarchical Room-Object Assignment using Progressive Boundary Closure from Monocular Video
arXiv:2609.12614v1 Announce Type: new Abstract: A 3D scene graph groups objects into rooms. When a robot is asked to fetch an object from the kitchen, that grou…
PATH: Continuous Target Sensing among Autonomous Cooperative Drones
arXiv:2609.12456v1 Announce Type: new Abstract: Continuous target sensing by uncrewed aerial vehicles (UAVs) is constrained by limited flight endurance, motivat…
FoldNet++: a Large-Scale Synthetic Dataset for Robotic T-Shirt Folding and Unfolding
arXiv:2609.12433v1 Announce Type: new Abstract: Due to the highly deformable nature of garments, training a generalizable policy for robotic T-shirt folding and…
Ultrasound offers a scalable path to tactile intelligence for physical AI
Ultrasound sensing can provide tactile perception for robotic hands while avoiding wear and tear, says UltraSense. The post Ultrasound offers a scalable path to…
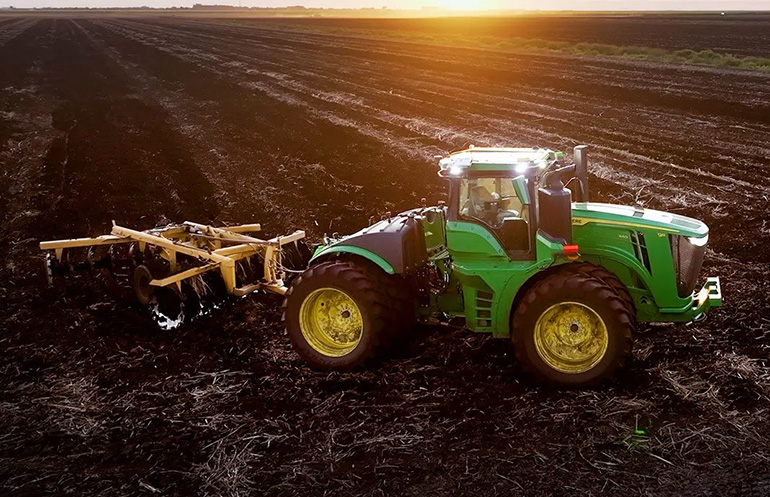
How autonomous fleets are changing what’s possible in American agriculture
Autonomous tractors can help American agriculture, as exemplified in ASI's collaboration with U.S. Sugar and Everglades Equipment. The post How autonomous fleet…

Learn how AVs and robotics are laying the groundwork for field deployments at RoboBusiness
ASI CEO Mel Torrie will explore why the intersection of autonomous vehicles and robotics will further revolutionize field deployments. The post Learn how AVs an…

One brick at a time: How Monumental uses robotics to build walls
CEO Salar al Khafaji introduces podcast listeners to how Monumental is using robotics to build walls. The post One brick at a time: How Monumental uses robotics…

How drone developers are navigating changing regulatory landscapes to help farmers
Before the FCC put restrictions on foreign-made robots, it had already set similar restrictions on drones last year, noted Hylio. The post How drone developers …

Building and programming autonomous robots at the York Micromaze Hackathon
From 25–27 August, UK RAS STEPS members came together at the University of York’s Institute for Safe Autonomy for a three-day Micromaze Robot Hackathon. Working…

How to select the right rack and pinion system for high-precision linear motion
Sponsored by GAM. Picture a scissor car jack — the one in your trunk for changing a tire. The spinning motion as you turn the crank translates to the linear mot…
HuRo: Robotizing Human Videos for Scalable VLA Pretraining
arXiv:2609.10706v1 Announce Type: new Abstract: Human video datasets have emerged as a compelling alternative to expensive real-robot data, offering rich divers…
Beyond Noise Steering: Dual-Latent Space Reinforcement Learning for Generative Robot Policy
arXiv:2609.11270v1 Announce Type: new Abstract: Pretrained generative robot policies learn expressive action priors from demonstrations. However, existing reinf…
2AM: Grounding Agent-Side Memory as Guidance for Steerable Action Models in Long-Horizon Manipulation
arXiv:2609.11308v1 Announce Type: new Abstract: Long-horizon robot manipulation requires memory, but not necessarily inside the action policy. To address such t…
Morphology-Aware Human Motion Retargeting for Wheeled-Humanoid Loco-Manipulation
arXiv:2609.11357v1 Announce Type: new Abstract: Human-to-humanoid retargeting has largely been studied on legged platforms, while comparatively few wheeled-huma…
FARM: Reading Failure Signals from the Internal Predictive States of a Frozen Robotic World Model
arXiv:2609.11445v1 Announce Type: new Abstract: Reliable robot deployment requires online failure monitoring, yet existing monitors mainly derive risk from prox…