News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4147 stories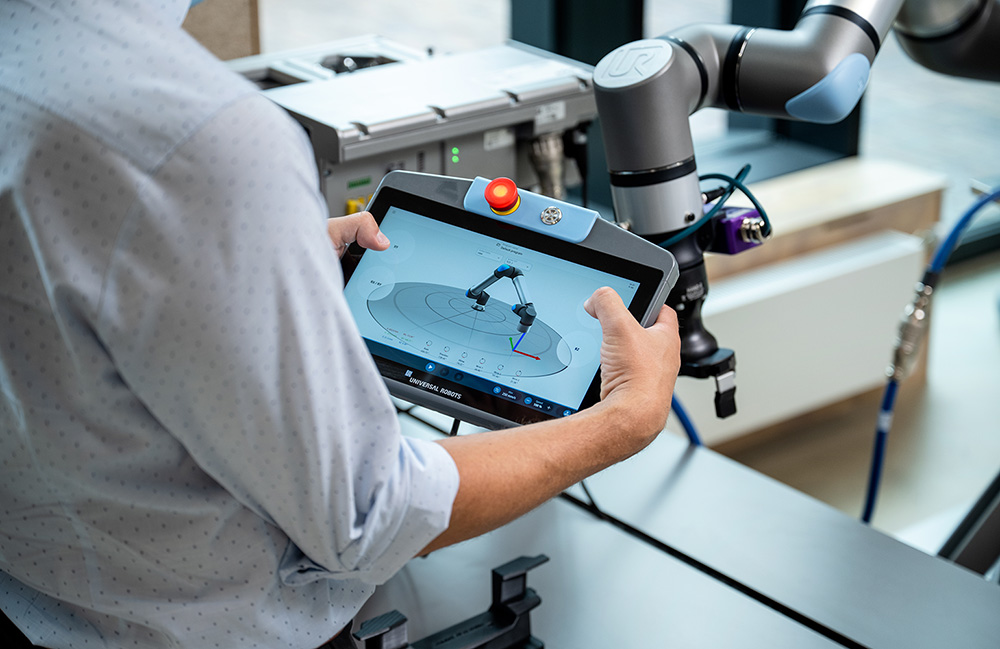
Universal Robots launches its seventh generation robot platform at IMTS
Universal Robots has released three new robot arms, a rebuilt core controller, a new AI-ready tool flange, and more. The post Universal Robots launches its seve…
DIA: Denoising Intermediate Advantage for Diffusion Policy Optimization
arXiv:2609.12245v1 Announce Type: new Abstract: Diffusion-based robot policies have become widely used in robotic manipulation, where they are typically trained…
Mission Performance: Automatic and Adaptive Race Pace Progression for Autonomous Racing
arXiv:2609.12292v1 Announce Type: new Abstract: In this paper, we describe the Mission Performance module implemented for a fully autonomous racing car to autom…
DWMP: Leveraging Dual World Models for Humanoid Obstacle Traversal
arXiv:2609.12347v1 Announce Type: new Abstract: Humanoid robots must traverse cluttered obstacle fields using onboard proprioceptive and visual observations, ye…
A Deployable Architecture for Robot-Mediated Tasks (DART): Evaluation in Socially Assistive Robot-Guided Cognitive Behavioral Therapy Exercises
arXiv:2609.12349v1 Announce Type: new Abstract: Socially assistive robots (SARs) can support structured health and well-being interventions, but hardware and co…
READ: Learning Risk-Informed Fields for End-to-End Autonomous Driving
arXiv:2609.12371v1 Announce Type: new Abstract: Autonomous driving requires more than recognizing what is present in a scene: a planner must determine how road …
Understanding Whole-Body Robot Teleoperation Strategies Under Diverse Task Objectives and Constraints
arXiv:2609.12384v1 Announce Type: new Abstract: This work investigates the control strategies of complex whole-body robot teleoperation that coordinate active p…
Communication-Constrained Multi-Robot Exploration With Adaptive Communication Windows
arXiv:2609.12502v1 Announce Type: new Abstract: Exploring unknown environments with multi-robot teams can improve efficiency by allowing robots to explore in pa…
Autonomous Precision Milling of Biological Structures via Generic Anatomical Priors and Active Boundary Perception
arXiv:2609.12530v1 Announce Type: new Abstract: Autonomous precision milling of biological structures is challenged by incomplete knowledge of target geometry, …
Quantifying Spectral Differences in Vehicle Between Production Autonomous and Human-Driven Vehicles Across Driving Scenarios
arXiv:2609.12609v1 Announce Type: new Abstract: Differences in vehicle kinematic characteristics between production autonomous vehicles (PAVs) and human-driven …
Size Doesn't Matter: Material-State Reinforcement Learning for Excavator Transferable Soil Manipulation
arXiv:2609.12677v1 Announce Type: new Abstract: Earthmoving tasks such as excavation, backfilling, or embankment construction require deliberate repositioning o…
High-Fidelity Multi-Body Simulator for Autonomous Racing
arXiv:2609.12795v1 Announce Type: new Abstract: We present a custom high-fidelity vehicle dynamics simulation environment for testing and validation of Autonomo…
A Multi-Vehicle Dataset with Camera, LiDAR, and Radar Sensors and Scanned 3D Models for Custom Auto-Annotation using RTK-GNSS
arXiv:2609.12871v1 Announce Type: new Abstract: Datasets are a crucial element in the development of perception algorithms. They relate sensor measurement data …
Before the Tipping Point: Force-Guided Active Perception for Shape-Agnostic Estimation of 3D Centers of Mass
arXiv:2609.12894v1 Announce Type: new Abstract: Estimating the 3D center of mass of unknown objects is challenging when grasping is infeasible, geometry is irre…
ASTRIL-MPC: Autonomous Traversal Framework of Articulated Tracked Robots with Language-Guided Neural-Kinematic MPC
arXiv:2609.13083v1 Announce Type: new Abstract: In urban search and rescue, articulated tracked robots (ATRs) must traverse structured but contact-rich environm…
Efficient Vision-Language-Action Management and Serving for Robot Factories
arXiv:2609.12075v1 Announce Type: cross Abstract: Vision-Language-Action (VLA) models show high robotic manipulation capabilities via a two-stage design: a Visi…
UniPart: Towards Zero-shot Language-Grounded 3D Part Segmentation for Embodied Interaction
arXiv:2609.12898v1 Announce Type: cross Abstract: Fine-grained robotic manipulation depends on understanding parts, not only whole objects. Existing 3D foundati…
RoMu4o: A Robotic Manipulation Unit For Orchard Operations Automating Proximal Hyperspectral Leaf Sensing
arXiv:2501.10621v3 Announce Type: replace Abstract: Driven by the need to address labor shortages and meet the demands of a rapidly growing population, robotic …
FLOAT Drone: A Fully-actuated Coaxial Aerial Robot for Close-Proximity Operations
arXiv:2503.00785v2 Announce Type: replace Abstract: How to endow aerial robots with the ability to operate in close proximity remains an open problem. The core …
Adversarial Game-Theoretic Algorithm for Dexterous Grasp Synthesis
arXiv:2511.05809v2 Announce Type: replace Abstract: For many complex tasks, multi-finger robot hands are poised to revolutionize how we interact with the world,…
Layered Safety: Enhancing Autonomous Collision Avoidance via Multistage CBF Safety Filters
arXiv:2603.00338v2 Announce Type: replace Abstract: This paper presents a general end-to-end framework for constructing robust and reliable layered safety filte…
NS-VLA: Towards Neuro-Symbolic Vision-Language-Action Models
arXiv:2603.09542v3 Announce Type: replace Abstract: Vision-Language-Action (VLA) models are formulated to ground instructions in visual context and generate act…
Dynamic Properties and Motion Reproducibility of a Compact Pneumatically Actuated Humanoid Upper Body for Data-Driven Control
arXiv:2603.14787v3 Announce Type: replace Abstract: Pneumatically-actuated anthropomorphic robots with high degrees of freedom (DOF) offer significant potential…
Trajectory Tracking Control Design for Autonomous Helicopters with Guaranteed Error Bounds
arXiv:2603.08045v2 Announce Type: replace-cross Abstract: This paper presents a systematic framework for computing formally guaranteed trajectory tracking error…
Improving Imitation Learning Efficiency for Manipulation through Geometric Prior Pretraining
arXiv:2609.12721v1 Announce Type: new Abstract: Applying an imitation learning policy to a new manipulation task usually requires collecting new demonstrations …
STAR: Sparse Tactile Representation Learning in Vision-Tactile-Language-Action Models for Dexterous Manipulation
arXiv:2609.12549v1 Announce Type: new Abstract: Dexterous manipulation requires coordinated multi-finger control and effective tactile feedback, yet learning th…
ArtManip: Category-Level Articulated In-Hand Manipulation
arXiv:2609.12498v1 Announce Type: new Abstract: Category-level in-hand manipulation of articulated objects is a formidable yet underexplored challenge for dexte…
DATAFARM: Distribution-Aligned Task and Motion Planning for Fine-Tuning Vision-Language-Action Models
arXiv:2609.12316v1 Announce Type: new Abstract: Collecting high-quality robot data remains a fundamental challenge for training robot foundation models. Task an…
An Automated Thickness Evaluation Procedure Using an Integrated Structured Light 3D Camera in a Robotic Bioprinting Framework
arXiv:2609.12206v1 Announce Type: new Abstract: Bioprinting is emerging as a tissue engineering technique to replace common treatment methods for large scale in…
Scenario-Independent Criticality Assessment and Prediction for Vulnerable Road Users in Autonomous Driving
arXiv:2609.11947v1 Announce Type: new Abstract: Increasing safety is the primary objective of automated vehicles. Achieving this goal requires reliable safety m…