News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4147 stories
Automate 2026 show recap
Editors Steve Crowe, Mike Oitzman, and Sarah Wynn review Automate 2026, analyzing key trends in physical AI, humanoids, and software orchestration. The post Aut…
AI Chips for Robotics: Which Processors Power Modern Robots and Why It Matters (2026)
Controllers in Robotics: Game, Microcontroller, and PLC — Which One Does Your Robot Actually Need?
Robotics Deployment & Automation: Docker, Kubernetes, and CI/CD Pipelines for Robot Systems (2026 Guide)
#RoboCup2026 – humanoid league day 1
Image credit: RoboCup Federation. RoboCup 2026 kicked off today in Incheon, South Korea, with the league competitions running until 5 July. It’s an exciting tim…
Luxonis closes Series A round to scale physical AI perception layer
Luxonis said it plans to scale production of its OAK camera and refine its platform to support robotics and industrial automation. The post Luxonis closes Serie…
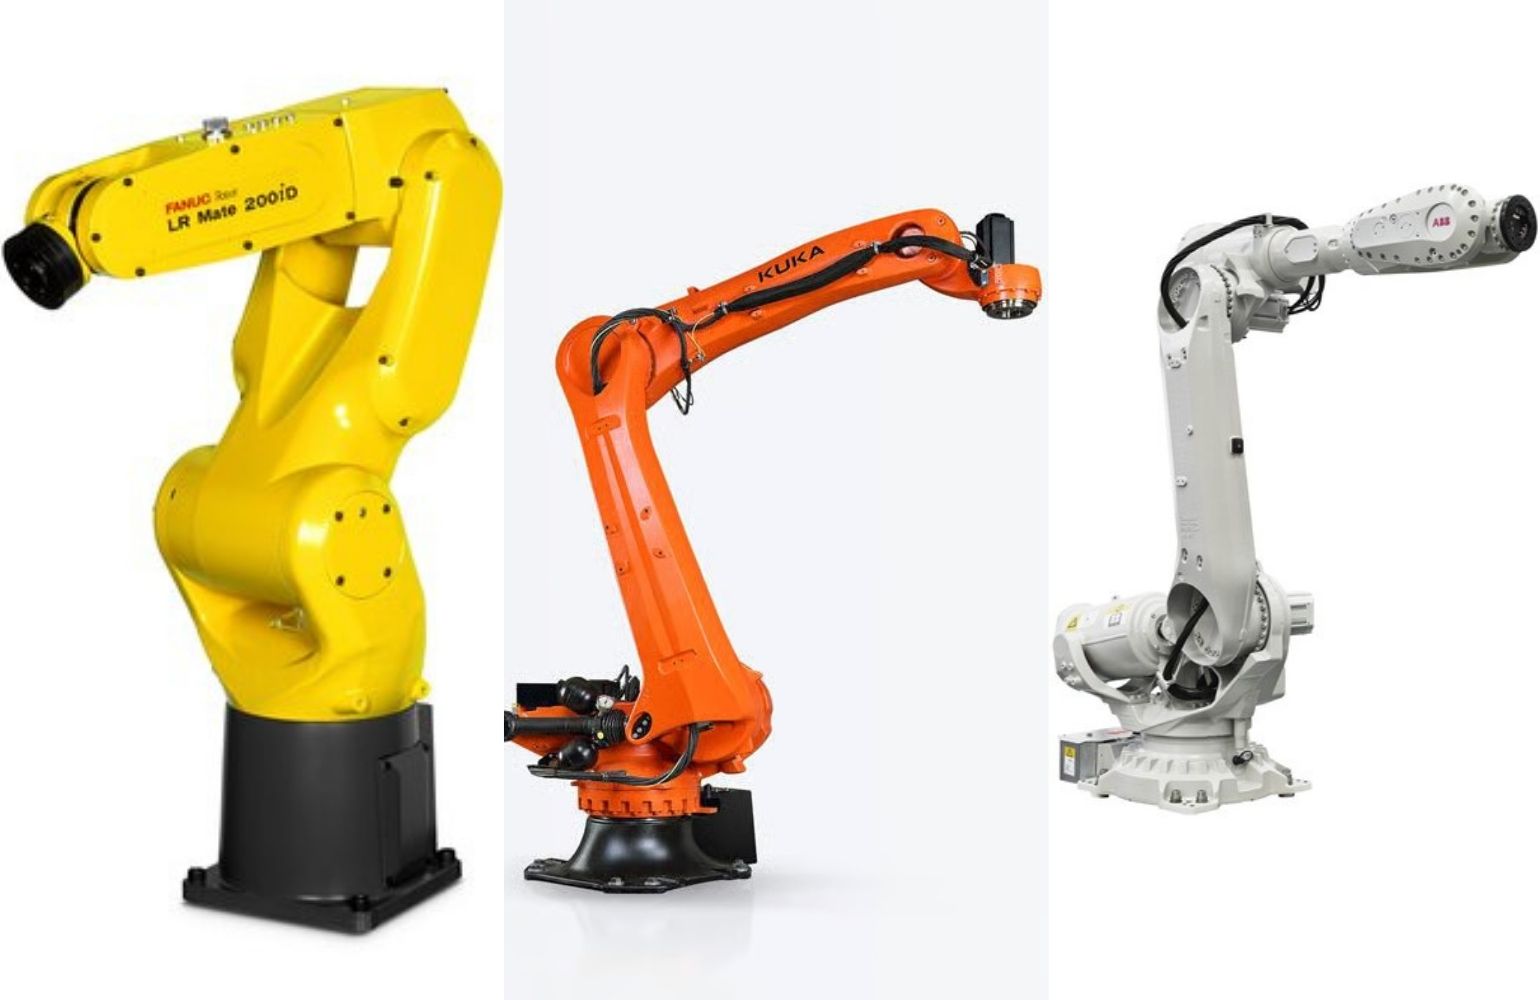
Why you should combine robot dexterity with mechanical positioning for complex assembly operations
Experts are recognizing the importance of mechanical positioning and its impact on the machine’s mobility, range and speed. The post Why you should combine robo…
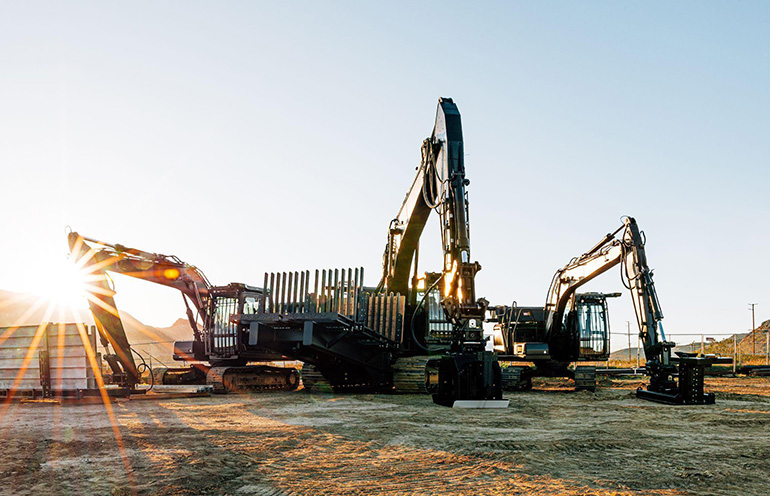
Blattner awards Built Robotics $75M contract for physical AI to help meet energy demand
Blattner has expanded its partnership with Built Robotics to scale autonomous systems for solar construction. The post Blattner awards Built Robotics $75M contr…
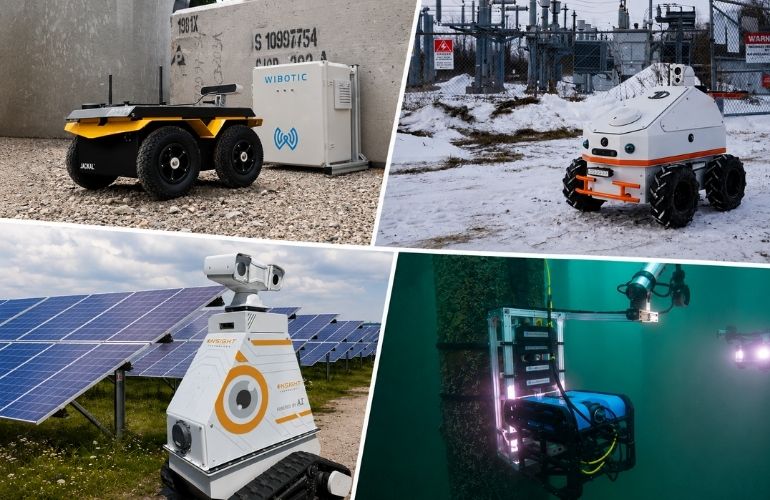
In Robotics, Ruggedization Is No Longer Optional
As autonomy moves beyond controlled environments, ruggedized design is becoming a prerequisite for reliable robotic operations. The post In Robotics, Ruggedizat…
Enhancing Robustness in Robot-Environment Interactions through Passive Compliant Degrees of Freedom: A Hybrid Position-Force Control Approach with Feedback Linearization
arXiv:2607.00571v1 Announce Type: new Abstract: Robot-environment interactions in dynamic or unstructured settings are often degraded by impact shocks, vibratio…
Guaranteed Escape for a Bouncing Robot in Pipe Chains
arXiv:2607.00221v1 Announce Type: cross Abstract: We study the symmetric bouncing of a point robot within orthogonally-joined rectangles with equal width, which…
Deconfounded Lifelong Learning for Autonomous Driving via Dynamic Knowledge Spaces
arXiv:2603.14354v3 Announce Type: replace-cross Abstract: End-to-End autonomous driving (E2E-AD) systems face challenges in lifelong learning, including catastr…
Human-Centric Transferable Tactile Pre-Training for Dexterous Robotic Manipulation
arXiv:2607.01067v1 Announce Type: new Abstract: As an essential modality for dexterous and contact-rich tasks, tactile sensing provides precise force feedback t…
FLYNN: Robust Neural Network for Robot Navigation using Fly Brain Topology
arXiv:2607.00025v1 Announce Type: new Abstract: While deep learning models achieve state-of-the-art performance in complex tasks, they remain brittle when faced…
Creating Impactful Autonomous Driving Datasets: A Strategic Guide from Research Gap to Benchmark
arXiv:2607.00710v1 Announce Type: cross Abstract: Well-designed autonomous driving datasets have fundamentally shaped research progress, yet existing literature…
DriveVA: Video Action Models are Zero-Shot Drivers
arXiv:2604.04198v2 Announce Type: replace-cross Abstract: Generalization is a central challenge in autonomous driving, as real-world deployment requires robust …
AMBUSH: Collaborative Capture in Complex Environments with Neural Acceleration
arXiv:2607.01029v1 Announce Type: new Abstract: Collaborative capture of dynamic targets is common in nature as an essential strategy for weaker species against…
AutoSpeed: Annotation-Free Stage-Adaptive Motion Speed Learning for Robot Manipulation
arXiv:2607.01051v1 Announce Type: new Abstract: Different stages of manipulation tasks exhibit varying levels of difficulty, suggesting stage-dependent motion s…
FurnitureVLA: Learning Long-Horizon Bimanual Furniture Assembly with Vision-Language-Action Model
arXiv:2607.01212v1 Announce Type: new Abstract: Current work on robot furniture assembly mostly focuses on toy-scale settings or single-arm manipulation. We int…
[Preprint] Dynamic Modeling, Gait Synthesis, and Control of a Novel Subsurface Bore Propagator
arXiv:2607.00569v1 Announce Type: new Abstract: In this article, we present dynamic modeling, gait synthesis, and feedback control design for a modular novel su…
Robust Operational Space Control with Conformal Disturbance Bounds for Safe Redundant Manipulation
arXiv:2607.00424v1 Announce Type: new Abstract: Redundant robotic manipulators operating in constrained and human-interactive environments require accurate task…
Enhancing Hardware Fault Tolerance in Machines with Reinforcement Learning Policy Gradient Algorithms
arXiv:2407.15283v2 Announce Type: replace-cross Abstract: Industry is moving toward autonomous, network-connected machines that detect and adapt to changing con…
Beyond Line of Sight: Hybrid Validation of V2X Collective Perception in Complex Scenarios
arXiv:2607.00874v1 Announce Type: new Abstract: This paper introduces a probabilistic framework and hybrid validation methodology for V2X-enabled Collective Per…
KungfuBot: Physics-Based Humanoid Whole-Body Control for Learning Highly-Dynamic Skills
arXiv:2506.12851v3 Announce Type: replace Abstract: Humanoid robots are promising to acquire various skills by imitating human behaviors. However, existing algo…
Learning Expert Strategy for Autonomous Robotic Endovascular Intervention via Decoupled Procedural Execution
arXiv:2607.00066v1 Announce Type: new Abstract: Endovascular interventions are high-stakes procedures requiring precise device operation within complex and tort…
Neural Surface and Reflectance Modelling from 3D Radar Data
arXiv:2603.25623v2 Announce Type: replace Abstract: Robust scene representation is essential for autonomous systems to safely operate in challenging low-visibil…
ROSA: A Robotics Foundation Model Serving System for Robot Factories
arXiv:2607.01088v1 Announce Type: new Abstract: Robotics foundation models (RFMs) are making general-purpose robots increasingly practical for factory deploymen…
Search-Based Spatiotemporal and Multi-Robot Motion Planning on Graphs of Space-Time Convex Sets
arXiv:2607.00444v1 Announce Type: new Abstract: Spatiotemporal motion planning, especially in multi-robot settings, requires robots to reason about collision-fr…
Stop Pretending Social Robots Are Inevitable
arXiv:2607.00142v1 Announce Type: new Abstract: This paper takes issue with the recent themes of both the RO-MAN and the HRI conferences for their portrayal of …
Where Am I? Semantic Map Grounding via Vision-Language Models for Multi-Modal Localization
arXiv:2607.01079v1 Announce Type: new Abstract: We address robot localization in GPS-denied indoor environments by reframing it as a semantic reasoning task rat…