News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4147 storiesGigaWorld-1: A Roadmap to Build World Models for Robot Policy Evaluation
arXiv:2607.02642v1 Announce Type: new Abstract: Evaluating embodied robot foundation models remains a critical bottleneck; unlike large language models efficien…
Learning 3D Affordances for Blade Insertion in Cluttered Stowing
arXiv:2607.02549v1 Announce Type: cross Abstract: Many manipulation tasks require reasoning about free-space affordances: discovering volumes where an extended …
WSA$_1$: a 3D-Centric World-Spatial-Action Model for Generalizable Robot Control
arXiv:2607.03941v1 Announce Type: new Abstract: Recent advances in embodied AI have established robot foundation models (RFMs) as the dominant approach for gene…
FLOAT Drone for Physical Interaction: Lateral Airflow Reduction, Wrench Modeling, and Adaptive Control
arXiv:2607.04260v1 Announce Type: new Abstract: Aerial physical interaction represents a promising direction for next-generation unmanned aerial vehicles (UAVs)…
Real-World Perturbation Testing of Autonomous Driving Systems
arXiv:2607.04953v1 Announce Type: cross Abstract: Autonomous Driving Systems (ADS) must operate reliably under diverse conditions, yet representative data for r…
KAM-WM: Kinematic Affordance Maps from Latent World Models for Robot Manipulation
arXiv:2607.04652v1 Announce Type: new Abstract: Learning manipulation from few demonstrations requires visual priors that capture not only where to interact, bu…
ObjRetarget: An Object-Aware Motion Retargeting Framework with Anthropomorphic Arm Constraints and Polyhedral Hand Modeling
arXiv:2607.03828v1 Announce Type: new Abstract: Learning robot dexterous manipulation from human manipulation videos requires reliably retargeting human intent …
Verifier-free Test-Time Sampling for Vision-Language-Action Models
arXiv:2510.05681v2 Announce Type: replace Abstract: Vision-Language-Action models (VLAs) have demonstrated remarkable performance in robot control. However, the…
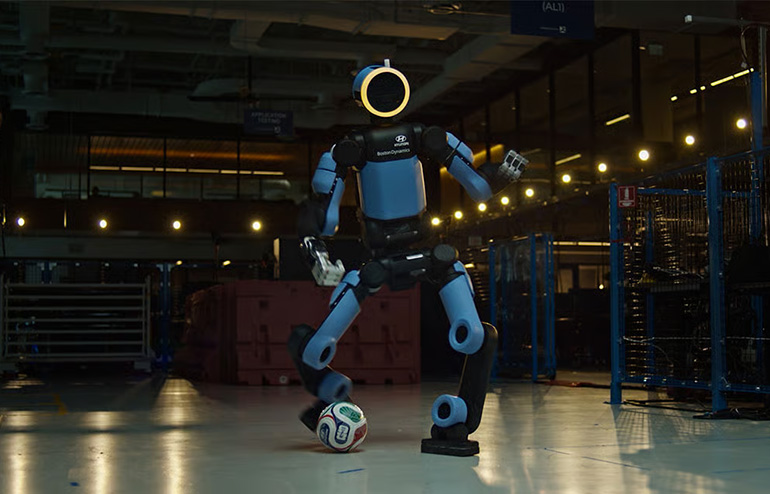
Boston Dynamics brings its legged robots to the FIFA World Cup
Around the 2026 FIFA World Cup, Hyundai and Boston Dynamics have taught footwork to the Atlas humanoid, while the Spot robot is on patrol. The post Boston Dynam…
Kraken Robotics acquires Covelya Group for $615M
Covelya Group expands Kraken Robotics' product offerings and total addressable market in subsea technology. The post Kraken Robotics acquires Covelya Group for …

Quantum Systems raises $1.2B to expand drone production and deployments
Quantum plans to use the proceeds to expand production capacity, strengthen supply chain resilience, and more. The post Quantum Systems raises $1.2B to expand d…

RoboBusiness 2026 call for speakers closes soon
RoboBusiness 2026, the premier event for developers of commercial robotics and those building robotics businesses, is seeking expert speakers. The post RoboBusi…
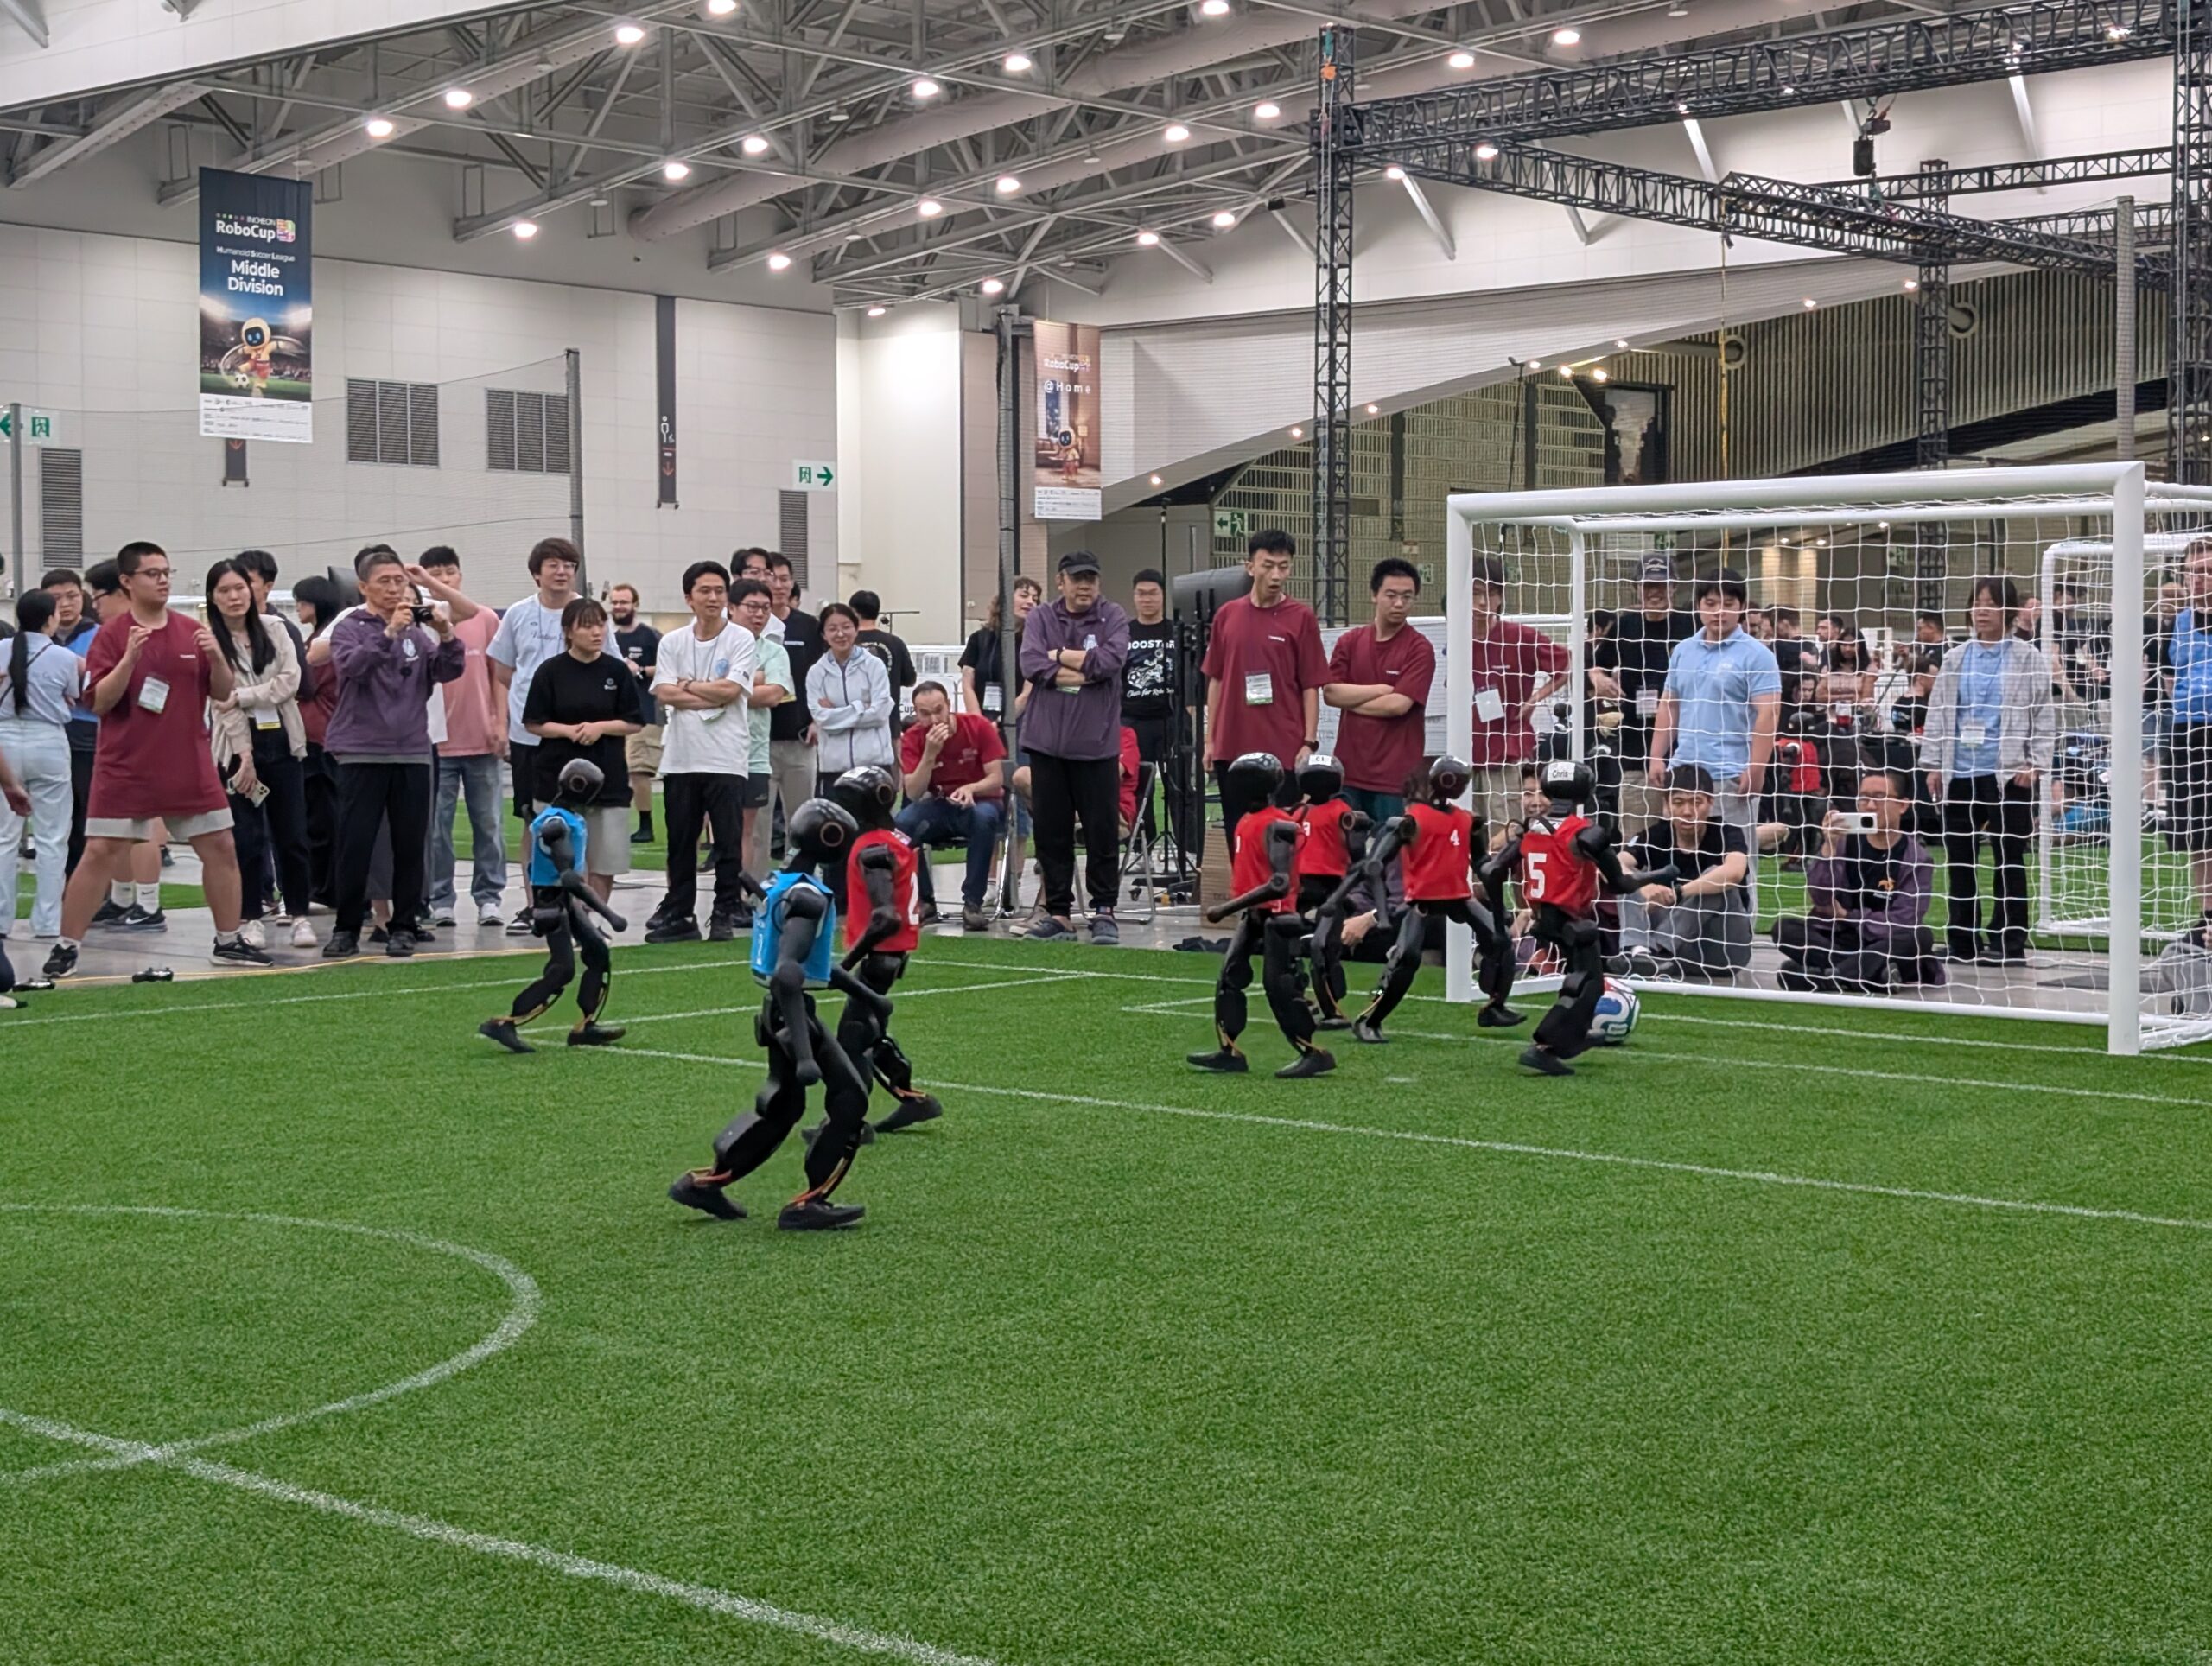
#RoboCup2026 – humanoid league knockout stages
This weekend saw the finale of the league competitions at RoboCup 2026 in Incheon, South Korea, with the winners in the small, middle, and large humanoid divisi…
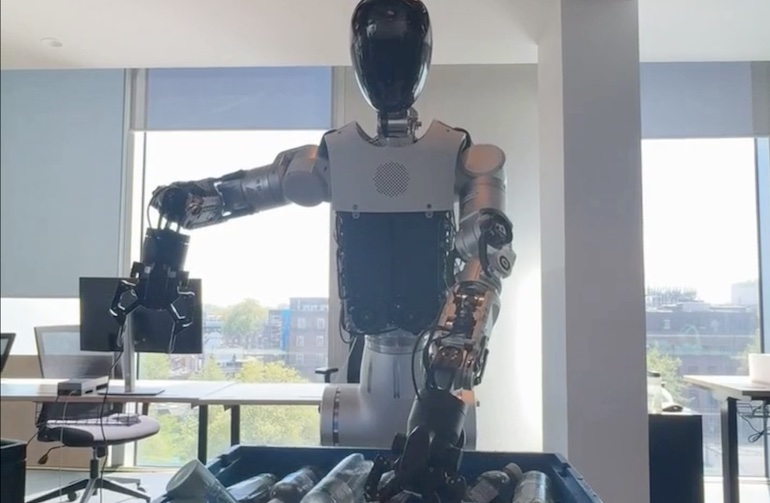
Humanoid says KinetIQ Ascend reinforcement learning approaches human-level dexterity
Humanoid says its KinetIQ Ascend approach can reach 99.9% manipulation reliability at human speed and beyond for industrial tasks. The post Humanoid says KinetI…
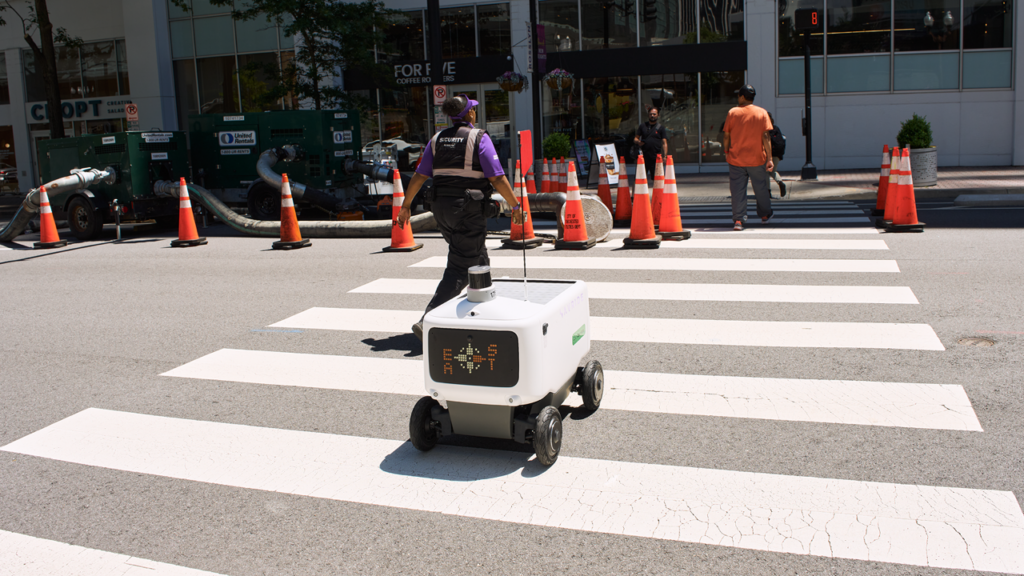
Context is king: How Avride uses cloud VLMs as a safety net for delivery robots
Avride uses vision-language models, or VLMs, to improve the environmental awareness of its delivery robots. The post Context is king: How Avride uses cloud VLMs…
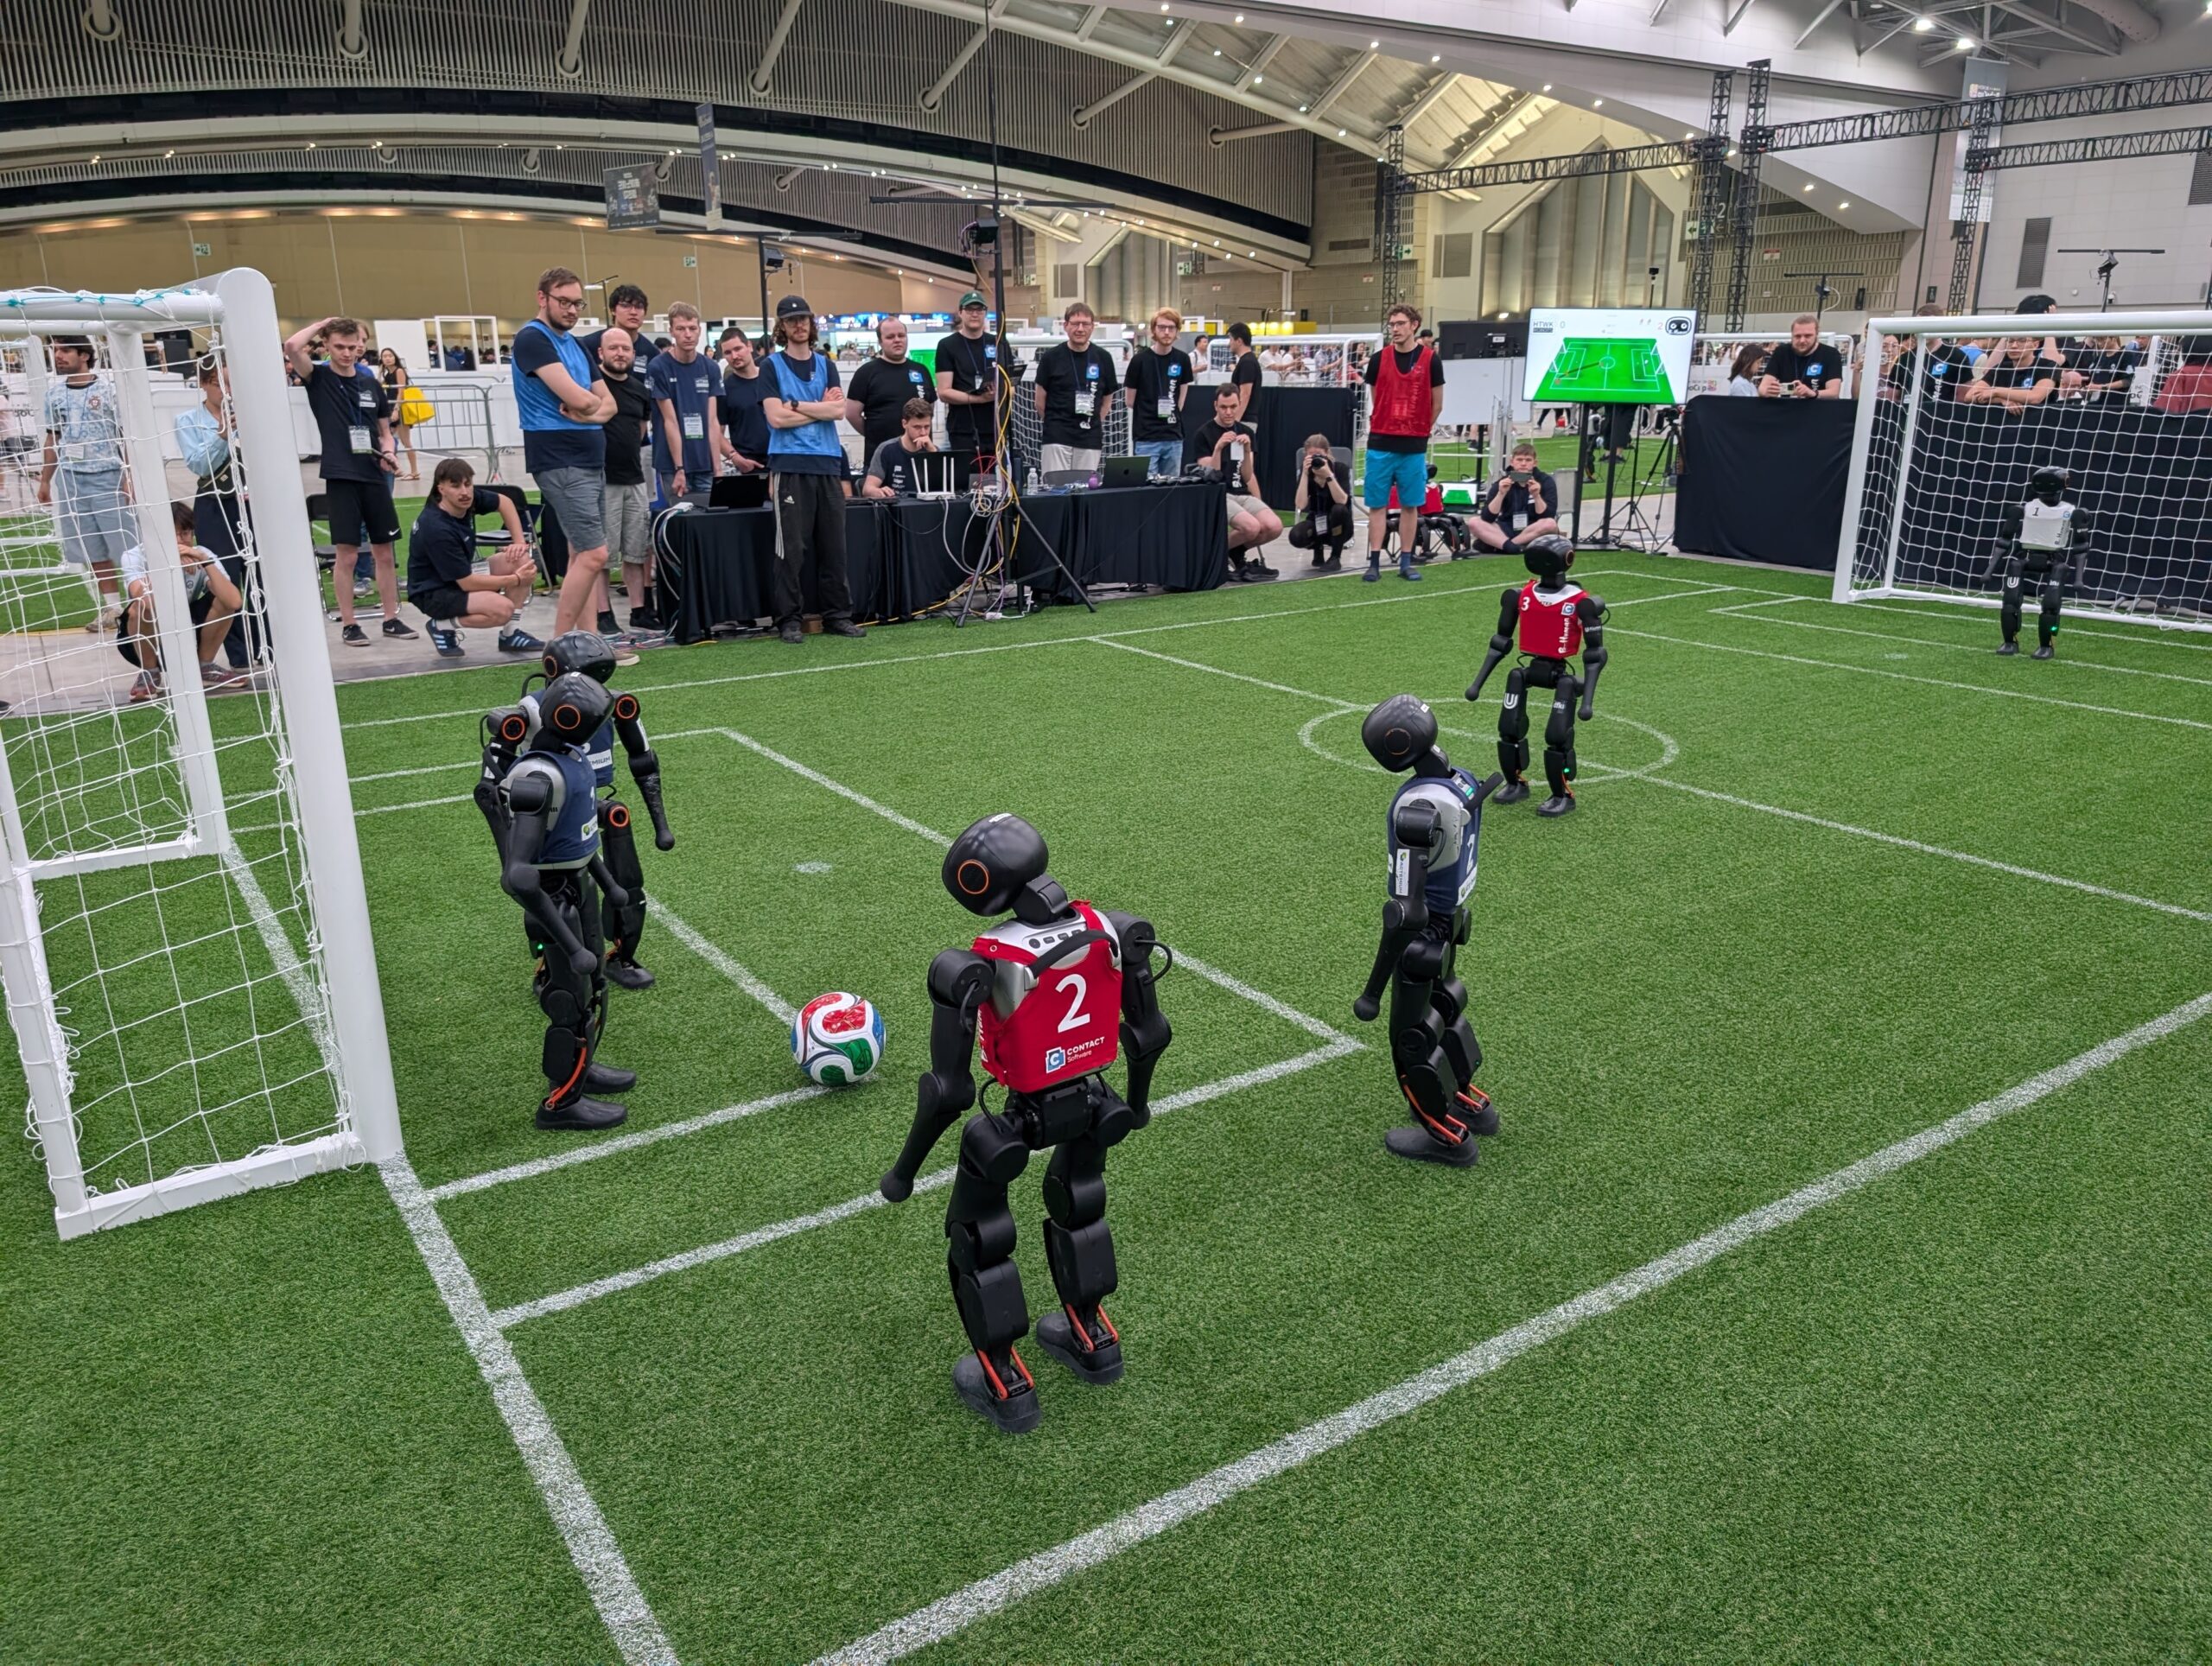
#RoboCup2026 – humanoid league day 2
The second day’s play at RoboCup 2026 has drawn to a close with another bumper set of matches. Teams have come from far and wide to take part in the humanoid so…
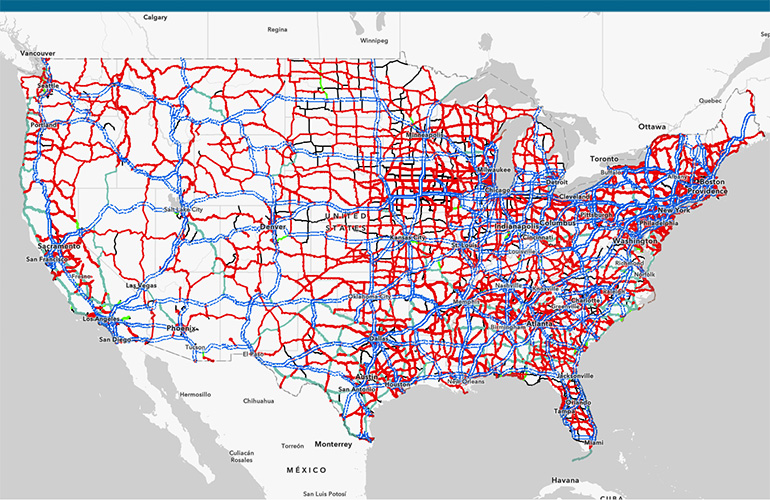
Quarterhill discusses transport modernization as U.S. marks 70 years of federal highways
At the U.S. celebrates 250 years of independence and 70 years of its highway system, an expert looks at the future of autonomous transport. The post Quarterhill…
Choreographing the Way of Water: A Computational Framework for Aquatic Robotic Art
arXiv:2607.02174v1 Announce Type: new Abstract: Robotic choreography in open water is governed by nonlinear fluid dynamics, which impose significant challenges …
Learning to Localize Reference Trajectories in Image-Space for Visual Navigation
arXiv:2602.18803v2 Announce Type: replace Abstract: We present LoTIS, a model for visual navigation that provides robot-agnostic image-space guidance by localiz…
Embodied.cpp: A Portable Inference Runtime of Embodied AI Models on Heterogeneous Robots
arXiv:2607.02501v1 Announce Type: new Abstract: Embodied AI models now span vision-language-action (VLA) models and world-action models (WAMs), but practical de…
Cross-Platform Control for Autonomous Surface Vehicles via Adaptive Reinforcement Learning
arXiv:2607.02037v1 Announce Type: new Abstract: Autonomous surface vehicles vary widely in hydrodynamic and actuation characteristics, yet most controllers are …
A Convex Obstacle Avoidance Formulation
arXiv:2512.13836v2 Announce Type: replace-cross Abstract: Autonomous driving requires reliable collision avoidance in dynamic environments. Nonlinear Model Pred…
PhysMani: Physics-principled 3D World Model for Dynamic Object Manipulation
arXiv:2607.01938v1 Announce Type: new Abstract: Manipulating fast and dynamically moving targets in unstructured 3D environments remains challenging for embodie…
Robust Image Processing Techniques for Construction Environment Monitoring Using Underwater Robots
arXiv:2607.01915v1 Announce Type: cross Abstract: This paper proposes a robust image processing framework for underwater robot-based construction environment mo…
Restoring Linguistic Grounding in VLA Models via Train-Free Attention Recalibration
arXiv:2603.06001v2 Announce Type: replace Abstract: Vision-Language-Action (VLA) models enable robots to perform manipulation tasks directly from natural langua…
CommonRoad-Game: A Human-in-the-Loop Simulation Framework for Autonomous Driving
arXiv:2607.01382v1 Announce Type: new Abstract: Motion planning algorithms should be evaluated in human-in-the-loop environments to ensure they produce safe and…
NEUROSYMLAND: Neuro-Symbolic Landing-Site Assessment for Robust and Edge-Deployable UAV Autonomy
arXiv:2607.02277v1 Announce Type: new Abstract: Safe landing-site assessment in unstructured environments remains a key challenge for autonomous UAV deployment,…
VLSA: Vision-Language-Action Models with Plug-and-Play Safety Constraint Layer
arXiv:2512.11891v2 Announce Type: replace Abstract: Vision-Language-Action (VLA) models have demonstrated remarkable capabilities in generalizing across diverse…
Imagining the Sense of Touch: Touch-Informed Manipulation via Imagined Tactile Representations
arXiv:2607.01684v1 Announce Type: new Abstract: Tactile sensing can substantially improve contact-rich robotic manipulation, yet its practical deployment remain…
Sim2Real-AD: A Modular Sim-to-Real Framework for Deploying VLM-Guided Reinforcement Learning in Real-World Autonomous Driving
arXiv:2604.03497v2 Announce Type: replace Abstract: Vision-language-model (VLM)-guided reinforcement learning (RL) has recently attracted significant attention …