News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4147 storiesFrom Prior to Pro: Efficient Skill Mastery via Distribution Contractive RL Finetuning
arXiv:2603.10263v2 Announce Type: replace Abstract: We introduce Distribution Contractive Reinforcement Learning (DICE-RL), a framework that uses reinforcement …
Top 10 robotics developments of June 2026
Humanoid robots made many headlines in June 2026, whether it be for companies going public, new deployments, or hitting production milestones. The post Top 10 r…
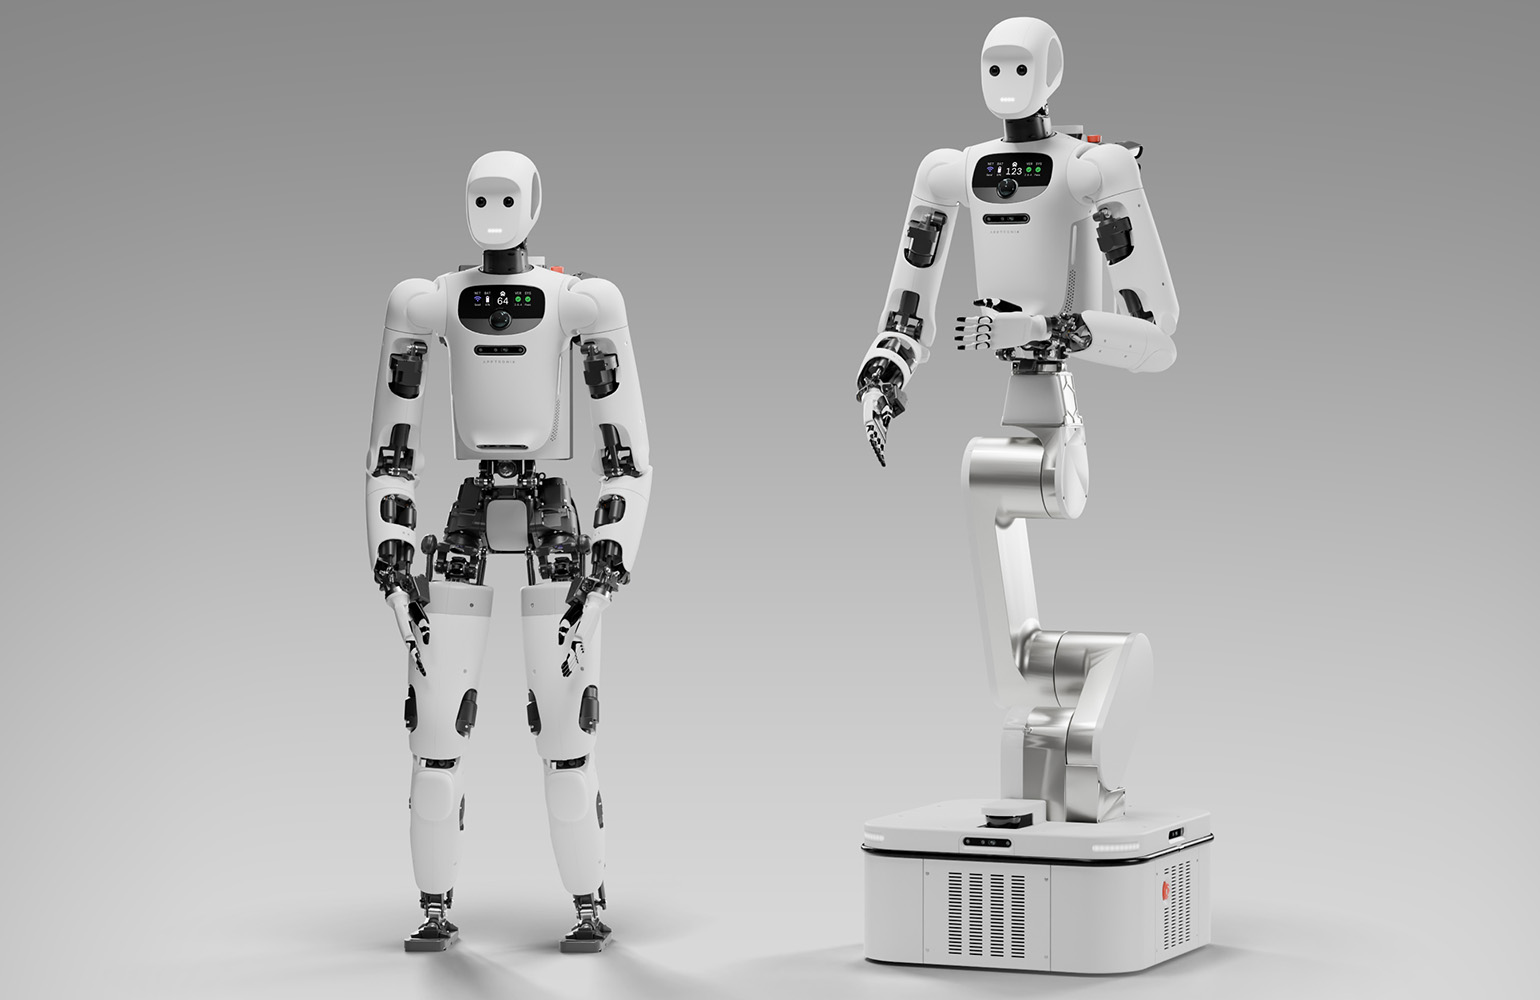
Apptronik unveils Apollo 2 and a flagship data collection and training facility
Built as a data collection and training platform, Apollo 2 enables continuous learning through deployment, Apptronik said. The post Apptronik unveils Apollo 2 a…
OopsieVerse: A Safety Benchmark with Damage-Aware Simulation for Robot Manipulation
arXiv:2606.31993v1 Announce Type: new Abstract: While robotic manipulation capabilities have advanced rapidly, physical safety remains a major barrier to deploy…
Multi-Robot Coordination for Planning under Context Uncertainty
arXiv:2603.13748v3 Announce Type: replace Abstract: Real-world robots often operate in settings where objective priorities depend on the underlying context of o…
HABIT: Human-Aware Behavior and Interaction Training Dataset for Robot Manipulation
arXiv:2606.31682v1 Announce Type: new Abstract: Large-scale demonstration datasets have been central to recent progress in general-purpose robot policies. Howev…
StemVLA:An Open-Source Vision-Language-Action Model with Future 3D Spatial Geometry Knowledge and 4D Historical Representation
arXiv:2602.23721v2 Announce Type: replace Abstract: Vision-language-action (VLA) models integrate visual observations and language instructions to predict robot…
Efficient Sim-to-Real Transfer of World-Action Models from Synthetic Priors
arXiv:2606.31101v1 Announce Type: new Abstract: Bridging the sim-to-real gap is a core challenge in deploying learned manipulation policies. Sim-to-real learnin…
Stage-Transition Dense Reward Modeling for Reinforcement Learning
arXiv:2606.31377v1 Announce Type: new Abstract: Reinforcement learning for long-horizon robotic manipulation is often limited by sparse and delayed rewards, whi…
RhinoVLA Technical Report
arXiv:2606.07383v2 Announce Type: replace Abstract: Vision-Language-Action (VLA) models have shown strong potential for robotic manipulation, but real-time depl…
LLM-Powered Interactive Robotic Action Synthesis from Multimodal Speech, Gestures, and Music
arXiv:2606.31158v1 Announce Type: new Abstract: The quest for intuitive and natural human-robot interaction (HRI) remains a significant challenge in robotics. T…
Off the Rails: Hijacking the Scoring Head in Generative End-to-End Driving Planners with Safety-Violating Adversarial Perturbations
arXiv:2606.30807v1 Announce Type: new Abstract: Generative models have recently seen rapid adoption in End-to-End (E2E) autonomous driving (AD), with diffusion-…
Early-Terminable Energy-Safe Iterative Coupling for Parallel Simulation of Partitioned Port-Hamiltonian Systems
arXiv:2603.16424v2 Announce Type: replace Abstract: Parallel simulation of robotic systems requires partitioning the dynamics into coupled subsystems. Finite-it…
Position: Vision-Language-Action Models Cannot Be Verified to Perform Physical Reasoning
arXiv:2606.30686v1 Announce Type: new Abstract: Vision-Language-Action (VLA) systems, built on pretrained vision-language models (VLMs), have shown rapidly impr…
Designing Privacy-Preserving Visual Perception for Robot Navigation Based on User Privacy Preferences
arXiv:2604.06382v2 Announce Type: replace Abstract: Visual navigation is a fundamental capability of mobile service robots, yet the onboard cameras required for…
Learning Locomotion on Discrete Terrain via Minimal Proximity Sensing
arXiv:2606.31912v1 Announce Type: new Abstract: Learning-based control has revolutionized dynamic locomotion, yet navigating unstructured terrain remains limite…
RCT: A Robot-Collected Touch-Vision-Language Dataset for Tactile Generalization
arXiv:2606.31694v1 Announce Type: new Abstract: For robots manipulating open-world objects, tactile representations must generalize to unseen materials. We intr…
ShapeGrasp: Simultaneous Visuo-Haptic Shape Completion and Grasping for Improved Robot Manipulation
arXiv:2605.02347v2 Announce Type: replace Abstract: Humans grasp unfamiliar objects by combining an initial visual estimate with tactile and proprioceptive feed…
Robustness of Robotic Manipulation: Foundations and Frontiers
arXiv:2606.31494v1 Announce Type: new Abstract: Humans and animals exhibit remarkable robustness in physical manipulation, yet robots remain far behind. Progres…
Learn Weightlessness: Imitate Non-Self-Stabilizing Motions on Humanoid Robot
arXiv:2604.21351v2 Announce Type: replace Abstract: The integration of imitation and reinforcement learning has enabled remarkable advances in humanoid whole-bo…
Genie Sim 3.0 : A High-Fidelity Comprehensive Simulation Platform for Humanoid Robot
arXiv:2601.02078v3 Announce Type: replace Abstract: The development of robust and generalizable robot learning models is critically contingent upon the availabi…
RPG: Robust Policy Gating for Smooth Multi-Skill Transitions in Humanoid Fighting
arXiv:2604.21355v2 Announce Type: replace Abstract: Humanoid robots have demonstrated impressive motor skills in a wide range of tasks, yet whole-body control f…
CoReLIN: Constraint-based Reasoning for Zero-shot Lifelong Interactive Navigation
arXiv:2602.20055v2 Announce Type: replace Abstract: Robot navigation typically assumes an obstacle-free path exists between start and goal. In real environments…
Multimodal Benchmark for Safety Assessment in Industrial Inspection Scenarios
arXiv:2601.21173v2 Announce Type: replace Abstract: With the rapid development of industrial intelligence and unmanned inspection, reliable perception and safet…
PriorEye: Geospatial Visual Priors for End-to-End Autonomous Driving
arXiv:2606.31830v1 Announce Type: cross Abstract: Most end-to-end autonomous driving methods rely solely on instantaneous sensor observations, limiting them to …
From Grasps to Dexterity: Large-Scale Grasp Pretraining for Dexterous Manipulation
arXiv:2606.30749v1 Announce Type: new Abstract: Large-scale dexterous grasp datasets encode rich priors over hand-object interaction, but their use has largely …
LARA: Latent Action Representation Alignment for Vision-Language-Action Models
arXiv:2606.07100v2 Announce Type: replace-cross Abstract: Visual-language action (VLA) models enable robots to predict actions directly from observations and la…
Neural Control: Adjoint Learning Through Equilibrium Constraints
arXiv:2605.03288v2 Announce Type: replace Abstract: Many physical AI tasks require sequential implicit computation: at each step, boundary controls are applied,…
Learning All-Terrain Locomotion for a Planetary Rover with Actively Articulated Suspension
arXiv:2606.06790v2 Announce Type: replace Abstract: This paper presents ERNEST, a four-wheeled planetary rover concept equipped with a two-degree-of-freedom Act…
Multisensory Continual Learning: Adapting Pretrained Visuomotor Policies to Force
arXiv:2606.30988v1 Announce Type: new Abstract: Robot manipulation often relies on sensory feedback beyond vision, particularly in contact-rich settings where f…