Industry
Robots at work: warehouses, factories, farms, hospitals, construction sites and the automation reshaping them.
Robots at work: warehouses, factories, farms, hospitals, construction sites and the automation reshaping them.
Latest in Industry
903 storiesLearning Manipulation-Sufficient Representations via Outcome Bottlenecks
arXiv:2609.13235v1 Announce Type: new Abstract: Networked manipulation endpoints couple perception to actuation across compute- and bandwidth-limited links, yet…
Self-Evolving AI for Humanoids: Mechanisms, Safety, and Evaluation of Post-Deployment Self-Improvement
arXiv:2609.13236v1 Announce Type: new Abstract: Humanoid robots are becoming an important part of embodied artificial intelligence, driven by advances in reinfo…
REVOLVE: An Automated Closed-Loop Framework for Evolving Robot Manipulation with Minimal Human Intervention
arXiv:2609.14633v1 Announce Type: new Abstract: Recent advances in data-driven robot manipulation policies have substantially improved task execution and genera…
An MRI-Guided Robotic System to Improve Hippocampal Access for Epilepsy Interventions
arXiv:2609.13572v1 Announce Type: new Abstract: This paper presents an MRI-guided robotic system that improves hippocampal access by delivering a curved needle-…
How to Better Train VLAs: Lessons Learned From the REAL-I Challenge at ICRA 2026
arXiv:2609.13679v1 Announce Type: new Abstract: How can robot policies learn more effectively from a fixed demonstration budget? The first Real-world Embodied A…
Generating Realistic Safety-Critical Scenarios for Vehicle-Pedestrian Interactions
arXiv:2605.17229v2 Announce Type: replace Abstract: Automated driving system deployment requires rigorous validation across safety-critical vehicle-pedestrian i…
Steering Generative Robot Policies with Lexicographic Preferences
arXiv:2609.15014v1 Announce Type: new Abstract: Pretrained generative robot policies can produce effective behaviors across diverse environments, but deployment…
Decentralized Multi-Robot Task Allocation Under Degraded Communication: A Benchmark of Performance, Reliability, and Computation
arXiv:2609.13711v1 Announce Type: new Abstract: Selecting a decentralized Multi-Robot Task Allocation (MRTA) method for embedded deployment on autonomous platfo…
LiPS: Lightweight Panoptic Segmentation for Resource-Constrained Robotics
arXiv:2604.00634v3 Announce Type: replace Abstract: Panoptic segmentation is a key enabler for robotic perception, as it unifies semantic understanding with obj…
Proprioception-Anchored Cross-Modal Pretraining for Zero-Shot Sim-to-Real Contact-Rich Assembly
arXiv:2609.07534v2 Announce Type: replace Abstract: Contact-rich assembly remains challenging because it requires submillimeter spatial accuracy and reliable in…
Learning Multi-Agent Task Assignment and Navigation in the Factory: from Simulation to Real Robots
arXiv:2609.14567v1 Announce Type: new Abstract: Reinforcement learning (RL) has shown considerable promise for robotic decision-making, yet deploying multi-agen…
Task-Specified Active Metrological Inspection with Measurement-Steered VLA Manipulation and Deterministic Evidence Gating
arXiv:2609.14219v1 Announce Type: new Abstract: High-mix low-volume (HMLV) manufacturing requires inspection systems to adapt to changing parts, specifications,…
Is Semantic SLAM Ready for Embedded Systems ? A Comparative Survey
arXiv:2505.12384v2 Announce Type: replace Abstract: Semantic SLAM holds promise for robust robot navigation in complex environments, but its practicality on emb…
Report covers advances in surgical robots, deploying warehouse automation in the real world
Learn from a surgical robotics case study and a discussion of how to best deploy mobile robots in the warehouse in this issue. The post Report covers advances i…
RodForesight: A World Model Enhanced Diffusion Policy for Slender and Material Agnostic Rod Insertion
arXiv:2609.12103v1 Announce Type: new Abstract: Slender rod insertion arises in precision manufacturing, where millimetre scale diameter and tight clearances de…
Size Doesn't Matter: Material-State Reinforcement Learning for Excavator Transferable Soil Manipulation
arXiv:2609.12677v1 Announce Type: new Abstract: Earthmoving tasks such as excavation, backfilling, or embankment construction require deliberate repositioning o…
RoMu4o: A Robotic Manipulation Unit For Orchard Operations Automating Proximal Hyperspectral Leaf Sensing
arXiv:2501.10621v3 Announce Type: replace Abstract: Driven by the need to address labor shortages and meet the demands of a rapidly growing population, robotic …
Comfort by Construction: Adaptive, Comfort-Bounded Action Spaces for Learned Driving Policies
arXiv:2609.13011v1 Announce Type: new Abstract: Data-driven driving simulators command accelerations and steering rates from a fixed grid without constraining t…
From Transportation to Manipulation: Enabling Grasping in Magnetic Robotics
arXiv:2609.12883v1 Announce Type: new Abstract: Magnetic levitation (MagLev) systems have great potential for application in high-mix, low-volume manufacturing …
FARM: Reading Failure Signals from the Internal Predictive States of a Frozen Robotic World Model
arXiv:2609.11445v1 Announce Type: new Abstract: Reliable robot deployment requires online failure monitoring, yet existing monitors mainly derive risk from prox…
CMoE: Contrastive Mixture of Experts for Motion Control and Terrain Adaptation of Humanoid Robots
arXiv:2603.03067v2 Announce Type: replace Abstract: For effective deployment in real-world environments, humanoid robots must autonomously navigate a diverse ra…
CAP: Continuously Adaptive Perception-Blind Humanoid Locomotion via Learned Denoising
arXiv:2609.11553v1 Announce Type: new Abstract: Humanoid locomotion across complex terrain demands forward-looking exteroception to anticipate obstacles, yet th…
Modular Kinematic Reduction of Closed-Chain Mechanisms Using Path Assembly and Defect Homotopy
arXiv:2609.11338v1 Announce Type: new Abstract: Closed kinematic chains complicate modular modeling by coupling active and passive coordinates through nonlinear…
Harness Robotic OS: A Unified Embodied-Agent Runtime for Closed-Loop Quadruped Inspection
arXiv:2609.11225v1 Announce Type: new Abstract: Autonomous property inspection requires more than robust robot navigation: a deployable system must connect hete…
Lie-Algebraic Bell Recurrences for Arbitrary-Order Twist Jets and Parallel-Mechanism Closure
arXiv:2609.10748v1 Announce Type: new Abstract: This paper develops an arbitrary-order kinematic construction that links serial propagation, parallel-mechanism …
ActSafeGuard: Differentiable and Training-Aligned Constraint Enforcement for Flow-Matching Policies
arXiv:2609.11697v1 Announce Type: new Abstract: Vision-Language-Action (VLA) and World-Action Models (WAMs) have demonstrated strong capabilities in general-pur…
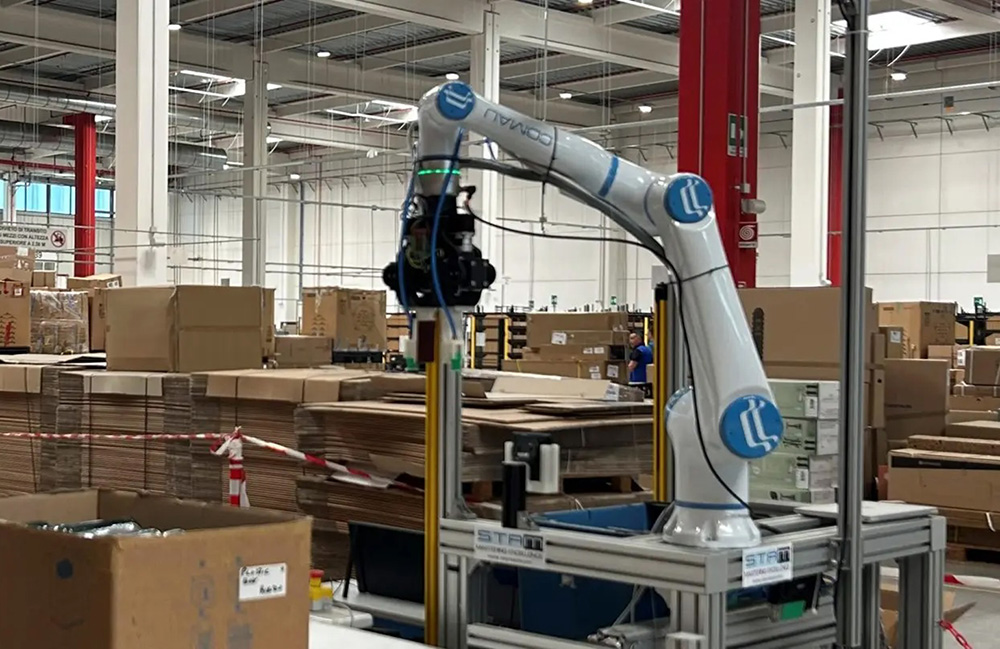
Comau automates picking, handling, and palletizing for Decathlon
Comau's system incorporates its MyCo cobot, ROS2 software architecture, AI-powered vision systems, and a modular gripper. The post Comau automates picking, hand…
Design and Attitude Control of an Underwater Quadruped Robot
arXiv:2609.09217v1 Announce Type: new Abstract: Legged robots are versatile on land, but their use in underwater environments remains limited. Extending quadrup…
Coastal Environment Generation with HoloOcean
arXiv:2609.10484v1 Announce Type: new Abstract: Marine robotic simulation provides a safe and inexpensive method of developing and testing algorithms for unmann…
Agentic AI-enabled Semantic Commissioning of a Cognitive Digital Twin for Reconfigurable Manufacturing
arXiv:2609.09503v1 Announce Type: new Abstract: Rapid bespoke commissioning of the Cognitive Digital Twin (CDT) is a major challenge in reconfigurable manufactu…