Industry
Robots at work: warehouses, factories, farms, hospitals, construction sites and the automation reshaping them.
Robots at work: warehouses, factories, farms, hospitals, construction sites and the automation reshaping them.
Latest in Industry
903 storiesPosterior-driven Heuristic Support Adaptation in a Probabilistic Treatment of Real2Sim2Real for Vision-Driven Deformable Linear Object Manipulation
arXiv:2510.26656v4 Announce Type: replace Abstract: Likelihood-free inference (LFI) enables system identification in complex tasks via black-box modelling, abst…
A traffic management system for large and heterogeneous vehicles in narrow industrial environments
arXiv:2609.10400v1 Announce Type: new Abstract: The coordination of Automated Guided Vehicles (AGVs) in high-density industrial environments represents a critic…
HiRAD: A Flexible Large-Scale AGV Routing System
arXiv:2609.09752v1 Announce Type: new Abstract: Automatic Guided Vehicles (AGVs) substantially boost warehouse throughput, but routing large-scale AGV fleets re…
AXON: A ROS 2 RMW with Shared-Memory/QUIC Transport and QKD/ML-KEM Key Establishment
arXiv:2609.10024v1 Announce Type: new Abstract: Robot Operating System 2 (ROS 2) standardizes application code against a middleware interface (RMW) whose refere…
Proxy Policy Steering
arXiv:2609.09148v2 Announce Type: replace Abstract: Generalist robot policies carry broad manipulation priors from large-scale data, but specializing them to a …
Frame-Coded Legged Locomotion over Noisy Terrain
arXiv:2609.10273v1 Announce Type: cross Abstract: Open-loop multilegged locomotion over rough terrain has been interpreted as matter transport over a noisy chan…
Assembling Two Parts in One Hand
arXiv:2609.10137v1 Announce Type: new Abstract: A hallmark of human dexterity is the cooperative use of fingers, where different fingers take on distinct yet co…
A Risk-Sensitive and Uncertainty-Aware Decision-Making and Control Framework for Safe and Robust Autonomous Driving
arXiv:2609.09650v1 Announce Type: new Abstract: Reinforcement learning (RL) has demonstrated considerable potential for autonomous driving decision-making. Howe…
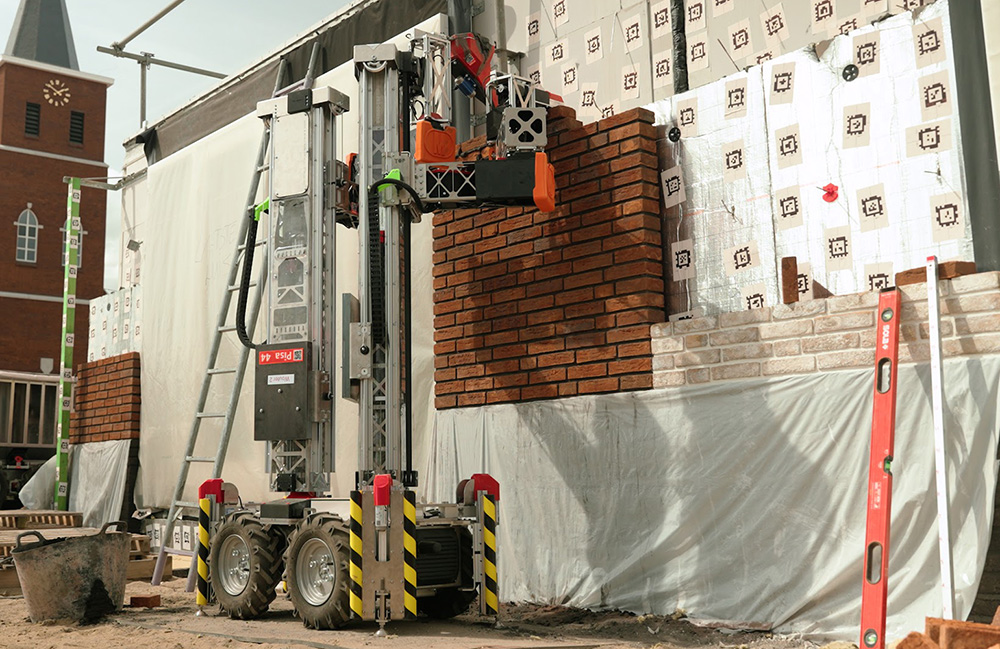
What bricklaying has taught Monumental about robots in construction
The construction industry is rife with opportunity for robotics, but the technology hasn't broken in at scale yet. The post What bricklaying has taught Monument…
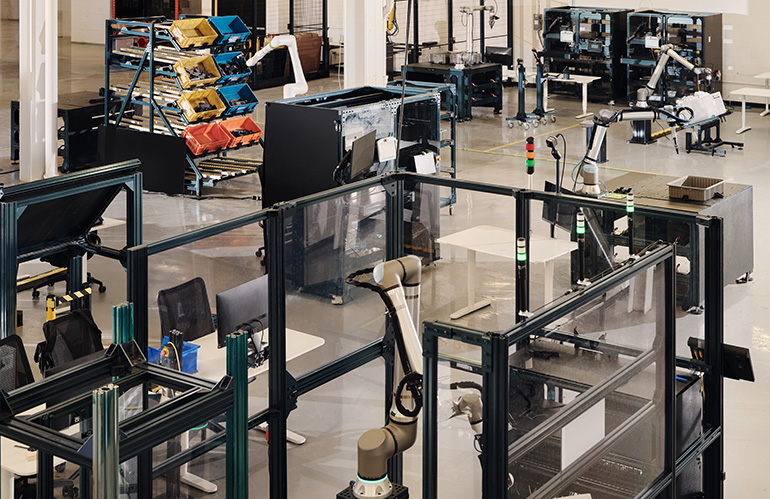
Vention opens Physical AI Lab for manufacturing in Montreal
Vention's new Physical AI Lab will focus on advancing robotic manipulation from research to scalable production-line deployment. The post Vention opens Physical…
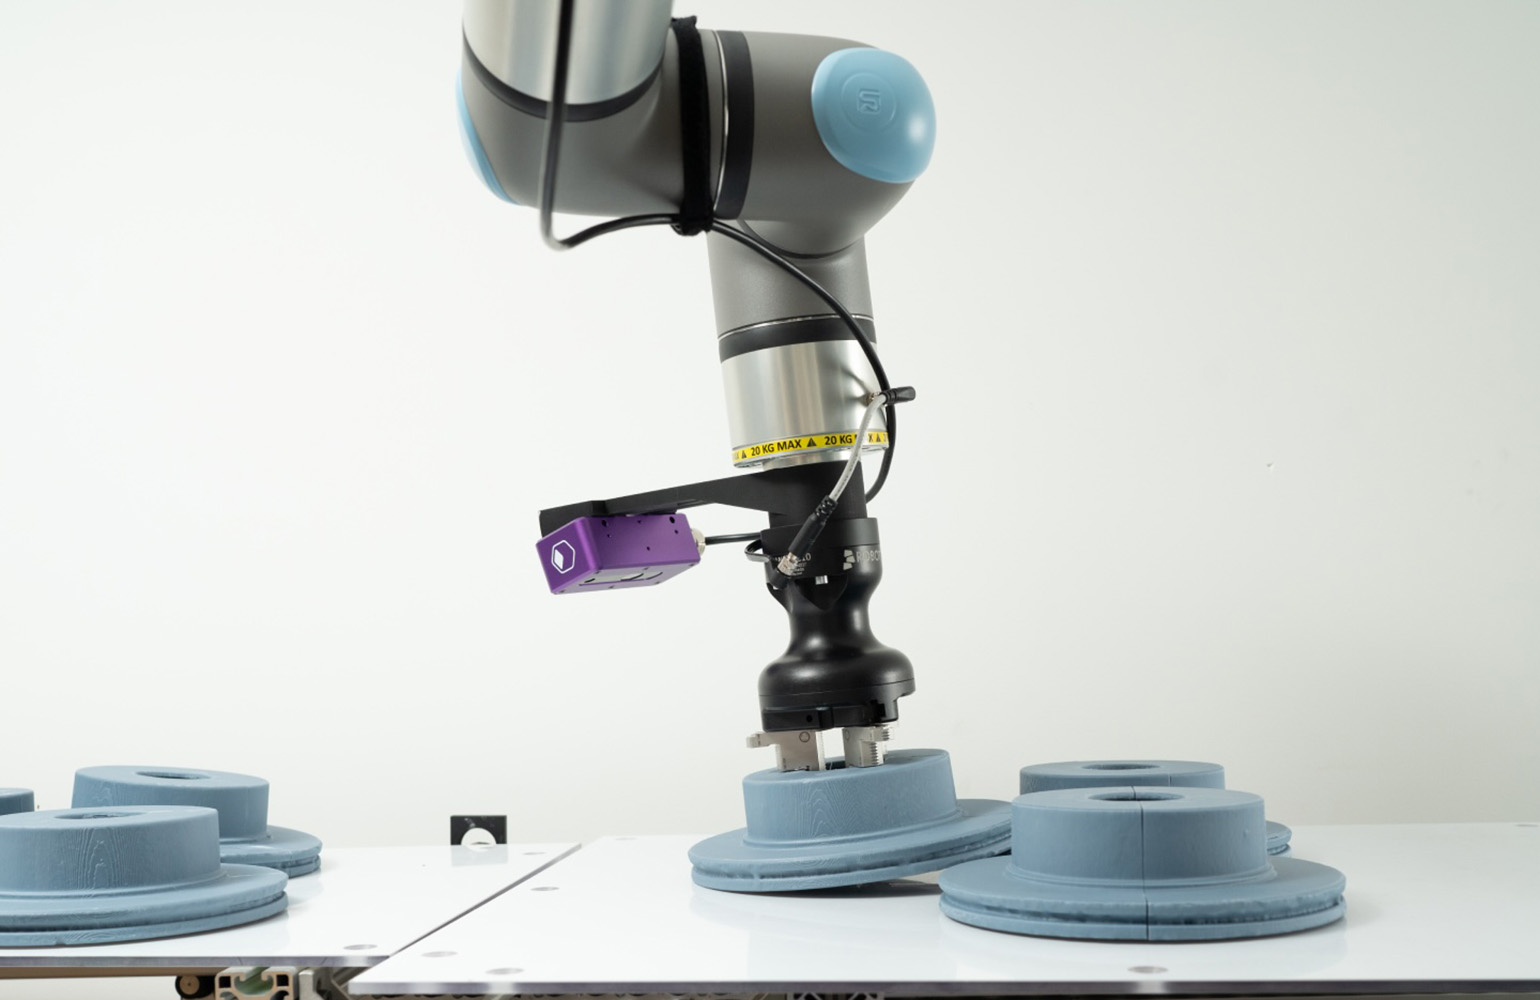
Inbolt to discuss physical AI’s deployment problem at RoboBusiness
Rudy Cohen, the co-founder and CEO of Inbolt, will reframe where physical AI pays off at RoboBusiness this fall. The post Inbolt to discuss physical AI’s …
APEX-RBD: Mixed-Precision Exploration Framework for Hardware-Efficient Robot Dynamics Accelerator Design
arXiv:2609.05161v1 Announce Type: cross Abstract: Rigid Body Dynamics (RBD) forms the computational core of real-time robotic control, but its immense computati…
NavArena: Automated Construction of Goal-Oriented Navigation Benchmarks from 3D Gaussian Splatting Reconstructions
arXiv:2609.04602v1 Announce Type: new Abstract: Fixed 3D Gaussian Splatting (3DGS) reconstructions provide realistic novel views but lack the traversability con…
ToPos: Automated Optimal Positioning on Topographic Manifolds using Constrained Geodesic Voronoi Decomposition
arXiv:2609.05084v1 Announce Type: new Abstract: Reliable autonomous mapping, environmental sampling, last-mile logistics, and infrastructure deployment depend o…
Where Appearance Fails, Geometry Recognizes: A CAD-Free 3D Shape Prior That Complements Vision Foundation Models
arXiv:2609.04381v1 Announce Type: cross Abstract: Recognizing specific objects onboarded without a labeled training set recurs across manufacturing and service …
LIBERO-RECOVER: Beyond Task Success Towards Failure Recovery in Robotic Manipulation Models
arXiv:2609.05178v1 Announce Type: new Abstract: Vision-Language-Action (VLA) or World Action (WAM) models have recently demonstrated remarkable performance in r…
AquaBEV: Monocular Underwater BEV Occupancy with 3D Sonar Supervision
arXiv:2609.04411v1 Announce Type: new Abstract: Autonomous underwater robots are widely used for exploration, monitoring, and inspection, where safe navigation …
Octopus Protocol: One-Shot Hardware Discovery and Control for AI Agents via Infrastructure-as-Prompts
arXiv:2605.09055v2 Announce Type: replace Abstract: Bringing a previously unintegrated device under the control of an AI agent still requires device-specific en…
Pack It My Way: Triadic Human-Robot Collaboration for Personalized Autonomous Packing
arXiv:2609.04620v1 Announce Type: new Abstract: Personalized autonomous packing requires robots to account for resident preferences that cannot be inferred from…
Continual Field-Adaptive Models (CFAMs) for Post-Deployment Physical AI
arXiv:2609.04552v1 Announce Type: new Abstract: Unattended interactive autonomy - machines that step into danger in place of humans and complete tasks with huma…
RedVLA: Physical Red Teaming for Vision-Language-Action Models
arXiv:2604.22591v2 Announce Type: replace Abstract: The real-world deployment of Vision-Language-Action (VLA) models remains limited by the risk of unpredictabl…
CoFreeVLA: Short-Horizon Collision-Free Dual-Arm Manipulation via Vision-Language-Action Model and Risk Estimation
arXiv:2601.21712v3 Announce Type: replace Abstract: Vision Language Action (VLA) models enable instruction-following manipulation, yet their deployment on coord…
Reasoning Without Inference Cost: Latent Semantic Scaffolding for Robot VLA Policies
arXiv:2609.04893v1 Announce Type: new Abstract: Vision-language-action (VLA) models are trained by imitation and capture what action to take but not why; adding…
FailureSpot: Label-Efficient Timestamp-Level Failure Detection for Vision-Language-Action Models
arXiv:2609.04277v1 Announce Type: new Abstract: Vision-language-action (VLA) policies have shown strong potential for general-purpose robotic manipulation, but …
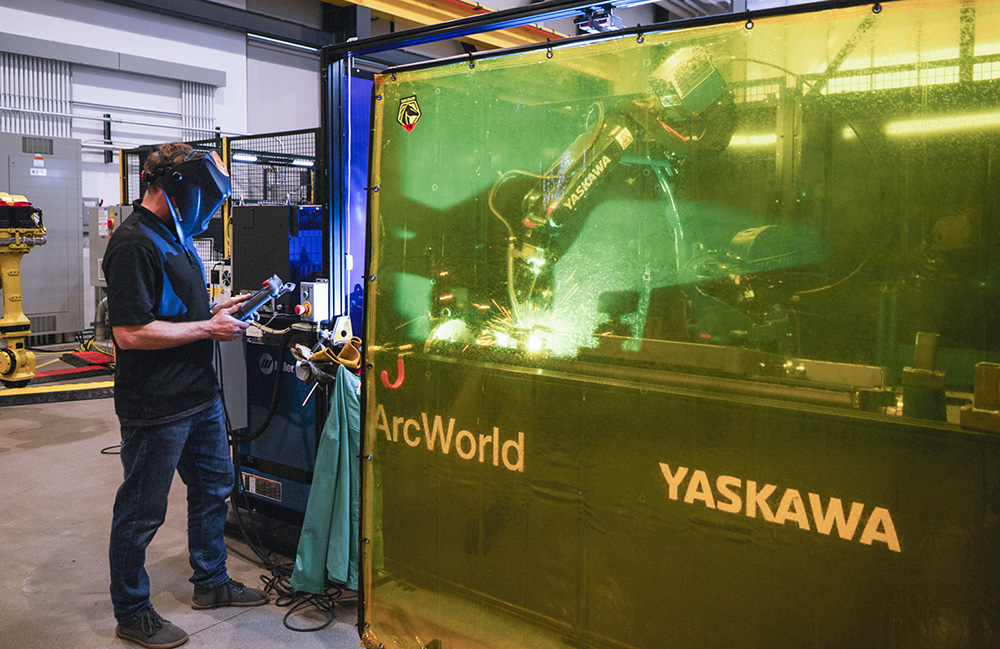
ARM Institute gets $90M for 10 projects to modernize military manufacturing
Fifteen member organizations will deliver viable working solutions within a two-year timeframe, the ARM Institute said. The post ARM Institute gets $90M for 10 …
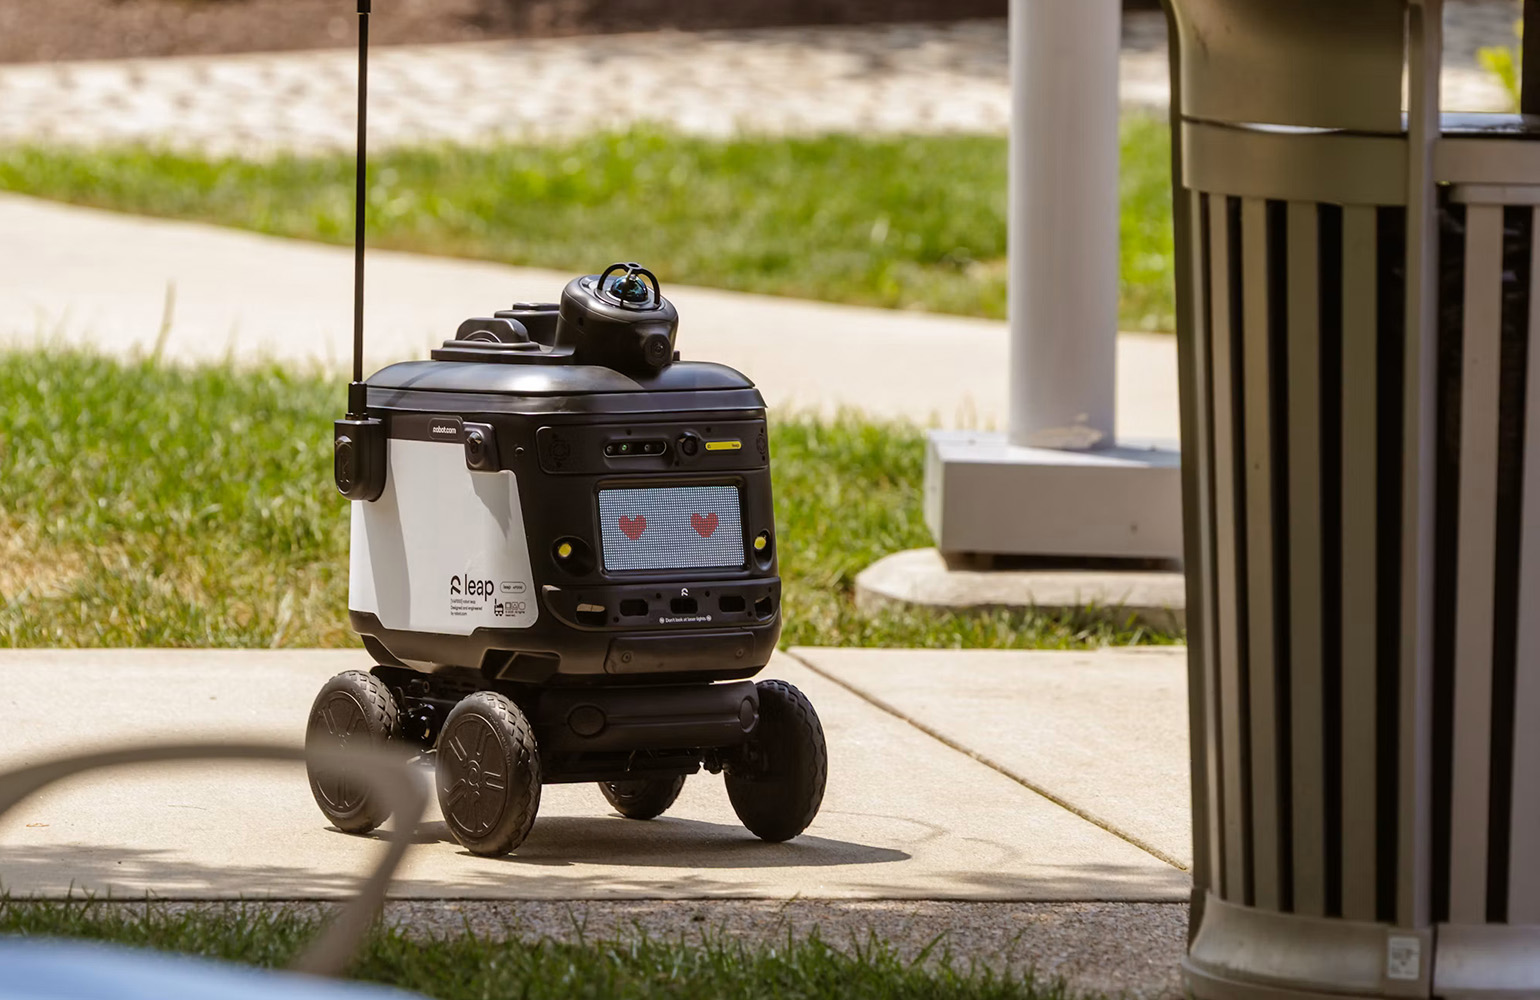
Robot.com partners with Sodexo to roll out more sidewalk delivery robots
Robot.com says college campuses will continue to be an important part of its strategy as it scales sidewalk delivery robots. The post Robot.com partners with So…
Programming and execution of skill-based human-robot-crane collaborative tasks
arXiv:2609.03392v1 Announce Type: new Abstract: Highly varying production sets increasing challenges for robotic manufacturing and indoor logistics. New capabil…
A comparative study on the accuracy & repeatability of mobile robotic platforms for the delivery of precision NDE measurement
arXiv:2609.03794v1 Announce Type: new Abstract: Mobile robotic platforms offer a flexible alternative to fixed manipulators for non-destructive evaluation (NDE)…
Understanding Autonomous Driving Datasets by Describing Differences between Image Subsets in Natural Language
arXiv:2609.03677v1 Announce Type: cross Abstract: Understanding the composition of large-scale autonomous driving datasets is essential for safety, robustness, …
Learning-based Adaptive Safety-Critical Control With Evolving Unsafe Regions
arXiv:2503.16551v4 Announce Type: replace Abstract: Control barrier functions (CBFs) provide a principled framework for safety-critical control, but their const…