Industry
Robots at work: warehouses, factories, farms, hospitals, construction sites and the automation reshaping them.
Robots at work: warehouses, factories, farms, hospitals, construction sites and the automation reshaping them.
Latest in Industry
903 storiesSafe Real-Time Policy Steering via Noise-Space Trajectory Optimization for One-Step Generative Policies
arXiv:2609.21220v1 Announce Type: new Abstract: Generative robot policies can represent diverse, multimodal behaviors, but adapting pretrained policies to deplo…
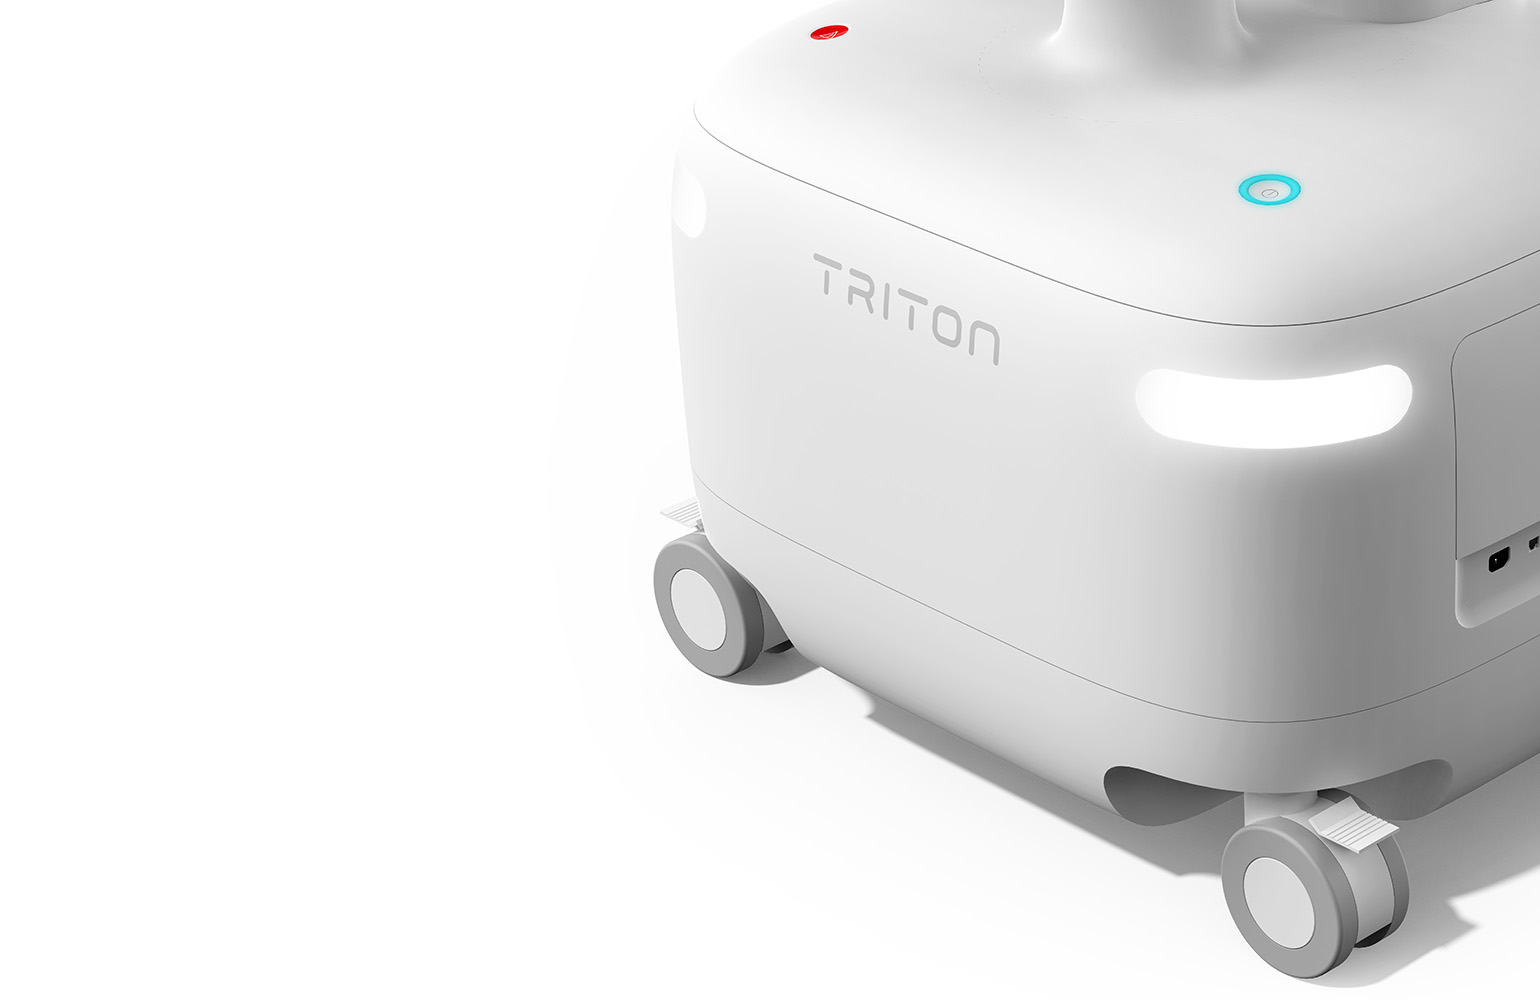
Neptune Medical earns FDA clearance for its Triton 1 robotic system
Neptune said Triton can elevate any endoscopist's capabilities for screening, surveillance, and diagnostic colonoscopies. The post Neptune Medical earns FDA cle…
DITTO: Dexterous Interface for Transparent TeleOperation
arXiv:2609.19196v1 Announce Type: new Abstract: Collecting data for manipulation with high-DOF hands is challenging, as interfaces must capture rich hand motion…
ULOHA: An Underwater Bimanual Robot System for Robot Learning
arXiv:2609.19200v1 Announce Type: new Abstract: Underwater visuomotor policy learning has focused primarily on single manipulators, while bimanual imitation lea…
Kinematics-Grounded Agentic AI for Robotic Additive Manufacturing Process Planning
arXiv:2609.19347v1 Announce Type: new Abstract: Robotic additive manufacturing (AM) extends material-extrusion printing beyond gantry kinematics but makes proce…
Predict Before You Deploy: Offline Prediction of Quantization-Induced Task Degradation for World Action Models
arXiv:2609.19441v1 Announce Type: new Abstract: World action models (WAMs) rely on video-generation backbones, requiring substantial memory and compute for depl…
Winning a Won Game: Strict Reach-Avoid-Stay Control Barrier Functions for High-Dimensional Black-Box Systems
arXiv:2609.19449v1 Announce Type: new Abstract: Robots must complete their tasks and maintain the achieved outcomes while avoiding safety failures at all times.…
GLAMDRING: Gait Learning And Morphology co-Design via Reinforcement LearnING of CPGs
arXiv:2609.19452v1 Announce Type: new Abstract: Robots are moving out of the structured factory floor and into unstructured environments such as disaster sites,…
FASA: Feedback-Aware Sampling Adaptation for Efficient Diffusion-Based VLA Models
arXiv:2609.19475v1 Announce Type: new Abstract: Diffusion-based Vision-Language-Action (VLA) models achieve strong performance in embodied tasks, but their iter…
OmniCalib: Target-Free, Task-Structured Self-Calibration for Humanoid Robots
arXiv:2609.19582v1 Announce Type: new Abstract: Assembly, wear, and component replacement perturb the sensor extrinsics and joint zeros encoded by a humanoid CA…
Towards High-DoF Dexterous Manipulation through VLA Post-Training
arXiv:2609.19666v1 Announce Type: new Abstract: Imitation-learned vision--language--action (VLA) foundation models acquire broad manipulation capabilities by sc…
LapaTrack-3D: 6 DoF pre-operative shape tracking for laparoscopic surgery
arXiv:2609.19954v1 Announce Type: new Abstract: This work proposes a real-time 6 Degree-of-Freedom (6 DoF) tracking algorithm for monocular laparoscopic surgery…
DR-MPC: Fast and Feasible Dynamics-Relaxed Model-Predictive Control for Legged Locomotion
arXiv:2609.20035v1 Announce Type: new Abstract: This paper presents dynamics-relaxed model predictive control (DR-MPC), a novel MPC formulation for legged locom…
Graph-Based Design of Soft Grippers with Multi-Objective Quality-Diversity Optimisation
arXiv:2609.20087v1 Announce Type: new Abstract: Effective manipulation across diverse objects is critical for applications ranging from agricultural harvesting …
AnyViewDex: View-Invariant Dexterous Manipulation from RGB Observations
arXiv:2609.20107v1 Announce Type: new Abstract: Visuomotor policies for multi-fingered dexterous manipulation are highly sensitive to camera viewpoint shifts. T…
Visual Sim-to-Real Learning for Robotic Insertion under Geometric Variations: Application to Rebar Installation
arXiv:2609.20477v1 Announce Type: new Abstract: Rebar insertion is among the most repetitive and physically demanding tasks on construction sites, and a contact…
Towards AI-enhanced control: a numerical technique for trajectory smoothing of a parallel robot for pancreatic surgery
arXiv:2609.20499v1 Announce Type: new Abstract: The paper presents a numerical approach for the end-effector trajectory smoothing of a parallel robot designed f…
Integrated Guidance and Control of a Mother-Child UAV-UGV System for Cooperative Missions
arXiv:2609.20540v1 Announce Type: new Abstract: Autonomous recovery of a small multirotor onto a hovering multirotor carrier differs from recovery onto ground o…
Learning Slope-Adaptive Whole-Body Locomotion for Humanoid Robots in Roofing Construction
arXiv:2609.20558v1 Announce Type: new Abstract: Roofing requires workers to coordinate locomotion, balance, and work-related body motions on pitched surfaces, c…
HIL-UMI: Bringing Human-in-the-Loop Post-Training of Vision-Language-Action Models to Universal Manipulation Interface
arXiv:2609.20659v1 Announce Type: new Abstract: Large-scale vision-language-action (VLA) models provide powerful priors for robot manipulation, yet adapting the…
OPTED: On-Policy Fine-Tuning for End-to-End Driving using a Render-Free Teacher
arXiv:2609.20756v1 Announce Type: new Abstract: As scaling pre-training data alone yields diminishing returns, post-training is becoming increasingly important …
Agile-WAM: An Agile Tactile World Action Model for Contact-Rich Robot Control
arXiv:2609.20761v1 Announce Type: new Abstract: World Action Models (WAMs) advance beyond conventional visuomotor policies by jointly predicting future world st…
"Your Robot Was Trained on a Lie": Collision Mesh Poisoning Attacks on Robotic Manipulation
arXiv:2609.18122v1 Announce Type: cross Abstract: Learning-enabled robotic manipulation increasingly relies on robot simulators for policy training and evaluati…
INSPECT: Learning Robot View Selection from Assistant Use
arXiv:2609.20615v1 Announce Type: new Abstract: Robots inspecting an assembly must determine which parts are present and whether they are correctly installed. D…
CALOS: Control-Affine Lyapunov On-manifold Safety Layer for Safe Deep Reinforcement Learning for Quadrotors
arXiv:2609.17758v1 Announce Type: new Abstract: Deep Reinforcement Learning has demonstrated remarkable capability in quadrotor control, yet learned policies of…
Not All Layers Need Tuning: Diagnosing and Directing Adaptation in Vision-Language-Action Models
arXiv:2609.18084v1 Announce Type: new Abstract: Fine-tuning a Vision-Language-Action (VLA) model for a new deployment environment is expensive, yet most methods…
Reinforcement Learning for Real-Time Vision-Language-Action Policies
arXiv:2609.18207v1 Announce Type: new Abstract: Reinforcement learning fine-tuning on top of large, pretrained Vision-Language-Action (VLA) models offers promis…
SurgRAW: Multi-Agent Workflow with Chain of Thought Reasoning for Robotic Surgical Video Analysis
arXiv:2503.10265v3 Announce Type: replace-cross Abstract: Robotic-assisted surgery (RAS) is central to modern surgery, driving the need for intelligent systems …
OmniPlanner: Universal Exploration and Inspection Path Planning Across Robot Morphologies
arXiv:2603.04284v2 Announce Type: replace Abstract: Autonomous robotic systems are increasingly deployed for mapping, monitoring, and inspection in complex and …
In-Context Robot Learning with VLM Agents
arXiv:2609.19138v1 Announce Type: cross Abstract: Enabling robots to adapt to unfamiliar environments as readily as humans remains a moonshot goal of embodied A…