Research
Frontier robotics research: arXiv cs.RO papers, embodied AI, VLA models, manipulation, navigation and learning systems.
Frontier robotics research: arXiv cs.RO papers, embodied AI, VLA models, manipulation, navigation and learning systems.
Latest in Research
6273 storiesTacForcing: Streaming Action Generation with Execution-Time Tactile Feedback
arXiv:2608.25798v1 Announce Type: new Abstract: Contact-rich manipulation requires adapting to contact states that can evolve substantially within an action hor…
LM-X: Explainable Action Modeling with Progress, Event, and Uncertainty Prediction for Generalist Robot Manipulation
arXiv:2608.25757v1 Announce Type: new Abstract: Generalist vision--language--action (VLA) policies learn long-horizon behavior mainly through short-horizon acti…
PRISM: Projection-Integrated Sampling-Based MPC with Bayesian Cost Tuning for Bimanual Manipulation
arXiv:2608.25666v1 Announce Type: new Abstract: Bimanual manipulation in cluttered, contact-rich environments remains challenging because it requires coordinate…
GaussianDream++: Efficient 3D Gaussian World Modeling for Robotic Manipulation
arXiv:2608.25659v1 Announce Type: new Abstract: Vision-Language-Action (VLA) policies have advanced language-conditioned robotic manipulation, yet action-imitat…
RA-VLA: Retrieval-Augmented VLA for Test-Time Adaptation
arXiv:2608.25585v1 Announce Type: new Abstract: Vision-Language-Action (VLA) models provide a versatile foundation for general robotic manipulation, yet they ex…
Transient multimode heat transfer of an industrial automated tape laying process under rapidly changing conditions
arXiv:2608.25470v1 Announce Type: new Abstract: This work presents a transient heat-transfer model of an industrial automated tape laying (ATL) process designed…
A Taxonomy of Construction Task Activities for Robot Workers
arXiv:2608.25395v1 Announce Type: new Abstract: Recent vision-language-action models offer a path toward robots with broader repertoires than conventional task-…
RAEM: Robust Autonomous Exploration for Multi-Floor Environments with a Quadruped Robot
arXiv:2608.25366v1 Announce Type: new Abstract: In this paper, we propose RAEM, a robust autonomous exploration framework for quadruped robots operating in mult…
Development of a Voice-Controlled Tendon-Driven Bionic Hand
arXiv:2608.25222v1 Announce Type: new Abstract: The impairment of the hands can seriously affect the abilities of every individual to perform the every-day acti…
ROS2 Connect: A new ROS2 over WAN Solution
arXiv:2608.25102v1 Announce Type: new Abstract: The Robot Operating System 2 (ROS2) has become a widely adopted framework for the development of distributed rob…
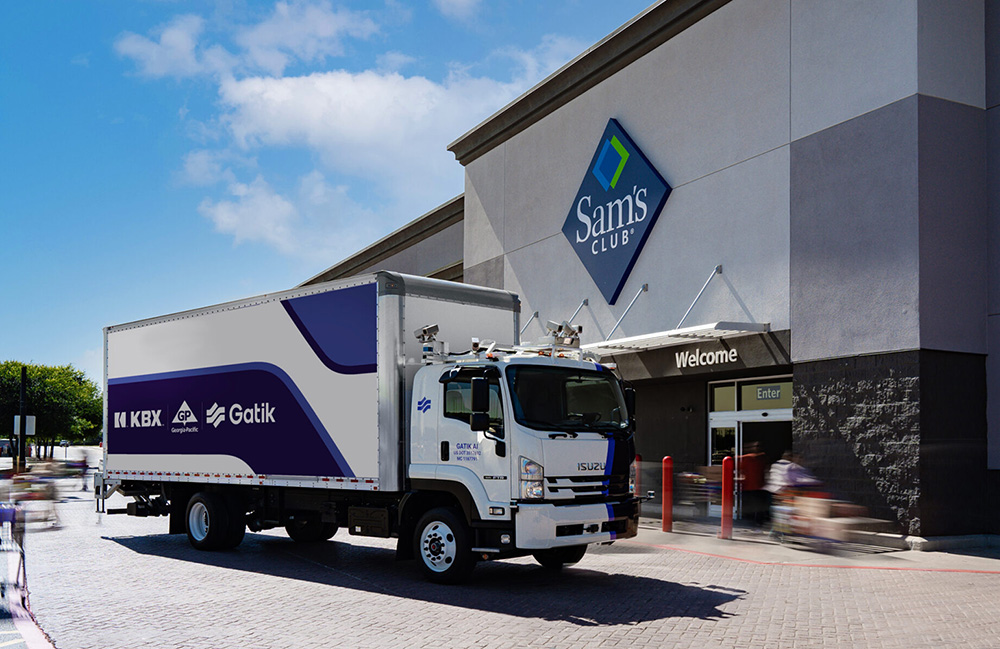
Gatik brings in $200M to continue expanding autonomous trucking operations
Gatik said the funding will help it expand its model built around high-frequency regional routes connecting distribution centers and stores. The post Gatik brin…
CARE: Camera-Residual Reserves for First Sightings in Adaptive LiDAR Sensing
arXiv:2608.24282v1 Announce Type: cross Abstract: Adaptive LiDAR scanning concentrates a limited sensing budget on regions of interest predicted from past objec…
A study on the effects of mixed explicit and implicit communications in human-artificial-agent interactions
arXiv:2409.18745v5 Announce Type: replace Abstract: Communication between humans and artificial agents is essential for their interaction. This is often inspire…
VGGT-DP: Generalizable Robot Control via Vision Foundation Models
arXiv:2509.18778v2 Announce Type: replace Abstract: Visual imitation learning frameworks allow robots to learn manipulation skills from expert demonstrations. W…
A Robust Task-Level Control Architecture for Learned Dynamical Systems
arXiv:2511.09790v2 Announce Type: replace Abstract: Dynamical system (DS)-based learning from demonstration (LfD) is a powerful tool for generating motion plans…
E2HiL: Entropy-Guided Sample Selection for Efficient Real-World Human-in-the-Loop Reinforcement Learning
arXiv:2601.19969v2 Announce Type: replace Abstract: Human-in-the-loop guidance has emerged as an effective approach for accelerating online reinforcement learni…
Enhancing RL Generalizability in Robotics through SHAP Analysis of Algorithms and Hyperparameters
arXiv:2605.02867v3 Announce Type: replace-cross Abstract: Despite significant advances in Reinforcement Learning (RL), model performance remains highly sensitiv…
IMAC-AgriVLN: Can Agricultural Vision-and-Language Navigation Agents be Aware of Instruction Mistakes?
arXiv:2606.02519v3 Announce Type: replace Abstract: Agricultural robots are playing as important roles across a wide range of tasks, nevertheless, they are stil…
From Dialogue to Execution: Mixture-of-Agents Assisted Interactive Planning for Behavior Tree-Based Long-Horizon Robot Execution
arXiv:2603.01113v2 Announce Type: replace Abstract: Interactive task planning with large language models (LLMs) lets robots generate high-level action plans fro…
Analytical Covariance Propagation for DVL-Aided Loosely Coupled SINS Under Attitude Uncertainty
arXiv:2601.19509v2 Announce Type: replace Abstract: In loosely coupled strapdown inertial navigation system/Doppler velocity log (SINS/DVL) integration, the bod…
AURASeg: Attention-Guided Upsampling with Residual-Assisted Boundary Refinement for Drivable-Area Segmentation
arXiv:2510.21536v5 Announce Type: replace Abstract: Free-space segmentation is essential for autonomous robots to identify drivable regions and navigate safely …
Do Robotic World Models Really Follow Actions? Diagnosing and Aligning Action-Conditioned Generation for Policy Learning
arXiv:2608.24885v1 Announce Type: new Abstract: Action-conditioned world models are increasingly used as learned simulators for policy evaluation and improvemen…
Latent Action as Intention Enables Efficient Future Imagination for World Action Models
arXiv:2608.24882v1 Announce Type: new Abstract: World action models (WAMs) improve robot control by modeling how observations evolve, but generating future obse…
One-Shot Learning from Demonstration of Contact-Rich Robotic Manipulation by Identifying Physical Interactions
arXiv:2608.24741v1 Announce Type: new Abstract: Learning from Demonstration (LfD) allows robots to learn manipulation tasks directly from humans, thereby suppor…
Fiber Optic Sensing Glove for High Performance Dexterous Manipulation Capture
arXiv:2608.24572v1 Announce Type: new Abstract: Capturing hand pose during dexterous manipulation remains difficult: vision-based methods degrade under occlusio…
NeuralParker: A Reinforcement Learning Planner for Irregular Parking Environments
arXiv:2608.24485v1 Announce Type: new Abstract: Automated parking commonly assumes marked slots and short approach maneuvers. Delivery and service vehicles, how…
NVIDIA Cosmos-H-Dreams: Real-Time Generative Physics Simulation for Surgical Robotics
arXiv:2608.24199v1 Announce Type: new Abstract: Generative simulation for surgical robotics still lacks real-time interaction. Physical-robot experiments, often…
Coverage Planning for Robotic Tooth Preparation in Densely Constrained Environments
arXiv:2608.24155v1 Announce Type: new Abstract: Tooth preparation refers to the controlled removal of tooth structure to create an optimal substrate for fixed r…
PonderPounce: A Pretrained MLLM as an Episode Context Engine for Robot Control
arXiv:2608.24115v1 Announce Type: new Abstract: Multimodal large language models (MLLMs) can integrate long visual histories, reason under partial observability…
SIREN-Bench: Behavior-Driven Generation and Evaluation of Emergency-Vehicle Interactions
arXiv:2608.24094v1 Announce Type: new Abstract: Emergency vehicles (EMVs) can reorganize surrounding traffic as civilian vehicles brake, change lanes, or form r…