News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4147 storiesTADPO: Reinforcement Learning Goes Off-road
arXiv:2603.05995v2 Announce Type: replace Abstract: Off-road autonomous driving poses significant challenges such as navigating unmapped, variable terrain with …
Practical Judgment, Virtue, and Intuition in the Use of Opaque AI-Enabled Systems
arXiv:2607.12755v1 Announce Type: cross Abstract: AI-enabled systems are seeing increasing deployment across numerous domains, with many being "black boxes" wit…
Model-Based Diffusion Optimal Control for Multi-Robot Motion Planning
arXiv:2607.12423v1 Announce Type: new Abstract: Multi-Robot Motion Planning in continuous environments, where robots must generate dynamically feasible, collisi…
Contract-Grounded Behavior Tree Synthesis via Coding Agents
arXiv:2607.12220v1 Announce Type: new Abstract: Synthesizing deployable robot behavior trees (BTs) from natural language (NL) requires grounding to ensure every…
UR-VC: Unsupervised Robotic Value Correction for Time-Derived Progress Proxies
arXiv:2607.12892v1 Announce Type: new Abstract: Modern robot learning systems increasingly rely on dense progress or value signals to evaluate intermediate stat…
EFLUX: Elastic Multi-Robot Formation Navigation and Adaptation with Agentic LLMs
arXiv:2607.12050v1 Announce Type: new Abstract: Multi-robot teams operating in confined or cluttered environments must adapt both their formation geometry and g…
Unveiling Complex Collective Behaviors from Simple Rewards
arXiv:2607.12861v1 Announce Type: new Abstract: Multi-agent Reinforcement Learning (MARL) holds great potential for robot swarms, but the black-box nature of ne…
More than a Manipulator: Planning Propellant-Free Attitude Maneuvers for Free-Floating Spacecraft
arXiv:2607.12130v1 Announce Type: new Abstract: Spacecraft attitude control is traditionally achieved using momentum exchange devices or propellant-consuming th…
Globalized Constrained Stein Variational Inference for Diverse Feasible Robot Motion Planning
arXiv:2607.12732v1 Announce Type: new Abstract: Robot motion planning is inherently multimodal, yet classical planners typically return only a single solution. …
VistaVLA: Geometry- and Semantic-Aware 3D Gaussian-Grounded VLA for Robotic Manipulation
arXiv:2607.12356v1 Announce Type: new Abstract: Vision-Language-Action (VLA) models have emerged as a powerful end-to-end paradigm for robotic manipulation by m…
APPLV: Adaptive Planner Parameter Learning from Vision-Language-Action Model
arXiv:2603.08862v2 Announce Type: replace Abstract: Autonomous navigation in highly constrained environments remains challenging for mobile robots. Classical na…
MAMMOTH: A Multi-Modal End-to-End Policy for Off-Road Mobility Robust to Missing Modality
arXiv:2607.12965v1 Announce Type: new Abstract: Reliable autonomous navigation in unstructured off-road environments remains a critical unsolved challenge due t…
Infra-Swarm: Robust Vision-Based Multi-Robot Swarming via Near-Infrared Spectral Vision
arXiv:2607.12489v1 Announce Type: new Abstract: Distributed swarms typically rely on either active wireless communication or passive vision, and they are freque…
RoboDesign1M: A Large-scale Dataset for Robot Design Understanding
arXiv:2503.06796v2 Announce Type: replace Abstract: Robot design is a complex and time-consuming process that requires specialized expertise. Gaining a deeper u…
LapSurgie: Humanoid Robots Performing Surgery via Teleoperated Handheld Laparoscopy
arXiv:2510.03529v3 Announce Type: replace Abstract: Robotic laparoscopic surgery has gained increasing attention in recent years for its potential to deliver mo…
Directional Constraints for Efficient Exploration in Safe Reinforcement Learning
arXiv:2607.12784v1 Announce Type: new Abstract: Reinforcement Learning has revolutionized the landscape of robotic research, allowing robust learning of complex…
LEGO-SLAM: Language-Embedded Gaussian Optimization SLAM
arXiv:2511.16144v2 Announce Type: replace-cross Abstract: Recent advances in 3D Gaussian Splatting (3DGS) have enabled Simultaneous Localization and Mapping (SL…
StratMamba: Strategic and Reactive Stream Partitioning for Path-Efficient LiDAR-Based Obstacle Avoidance
arXiv:2607.12370v1 Announce Type: new Abstract: This paper proposes StratMamba, a dual-stream Mamba-based temporal modeling architecture, to more efficiently ca…
Improving Autonomous Nano-drones Performance via Automated End-to-End Optimization and Deployment of DNNs
arXiv:2607.12593v1 Announce Type: cross Abstract: The evolution of energy-efficient ultra-low-power (ULP) parallel processors and the diffusion of convolutional…
Vision-Based Dribbling for Humanoid Soccer via Privileged Representation Learning
arXiv:2607.12702v1 Announce Type: new Abstract: Recent advances in humanoid robotics have highlighted the importance of deployable loco-manipulation skills. Dri…
Reducing Temporal Redundancy for Efficient Vision-Language-Action Inference
arXiv:2607.12287v1 Announce Type: new Abstract: Vision-Language-Action (VLA) models exhibit strong generalization for robotic manipulation, yet their high infer…
Analysis of Mutual and Referential Human and Robot Gazes in a Collaborative Word Association Game
arXiv:2607.12181v1 Announce Type: new Abstract: Robot gaze is a major component of human-robot dialogue coordination. Most studies of gaze in human-robot dialog…
Expert Knowledge-driven Reinforcement Learning for Autonomous Racing via Trajectory Guidance and Dynamics Constraints
arXiv:2603.05842v2 Announce Type: replace Abstract: Reinforcement learning has demonstrated significant potential in the field of autonomous driving. However, i…
Autonomous Tracking and Terminal Guidance of Moving Targets for Fixed-Wing UAVs
arXiv:2607.12801v1 Announce Type: new Abstract: This study introduces a unified control framework for fixed-wing unmanned aerial vehicles (UAVs) fitted with a p…
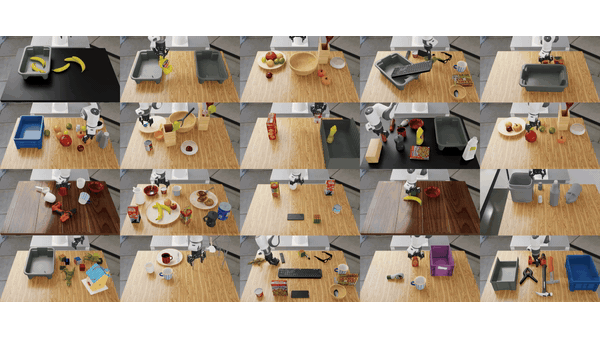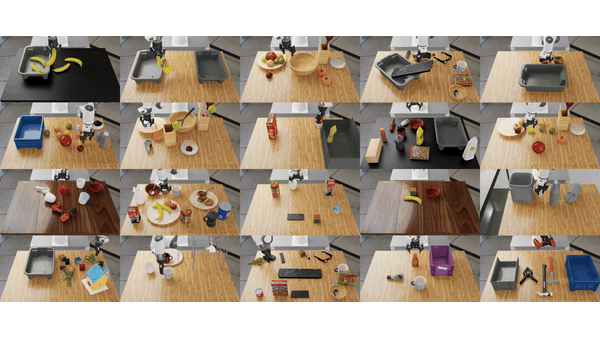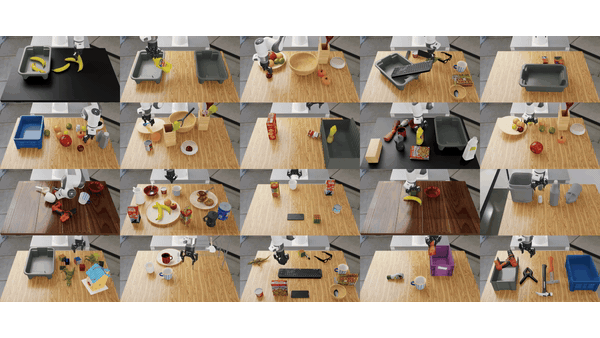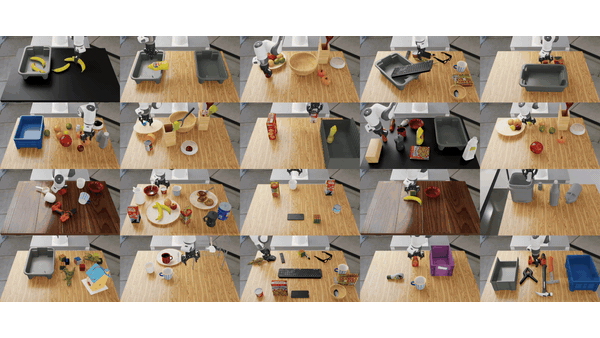
NVIDIA shares how to evaluate general-purpose robot policies for real-world deployment
RoboLab research powers NVIDIA Isaac Lab-Arena, an open-source simulation framework for large-scale policy setup and evaluation. The post NVIDIA shares how to e…
Key to Humanoid Progress: Managing the Power Behind the Robots
Murata Power Solutions' John Quinlan on how advanced robotics converts, distributes and controls on-board power from battery to actuator. The post Key to Humano…
Task Parameter Extrapolation via Learning Inverse Tasks from Forward Demonstrations
arXiv:2603.05576v3 Announce Type: replace Abstract: Generalizing skill policies to novel conditions remains a key challenge in robot learning. Imitation learnin…
Minimizing Worst-Case Weighted Latency for Multi-Robot Persistent Monitoring: Theory and RL-Based Solutions
arXiv:2605.09633v2 Announce Type: replace Abstract: We study multi-robot persistent monitoring on weighted graphs, where node weights encode monitoring prioriti…
The Individual-Targeting Assumption: A Systematic Review of Proactive Robots in Human Group Settings
arXiv:2607.09734v1 Announce Type: cross Abstract: Proactive robots are increasingly deployed in public environments where people are encountered not as isolated…
A Comprehensive Survey and Systematic Real-World Evaluation of Embodied Vision-and-Language Navigation
arXiv:2607.09792v1 Announce Type: new Abstract: Navigation is a fundamental capability of autonomous systems, yet most existing approaches rely on highly struct…