News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4147 storiesKepler-Encoder-v0.1: Towards a Multimodal Embedding Model for Robots
arXiv:2607.13522v1 Announce Type: new Abstract: A robot must understand the state of its own body, but a camera sees only part of it. Force and contact leave al…
WNOJ-LIO: A White-Noise-on-Jerk Motion-Prior EKF for High-Dynamic LiDAR-IMU Fusion
arXiv:2607.13405v1 Announce Type: new Abstract: LiDAR-inertial odometry (LIO) is a key component of autonomous navigation, but high-dynamic driving exposes two …
STITCHER: Constrained Trajectory Planning in Complex Environments with Real-Time Motion Primitive Search
arXiv:2510.14893v4 Announce Type: replace Abstract: Autonomous high-speed navigation through large, complex environments requires real-time generation of agile …
Generalizable VLA Finetuning via Representation Anchoring and Language-Action Alignment
arXiv:2607.13429v1 Announce Type: new Abstract: Finetuning a pretrained vision-language model (VLM) on robot demonstrations via behavior cloning (BC) has become…
Active Trust Management for Successful Human-Robot Teaming: Moving from a Trust Repair to a Trust Satisficing Perspective
arXiv:2607.13595v1 Announce Type: new Abstract: Integrating mobile robots into human teams promises significant capability improvements for tasks such as search…
Simulation-based planning of Motion Sequences for Automated Procedure Optimization in Multi-Robot Assembly Cells
arXiv:2507.23270v3 Announce Type: replace Abstract: Reconfigurable multi-robot cells offer a promising approach to meet fluctuating assembly demands. However, t…
PC-Diffuser: Path-Consistent Capsule CBF Safety Filtering for Diffusion-Based Trajectory Planner
arXiv:2603.10330v2 Announce Type: replace Abstract: Autonomous driving in complex traffic requires planners that generalize beyond hand-crafted rules, motivatin…
Safe Overtaking for Autonomous Racing Using Hierarchical Optimization and Learning-Based Control
arXiv:2607.13348v1 Announce Type: new Abstract: Autonomous racing overtaking requires balancing competitive performance with safety under nonlinear vehicle dyna…
An Empirical Study on Stage-Information Interfaces for VLA Fine-Tuning
arXiv:2607.13605v1 Announce Type: new Abstract: One high-level instruction in long-horizon manipulation can cover several action stages. We use segmented action…
The Nonsmooth Impact Direction (NSID) of Robotic Systems
arXiv:2607.13768v1 Announce Type: new Abstract: Collisions of rigid-link robots and rigid environments are often modeled as instantaneous events. Under this ide…
SPINE: Bridging the Cyber-Physical Gap with Agentic AI
arXiv:2607.13049v1 Announce Type: cross Abstract: Foundation models have given robots a sophisticated brain for complex decision-making, yet deploying that inte…
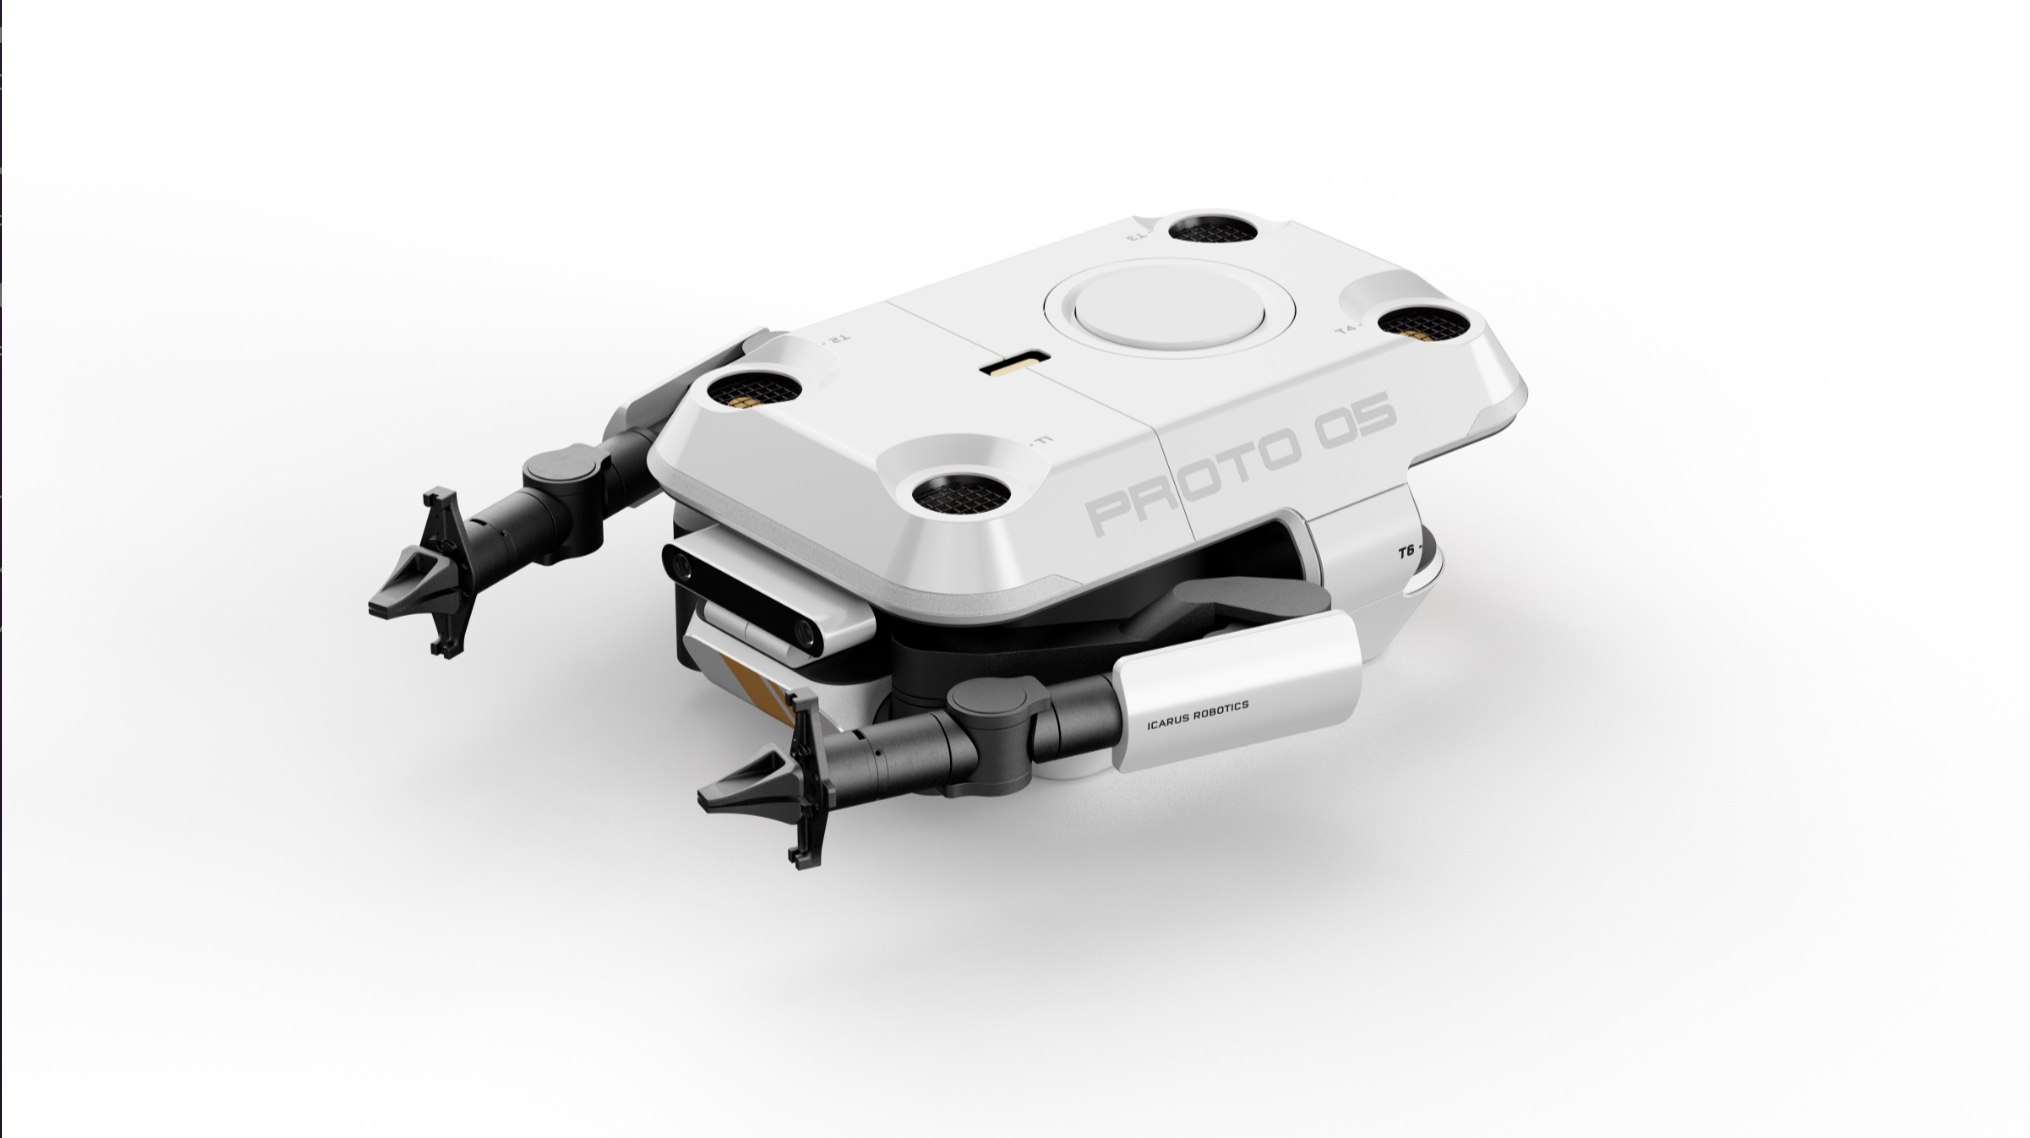
Icarus Robotics uses KULR technology to power JOY free-flying space robot
Under the agreement, KULR will supply its KULR ONE Space battery systems to power JOY’s onboard systems on the ISS. The post Icarus Robotics uses KULR technolog…

Vicarious Surgical board seeks to dissolve company
The board is asking shareholders to approve their plan to dissolve and liquidate the business at a special meeting scheduled for July 21, but said it can not pr…

Agility outlines six recommendations for U.S. humanoid robot policies
Peggy Johnson, CEO of Agility, said the U.S. needs a policy framework that can strengthen what’s already working for the humanoid industry. The post Agility out…

Walden Robotics launches at $1.1B valuation for general-purpose robots
Leading technology companies have invested in Walden Robotics, which emerged from stealth as it develops full-stack physical AI. The post Walden Robotics launch…
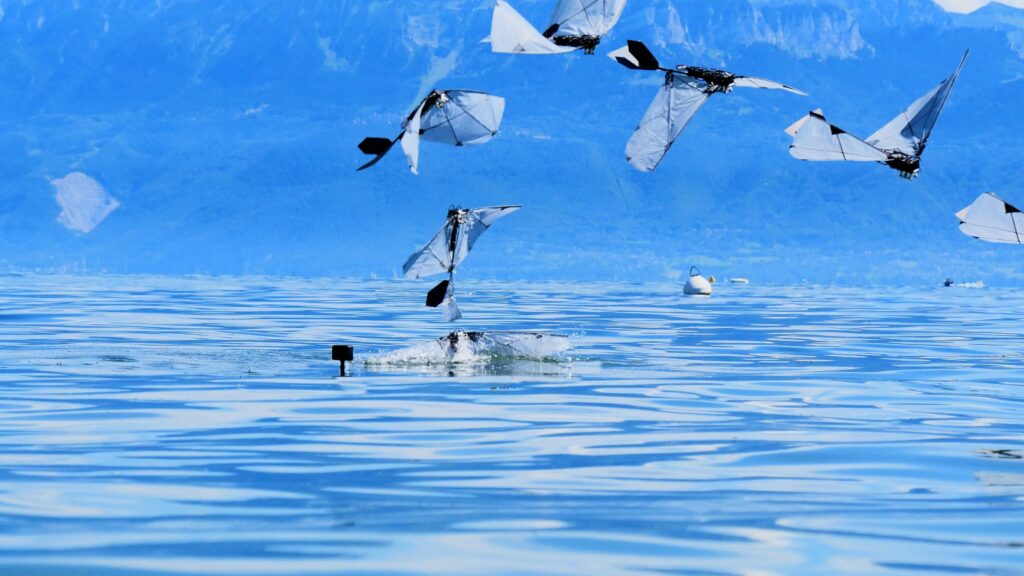
A flapping robot swims and flies like a diving bird
Image copyright: Raphael Zufferey. By Jennifer Chu Loons, gulls, puffins, and petrels are some of the 100 species of birds that can both fly and swim. These div…
ABot-AgentOS: A General Robotic Agent OS with Lifelong Multi-modal Memory
arXiv:2607.10350v1 Announce Type: cross Abstract: Recent VLM and VLA systems have improved robotic perception and action prediction, yet long-horizon embodied a…
Streamlining stereo differentiable rendering for marker-free real-time tracking of surgical robots
arXiv:2607.12604v1 Announce Type: new Abstract: Purpose: Marker-based tracking of surgical robots is occlusion-prone in cluttered operating rooms. We evaluate s…
DenseReward: Dense Reward Learning via Failure Synthesis for Robotic Manipulation
arXiv:2607.13033v1 Announce Type: new Abstract: Reinforcement learning holds great promise for improving robot policies beyond the limits of imitation learning.…
TrustVLA: Mechanism-Guided Inference-Time Defense Against Vision-Language-Action Backdoors
arXiv:2607.12571v1 Announce Type: new Abstract: Vision-Language-Action (VLA) models are deployed through pipelines that end users cannot audit, and a poisoned V…
Deployable Human Preference Alignment in Robotics: Learning Representative Rewards from Diverse Human Preferences
arXiv:2607.12466v1 Announce Type: new Abstract: Aligning robot policies with human preferences is essential for deployment to diverse end users. In per-user ali…
Jetson-PI: Towards Onboard Real-Time Robot Control via Foresight-Aligned Asynchronous Inference
arXiv:2607.12659v1 Announce Type: new Abstract: Vision-Language-Action (VLA) models have achieved impressive performance on diverse embodied tasks. However, dep…
TerraZero: Procedural Driving Simulation for Zero-Demonstration Self-Play at Scale
arXiv:2607.13028v1 Announce Type: cross Abstract: Training robust autonomous driving agents requires a simulator that is fast enough for reinforcement learning …
SANTS: A State-Adaptive Scheduler for World Action Models
arXiv:2605.27947v2 Announce Type: replace Abstract: World Action Models (WAMs) improve robot manipulation by using video-based future representations to conditi…
Mosaic: An Extensible Framework for Composing Rule-Based and Learned Motion Planners
arXiv:2604.13853v2 Announce Type: replace Abstract: Safe and explainable motion planning remains a central challenge in autonomous driving. While rule-based pla…
Enabling 24-hour Agricultural Robotics: Unsupervised Day-to-Night Cross-Modal Image Translation for Nighttime Visual Navigation
arXiv:2607.12065v1 Announce Type: new Abstract: While visual navigation has been extensively studied in agricultural robotics, most existing systems assume dayt…
GaitSpan: Growing Humanoid Locomotion from Walking to Running
arXiv:2607.12114v1 Announce Type: new Abstract: A humanoid that can walk should not relearn locomotion from scratch to jog or run. Yet current approaches often …
Robot Drummer: Learning Rhythmic Skills for Humanoid Drumming
arXiv:2507.11498v3 Announce Type: replace Abstract: Humanoid robots have seen remarkable advances in dexterity, balance, and locomotion, yet their role in expre…
Real-Time Model Checking for Closed-Loop Robot Reactive Planning
arXiv:2508.19186v2 Announce Type: replace Abstract: Reactive obstacle avoidance methods often cause agents to become trapped in local minima, because they can o…
Look, Focus, Act: Efficient and Robust Robot Learning via Human Gaze and Foveated Vision Transformers
arXiv:2507.15833v3 Announce Type: replace Abstract: Human vision is a highly active process driven by gaze, which directs attention to task-relevant regions thr…