News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4146 storiesToward Self-Repairing Ubiquitous Robots Using Goal-Oriented Agentic AI in Human-Robot Interactions
arXiv:2609.26155v1 Announce Type: new Abstract: Ubiquitous robotic systems often lack traditional visual interfaces, making natural language interaction importa…
Teaching Reinforcement Learning and Humanoid Robotics to High-School Students: An Expert-Validated Curriculum Design on a Low-Cost Open Platform
arXiv:2609.25674v1 Announce Type: new Abstract: Lower cost open source robots and reinforcement learning (RL) simulation tools create new opportunities for prec…
MotionForge: A Data Generation Pipeline and Large-Scale Benchmark for Long-Horizon Manipulation of Dynamic Objects with Domain Shifts
arXiv:2609.25689v1 Announce Type: new Abstract: Recent advances in learning-based robot policies have demonstrated promising progress, yet they are predom- inan…
Induced Riemannian Metrics for Motion Planning with Constraints
arXiv:2609.25695v1 Announce Type: new Abstract: In constrained motion planning problems, task and loop-closure constraints restrict a robot's motion to a curved…
The Cartesian Hand: In-Hand Manipulation with All-Linear Fingers
arXiv:2609.25696v1 Announce Type: new Abstract: Robotic manipulation has increasingly pursued human-like dexterous hands with many articulated degrees of freedo…
PLAT: Sparse Timed Keyframe Motion Tracking for Humanoid Control via Privileged Latent Transition Learning
arXiv:2609.25754v1 Announce Type: new Abstract: Humanoid motion tracking policies rely on dense frame-by-frame references, limiting their use as high-level moti…
MedVLA: A Hierarchical Vision-Language-Action Framework for Closed-Loop Precision Medical Robot Manipulation
arXiv:2609.25756v1 Announce Type: new Abstract: Precision medical robotics demands adaptive decision-making under strict safety, interpretability, and execution…
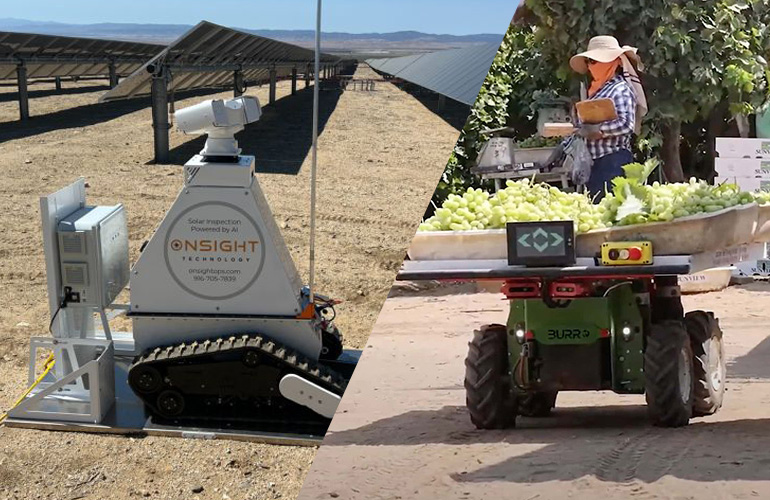
Why outdoor robots fail (and how to build systems that survive)
Learn practical strategies for building reliable outdoor robots from WiBotic, Burro, and Nextpower at RoboBusiness in Silicon Valley. The post Why outdoor robot…
Intel to discuss the infrastructure needed to scale physical AI at RoboBusiness
Intel's Nagesh Puppala will discuss why the next phase of robotics innovation depends on more than bigger models or better simulations. The post Intel to discus…
Isaac ROS 5.0 brings AI agents to robotics development, says NVIDIA
The release brings new agentic workflows and platform support to NVIDIA Isaac ROS to help developers deploy robotics applications faster. The post Isaac ROS 5.0…
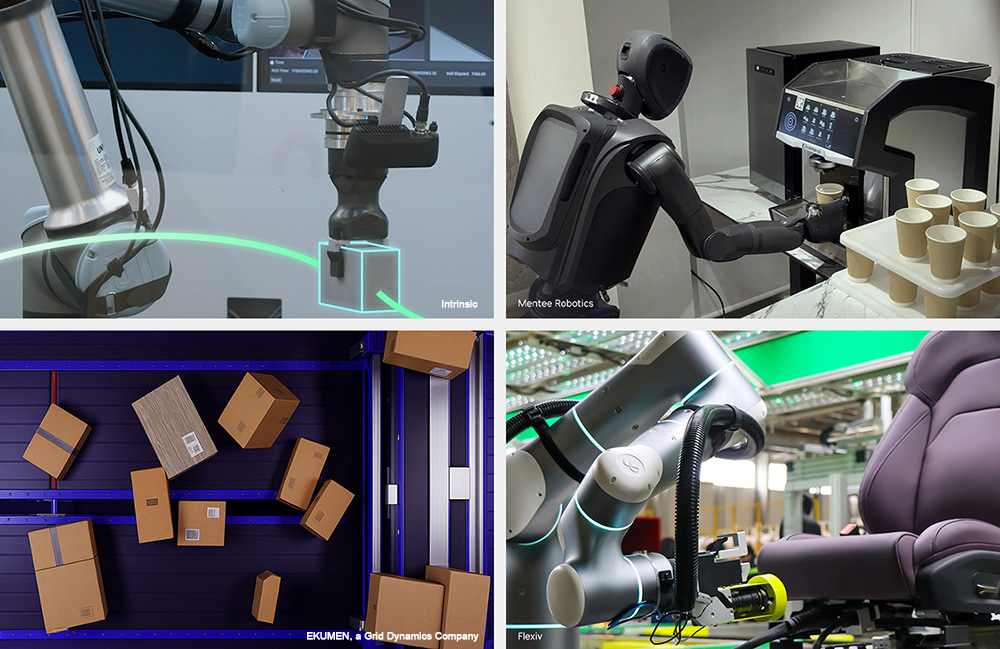
Intrinsic open sources key parts of its platform for easier development
With Intrinsic Core, the company is making key parts of its manipulation platform available to robotics developers. The post Intrinsic open sources key parts of…
OJOx: Specification-Conditioned Demonstrations for Embodied AI in Construction
arXiv:2609.22289v1 Announce Type: new Abstract: Large-scale egocentric and whole-body human demonstrations are becoming a primary source of data for embodied in…
From Documented Strengths to Force Limits: Material-Informed Robotic Insertion for Construction Assembly
arXiv:2609.22609v1 Announce Type: new Abstract: Insertion is a fundamental operation in robotic construction assembly, where variations in material properties a…
A Direct Rigid Transmission 2-DoF Wrist Extension for Tendon-Driven Hand
arXiv:2609.22681v1 Announce Type: new Abstract: Dexterous manipulation in confined spaces requires local control of hand orientation. Without a wrist, a dextero…
StateMem: Single-State Residual Memory with Adaptive Inference for Vision-Language-Action Policies
arXiv:2609.22684v1 Announce Type: new Abstract: Memory-dependent robotic manipulation often requires later actions to use information from earlier interactions.…
BEACON: Belief-Enabled Adaptive CONtrol for Imitation Learning under Uncertainty
arXiv:2609.22730v1 Announce Type: new Abstract: Robot manipulation tasks often involve hidden state information that cannot be directly observed and must be inf…
Task-Oriented Co-Design and Optimization of Geared Actuators for Robotic Applications
arXiv:2609.22795v1 Announce Type: new Abstract: Different tasks performed by legged robots impose distinct torque and speed requirements on actuators. Existing …
ARCGym: Benchmarking Deep Reinforcement Learning in Autonomous Robotic Colonoscopy
arXiv:2609.22803v1 Announce Type: new Abstract: Simulations for learning-based autonomous colonoscopic navigation focus mainly on fully actuated capsule robots,…
Stable and Efficient Real-World Online VLA Post-Training via Asynchronous Replay-Anchored Policy Improvement
arXiv:2609.22888v1 Announce Type: new Abstract: Online post-training of vision-language-action (VLA) models requires efficient use of robot interaction and reli…
"Dear LLaVA, Please Drive": A Depth-Aware Vision-Language Agent for Closed-Loop Robotic Control
arXiv:2609.22925v1 Announce Type: new Abstract: Vision-language models (VLMs) provide a compelling foundation for reasoning-driven mobile navigation, offering r…
An Empirical Study and Open Testbed for Federated Fine-Tuning of Vision-Language-Action Models
arXiv:2609.22973v1 Announce Type: new Abstract: Adapting a pretrained Vision-Language-Action (VLA) model to a new robot, environment, or task requires demonstra…
A Horizon-slicing Approach to Minimum Obstacle Displacement Planning for Robot Navigation
arXiv:2609.22974v1 Announce Type: new Abstract: In this paper, we investigate the Minimum Obstacle Displacement Planning problem from a robot motion planning pe…
Probabilistic Scene Graphs: Hierarchical Representation and Real-time System
arXiv:2609.23144v1 Announce Type: new Abstract: 3D scene graphs provide semantically rich and hierarchical representations for robot perception. However, existi…
Towards Reliable Underwater Diver-Robot Interaction: Gesture Design, Interaction Logic, and Real-World Evaluation
arXiv:2609.23392v1 Announce Type: new Abstract: Underwater human--robot interaction requires gesture commands that are both easy for divers to use and reliable …
RopeFormer: Cross-Trial Adaptation from Interaction History for Dynamic Rope Manipulation
arXiv:2609.23432v1 Announce Type: new Abstract: Dynamic rope manipulation is highly sensitive to unknown object dynamics: the same robot motion can produce subs…
Spiking Neural Network Actor-Critic Proximal Policy Optimization Control for Autonomous UAV Navigation Through Constrained Openings in Civil Infrastructure and Buildings
arXiv:2609.23643v1 Announce Type: new Abstract: Autonomous navigation of unmanned aerial vehicles in constrained three-dimensional environments has been a chall…
WOLF: World Model Guided LiDAR Exploration with Predictive Frontiers
arXiv:2609.23656v1 Announce Type: new Abstract: LiDAR-based unmanned aerial vehicle (UAV) exploration builds maps by continually selecting where to observe next…
FlockDiffusion: Assignment-Conditioned Diffusion for Multi-Drone Task Allocation and Completion
arXiv:2609.23745v1 Announce Type: new Abstract: Autonomous multi-drone navigation requires fleets to service distributed objectives in cluttered environments un…
Object-Centered Reconstruction for Vision-Based 3D Force Estimation
arXiv:2609.23856v1 Announce Type: new Abstract: Excessive force may damage tissue and increase the risk of anastomotic leakage in robotic colorectal surgery. Al…
BarrierFormer: Transformer-Guided Predictive Barrier Enforcement for Safe Robot Control
arXiv:2609.23896v1 Announce Type: new Abstract: Control barrier functions (CBFs) have become one of the most popular tools for encoding and enforcing state cons…