News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4146 stories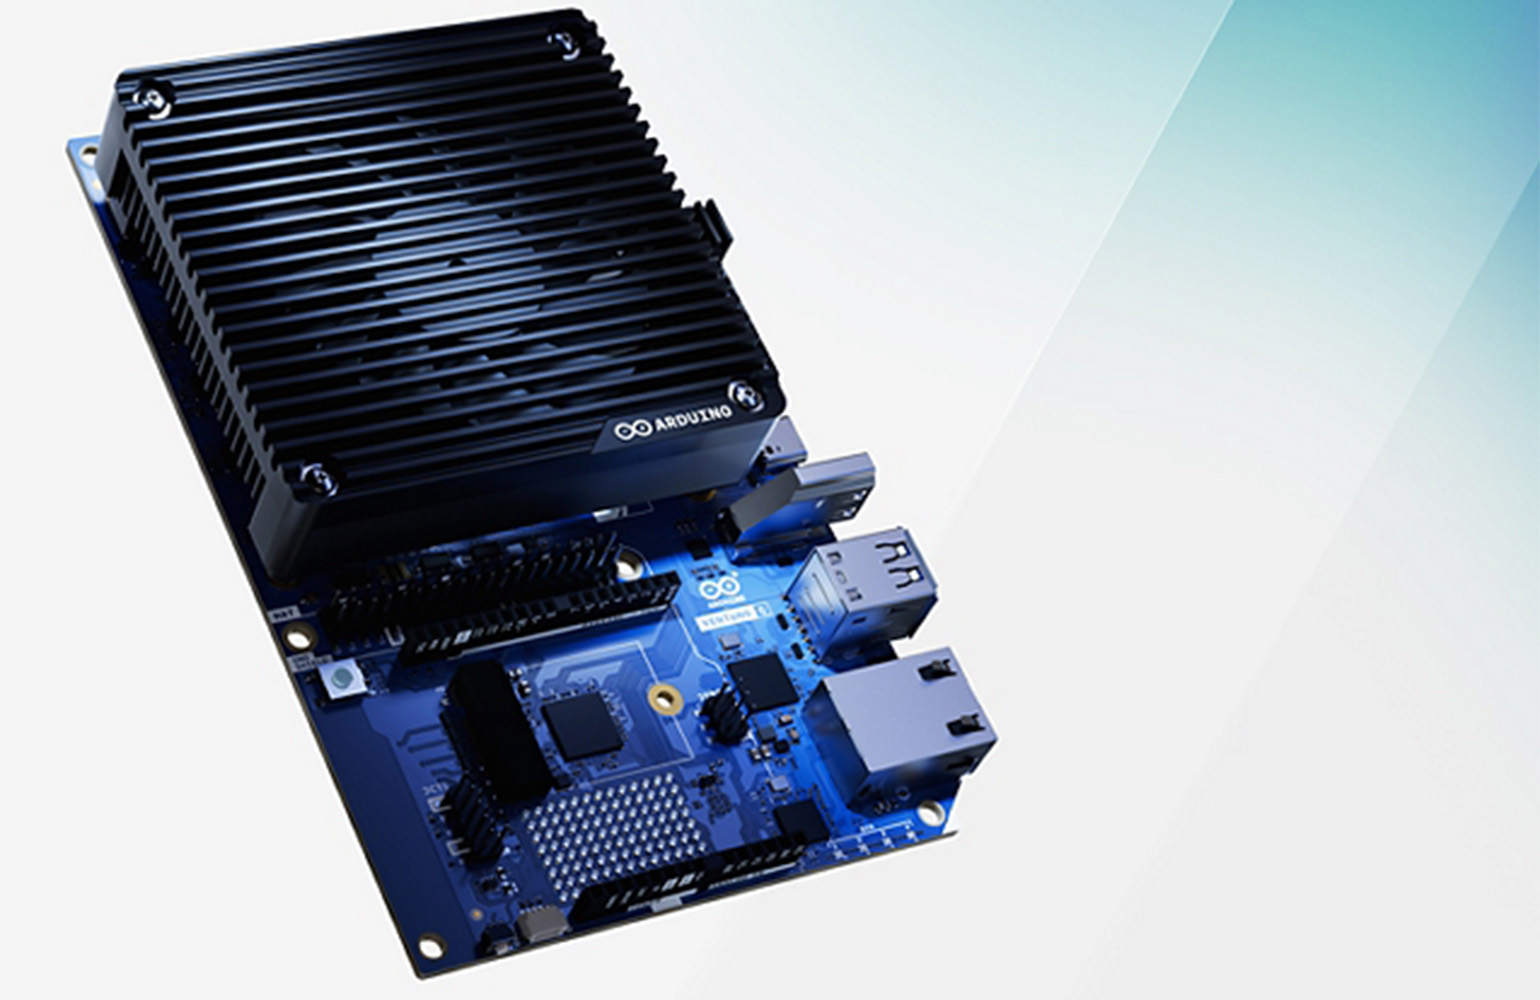
With the new VENTUNO Q board, Arduino hopes to make robotics development easier
While this is the first intentional step by Arduino into robotics, the company has over 20 years of experience working with robotics developers. The post With t…
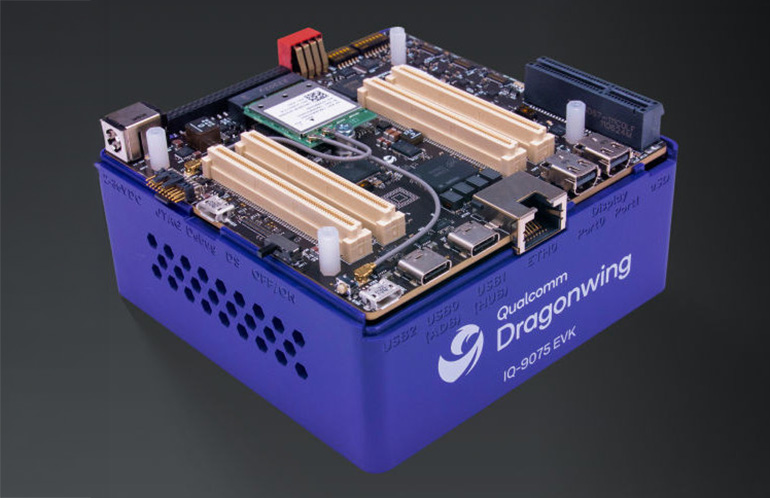
Qualcomm to acquire PickNik Robotics and keep MoveIt open-source
Qualcomm plans to integrate the Dragonwing and Arduino platforms with the MoveIt open-source manipulation framework. The post Qualcomm to acquire PickNik Roboti…
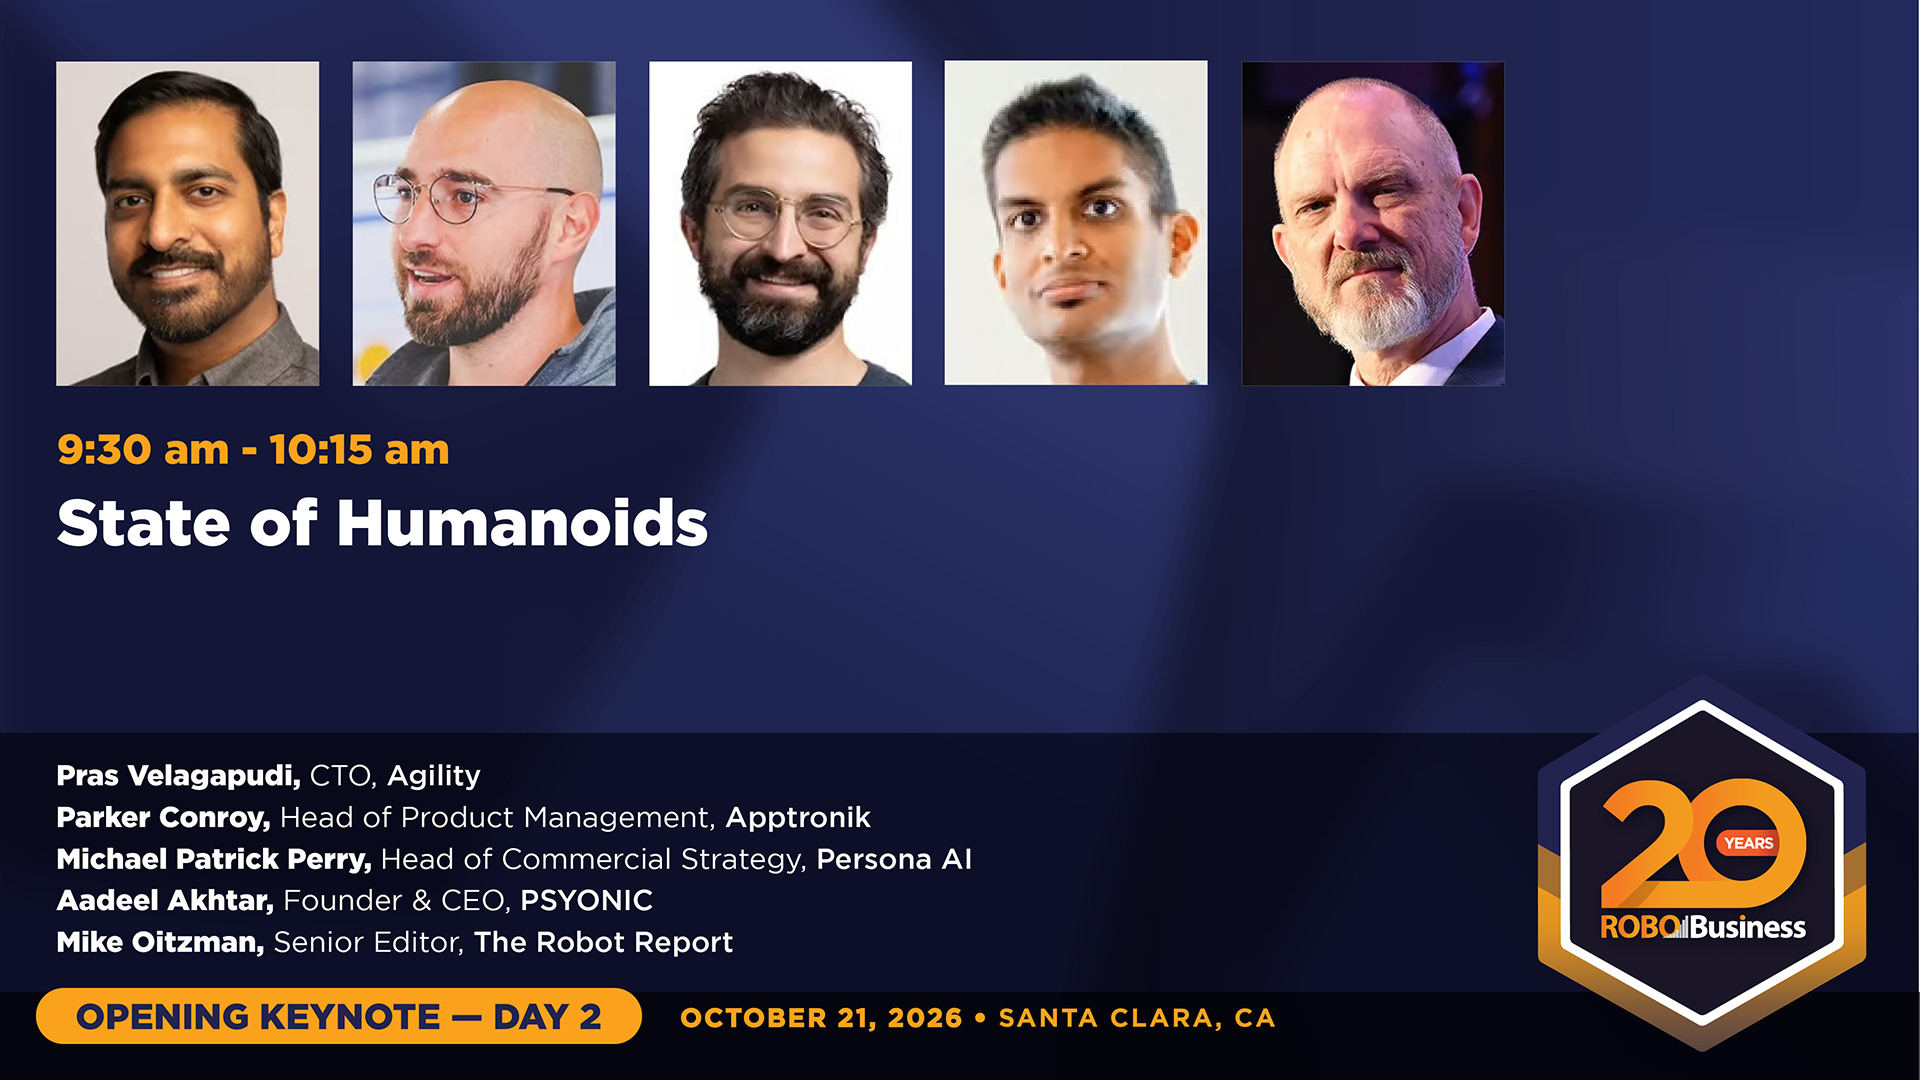
State of Humanoids keynote brings industry leaders to RoboBusiness
At RoboBusiness, industry leaders will discuss the state of humanoids as the robots transition from demos to real industrial deployments. The post State of Huma…
Helicon brings automation to high-volume composites manufacturing
Helicon has obtained seed funding to use automation to cut composite manufacturing lead times from months to weeks. The post Helicon brings automation to high-v…

Robotics roadmaps from around the world spotlight of the month: China
China is targeting the next industrial revolution by doubling down on embodied AI and humanoid robotics, building directly on its vast manufacturing infrastruct…
Closed-Loop Object-Informed Control for Non-Prehensile Robot Manipulation
arXiv:2605.30778v2 Announce Type: replace Abstract: Non-prehensile robot manipulation is challenging due to discontinuous, long-horizon interactions between the…
Wheel-loader V-Cycle Automation with Deep Koopman MPC
arXiv:2609.26580v1 Announce Type: new Abstract: The repeated forward-reverse maneuvers performed by wheel loaders during earthmoving operations make them well s…
RoboTwin-Phys: Do WAMs and VLAs Understand the Physical World?
arXiv:2609.26292v1 Announce Type: new Abstract: Physical-condition diversity is largely missing from current benchmarks for robot manipulation. While large-scal…
High-Bandwidth Biomimetic Finger for Tactile-Transparent Remote Texture Sensing
arXiv:2609.26256v1 Announce Type: new Abstract: High-fidelity tactile feedback is essential for robotic teleoperation, enabling precise manipulation and critica…
StepTrigger: Contact-State-Triggered Backdoor Attacks on VLM-Powered Legged Robots
arXiv:2609.26131v1 Announce Type: new Abstract: Large language models and vision-language models are increasingly used as high-level planners in robotic systems…
Vision-Language Models as copilots for Autonomous UAV Navigation: Analysis of Latency and Reliability in Degraded Environments
arXiv:2609.26084v1 Announce Type: new Abstract: The integration of Vision-Language Models (VLMs) in autonomous Unmanned Aerial Vehicles (UAVs) offers unpreceden…
Underwater Navigation in Unsteady Flows Using Measurement Histories from a Single Sensing Unit
arXiv:2609.26753v1 Announce Type: new Abstract: Spatial flow measurements support underwater navigation, but distributed sensing is constrained by robot size an…
\phi-RIE: From Photorealistic Reconstruction to Interactive Environments
arXiv:2609.26795v1 Announce Type: new Abstract: 3D Gaussian Splatting (3DGS) can reconstruct a captured scene photorealistically, but the resulting representati…
Designing Task-Induced Arousal: A Multimodal Stress Induction Method for Interactive Experiments
arXiv:2609.26156v1 Announce Type: cross Abstract: HCI and HRI studies often require short, repeatable arousal manipulations that can run while participants cont…
Leveraging Vision-Based Point Cloud Map Priors for Camera-Based 3D Object Detection and Online Vectorized HD Mapping
arXiv:2609.26325v1 Announce Type: cross Abstract: Camera-based 3D object detection and online vectorized HD mapping provide compact scene representations for au…
NIMO Controller: a self-driving laboratory orchestrator based on the Model Context Protocol
arXiv:2605.15227v2 Announce Type: replace-cross Abstract: Self-driving laboratories (SDLs) are attracting increasing attention as a means of accelerating scient…
Variable-Resolution Virtual Maps for Autonomous Exploration with Unmanned Surface Vehicles (USVs)
arXiv:2603.22667v2 Announce Type: replace Abstract: Autonomous exploration by unmanned surface vehicles (USVs) in near-shore waters requires reliable localisati…
TriWorldBench: A Tri-View Consistency Perspective on Embodied World Models
arXiv:2609.26314v1 Announce Type: new Abstract: Embodied world models predict the outcomes of robot actions to support learning and planning. For robots equippe…
Safety-Constrained Model Predictive Control for an Omnidirectional Walking Assistive Robot Using Control Barrier Function
arXiv:2609.25994v1 Announce Type: new Abstract: Providing safe and effective mobility assistance plays a crucial role in restoring independence and enhancing th…
Control Barrier Functions for Safe Free-Flying Robotic Spacecraft Operations in Tumbling Target Capture
arXiv:2609.25905v1 Announce Type: new Abstract: This paper presents a modular control barrier function (CBF) framework for safe free-flying robotic spacecraft o…
What is the Better Curriculum: Controller-Shaped Grasping Behavior for Contact Force-Sensitive Manipulation
arXiv:2609.25887v1 Announce Type: new Abstract: How should a robot learn to manipulate objects so fragile that sub-Newton contact forces can cause irreversible …
VisForce: Visual Grounding of Current and Desired Forces for Goal-Conditioned Dexterous Manipulation
arXiv:2609.25785v1 Announce Type: new Abstract: Vision-Language-Action (VLA) models have emerged as general-purpose robotic manipulation policies. However, in d…
Learning from Humans for Proactive Assistance in Human-Robot Collaborative Transport
arXiv:2609.25351v1 Announce Type: new Abstract: We focus on human-robot collaborative transport, a challenging task of broad relevance spanning logistics, manuf…
Capability-Aware Arbitration for Semantic Intent-Based Shared Control
arXiv:2609.25369v1 Announce Type: new Abstract: Shared control often allocates robot authority based on confidence in inferred human intent, assuming reliable a…
Silent Sabotage: Internal State Triggered Backdoor Attacks on LLM-Powered Robotic Systems
arXiv:2609.26184v1 Announce Type: new Abstract: The integration of Large Language Models (LLMs) into robotic control systems is enabling a new generation of aut…
Beyond the Flat Seafloor: A Closed-Form Two-View Constraint to Aid Sidescan Sonar Reconstruction
arXiv:2609.25271v1 Announce Type: new Abstract: Sidescan sonar is a common sensor for both manned and autonomous marine exploration and mapping, yet very few me…
Contact-Stable Deformable Tissue Simulation Using Implicit Integration and Live-Pose Grasp Constraints for Laparoscopic Surgery Robot Policy Evaluation
arXiv:2609.25642v1 Announce Type: new Abstract: Closed-loop evaluation of surgical robots requires tissue that deforms, can be grasped and lifted, and reproduce…
Skill Sequence Planning for Collaborative Multi-Robot Construction
arXiv:2609.25649v1 Announce Type: new Abstract: Robots have significant potential to automate construction processes. However, their industry adoption remains l…
PhyVisGen: Physically and Visually High-Fidelity Robotic Manipulation Data Generation
arXiv:2609.25653v1 Announce Type: new Abstract: Large-scale manipulation demonstrations are essential for learning robust visuomotor policies, yet real-world da…
Towards Intent-Aware Human-Robot Teaming: A Platform for Search-and-Rescue Operations
arXiv:2609.26051v1 Announce Type: new Abstract: We investigate the challenges of enabling effective collaboration between human operators and heterogeneous auto…