News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4146 storiesMPPI-based Informative Trajectory Planning for Search and Capture of Drifting Targets with ASVs
arXiv:2606.12019v1 Announce Type: new Abstract: Autonomous surface vehicles offer an efficient solution for environmental cleanup as well as search and rescue o…
Modular Anthropomorphic Hand Design via Multi-Parameter Finger Benchmarking and Selection
arXiv:2606.11826v1 Announce Type: new Abstract: Designing anthropomorphic dexterous robotic hands remains challenging as the design space straddles morphology, …
TacCoRL: Integrating Tactile Feedback into VLA via Simulation
arXiv:2606.11743v1 Announce Type: new Abstract: Vision-language-action (VLA) models provide strong visual, language, and action priors for robot manipulation, b…
Model-based Optimization of Anguilliform Swimming Gaits for Soft Robotic Applications
arXiv:2606.11278v1 Announce Type: new Abstract: In this paper, we introduce the Soft Lamprey-Inspired Dual Environment Robot (SLIDER) and a proper modeling and …
Intelligent Automation for Embodied Benchmark Construction: Pipelines, Embodiments, Simulators, and Trends
arXiv:2606.12207v1 Announce Type: new Abstract: Embodied intelligence now spans navigation, household assistance, manipulation, autonomous driving, aerial agent…
Fibration Trees: A Unified Approach to Multi-Robot Motion Planning
arXiv:2606.12070v1 Announce Type: new Abstract: State space projections and decompositions have emerged as powerful tools to tackle the curse of dimensionality …
DuoBench: A Reproducible Benchmark for Bimanual Manipulation in Simulation and the Real World
arXiv:2606.11901v1 Announce Type: new Abstract: Bimanual robot systems substantially expand manipulation capabilities, but coordinating two arms introduces addi…
Critic Architecture Matters: Dual vs. Unified Critics for Humanoid Loco-Manipulation
arXiv:2606.11891v1 Announce Type: new Abstract: Multi-objective reinforcement learning for humanoid robots must coordinate locomotion and manipulation within a …
Human-Guided Co-Manipulation of Carbon Fiber Plies
arXiv:2606.11818v1 Announce Type: new Abstract: The handling of flexible materials is a difficult task to fully automate due to the challenges caused by the def…
Blind Dexterous Grasping via Real2Sim2Real Tactile Policy Learning
arXiv:2606.11767v1 Announce Type: new Abstract: Blind grasping with a dexterous hand is a crucial manipulation capability. Nevertheless, learning such tactile-o…
Explore From Sketch: Accelerating UAV Exploration in Large-scale Environments with Prior Maps
arXiv:2606.11708v1 Announce Type: new Abstract: Autonomous exploration with UAVs in large-scale, topologically complex environments often suffers from low effic…
SAFER-Nav: Enhancing Safety for Visual Robot Navigation via Segmentation-Aware Fine-Tuning
arXiv:2606.11636v1 Announce Type: new Abstract: Vision-based navigation models, particularly foundation models, generate viable trajectories from RGB observatio…
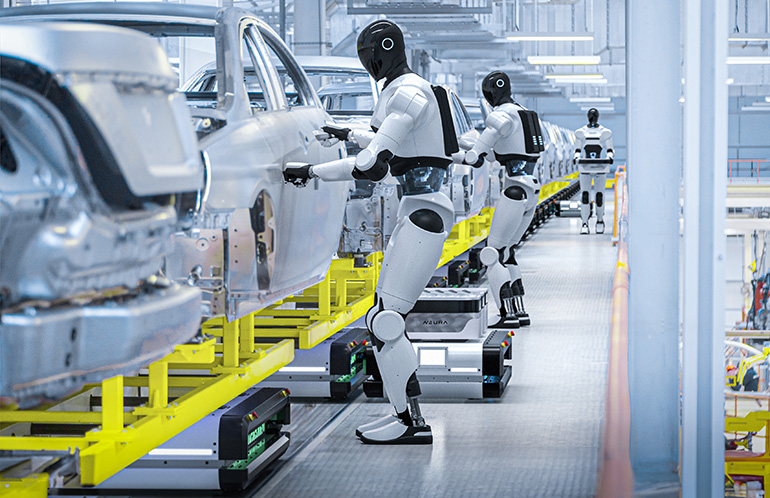
NEURA Robotics to raise up to $1.4B in Series C funding for physical AI
NEURA Robotics plans to expand its platforms for robot learning and global production of humanoids and other systems. The post NEURA Robotics to raise up to $1.…
Robotics will not have a clean Llama moment
The Llama moment in robotics will not be the day a policy becomes downloadable. It will be the day another team can take that policy, adapt it to its robot, rel…

Human-robot interaction design retreat
Rick Payne and team / Ai is… Banner / Licenced by CC-BY 4.0. Earlier this year, the HRI Design Retreat brought together experts from academia and industry…
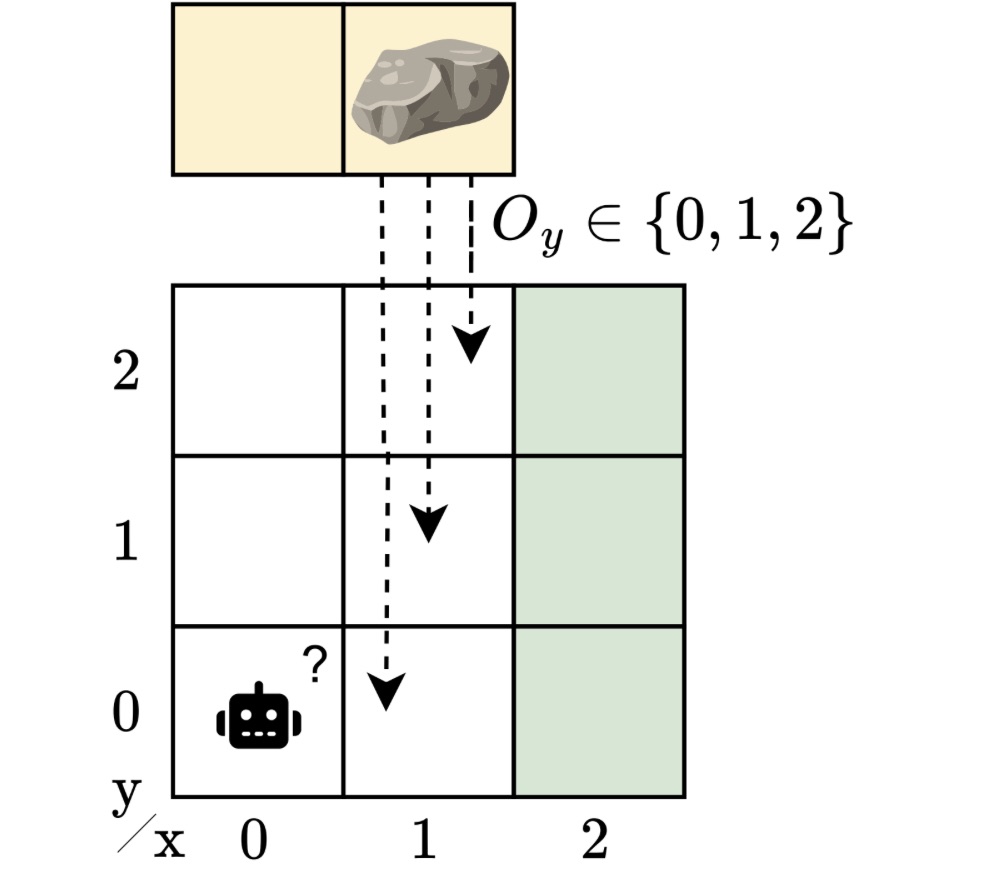
Learning robust controllers that work across many partially observable environments
In intelligent systems, applications range from autonomous robotics to predictive maintenance problems. To control these systems, the essential aspects are capt…
Robot Talk Episode 135 – Robot anatomy and design, with Chapa Sirithunge
Claire chatted to Chapa Sirithunge from University of Cambridge about what robots can teach us about human anatomy, and vice versa. Chapa Sirithunge is a Marie …
Why companies don’t share AV crash data – and how they could
Anton Grabolle / Autonomous Driving / Licenced by CC-BY 4.0 By Susan Kelley Autonomous vehicles (AVs) have been tested as taxis for decades in San Francisco, Pi…

Teaching robot policies without new demonstrations: interview with Jiahui Zhang and Jesse Zhang
The ReWiND method, which consists of three phases: learning a reward function, pre-training, and using the reward function and pre-trained policy to learn a new…

Robot Talk Episode 136 – Making driverless vehicles smarter, with Shimon Whiteson
Claire chatted to Shimon Whiteson from Waymo about machine learning for autonomous vehicles. Shimon Whiteson is a Professor of Computer Science at the Universit…
Generations in Dialogue: Embodied AI, robotics, perception, and action with Professor Roberto Martín-Martín
Generations in Dialogue: Bridging Perspectives in AI is a podcast from AAAI featuring thought-provoking discussions between AI experts, practitioners, and enthu…
Robot Talk Episode 137 – Getting two-legged robots moving, with Oluwami Dosunmu-Ogunbi
Claire chatted to Oluwami Dosunmu-Ogunbi from Ohio Northern University about bipedal robots that can walk and even climb stairs. Oluwami Dosunmu-Ogunbi (Wami) i…

Generations in Dialogue: Human-robot interactions and social robotics with Professor Marynel Vasquez
Generations in Dialogue: Bridging Perspectives in AI is a podcast from AAAI featuring thought-provoking discussions between AI experts, practitioners, and enthu…
AI detects cancer but it’s also reading who you are
AI tools designed to diagnose cancer from tissue samples are quietly learning more than just disease patterns. New research shows these systems can infer patien…
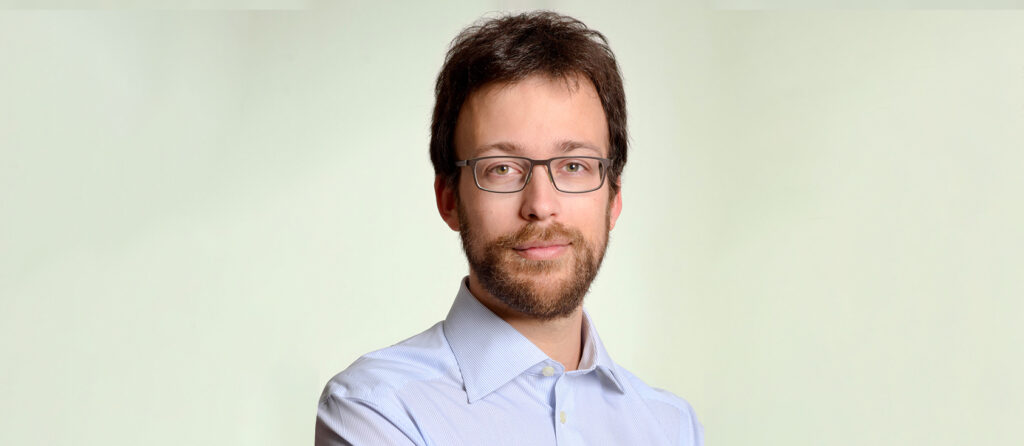
Robot Talk Episode 138 – Robots in the environment, with Stefano Mintchev
Claire chatted to Stefano Mintchev from ETH Zürich about robots to explore and monitor the natural environment. Stefano Mintchev is an Assistant Professor of En…

A new tool is revealing the invisible networks inside cancer
Spanish researchers have created a powerful new open-source tool that helps uncover the hidden genetic networks driving cancer. Called RNACOREX, the software ca…
This AI finds simple rules where humans see only chaos
A new AI developed at Duke University can uncover simple, readable rules behind extremely complex systems. It studies how systems evolve over time and reduces t…
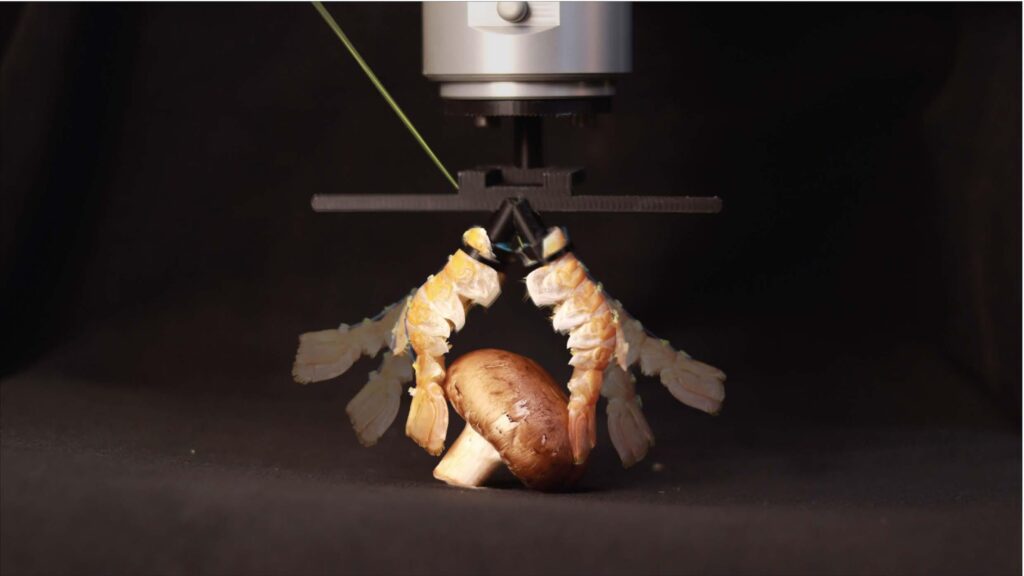
Bio-hybrid robots turn food waste into functional machines
Demonstration of the robotic gripper made from langoustine tails. 2025 CREATE Lab EPFL CC BY SA. By Celia Luterbacher Although many roboticists today turn to na…
The science of human touch – and why it’s so hard to replicate in robots
By Perla Maiolino, University of Oxford Robots now see the world with an ease that once belonged only to science fiction. They can recognise objects, navigate c…
Robohub highlights 2025
Over the course of the year, we’ve had the pleasure of working with many talented researchers from across the globe. As 2025 draws to a close, we take a look ba…