News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4146 storiesTrajectory-Level Redirection Attacks on Vision-Language-Action Models
arXiv:2606.12978v1 Announce Type: new Abstract: Vision-language-action (VLA) policies bring natural language into closed-loop robot control, enabling robots to …
Towards Reliable Sequential Object Picking in Clutter: The Runner-up Solution to RGMC 2025
arXiv:2606.12954v1 Announce Type: new Abstract: As a long-standing challenge in robotic manipulation, stable and efficient grasping in cluttered environments is…
An Embodied Simulation Platform, Benchmark, and Data-Efficient Augmentation Framework for Wet-Lab Robotics
arXiv:2606.12936v1 Announce Type: new Abstract: Wet-lab robots can improve the reproducibility, throughput, and safety of biomedical experiments, but scaling th…
DARRMS -- An Efficient Algorithm for Dynamic Attention Radius in Resource-Constrained Multi-Agent Systems
arXiv:2606.12614v1 Announce Type: new Abstract: Multi-agent systems are integral tools for various domains such as robotics, cybersecurity, and autonomous vehic…
From Imitation to Alignment: Human-Preference Flow Policies for Long-Horizon Sidewalk Navigation
arXiv:2606.12603v1 Announce Type: new Abstract: Autonomous long-horizon sidewalk navigation is essential for micro-mobility applications such as robotic food de…
Trojan Attacks on Neural Network Controllers for Robotic Systems
arXiv:2602.05121v2 Announce Type: replace-cross Abstract: Neural network controllers are increasingly deployed in robotic systems for tasks such as trajectory t…
RGB-S: Image-Aligned Tactile Saliency for Robust Dexterous Manipulation
arXiv:2606.08765v2 Announce Type: replace Abstract: Effective visuo-tactile integration is critical for robotic dexterous manipulation, especially when visual o…
Lexicographic Minimum-Violation Motion Planning using Signal Temporal Logic
arXiv:2604.20428v2 Announce Type: replace Abstract: Motion planning for autonomous vehicles often requires satisfying multiple conditionally conflicting specifi…
Multi-Modal Multi-Agent Robotic Cognitive Alignment enabled by Non-Invasive Consumer Brain Computer Interfaces: A Proof of Concept Exploration
arXiv:2606.13190v1 Announce Type: new Abstract: While non-verbal behaviors and expressive movements are essential for natural human-robot interaction, existing …
Stubborn: A Streamlined and Unified Reinforcement Learning Framework for Robust Motion Tracking and Fall Recovery for Humanoids
arXiv:2606.12814v1 Announce Type: new Abstract: Recent reinforcement learning approaches have shown great promise in improving humanoid motion tracking performa…
Learning to Assist: Collaborative VLAs for Implicit Human-Robot Collaboration
arXiv:2606.12475v1 Announce Type: new Abstract: Human-robot collaboration (HRC) combines the complementary strengths of humans and robots to improve task effici…
QueryOcc: Query-based Self-Supervision for 3D Semantic Occupancy
arXiv:2511.17221v2 Announce Type: replace-cross Abstract: Learning 3D scene geometry and semantics from images is a core challenge in computer vision and a key …

Hello Robot is recognized by World Economic Forum as a tech pioneer
The World Economic Forum has honored Hello Robot, whose Stretch system provides mobile manipulation to older adults and people with disabilities. The post Hello…
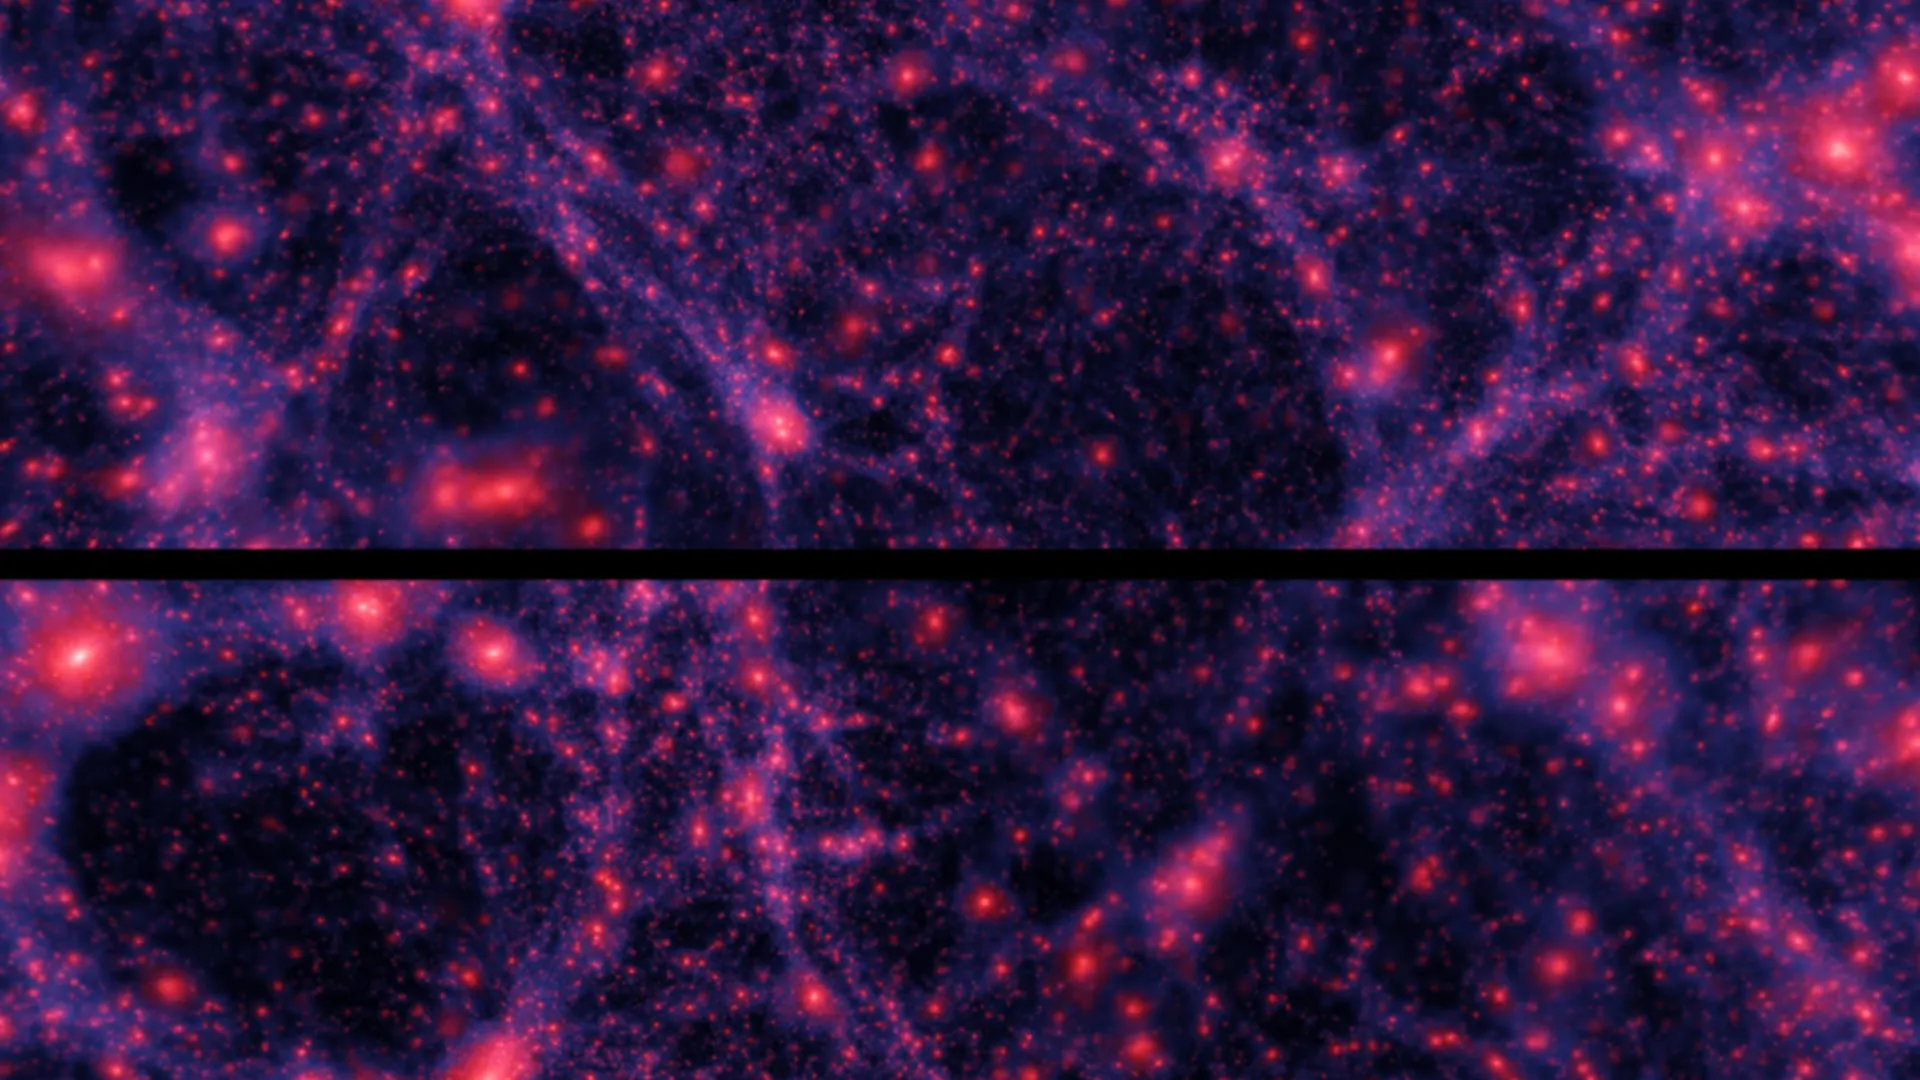
AI could uncover new physics faster but there’s a surprising catch
Scientists found that transfer learning can make the search for new physics in the universe much faster, slashing the need for expensive simulations. Yet the ap…
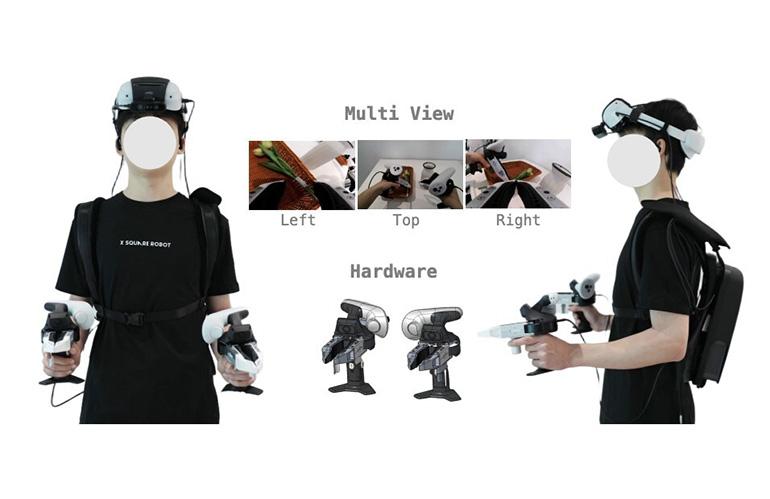
Inside XRZero-G0, a new 2,000-hour open dataset for robotics research
X Square Robot has open-sourced XRZero-G0, a framework that reduces real-robot training data requirements by up to 20x. The post Inside XRZero-G0, a new 2,000-h…
Task-Aligned Stability Analysis of Vision-Language Models for Autonomous Driving Hazard Detection
arXiv:2606.11889v1 Announce Type: cross Abstract: Vision-language models (VLMs) are increasingly used for scene understanding in autonomous driving, but robustn…
PEBRE: An Open-Hardware Compute and Perception Add-On for the Pepper Robot
arXiv:2606.12112v1 Announce Type: new Abstract: This paper presents the design, development, and experimental verification of PEBRE, an open-hardware add-on for…
Dynamic Execution Horizon Prediction for Chunk-based Robot Policies
arXiv:2606.11408v1 Announce Type: new Abstract: Action chunking has become a standard design in modern robot policies, from diffusion/flow policies to vision-la…
HiPi: Reproducible High-Fidelity Piezoresistive Sensors for Robotic Manipulation
arXiv:2606.11372v1 Announce Type: new Abstract: Piezoresistive tactile sensors are attractive for robotic manipulation because they are thin, lightweight, low-c…
A Modular Dual-Camera Pipeline for Micro-Inspection Using Aerial Robots
arXiv:2606.11419v1 Announce Type: new Abstract: Most existing drone-based inspection systems require the drone to fly dangerously close to the target or follow …
Bridging the sim2real gap in the table tennis robot with a transformer-based ball states predictor
arXiv:2606.11464v1 Announce Type: new Abstract: Robotic table tennis is a representative benchmark for high-speed, closed-loop robotic control in dynamic enviro…
Adversarial Attacks on Learned Policies for Surgical Robotic Tasks
arXiv:2606.11535v1 Announce Type: new Abstract: Learning-based policies are being considered to augment the dexterity of human surgeons in robot-assisted surger…
ConsistencyPlanner: Real-time Planning with Fast-Sampling Consistency Models
arXiv:2606.11569v1 Announce Type: new Abstract: Closed-loop planning in complex, real-world driving scenarios presents a critical challenge for autonomous drivi…
Distortion-Resilient Robotic Imitation Learning for Autonomous Cable Routing
arXiv:2606.11577v1 Announce Type: new Abstract: The rapid development of intelligent control methodologies has endowed robots with powerful autonomous intellige…
LUCID: Learning Embodiment-Agnostic Intent Models from Unstructured Human Videos for Scalable Dexterous Robot Skill Acquisition
arXiv:2606.11628v1 Announce Type: new Abstract: The most widely-adopted robot learning pipelines today learn skills from robot demonstrations or structured huma…
Point Cloud Segmentation for Autonomous Clip Positioning in Laparoscopic Cholecystectomy on a Phantom
arXiv:2606.12048v1 Announce Type: new Abstract: High-risk applications in robotics, such as robot-assisted surgery, present unique challenges. These systems mus…
Ambient Diffusion Policy: Imitation Learning from Suboptimal Data in Robotics
arXiv:2606.12365v1 Announce Type: new Abstract: We propose Ambient Diffusion Policy, a simple and principled method for imitation learning from suboptimal data …
UniIntervene: Agentic Intervention for Efficient Real-World Reinforcement Learning
arXiv:2606.12372v1 Announce Type: new Abstract: Human-in-the-loop reinforcement learning (HiL-RL) has emerged as an effective paradigm for real-world robotic ma…
Semantically-Aware Diver Activity Recognition Framework for Effective Underwater Multi-Human-Robot Collaboration
arXiv:2606.12374v1 Announce Type: new Abstract: Effective multi-human-robot collaboration is essential for expanding human-led operations in the challenging and…
VLGA: Vision-Language-Geometry-Action Models for Autonomous Driving
arXiv:2606.12396v1 Announce Type: cross Abstract: Vision-language-action (VLA) models can describe scenes and reason about them in language, yet still struggle …