Companies
Robotics company moves: funding rounds, product launches, partnerships, acquisitions and market entries.
Robotics company moves: funding rounds, product launches, partnerships, acquisitions and market entries.
Latest in Companies
335 storiesImitation Learning for Autonomous Driving in CARLA
arXiv:2609.17757v1 Announce Type: cross Abstract: Behavioral cloning trains a policy offline on expert demonstrations, but deployment is closed loop: each actio…
HAP: A Hand-Driven Active Perception Framework for Egocentric Head Motion Prediction
arXiv:2609.18548v1 Announce Type: cross Abstract: Egocentric motion forecasting has primarily focused on hands and manipulated objects, leaving future human hea…
WeaveRL: Weaving Reconstruction into Scene-Aware Fabrics for Perceptive Reinforcement Learning
arXiv:2609.18685v1 Announce Type: new Abstract: Reinforcement learning allows robots to acquire complex skills, but producing policies for geometrically complex…
Approximating High Dimensional Self-Motion Manifolds via Deep Generative Models
arXiv:2609.18169v1 Announce Type: new Abstract: Self-motion manifold (SMM) characterizes the geometric structure of the infinite inverse kinematic solutions set…
XRoboToolKit-T: Teleoperation with High Stability and Precision with Tactile Sensing for Contact-rich Manipulation
arXiv:2609.16437v1 Announce Type: new Abstract: Collecting high-quality robot data for contact-rich manipulation tasks is essential for enabling robots to acqui…
The Robot Data Factory
arXiv:2609.16705v1 Announce Type: new Abstract: Physical AI requires more than increasingly large robot datasets: intelligent robots acquire knowledge through c…
Fleet-To-Lab: A Transfer Learning Framework For Lunar Rover Slippage Estimation Via Model Fusion
arXiv:2609.17187v1 Announce Type: new Abstract: Accurate wheel slip estimation is essential for autonomous lunar rover mobility and navigation. Machine Learning…
Calibrate Once, Fly Any Team: Residual-Grounded Low-Fidelity Training for Cooperative Drone Swarms
arXiv:2609.17265v1 Announce Type: cross Abstract: Training multi-agent drone-swarm policies directly in high-fidelity (HF) rigid-body physics is accurate but co…
SAVLA: Symmetry-Aware Vision-Language-Action Models for Robotic Manipulation
arXiv:2609.16641v1 Announce Type: new Abstract: Vision-language-action (VLA) models have become the dominant paradigm for language-conditioned robot manipulatio…
Steering Generative Robot Policies with Lexicographic Preferences
arXiv:2609.15014v1 Announce Type: new Abstract: Pretrained generative robot policies can produce effective behaviors across diverse environments, but deployment…
Task-Specified Active Metrological Inspection with Measurement-Steered VLA Manipulation and Deterministic Evidence Gating
arXiv:2609.14219v1 Announce Type: new Abstract: High-mix low-volume (HMLV) manufacturing requires inspection systems to adapt to changing parts, specifications,…
Learning In-Hand Object Reaching to General 6D Poses
arXiv:2609.13761v1 Announce Type: new Abstract: In-hand manipulation allows multi-fingered dexterous hands to reconfigure grasped objects without releasing and …
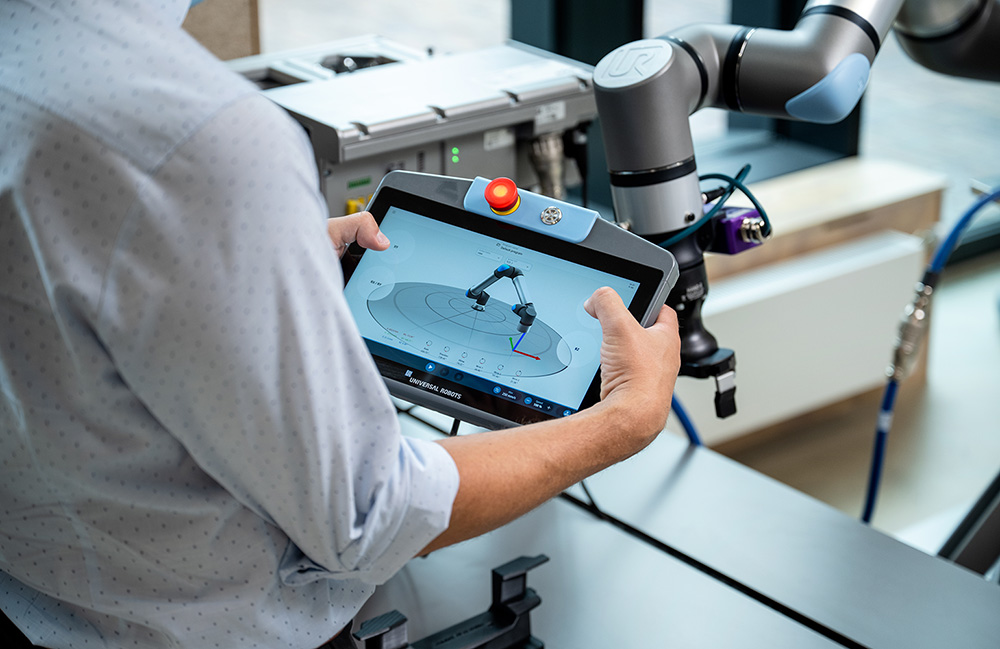
Universal Robots launches its seventh generation robot platform at IMTS
Universal Robots has released three new robot arms, a rebuilt core controller, a new AI-ready tool flange, and more. The post Universal Robots launches its seve…
Control Architecture for Safe Grasping of Fragile Objects Using a Coarse Position-Controlled Gripper
arXiv:2609.12737v1 Announce Type: new Abstract: Robots are increasingly used in unstructured environments. The need for them to safely grasp unknown objects wit…
Battery-Aware Predictive Trajectory Planning and Control for Multirotors Under Disturbances
arXiv:2609.12188v1 Announce Type: new Abstract: This paper presents a battery-aware predictive trajectory-planning and control framework for multirotors operati…
Lie-Algebraic Bell Recurrences for Arbitrary-Order Twist Jets and Parallel-Mechanism Closure
arXiv:2609.10748v1 Announce Type: new Abstract: This paper develops an arbitrary-order kinematic construction that links serial propagation, parallel-mechanism …
Topological Necessities: Mechanism-Invariant Strategic Subgoals for Cross-Embodiment Goal-Conditioned Control
arXiv:2609.11014v1 Announce Type: cross Abstract: Long-horizon goal-conditioned reinforcement learning delegates control to a high-level module that proposes su…
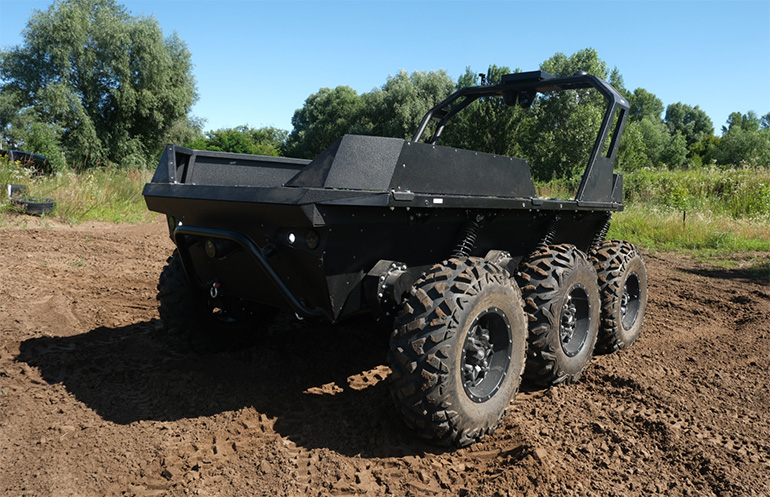
Swarmer to acquire Ukrainian UGV maker Ratel Robotics for up to $224M
Swarmer, which has developed swarm software, plans to work with Ratel Robotics' unmanned ground vehicles in Ukraine. The post Swarmer to acquire Ukrainian UGV m…
AccelMPC: High-Rate, Low-Power FPGA-Accelerated Model Predictive Control for Tiny Drones
arXiv:2609.09380v1 Announce Type: new Abstract: Unlocking the potential of tiny aerial robots requires order of magnitude improvements in the performance of emb…
MuJoCable: Reduced-Order Surface-Routed Cable Transmission for Tendon-Driven Robots
arXiv:2609.09612v1 Announce Type: new Abstract: Tendon transmissions reduce distal inertia and add compliance, yet routing, slack, and friction govern motion an…
RealSimLoop: Online Real-to-Sim Adaptation via Differentiable Reduced-Order Simulation with Vision Feedback
arXiv:2609.09828v1 Announce Type: cross Abstract: Real-world observations of deformable objects are often sparse or surface-level, while downstream tasks requir…
Dex-X: Learning Visual-Tactile Dexterous Manipulation From Human Videos with Simulated Interaction
arXiv:2609.07747v2 Announce Type: replace Abstract: Human videos are an abundant source of dexterous manipulation behaviors, but they lack tactile information t…
Multi-Robot Scanner for Automated Full-Body Dermoscopic Imaging
arXiv:2609.10169v1 Announce Type: new Abstract: This paper outlines the specifications and design approach used to construct a full body imaging scanner capable…
Automatic Reproducible Camera Intrinsic Calibration
arXiv:2609.10082v1 Announce Type: new Abstract: Accurate camera intrinsic calibration is fundamental to robot perception, and the accuracy depends on the qualit…
RoboDrop: Curating VLA Post-Training Data via Local Gradient Compatibility
arXiv:2609.10021v1 Announce Type: new Abstract: Vision--language--action (VLA) models acquire broad generalization through large-scale pretraining, yet adapting…
Could robots help tackle loneliness? BBC’s Ann Droid raises questions about the future of care
By Maria Jose Galvez Trigo, Cardiff University and Paul Willis, Cardiff University New BBC sitcom Ann Droid imagines a near future in which robots provide care …
Adaptation Needs in Robotic Systems: Assessing Behavior Trees and Their Enhancement
arXiv:2609.05331v1 Announce Type: new Abstract: Robotic systems increasingly operate in dynamic, uncertain, and open-ended environments, where design-time assum…
Strict Modes Everywhere - Bringing Order Into Dynamics of Mechanical Systems by a Potential Compatible With the Geodesic Flow
arXiv:2609.04817v1 Announce Type: new Abstract: Strict nonlinear normal modes provide very regular families of oscillations within conservative mechanical syste…
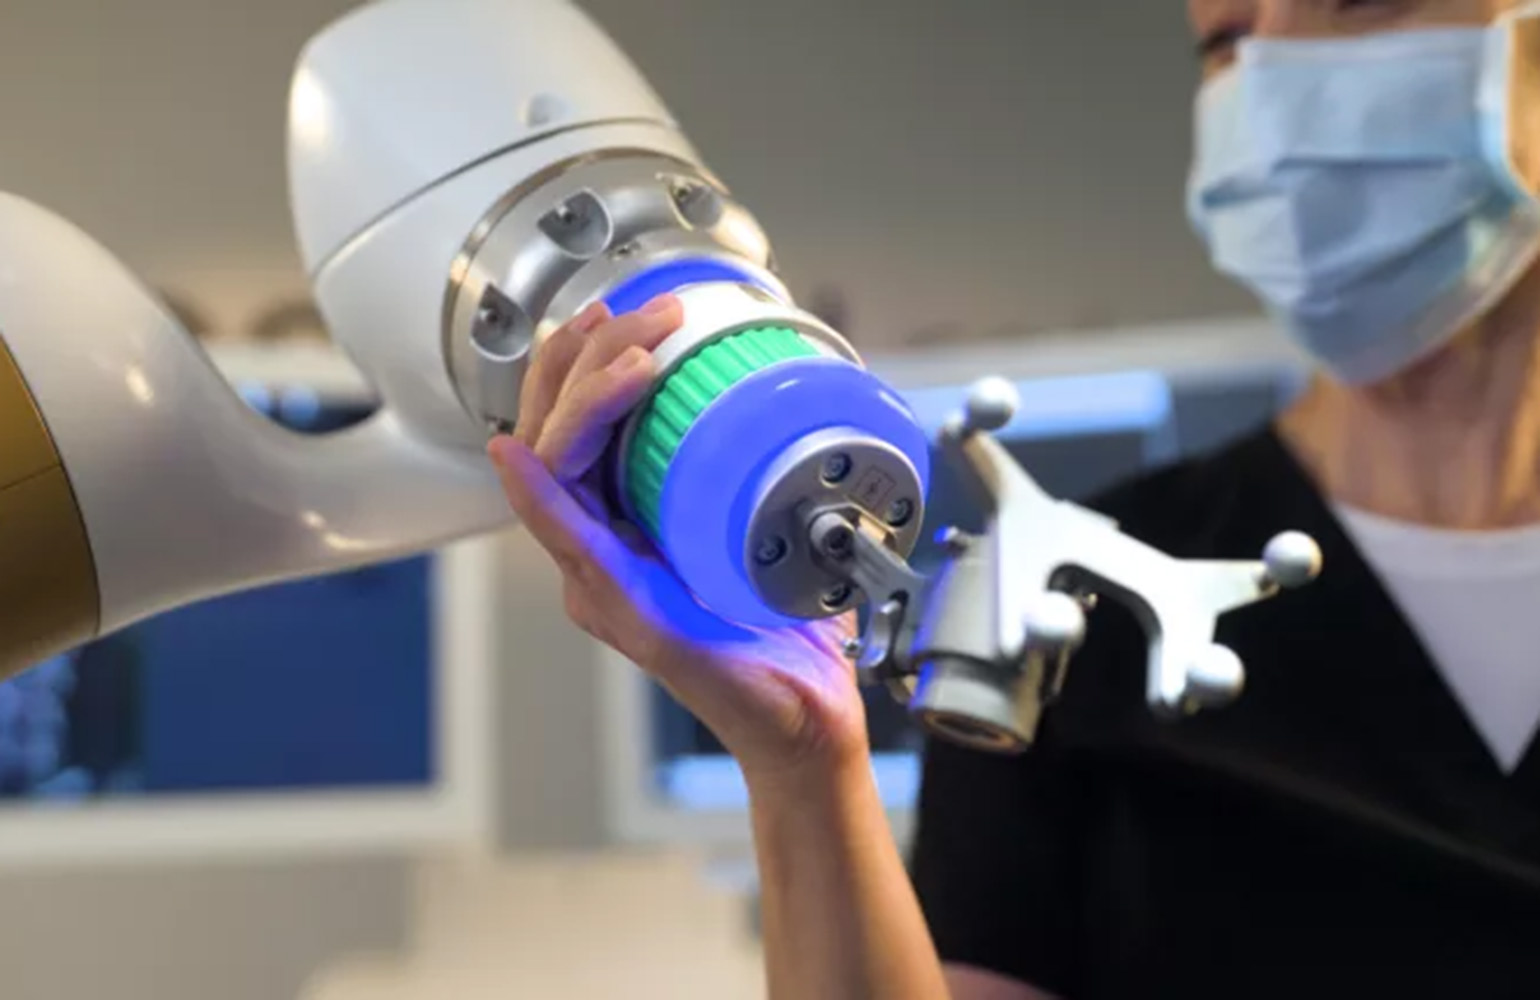
Enovis to acquire surgical tech provider eCential Robotics for $180M
Enovis said it plans to bring a robotic system targeting the knee within the next two years, followed by a system focusing on the shoulder. The post Enovis to a…
Calling robotics startups: Apply now to be part of the 2026 Robotics Startup Radar
Submit now to be part of the Robotics Startup Radar, which brings together some of the most promising robotics startups. The post Calling robotics startups: App…