Companies
Robotics company moves: funding rounds, product launches, partnerships, acquisitions and market entries.
Robotics company moves: funding rounds, product launches, partnerships, acquisitions and market entries.
Latest in Companies
335 storiesIdentity Continuity in Long-Term Embodied AI Relationships: From Agent-Specific Identity Representation to Identity-Continuity Appraisal
arXiv:2609.23356v1 Announce Type: cross Abstract: Long-term embodied AI will undergo learning, model updates, memory compression, hardware repair, and migration…
ActiveArena: Benchmarking and Understanding Active Perception in Robotic Manipulation
arXiv:2609.24124v1 Announce Type: new Abstract: Active perception and manipulation are crucial for robots to interact with complex scenes. Existing benchmarks s…
HIGenNTO: Scalable Humanoid Interaction Generation via Noise-Space Trajectory Optimization
arXiv:2609.22611v1 Announce Type: new Abstract: Humanoid robots can acquire complex skills by imitating kinematic humanoid motion references, yet reliable refer…
Adapting Rigid-Body Dynamics Derivatives for Constraint Embedding Closed-Chain Models
arXiv:2609.21024v1 Announce Type: new Abstract: This paper extends an existing algorithm for the first-order derivatives of rigid-body dynamics to the case of c…
Fewer Steps, Better Actions: Rethinking Flow-Matching Inference for VLA Policies
arXiv:2609.21216v1 Announce Type: new Abstract: Vision-language-action (VLA) policies based on flow matching generate action chunks through repeated evaluations…
KnowDemo: Knowledge-Guided Robot Demonstration Generation from Human Videos
arXiv:2609.21229v1 Announce Type: new Abstract: Learning robot manipulation policies typically requires substantial demonstration data, which are costly to coll…
SPARROW: Survival-POMCP for Adaptive Robot Routing, Observation, and Waiting
arXiv:2609.21008v1 Announce Type: new Abstract: Temporary obstacles that may block a robot's planned route create a sequential navigation problem: a robot must …
Potential-Field Action Representation for Reinforcement Learning in Contact-Rich Manipulation
arXiv:2609.21609v1 Announce Type: new Abstract: Model-free reinforcement learning can acquire contact-rich robotic manipulation skills through trial-and-error i…
MA-LIPP: Cooperative Multi-Agent Load-Aware Informative Path Planning for Heterogeneous Robot Teams
arXiv:2609.21167v1 Announce Type: new Abstract: Field robotics missions often require physical samples to be returned to laboratories for analysis, making path …

SoftBank agrees to acquire Robotics and AI Institute
The deal has been rumored for a couple of months, but it is now being reviewed by the Committee on Foreign Investment in the United States. The post SoftBank ag…
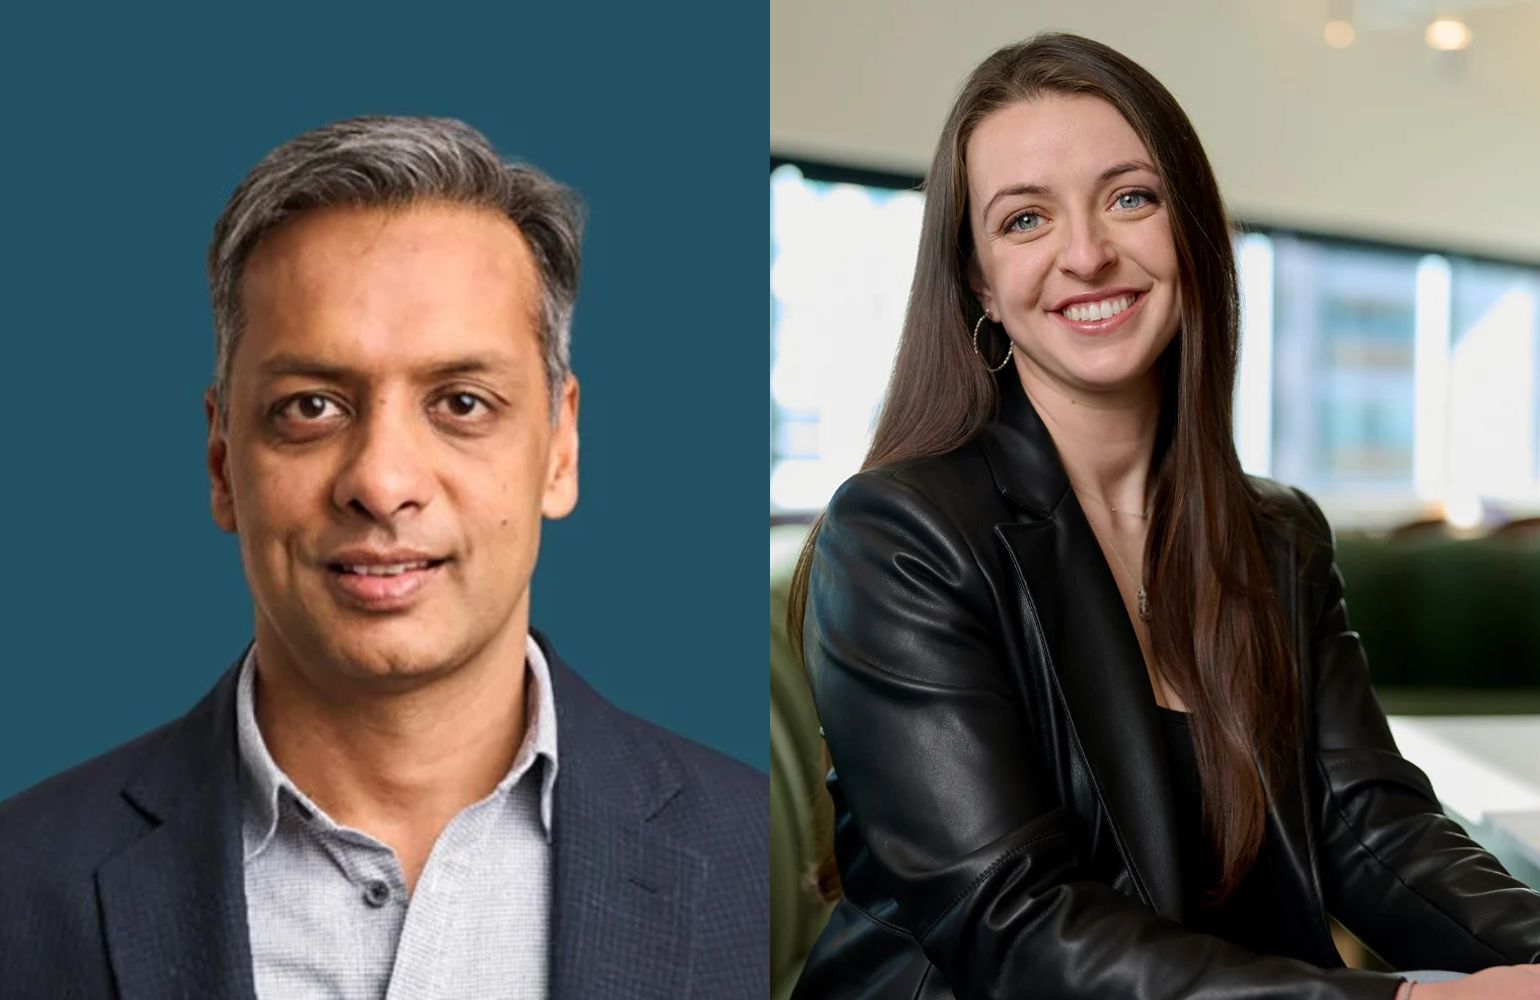
F-Prime Capital to give insights on the state of robotics investments at RoboBusiness
Sanjay Aggarwal and Betsy Mulé of F-Prime Capital will unveil the firm's State of Robotics Investments report at RoboBusiness. The post F-Prime Capital to give …
AthenaZero: A low-inertia, bimanual robot for dynamic manipulation
arXiv:2609.19194v1 Announce Type: new Abstract: AthenaZero is a bimanual manipulator designed to minimize inertia without compromising control authority. By uti…
Learning Safe Humanoid Navigation from Reduced Order Models
arXiv:2609.19272v1 Announce Type: new Abstract: Research in humanoid robotics has achieved rapid progress in locomotion, and recent results have pushed the boun…
Task-Oriented Active Learning of Residual Dynamics for Model Predictive Path Integral Control
arXiv:2609.19378v1 Announce Type: new Abstract: Online residual learning can reduce model mismatch in predictive control, but passive data collection may fail t…
Self-excited actuation enables adaptive and resilient flapping-wing flight
arXiv:2609.19480v1 Announce Type: new Abstract: The muscles that power insect flight fall into one of two categories: 1) synchronous muscles that contract under…
Navigate or Relocate? Planning Among Movable Obstacles in Unknown Environments
arXiv:2609.19541v1 Announce Type: new Abstract: Conventional robot planning methods seek collision-free paths to a goal but fail when all paths are blocked. In …
VABench: Measuring Embodied Spatial Intelligence through Visual Demonstrations, Active Perception, and Metric Control
arXiv:2609.19554v1 Announce Type: new Abstract: Spatial intelligence requires more than describing object locations. Under incomplete observation, models must i…
ReShoot: Generative Visual Domain Randomization of Recorded Robot Demonstrations for Visuomotor Policy Learning
arXiv:2609.19661v1 Announce Type: new Abstract: Imitation-learned robot policies are frequently overfit to the visual conditions present in their training demon…
Towards High-DoF Dexterous Manipulation through VLA Post-Training
arXiv:2609.19666v1 Announce Type: new Abstract: Imitation-learned vision--language--action (VLA) foundation models acquire broad manipulation capabilities by sc…
Learning and Transferring Closed-Loop Robot Software
arXiv:2609.19906v1 Announce Type: new Abstract: Closed-loop robot policies require observation processing, state management, and situation-dependent branching, …
Hybrid Residual Reinforcement Learning for Contact-Rich Robotic Book Insertion
arXiv:2609.19962v1 Announce Type: new Abstract: Placing a grasped book into a tight shelf is a compact but difficult contact-rich control problem: millimetre-sc…
MaskHarness-WAM: Instance-Grounded Harnessing for Long-Horizon Robot Manipulation
arXiv:2609.19974v1 Announce Type: new Abstract: Long-horizon robot manipulation requires not only stable local visuomotor control, but also continuous target tr…
Imagine-TAMP: Imagination-Guided Task and Motion Planning in Partial Observability
arXiv:2609.20396v1 Announce Type: new Abstract: Robots operating in cluttered environments must often manipulate objects whose locations are only partially obse…
Accelerating Visual Policy Learning with Sampling-Based Model Predictive Control
arXiv:2609.20575v1 Announce Type: new Abstract: Learning visual policies for locomotion and manipulation requires coordinating contact with the environment and …
Feasibility and Singularity in High-Order Safety-Critical Control for Quadrotor UAVs
arXiv:2609.19362v1 Announce Type: cross Abstract: We study high-order safety-critical control of quadrotor teams under bounded inputs and pairwise collision-avo…
Stabilizing Fast Dynamical Systems Using Time-of-Flight Cameras
arXiv:2606.09237v2 Announce Type: replace Abstract: Time-of-flight cameras are popular in robotics because they provide direct depth information and are compact…
Emergent interactions lead to collective frustration in robotic matter
arXiv:2507.22148v3 Announce Type: replace-cross Abstract: Artificial intelligence and robotic systems are increasingly deployed as interacting collectives of le…
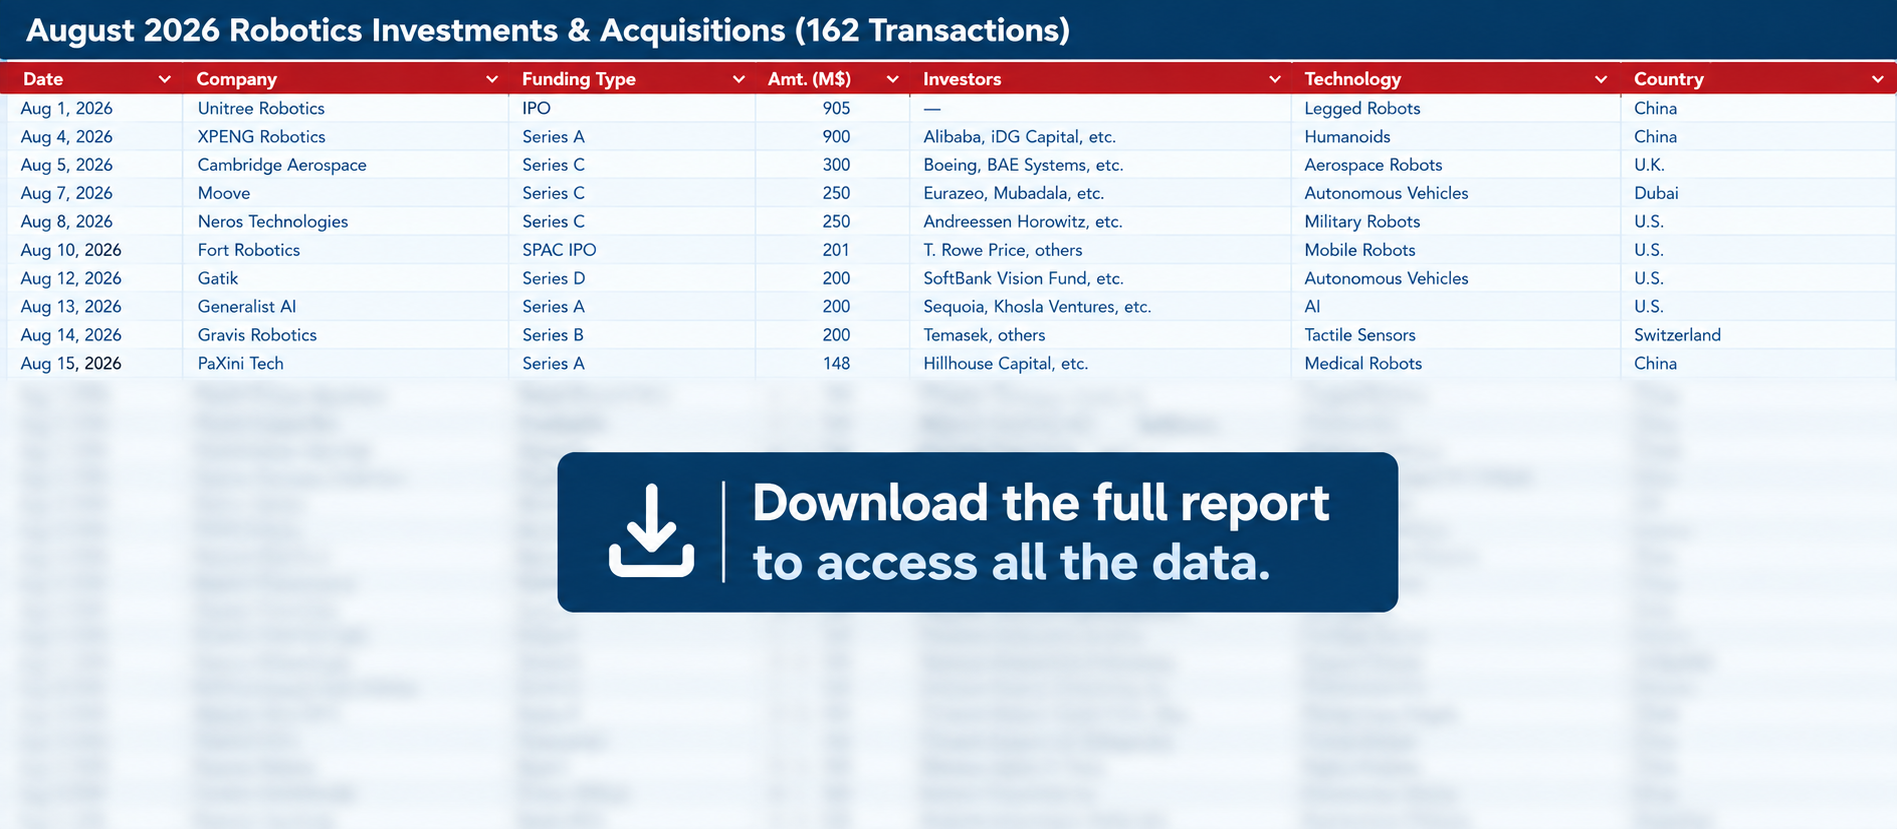
Robotics investments reach $4.9B in August 2026
The August 2026 Robotics Investments Report includes a table with all 162 investments rounds, complete with breakdowns by technology, country, funding stage, an…
Curvature-aware Expected Free Energy as an Acquisition Function for Bayesian Optimization
arXiv:2603.26339v2 Announce Type: replace-cross Abstract: We propose an Expected Free Energy-based acquisition function for Bayesian optimization to solve the j…
ActiveScale: Scaling Active Perception for Robots across Model, Data, and Hardware
arXiv:2609.18514v1 Announce Type: new Abstract: Active perception is essential for robotic manipulation when fixed viewpoints leave task-relevant information oc…