Companies
Robotics company moves: funding rounds, product launches, partnerships, acquisitions and market entries.
Robotics company moves: funding rounds, product launches, partnerships, acquisitions and market entries.
Latest in Companies
335 storiesTaPeR: Probabilistic Recovery of Sparse Task Precedence Graphs from a Handful of Demonstrations
arXiv:2608.21035v1 Announce Type: new Abstract: Long-horizon manipulation tasks are often only partially ordered. For example, when assembling an electronic dev…
Hybrid Roller-Jamming Gripper for Object Acquisition and Retention Under Pose Uncertainty
arXiv:2608.20962v1 Announce Type: new Abstract: In household manipulation, pose uncertainty often results in off-centre or partial initial contact, making relia…
Multi-Tool Robotics Enables In-Situ Sample Manipulation for Time-Resolved Synchrotron Measurements
arXiv:2608.19280v1 Announce Type: cross Abstract: The high photon flux at synchrotron beamlines allows for the measurement of fast dynamical processes. However,…
DiffDef: A Diffusion Model for Generating Multimodal Goal Shapes From Demonstrations for Deformable Object Manipulation
arXiv:2506.18779v2 Announce Type: replace Abstract: Deformable object manipulation is a key capability in many robotic applications. A promising paradigm for th…
UAV-Based Infrastructure Inspections: A Literature Review and Proposed Framework for AEC+FM
arXiv:2601.11665v3 Announce Type: replace-cross Abstract: Unmanned Aerial Vehicles (UAVs) are transforming infrastructure inspections in the Architecture, Engin…
Reconstruction of continuum robots by marker-free shape registration of image data using a kinematic model
arXiv:2405.15336v2 Announce Type: replace Abstract: Continuum robots are slender, flexible manipulators that navigate confined, curved workspaces and are gainin…

Pudu Robotics launches new MP2000 autonomous forklift
Pudu Robotics has launched the MP2000, an AI-native autonomous robot designed to transport 2,000 kg loads across complex warehouse environments. The post Pudu R…
Optimal control of a swimming robot based on Purcell's microswimmer model
arXiv:2608.17455v1 Announce Type: cross Abstract: Purcell's swimmer is a well-known planar model of a swimming microorganism, governed by low Reynolds number hy…
tinyDSM: A Framework for Skill Modeling and Development for Resource-Constrained Millirobots
arXiv:2608.17596v1 Announce Type: new Abstract: In this study, we investigate developmental mechanisms that enable small, resource-constrained systems such as c…
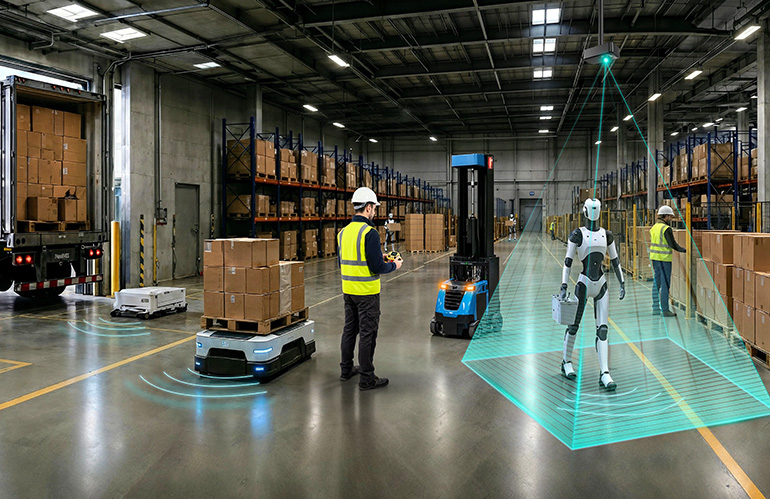
FORT Robotics to take safety stack public via SPAC merger
FORT Robotics said it expects valuation of more than $500 million as it lists on Nasdaq with plans to accelerate safety software development. The post FORT Robo…
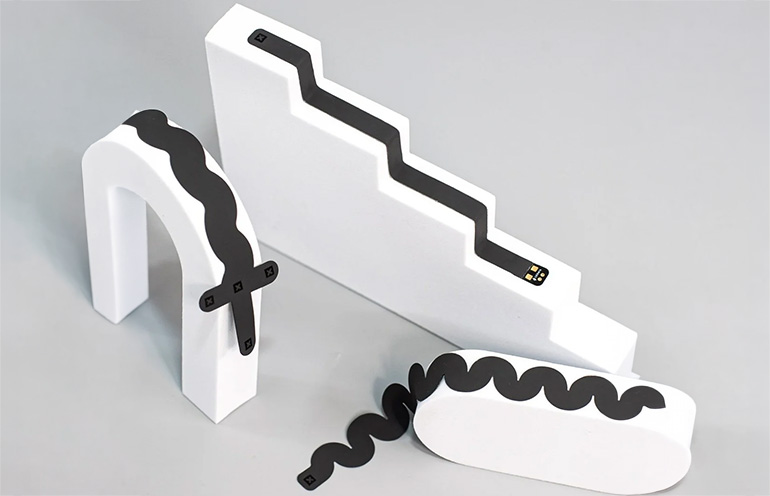
Unichem acquires Loomia to accelerate entry into the humanoid ‘skin’ market
Automotive suppliers Unichem and R&Y are working with Loomia to develop tactile sensors for automotive and robotics applications. The post Unichem acquires…
Morphology-Conditioned World Model for Cross-Embodiment Quadrupedal Locomotion
arXiv:2604.08780v2 Announce Type: replace Abstract: World models promise a paradigm shift in robotics, where an agent learns the physics of its environment once…
I-Perceive: A Foundation Model for Active Perception with Language Instructions
arXiv:2603.00600v2 Announce Type: replace Abstract: Active perception - the ability of a robot to proactively select viewpoints to acquire task-relevant informa…
MiDAS: A Multimodal Data Acquisition System and Dataset for Robot-Assisted Minimally Invasive Surgery
arXiv:2602.12407v3 Announce Type: replace Abstract: Background: Robot-assisted minimally invasive surgery (RMIS) research increasingly relies on multimodal data…
Neurosymbolic Embodied Agents
arXiv:2608.16794v1 Announce Type: new Abstract: Language and vision-language models generate plausible embodied plans but do not guarantee executability, as the…
US-VLA: An Ultrasound Vision-Language-Action Model for Embodied Abdomina
arXiv:2608.16074v1 Announce Type: new Abstract: Artificial intelligence-assisted ultrasound scanning enhances diagnostic reliability and efficiency by providing…
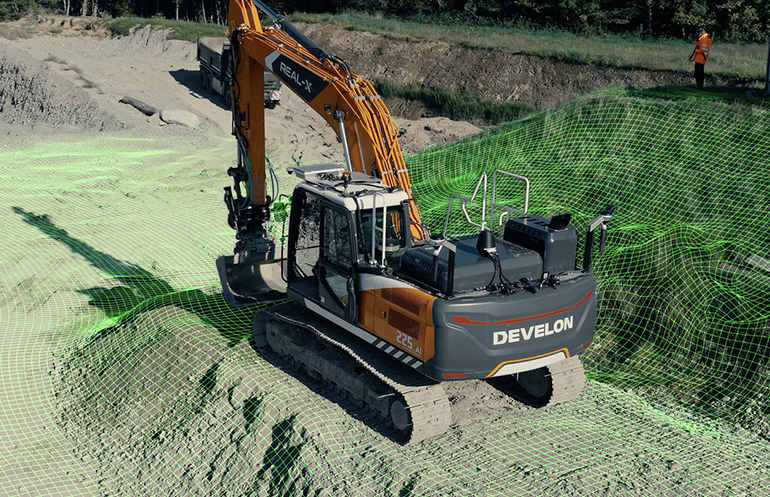
Gravis Robotics raises $200M for autonomous construction
Gravis Robotics has designed autonomy AI and hardware for a wide range of excavators and construction equipment and plans to scale globally. The post Gravis Rob…
CORAL: Curriculum-Optimized Reward Adaptation for LiDAR-Based Goal-Directed Urban Driving
arXiv:2608.14332v1 Announce Type: new Abstract: Reinforcement learning is promising for autonomous urban driving, but long-horizon goal-directed navigation asks…
Graph-MambaNav: Spatial-Temporal Graph Mamba Leveraging Object-Relation Knowledge for Object-Goal Navigation
arXiv:2608.13723v1 Announce Type: new Abstract: Object-goal navigation requires an agent to reason over object relationships and prioritize target-relevant obje…
MMUSV-Sim: A Perception-Oriented Simulation and Data-Generation Platform for Multi-USV Cooperative Perception
arXiv:2608.14207v1 Announce Type: new Abstract: Cooperative perception among multiple unmanned surface vehicles (USVs) combines complementary observations to ex…

Neros Technologies raises $250M to deploy its defense drones by the end of 2026
Neros is developing its Archer AI and Bandit platform with the hardware and compute required for multi-asset control. The post Neros Technologies raises $250M t…
FUSE: Active Functional Affordance Grounding through Adaptive Semantic-Geometric Evidence Acquisition
arXiv:2608.12683v1 Announce Type: new Abstract: Embodied agents must often identify and interact with objects based on their function rather than their identity…
OpenRC: An Open-Source Robotic Colonoscopy Framework for Multimodal Data Acquisition and Autonomy Research
arXiv:2604.03781v2 Announce Type: replace Abstract: Colorectal cancer screening critically depends on colonoscopy, yet existing platforms offer limited support …
From Self-Normal-Positioning to Omni-Directional Tracking: Real-Time Surface Modeling Enabled Probe Tilt Control for Robotic Ultrasound Imaging
arXiv:2608.11409v1 Announce Type: new Abstract: Ultrasound (US) provides real-time, radiation-free imaging, but the image quality depends strongly on how the pr…
First-order friction models with bristle dynamics: lumped and distributed formulations
arXiv:2602.09429v3 Announce Type: replace-cross Abstract: Dynamic models, particularly rate-dependent models, have proven effective in capturing the key phenome…
Synchronizing Beliefs with Second-Order Theory-of-Mind in Human-Autonomy Teams (Extended Version)
arXiv:2608.11229v1 Announce Type: cross Abstract: Comparative feedback, asking people which of two behaviors they prefer, has become a standard way to align rob…
HandEdit: A Unified Benchmark for Egocentric Human-to-Robot Dexterous Hand Image Editing
arXiv:2608.12122v1 Announce Type: new Abstract: Robotic manipulation with dexterous hands is a cornerstone of Embodied AI, yet its progress is stifled by the hi…
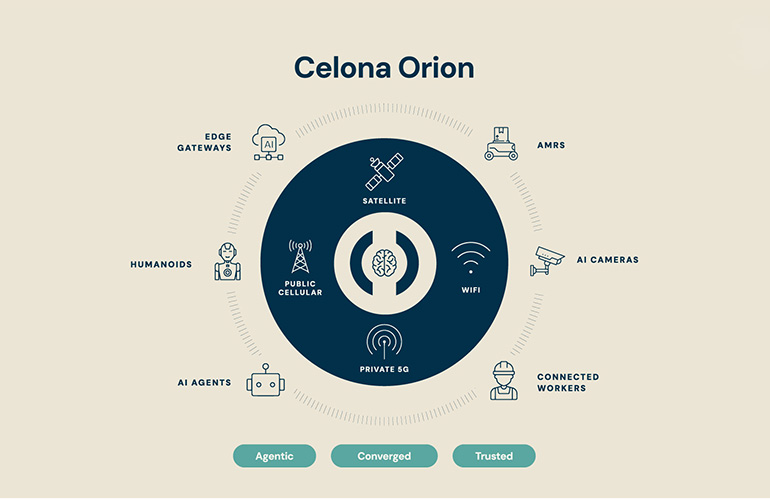
Celona launches Orion agentic wireless platform built for physical AI and robotics
Celona launched Celona Orion, a unified agentic platform merging private 5G, Wi-Fi, cellular, and satellite into one network for physical AI. The post Celona la…
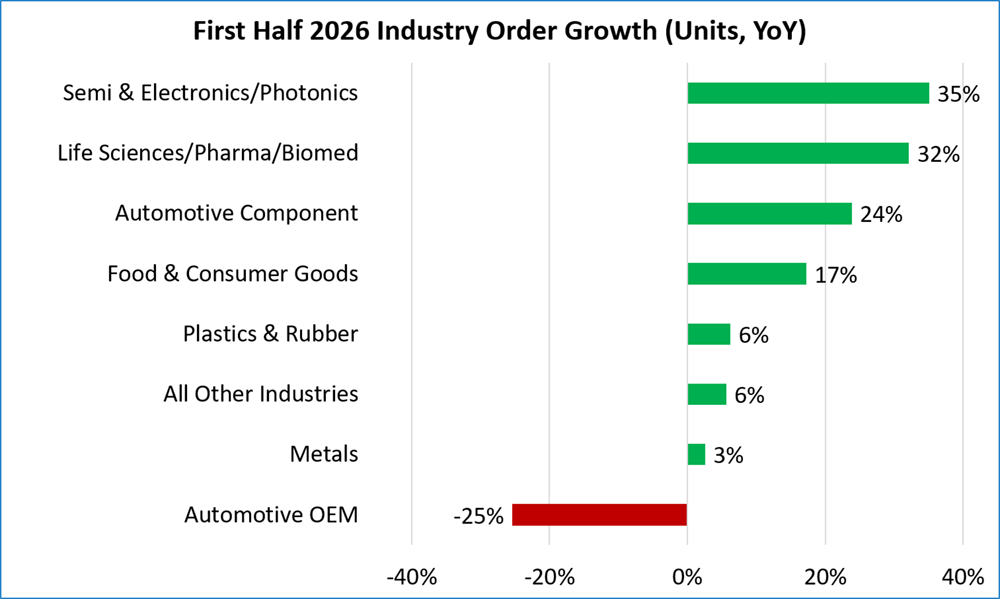
Q2 2026 robotics demand increased across industries, reports A3
A3 said that Q2 2026 robotics orders in food, electronics, and healthcare helped offset soft demand from automotive manufacturing. The post Q2 2026 robotics dem…
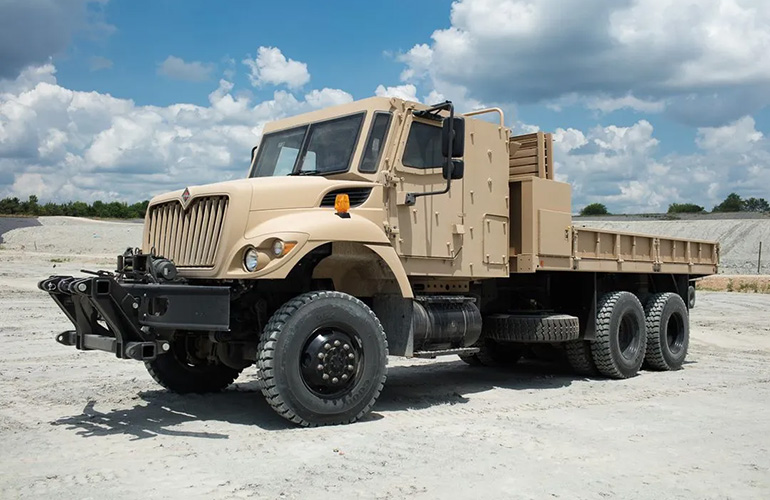
Strengthening U.S. Army sustainment: TALUS to deliver autonomous distribution
A Stratom-led team won a U.S. Army contract to develop TALUS, an autonomous logistics system for contested environments. The post Strengthening U.S. Army sustai…