Research
Frontier robotics research: arXiv cs.RO papers, embodied AI, VLA models, manipulation, navigation and learning systems.
Frontier robotics research: arXiv cs.RO papers, embodied AI, VLA models, manipulation, navigation and learning systems.
Latest in Research
6273 storiesPACE: Perceived-Latency-Aware Cascading Service Routing and Filler Control for QoE-Efficient Retrieval-Augmented Dialogue Serving
arXiv:2609.10372v1 Announce Type: cross Abstract: We present the PACE, a framework for retrieval-augmented dialogue serving that formalizes Perceived Time-to-Fi…
Frame-Coded Legged Locomotion over Noisy Terrain
arXiv:2609.10273v1 Announce Type: cross Abstract: Open-loop multilegged locomotion over rough terrain has been interpreted as matter transport over a noisy chan…
Belief-State Engine: Augmenting LLMs for Principled Planning Under Partial Observability
arXiv:2609.10036v1 Announce Type: cross Abstract: Large language model agents produce fluent action sequences across a wide range of tasks, yet they fail in cha…
Time-Frequency Geometric Cross-Attention for Chunked Vision-Language-Action Models
arXiv:2609.09925v1 Announce Type: cross Abstract: Modern vision-language-action (VLA) policies predict a whole chunk of actions: one to two seconds of coordinat…
CLFTv2: Efficient Camera-LiDAR Fusion for Semantic Segmentation via Hierarchical Feature Pyramids
arXiv:2609.09881v1 Announce Type: cross Abstract: Semantic segmentation for autonomous driving requires reliable detection of vulnerable road users (VRUs) despi…
Deformable Object Manipulation under Partial Observability via Real-Time Full-Shape Estimation
arXiv:2609.10308v1 Announce Type: new Abstract: Manipulating deformable objects (DOs) is challenging due to their high-dimensional state space, underactuated dy…
SwingBot: Learning Whole-Body Brachiation for Humanoid Robots
arXiv:2609.10283v1 Announce Type: new Abstract: Brachiation enables primates to move across overhead supports when ground paths are blocked, suggesting a comple…
FolDeX: A Physical-World Benchmark for Long-Horizon Robotic Manipulation of Deformable Objects
arXiv:2609.10243v1 Announce Type: new Abstract: Embodied AI, including vision-language-action and world-action models, must operate reliably in the physical wor…
Adaptive Shared Control with Online Bounded-Rational Human Behavior Estimation
arXiv:2609.10215v1 Announce Type: new Abstract: This work considers adaptive shared human-robot control for nonlinear control-affine systems, where the assumpti…
Multi-Robot Scanner for Automated Full-Body Dermoscopic Imaging
arXiv:2609.10169v1 Announce Type: new Abstract: This paper outlines the specifications and design approach used to construct a full body imaging scanner capable…
Future-Aware Flow Planning for Safe UAV Target Following
arXiv:2609.10166v1 Announce Type: new Abstract: UAV target following in cluttered environments is inherently predictive: current-state followers can lag behind …
Assembling Two Parts in One Hand
arXiv:2609.10137v1 Announce Type: new Abstract: A hallmark of human dexterity is the cooperative use of fingers, where different fingers take on distinct yet co…
Automatic Reproducible Camera Intrinsic Calibration
arXiv:2609.10082v1 Announce Type: new Abstract: Accurate camera intrinsic calibration is fundamental to robot perception, and the accuracy depends on the qualit…
Grounding Generated Video Plans in Simulation Towards Versatile Dexterous Controllers
arXiv:2609.10050v1 Announce Type: new Abstract: Generated hand-object interaction (HOI) videos provide a controllable way to propose manipulation motions. Simul…
What Symmetry Buys a Learned Motion Planner
arXiv:2609.10033v1 Announce Type: new Abstract: Learning-based motion planners pay at training what classical planners pay per query. Trained in world coordinat…
RoboDrop: Curating VLA Post-Training Data via Local Gradient Compatibility
arXiv:2609.10021v1 Announce Type: new Abstract: Vision--language--action (VLA) models acquire broad generalization through large-scale pretraining, yet adapting…
HaWMPO: Hallucination-Aware World Model-based Policy Optimization for Generalist Robot Policy
arXiv:2609.09941v1 Announce Type: new Abstract: Generalist robot policies have demonstrated strong generalization across robotic manipulation tasks, yet their s…
ViBe: Visual Behavior Adaptation for Perceptive Humanoid Whole-Body Control
arXiv:2609.09918v1 Announce Type: new Abstract: Motion tracking provides a scalable recipe for humanoid whole-body control. By design, the resulting trackers la…
PccDiffuser: Multi-solution Motion Planning for Continuum Robots
arXiv:2609.09745v1 Announce Type: new Abstract: We present the PccDiffuser, a conditional diffusion framework for continuum robots that learns a multimodal dist…
A Risk-Sensitive and Uncertainty-Aware Decision-Making and Control Framework for Safe and Robust Autonomous Driving
arXiv:2609.09650v1 Announce Type: new Abstract: Reinforcement learning (RL) has demonstrated considerable potential for autonomous driving decision-making. Howe…
JEPA Policy: Diffusion-Free Imitation Learning via Paired Action and Future Representation Prediction
arXiv:2609.09630v1 Announce Type: new Abstract: Standard behavior cloning supervises actions without explicitly constraining the future representation paired wi…
PGMT: Perceptive General Motion Tracking for Humanoid Robots
arXiv:2609.08511v2 Announce Type: replace Abstract: Humanoid motion trackers can reproduce diverse whole-body motions, but their performance degrades on complex…
Meta-RL with Bayesian Linear Task Models
arXiv:2512.20974v4 Announce Type: replace-cross Abstract: Deep Bayesian reinforcement learning adapts to unseen tasks by inferring latent transition and reward …
FiberTune: Preserving Action-Fiber Visual Residuals in Vision-Language-Action Fine-Tuning
arXiv:2606.08653v2 Announce Type: replace-cross Abstract: Action-supervised fine-tuning of vision-language-action (VLA) policies fits demonstrations effectively…
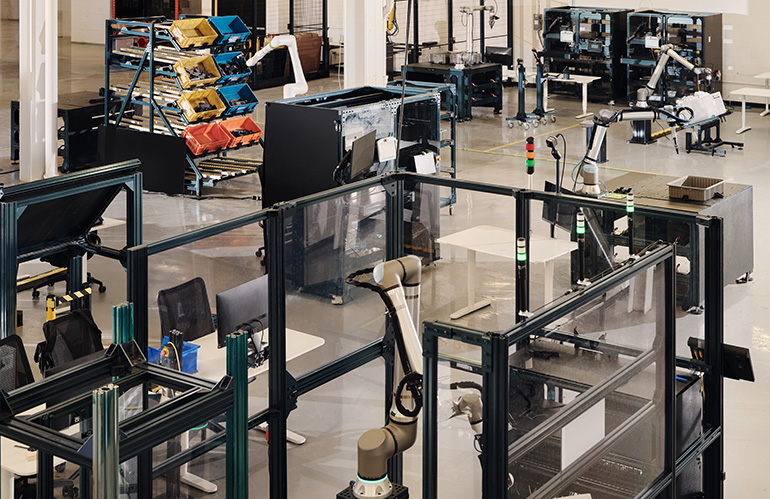
Vention opens Physical AI Lab for manufacturing in Montreal
Vention's new Physical AI Lab will focus on advancing robotic manipulation from research to scalable production-line deployment. The post Vention opens Physical…
Alignment Under Pressure: AR-HMD Support Tools for Action Teams
arXiv:2502.17295v2 Announce Type: replace-cross Abstract: Team communication breakdowns represent a contributor to patient safety risks within action teams-defi…
APEX-RBD: Mixed-Precision Exploration Framework for Hardware-Efficient Robot Dynamics Accelerator Design
arXiv:2609.05161v1 Announce Type: cross Abstract: Rigid Body Dynamics (RBD) forms the computational core of real-time robotic control, but its immense computati…
One Diffusion Model, Two Roles: Guided Trajectory Planning and Safety-Critical Scenario Generation in Closed-Loop Simulation
arXiv:2609.04921v1 Announce Type: cross Abstract: Diffusion probabilistic models can capture the multi-modal, interaction-rich distribution of joint future traj…
Dual-Part Multi-Lateral Branched Network for Multi-Class Segmentation in Cardiovascular Catheterization Angiograms
arXiv:2609.04590v1 Announce Type: cross Abstract: Catheterisation image processing requires segmentation models that are fast, accurate and explainable. While m…
Achieving Asymptotic Near-Optimality Without $\delta$-Similarity
arXiv:2609.04464v1 Announce Type: new Abstract: Sampling-based motion planning algorithms are a popular class of trajectory planning algorithm due to their spee…