News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4147 storiesPACE: Persona Adaptation through Conversational Elicitation in Human-Robot Interaction
arXiv:2607.15579v1 Announce Type: new Abstract: Equipping humanoid robots with coherent and adaptable personas is crucial for fostering natural, engaging, and t…
Passive Phase-Oriented Impedance Shaping for Rapid Acceleration in Soft Robotic Swimmers
arXiv:2603.03537v2 Announce Type: replace Abstract: Rapid acceleration and burst maneuvers in underwater robots depend less on maintaining precise resonance and…
Learning a System-Level Surrogate for Hydraulic Excavators: A Simulation-to-Real LSTM Approach
arXiv:2607.15656v1 Announce Type: new Abstract: Developing autonomous hydraulic excavators is constrained by limited access to physical machines and the high co…
A Task-Space Receding Horizon Controller for Fast Collision Avoidance
arXiv:2607.15733v1 Announce Type: new Abstract: Real-time collision avoidance for robotic manipulators requires fast reactions to unexpected obstacle motion and…

How to avoid the teleoperation trap in robotics development
Teleoperation is necessary for training humanoid robots, but reinforcement learning and simulation are still necessary, says Flexion's CEO. The post How to avoi…

Palm Garden AI develops Coherence Guard relational decision layer for human-facing robots
Palm Garden AI is developing a hardware-agnostic software layer, including Coherence Guard, for human-robot interaction and relationships. The post Palm Garden …

Weave Robotics launches Isaac, its first mobile humanoid robot
Weave Robotics has listed the features of its Isaac wheeled bimanual manipulator robot for household and office use. The post Weave Robotics launches Isaac, its…

Founder of Maximo discusses how robotics is accelerating solar construction
Maximo founder Deise Yumi Asami discusses the process of automating solar construction with robotics. The post Founder of Maximo discusses how robotics is accel…
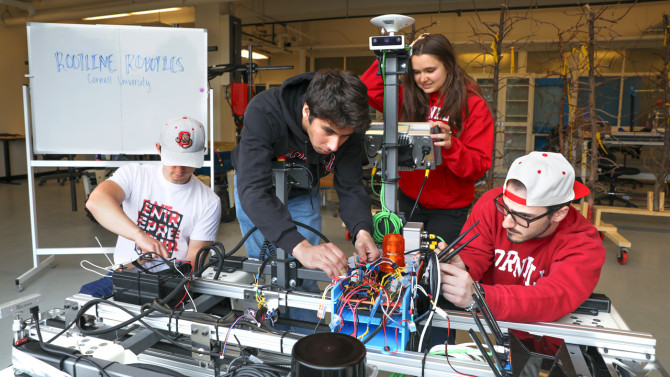
Undergrads’ weed-killing robot wins top prize
Andrew James (from left), Neil Morrison, Natalia Kurz and Michael Neiss work on a prototype of their weed-killing robot ahead of The Farm Robotics Challenge, wh…

With new funding, Monumental plans to bring its construction robots to the U.S.
Monumental acts as a subcontractor during construction tasks. Contractors pay the company for finished walls rather than for robots. The post With new funding, …
Assessing Physical Frailty and Fall-Risk Indicators with Social Robots: An in situ Evaluation with Older Adults
arXiv:2607.15156v1 Announce Type: new Abstract: Frailty assessments are crucial to evaluate the risk of adverse events and the health and social care needs of o…
Semantic Audio-driven Understanding for Dynamic Humanoid Whole Body Control
arXiv:2607.14182v1 Announce Type: new Abstract: Recent advances in humanoid robotics and reinforcement learning have enabled the acquisition of highly expressiv…
MIND-CAVs: Multi-Intelligence Negotiation and Decision System for CAVs based on Intent-Driven Autonomy
arXiv:2607.14688v1 Announce Type: new Abstract: Modern autonomous vehicles largely operate as isolated agents: they rely on on-board perception and decision mod…
RoboTTT: Context Scaling for Robot Policies
arXiv:2607.15275v1 Announce Type: new Abstract: Recent robot foundation models operate with single-step or short-history visuomotor context. We introduce Test-T…
UniSteer: Unified Noise Steering for Efficient Human-Guided VLA Adaptation
arXiv:2605.10821v2 Announce Type: replace Abstract: Diffusion-based vision-language-action (VLA) models have emerged as strong priors for robotic manipulation, …
Reinforcement Learning for the Full Strawberry Harvesting Process: Obstacle Separation, Detachment, and Placement
arXiv:2607.14708v1 Announce Type: new Abstract: Severe occlusions and deformable plant structures introduce complex contact dynamics that challenge robotic stra…
BridgeFlow: Fast and Robust SE(2)-Equivariant Motion Planning with Flow Matching
arXiv:2607.14725v1 Announce Type: new Abstract: In robotic motion planning, equivariance to rigid body transformations is crucial for robust spatial generalizat…
Chat2Scenic: An Iterative RAG-Based Framework for Scenario Generation in Autonomous Driving
arXiv:2607.14387v1 Announce Type: cross Abstract: Validating autonomous driving systems requires diverse, regulation-compliant test scenarios. In simulation-bas…
Lights, Camera, Malfunction: When Illumination Robustness Leaves VLA Models Blind to Color
arXiv:2607.14698v1 Announce Type: new Abstract: Vision-Language-Action (VLA) models have emerged as a powerful paradigm for general-purpose robot manipulation; …
Catch, Throw, Repeat: Planning for Human-Robot Partner Juggling
arXiv:2607.15129v1 Announce Type: new Abstract: Dynamic object exchange between humans and robots remains a challenging problem due to uncertainty in perception…
Hybrid Rigid-Soft Robotic Gripper with Shape Adaptation, Uniform Force Distribution, and Self-Locking Capabilities
arXiv:2607.14730v1 Announce Type: new Abstract: Conventional robotic grippers face a significant challenge in agricultural automation: the trade-off between com…
Towards Human-like Physical Intelligence: LifelongVision-Language-Action Learning for Robotic Manipulation
arXiv:2607.14852v1 Announce Type: new Abstract: Similar to the natural capabilities of humans to sequentially learn new tasks, robots with Vision-Language-Actio…
Scaling Behavior Foundation Model for Humanoid Robots
arXiv:2607.15163v1 Announce Type: new Abstract: Humanoid control requires natural whole-body coordination, precise real-time responses to control signals, and r…
Mixed-Agent Museum Tour Guide Design Improves Gendered Learning Outcomes and Visitor Preferences
arXiv:2607.14468v1 Announce Type: new Abstract: Robots are increasingly integrated into everyday contexts, including museums, where they can both entertain and …
An offline approach to fNIRS-guided reinforcement learning for robot behavior
arXiv:2607.14393v1 Announce Type: new Abstract: Human-in-the-loop Reinforcement Learning has become a popular approach to training, finetuning, and aligning rob…
BadWAM: When World-Action Models Dream Right but Act Wrong
arXiv:2607.15207v1 Announce Type: cross Abstract: World-action models (WAMs) are emerging as a promising foundation for embodied control: rather than predicting…
ConFlow: Constraints-Guided Learning with Flow Matching for Motion Generation
arXiv:2607.14424v1 Announce Type: new Abstract: In recent years Flow Matching has become a prominent method for generative modeling robot motion generation. In …
Active Real-World Factor-Based Evaluation for Generalist Robot Policies
arXiv:2607.14439v1 Announce Type: cross Abstract: Generalist robot manipulation policies trained on large, diverse datasets have shown remarkable promise across…
Curvature-Constrained and Constant-Speed Distributed Simultaneous Arrival Control for Multi-Robot Systems
arXiv:2607.14781v1 Announce Type: new Abstract: The simultaneous arrival of multiple mobile robots at a target point is crucial for cooperation tasks such as co…
Beyond Visual Grasping: Benchmarking Complex Grasping from Detection to Execution
arXiv:2607.14341v1 Announce Type: new Abstract: Robust robotic grasping remains a fundamental challenge for complex real-world applications. Recent advances in …