News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4146 storiesAssessing the Impact of Fleet Size on Crowdsourced Mapping Using a Dissimilarity Measure
arXiv:2609.29198v1 Announce Type: new Abstract: Accurate digital maps are essential for Advanced Driver Assistance Systems (ADAS) or Autonomous Driving (AD), pr…
BeyondRetarget: Learning Executable Humanoid Motions Directly from Monocular Video
arXiv:2609.29850v1 Announce Type: new Abstract: Learning executable motions from human videos offers a scalable solution for humanoid robots to acquire demonstr…
World Action Agent: Harnessing VLMs for Robot Manipulation via World Action Rehearsal
arXiv:2609.29964v1 Announce Type: new Abstract: General-purpose vision-language models (VLMs) bring broad knowledge and spatial reasoning to robot manipulation,…
RHINO-AR: An Augmented Reality Exhibit for Teaching Mobile Robotics Concepts in Museums
arXiv:2604.16384v2 Announce Type: replace Abstract: Understanding autonomous mobile robots is challenging for people without robotics expertise, because key pro…
SCoCaT: Success Conditioned Constrained Reinforcement Learning for Spacecraft Docking
arXiv:2609.06061v2 Announce Type: replace Abstract: Termination-based constrained reinforcement learning is attractive for safety-critical robotic deployments: …
TactileStep: Sole Tactile Learning for Regulating Foot-Terrain Interaction in Humanoid Locomotion
arXiv:2609.28959v1 Announce Type: new Abstract: Humanoid parkour policies can traverse various terrains, but task completion may mask challenges of harsh landin…
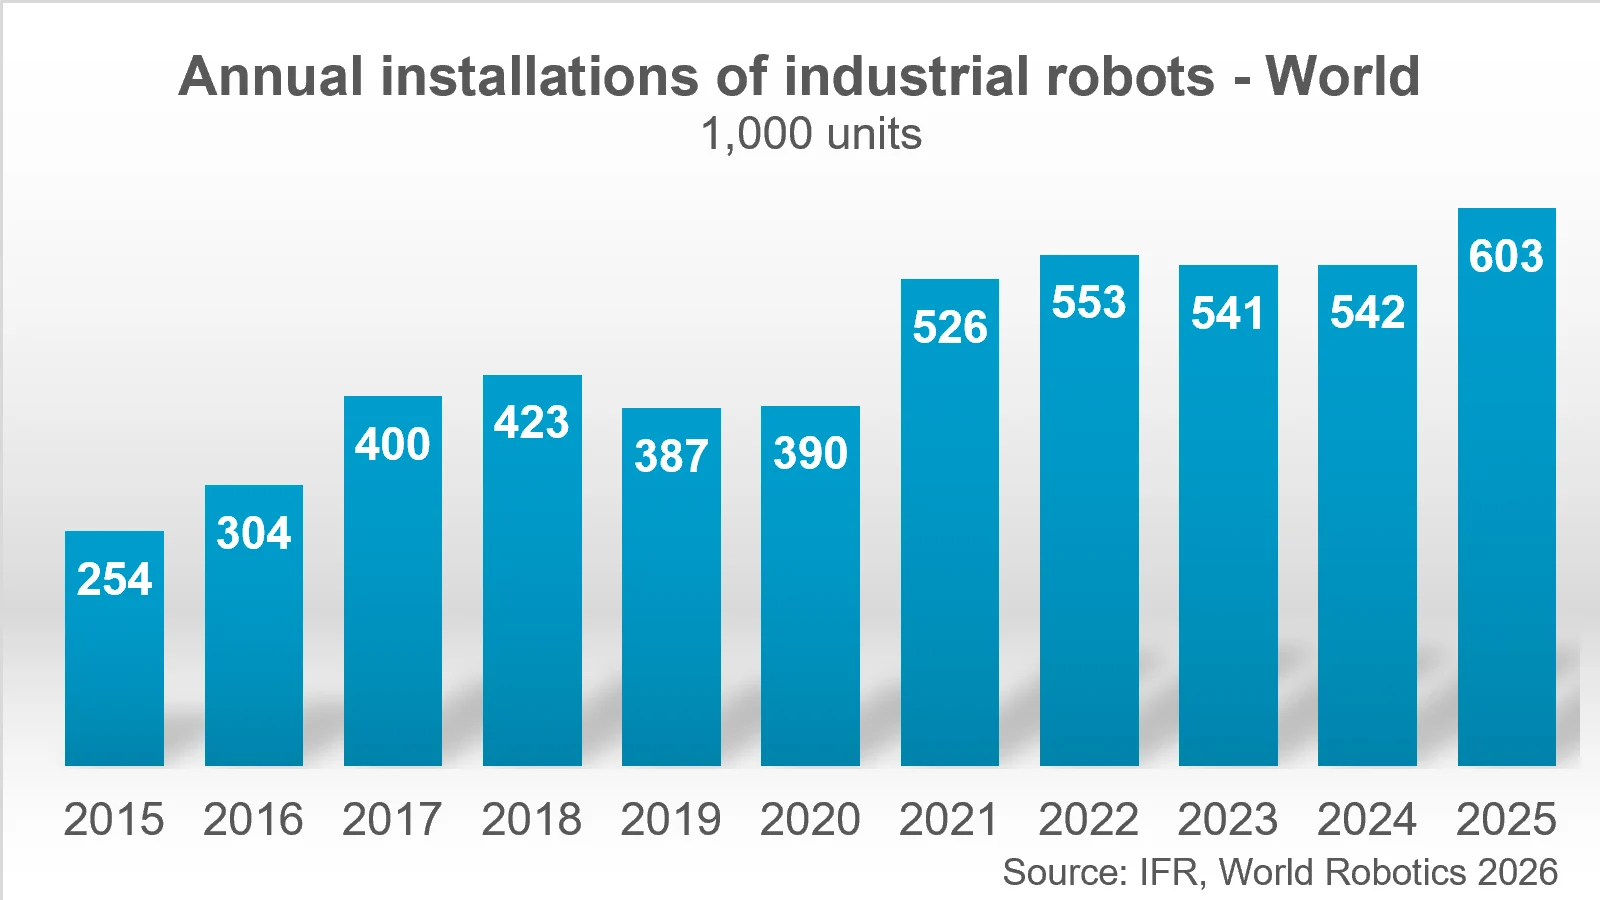
5 million robots are now at work in factories worldwide, reports the IFR
China still leads the world in industrial robot installations, but the U.S. and Germany are also significant markets, found the IFR. The post 5 million robots a…
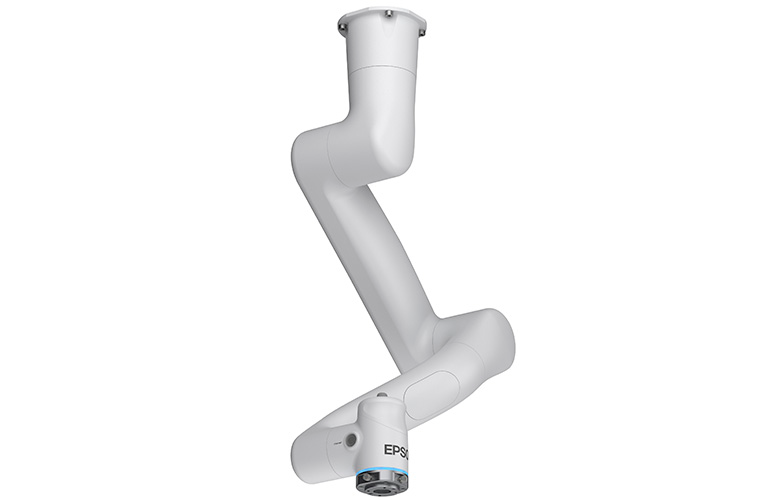
Epson introduces AX6 cobot with compact design, no-code programming
Epson Robots has expanded its six-axis robot line with the AX6, a lightweight force- and power-limited arm. The post Epson introduces AX6 cobot with compact des…
Why you should look beyond the spec sheet when choosing motion architecture
Choosing the right motion architecture is about understanding how the entire system will behave in use, explains Kollmorgen. The post Why you should look beyond…
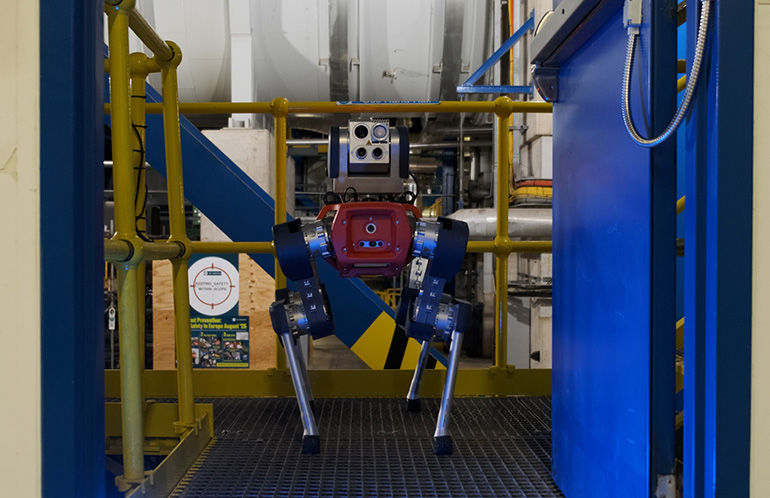
ANYbotics opens the door for inspections with ANYmal robots
ANYbotics partnered with dormakaba and LEGIC Identsystems to enable the ANYmal quadruped to gain access like a badged employee. The post ANYbotics opens the doo…
MSK-Bench: Benchmarking Full-Body Musculoskeletal Motor Control Across Tasks, Control Paradigms, and Physiological Metrics
arXiv:2609.26872v1 Announce Type: new Abstract: Musculoskeletal (MSK) humanoids provide a physiologically grounded embodiment for studying full-body motor contr…
Bend the Clock: Predicting Ahead to Beat Latency in Event-Based Object Detection
arXiv:2609.26919v1 Announce Type: new Abstract: Event cameras promise low-latency perception for high-speed robotic systems, where even short delays can render …
Humanoid Locomotion with a Fly-Inspired Recurrent Controller
arXiv:2609.27001v1 Announce Type: new Abstract: We investigate humanoid locomotion with a fly-inspired recurrent controller and identify the pathways supporting…
Learning Expressive Humanoid Locomotion from Monocular Runway Videos for Robot Fashion Shows
arXiv:2609.27003v1 Announce Type: new Abstract: Runway walking requires coordinated control of posture, stride, foot placement, and whole-body motion to effecti…
MultiPush: Learning to Rearrange with Teams of Car-Like Pushers
arXiv:2609.27005v1 Announce Type: new Abstract: We focus on the problem of rearranging multiple objects within a constrained workspace via pushing using a team …
Laser-Tracker-Assisted Camera-to-Robot Calibration for Mobile Robots
arXiv:2609.27006v1 Announce Type: new Abstract: We present a laser-tracker-assisted hand-eye calibration method for camera-equipped mobile robots. The method co…
HiRE: Hindsight Reward Editing for Policy Finetuning
arXiv:2609.27068v1 Announce Type: new Abstract: Pre-trained robot policies always require finetuning to adapt to specific environments. Reinforcement Learning (…
The Gaussian Is Enough: Flow-Matching Priors Do Not Help When Fine-Tuning Large Behavior Models
arXiv:2609.27070v1 Announce Type: new Abstract: Modern robot imitation learning increasingly relies on generative policies based on diffusion or flow-matching m…
Fast Direction-Conditioned Reachability for Motion Prediction Under Model Uncertainty
arXiv:2609.27077v1 Announce Type: new Abstract: To avoid collisions, a robot must repeatedly predict where nearby agents may move, usually with an imperfect mod…
Design and Modeling of a Single-Port Three-Arm Robotic Tool for Minimally Invasive Neurosurgery
arXiv:2609.27099v1 Announce Type: new Abstract: Surgical robots require highly dexterous and compact robotic systems capable of operating effectively within con…
Planning Trajectories that Bounce: Reflection Classes for Collision-Tolerant Robots
arXiv:2609.27145v1 Announce Type: new Abstract: Robot navigation methods tend to avoid contact, and consequently search for collision-free trajectories. For rob…
HINT-Blimp: Human INTent Inference from Multimodal Cues for Robotic Blimps
arXiv:2609.27154v1 Announce Type: new Abstract: In human-robot interaction, traditional interfaces such as joysticks and handheld tablets introduce latency into…
Fine Wrist Control as a Marker of Surgical Teleoperation Expertise
arXiv:2609.27160v1 Announce Type: new Abstract: Unlike most intensely physical pursuits, surgical robotic teleoperation training focuses primarily on task outco…
A Quasi-Direct-Drive Underactuated Asymmetric Hand for Dexterous and Efficient Grasping and Manipulation
arXiv:2609.27240v1 Announce Type: new Abstract: In this paper, we present the Berkeley QUAD (Quasi-direct-drive, Underactuated, Asymmetric Design) Hand, a four-…
Memory That Changes Action Is Not Memory That Guides It: Counterfactual Auditing of History-Conditioned Robot Policies
arXiv:2609.27247v1 Announce Type: new Abstract: A robot returning a block to its origin tray may encounter two task-consistent pasts that reconverge to the same…
Banana Kick: Response-Informed Skill Evolution for Humanoid Soccer
arXiv:2609.27269v1 Announce Type: new Abstract: Humanoid kicking requires coordinated whole-body motion and precise contact, while a banana kick demands contact…
BranchDrive: A Branch-Structured Dataset for Action-Conditioned Driving Prediction
arXiv:2609.27275v1 Announce Type: new Abstract: Most autonomous-driving datasets record only the action executed by a behavior policy and the single future that…
EmbodiedSWE: Coding Agents for Long Horizon Dexterous Robotics
arXiv:2609.27308v1 Announce Type: new Abstract: We study coding agents for long-horizon, dexterous robotics and ask whether their solutions can provide scalable…
Turning Safety into Competence: Minimally Exploitable Robot Policies via Safety-Filtered Reinforcement Learning
arXiv:2609.27312v1 Announce Type: new Abstract: Robots deployed for competitive tasks must outmaneuver their opponents without sacrificing safety. Existing appr…
Spatial and Semantic Reasoning for LLM-Driven Robot Navigation via MCP
arXiv:2609.27340v1 Announce Type: new Abstract: Large language models (LLMs) are increasingly used as natural-language interfaces for robotic systems, yet their…