News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4147 storiesMR-GLi: Mixed Reality-Based Gripper-Linked Overlays for Underwater Robot Arm Teleoperation via Bilateral Control
arXiv:2609.16041v1 Announce Type: new Abstract: Visual torque feedback supports underwater bilateral teleoperation, but the benefit of mixed reality (MR) over c…
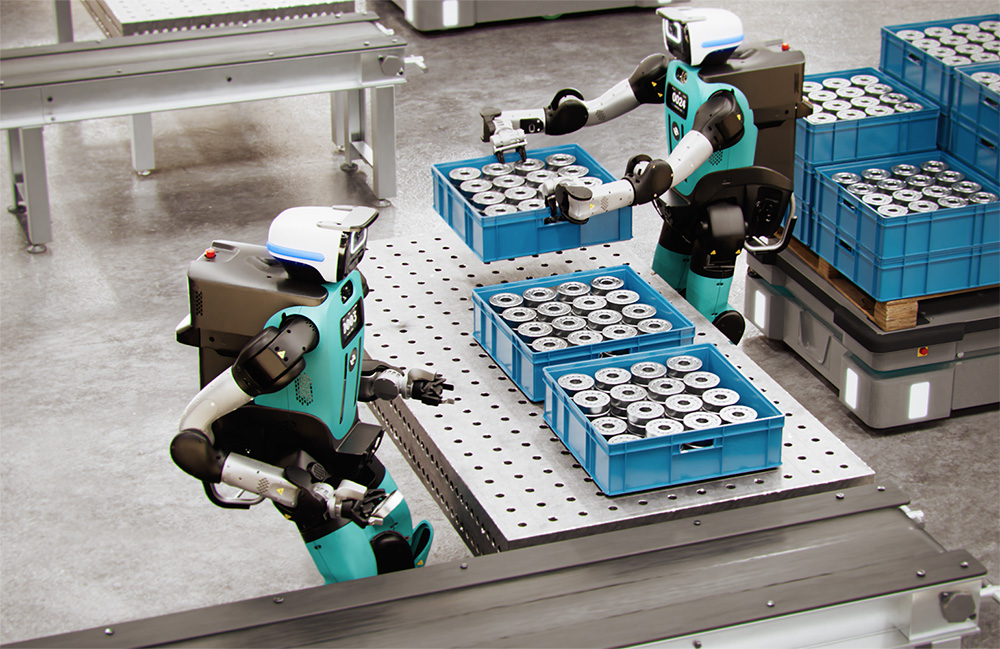
Agility’s Digit 5 humanoid has new legs, batteries and safety upgrades
The latest version of Digit includes new knees, upgraded batteries, and more comprehensive safety architecture. The post Agility’s Digit 5 humanoid has new legs…
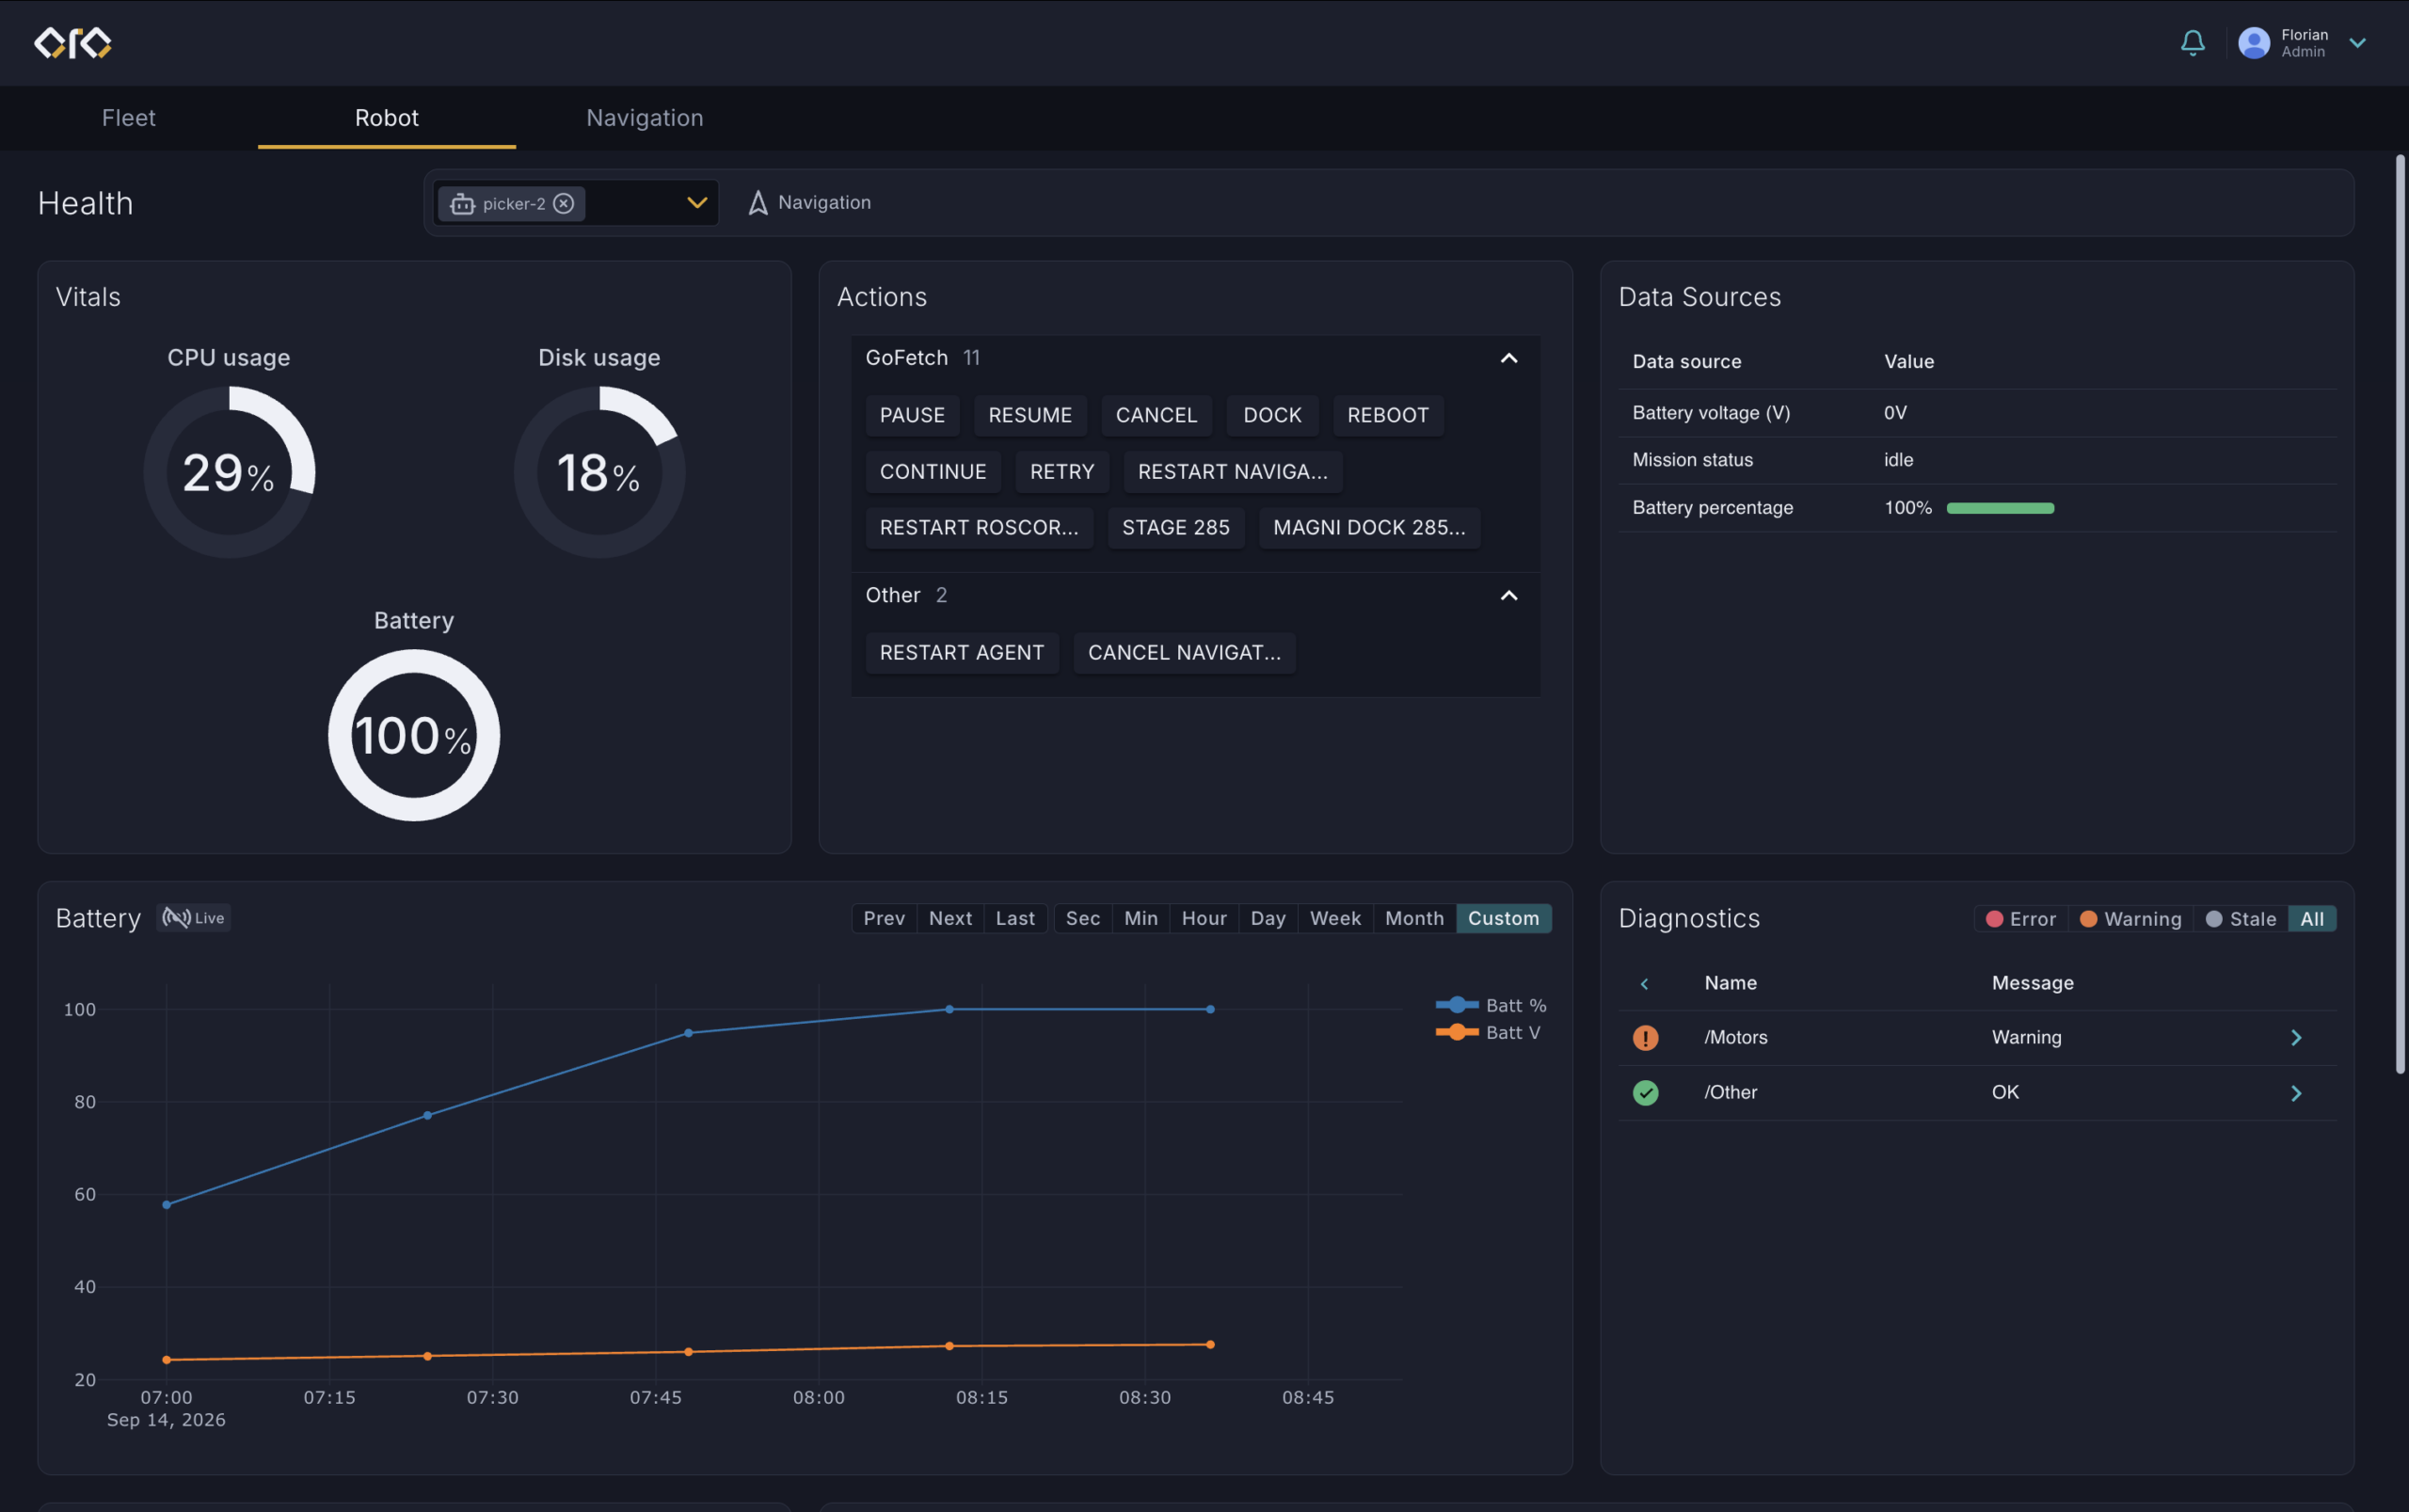
InOrbit.AI releases OpenRobOps ISO 21423 reference implementation
OpenRobOps gives robotics developers a foundation to deliver a fleet manager with support for the upcoming interoperability standard. The post InOrbit.AI releas…
Gradient-Free Neural Hamilton-Jacobi Reachability for Scalable Safety-Critical Control
arXiv:2609.14087v1 Announce Type: new Abstract: Hamilton-Jacobi (HJ) reachability provides a principled framework for synthesizing safety certificates and robus…
VGFM: Expressive Robot Policies via Dense Value Guidance in Flow Matching
arXiv:2609.14261v1 Announce Type: new Abstract: Recent robot learning paradigms increasingly rely on large offline datasets of robotic interactions to train con…
Orientation Control of Soft Robots via Adiabatic Spectral Submanifolds
arXiv:2609.14376v1 Announce Type: new Abstract: Soft robots are commonly sought for safety-critical interactions in delicate environments, where accurate positi…
From Learned-Mode AV-Traffic Pairing to Planner Decisions: A Marginal-Preserving Study on Argoverse 2
arXiv:2609.14997v1 Announce Type: new Abstract: Joint motion forecasts pair each autonomous-vehicle (AV) future with surrounding traffic, but actor-level metric…
LieSpline-DP: Lie-Group B-Spline Diffusion Policy for Smooth Robot Manipulation
arXiv:2609.15162v1 Announce Type: new Abstract: Diffusion Policy (DP) is a powerful Learning from Demonstration (LfD) method for robotic manipulation, yet it su…
X-WBC: A Cross-Embodiment Foundation Model for Humanoid Whole-Body Control
arXiv:2609.15213v1 Announce Type: new Abstract: Scaling humanoid whole-body control toward general-purpose deployment requires large human motion corpora and tr…
InterSocialBench: Benchmarking Human and LLM Preferences for Companion-Robot Social Behavior
arXiv:2609.15455v1 Announce Type: new Abstract: Companion robots face everyday situations in which several feasible behaviors may be appropriate, yet different …
P-POSEMEM: Projective Semantic Memory for Consistent Language Grounding under Pose-Graph Rewrites
arXiv:2609.15475v1 Announce Type: new Abstract: A robot following language instructions needs its semantic memory to keep naming the same physical object while …
StereoPatch: Patch-Aligned RGB-Depth Fusion for Spatial Perception in Robot Manipulation
arXiv:2609.15509v1 Announce Type: new Abstract: Recent advances in robot imitation learning have produced visuomotor policies that predict actions directly from…
DIDO: Distilling Interaction-Centric Dynamics into One-Step Denoising for World Action Models
arXiv:2609.15570v1 Announce Type: new Abstract: World Action Models (WAMs) use video generation models to predict future visual dynamics for robotic manipulatio…
An Information-Space Perspective to Scene Graph Sufficiency for Robotic Task Planning
arXiv:2609.15587v1 Announce Type: new Abstract: Planning in complex environments requires task specifications grounded in representations that capture objects, …
Uncertainty-Guided Sparse Refinement for Action Chunking Transformer Policies
arXiv:2609.15840v1 Announce Type: new Abstract: Learning chunk-based visuomotor policies for long-horizon robot manipulation remains challenging. Recent action-…
Real-time Learning and Evolution in Robotic Art Installations
arXiv:2609.13352v1 Announce Type: cross Abstract: We present three robotic art installations which explore the aesthetics of adaptive behavior. Through embodied…
Real-Time Synthesis of Robust Controlled Invariant Sets for Monotone Systems
arXiv:2609.14115v1 Announce Type: cross Abstract: Safety-critical control of autonomous systems requires formal safety certificates, such as controlled invarian…
S3-Tracker: Self-Supervised Surgical Tissue Tracking With Contrastive Random Walks
arXiv:2609.14313v1 Announce Type: cross Abstract: Robust point tracking in endoscopic videos is essential for computer-assisted intervention and autonomous robo…
PredTac: Learning Contact-Rich Manipulation with Predicted Touch
arXiv:2609.15198v1 Announce Type: new Abstract: Contact-rich manipulation benefits from tactile feedback, yet physical tactile sensors introduce hardware, calib…
C$^2$Nav: Compare Before You Commit for Zero-Shot Vision-and-Language Navigation
arXiv:2609.15142v1 Announce Type: new Abstract: Zero-shot vision-and-language navigation in continuous environments (VLN-CE) increasingly places foundation visi…
Legislating World-Model-Based Planning with Legal Reasoning
arXiv:2609.15113v1 Announce Type: new Abstract: As robotic systems grow more general, legal norms are needed to integrate them into society. This paper extends …
HydroMap: Probabilistic Water Surface Elevation Mapping for Semantic Scene Representation in Inland Waterways
arXiv:2609.14903v1 Announce Type: new Abstract: Autonomous surface vehicles operating in inland waterways require a persistent representation of both surroundin…
Understanding User Preferences of a Slope-Aware Variable-Admittance Filter for a Robot Guide Dog
arXiv:2609.15362v1 Announce Type: new Abstract: This letter investigates how the parameters of a slope-aware variable-admittance filter influence user preferenc…
Tracking the Ground: Online Lidar Identification of Robot-Induced Soil Deformation in Agricultural Environments
arXiv:2609.15667v1 Announce Type: new Abstract: Agriculture faces many challenges, and robotic systems can play an important role in addressing them by improvin…
On-Demand Human Assistance for Task Continuation under Physical Action Failures in LLM-based Planning
arXiv:2603.28156v2 Announce Type: replace Abstract: While robot action planning based on large language models (LLMs) has advanced remarkably, continuing a task…
Compositional Shift Algebra: Extrapolating Mixed Robot Shifts Without Mixed Finetuning
arXiv:2609.13651v1 Announce Type: new Abstract: Robot deployments rarely change one mechanism at a time: cameras, action interfaces, and physical dynamics often…
From Vision to Harvest: Benchmarking Vision-Language Models for Multi-Arm Robotic Fruit Harvesting
arXiv:2609.13606v1 Announce Type: new Abstract: Multi-arm robotic harvesting offers a promising path to improve harvesting efficiency and reduce reliance on man…
Distributed Safe Cooperative Vector Field for Trajectory Curvature Constrained Multi-Robot Systems
arXiv:2609.15266v1 Announce Type: new Abstract: Trajectory curvature constraints are inherent in practical multi-robot systems due to the limited turning capabi…
A Vision Based Framework Integrating Attention and Action Cues for Interpretable Cognitive Workload Assessment in Human Robot Collaborative Assembly
arXiv:2609.15232v1 Announce Type: new Abstract: The introduction of human-robot collaboration (HRC) in industrial assembly operations is revolutionizing the man…
Runtime-Incremental Transformer for Reinforcement-Learning-Based Adaptive Control
arXiv:2609.13545v1 Announce Type: new Abstract: Learning-based adaptive control of robotic manipulators with non-observable friction memory has been addressed b…