News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4147 storiesDetAug: Obstacle-Blind Trajectory Augmentation for Zero-shot Obstacle Avoidance
arXiv:2609.18395v1 Announce Type: new Abstract: Policies for robotic manipulation are produced by training on large teleoperated datasets. These datasets typica…
ForwardDLO: Model-Based Bimanual Shape Matching of Unconstrained Deformable Linear Objects
arXiv:2609.18455v1 Announce Type: new Abstract: Ropes, cables, and other deformable linear objects appear in tasks from untangling to cable routing and suturing…
TAO-Force: Unifying Force-Aware Perception and Fast-Slow Control for Contact-Rich Manipulation
arXiv:2609.18497v1 Announce Type: new Abstract: Vision-Language-Action (VLA) models have demonstrated strong performance across diverse robotic manipulation tas…
ActiveScale: Scaling Active Perception for Robots across Model, Data, and Hardware
arXiv:2609.18514v1 Announce Type: new Abstract: Active perception is essential for robotic manipulation when fixed viewpoints leave task-relevant information oc…
DeformSmith: Physics Harness-Guided Hierarchical Generation of Deformable Assets for Robot Manipulation
arXiv:2609.18620v1 Announce Type: new Abstract: Creating deformable assets for robot manipulation requires jointly specifying their geometry, appearance, and ph…
M$^3$P-R1: Reinforcement Learning for Large Language Model Guided Multi-Modal Motion Planning via MIP Code Generation
arXiv:2609.18669v1 Announce Type: new Abstract: Multi-Modal Motion Planning (M$^3$P) requires joint reasoning over continuous motions and discrete mode transiti…
Imitation Learning for Autonomous Driving in CARLA
arXiv:2609.17757v1 Announce Type: cross Abstract: Behavioral cloning trains a policy offline on expert demonstrations, but deployment is closed loop: each actio…
LiteViLNet: Lightweight Vision-LiDAR Fusion Network for Efficient Road Segmentation
arXiv:2605.21007v3 Announce Type: replace-cross Abstract: Road segmentation is a fundamental perception task for autonomous driving and mobile robotics, where b…
Not All Agreement Counts as Corroboration: Provenance-Conserving Multi-View Fusion for Typed Action Admission in Human-Robot Collaboration
arXiv:2609.01662v2 Announce Type: replace Abstract: Better probability scores do not establish that evidence has been counted correctly. Repeated inference over…
Loco-Loco-RL: Low-Cost Terrain Mapping for Humanoid Locomotion with Reinforcement Learning
arXiv:2609.19041v1 Announce Type: new Abstract: Informative terrain perception is important for robust reinforcement learning policies in humanoid locomotion. S…
CaSCo: Cascade-Aware Soft-Collision Motion Planning
arXiv:2609.18910v1 Announce Type: new Abstract: Conventional motion planning treats collision as a binary constraint, although contact with different objects ca…
Asymptotically Optimal Multi-Robot Task and Motion Planning
arXiv:2609.18813v1 Announce Type: new Abstract: Multi-robot task and motion planning (MR-TAMP) requires jointly reasoning about discrete task decisions and cont…
Gated Residual Body-Hand Coordination for Whole-Body Humanoid Teleoperation
arXiv:2609.18763v1 Announce Type: new Abstract: Whole-body humanoid teleoperation commonly combines a motion-tracking policy with a separate dexterous-hand reta…
Active perception for robotic harvesting: 3D reconstruction and localisation of tomatoes hidden within clusters in a Mediterranean greenhouse
arXiv:2609.18738v1 Announce Type: new Abstract: Automating robotic harvesting in intensive agriculture within Mediterranean greenhouses requires overcoming sign…
From Gameplay to Policy: Towards Scalable Robot Data Collection via Gamified Robot-Free Interaction
arXiv:2609.18650v1 Announce Type: new Abstract: Learning generalizable robot manipulation policies requires large-scale and diverse interaction data, yet collec…
Benchmarking Visual-Inertial Odometry in Subterranean Environments Under Sensor Degradation, Miscalibration, and Dynamic Occlusion
arXiv:2609.18628v1 Announce Type: new Abstract: Visual-inertial odometry (VIO) is a core capability for autonomous operation in GPS-denied subterranean environm…
InterMASH: A Unified Geometric Representation for Grasp Synthesis
arXiv:2609.18504v1 Announce Type: new Abstract: Grasp synthesis aims to generate stable and physically plausible hand--object interactions, and has become a fun…
Real-Time Bounded Catenary Solver for UAV Tether Modeling
arXiv:2609.18482v1 Announce Type: new Abstract: For non-stationary tethered multirotor UAVs in real-world conditions, simulating the forces imposed on the drone…
UAVs Meet Embodied Intelligence: Bridging Human Intents and Flying Dynamics Via Harnessing Physical-Digital AI Agents
arXiv:2609.18326v1 Announce Type: new Abstract: Unmanned aerial vehicles (UAVs) extend embodied intelligence into continuous three-dimensional space, where perc…
A3P5 NEMESIS Integrated Rover Design for Environmental Reconnaissance and Robotic Sampling with Reproducible Mobility Analysis and an External Data Machine Learning Calibration Benchmark
arXiv:2609.18245v1 Announce Type: new Abstract: A3P5 NEMESIS is a four-wheel rover intended to combine remote inspection, environmental observation and lightwei…
CANTABILE: Learning Expressive Dynamics for Robotic Piano Performance
arXiv:2609.18213v1 Announce Type: new Abstract: Robotic piano playing has emerged as a standard benchmark for dexterous bimanual manipulation, yet progress on i…
WholeBodyWAM: Learning Whole-Body World Action Models with Scalable Motion Priors
arXiv:2609.18197v1 Announce Type: new Abstract: Humanoid whole-body manipulation requires coordinated whole-body dynamics, yet large-scale trajectories from a t…
Online Multimodal Workload Assessment in Contact-Rich Physical Human-Robot Interaction
arXiv:2609.18031v1 Announce Type: new Abstract: Contact-rich physical human--robot interaction (pHRI) imposes time-varying demands associated with physical inte…
Vision-Language Grounded Task-Context-Aware Imitation Learning for Robotic Disassembly
arXiv:2609.17714v1 Announce Type: new Abstract: Real-world robotic disassembly requires long-horizon execution, where robots must perform ordered sequences of m…
Human-Centric Grasp State Assessment: Toward Transferring Subjective Evaluation to Robots
arXiv:2609.17540v1 Announce Type: new Abstract: We propose a framework that transfers tacit human subjective criteria to robotic systems for the appropriate gra…
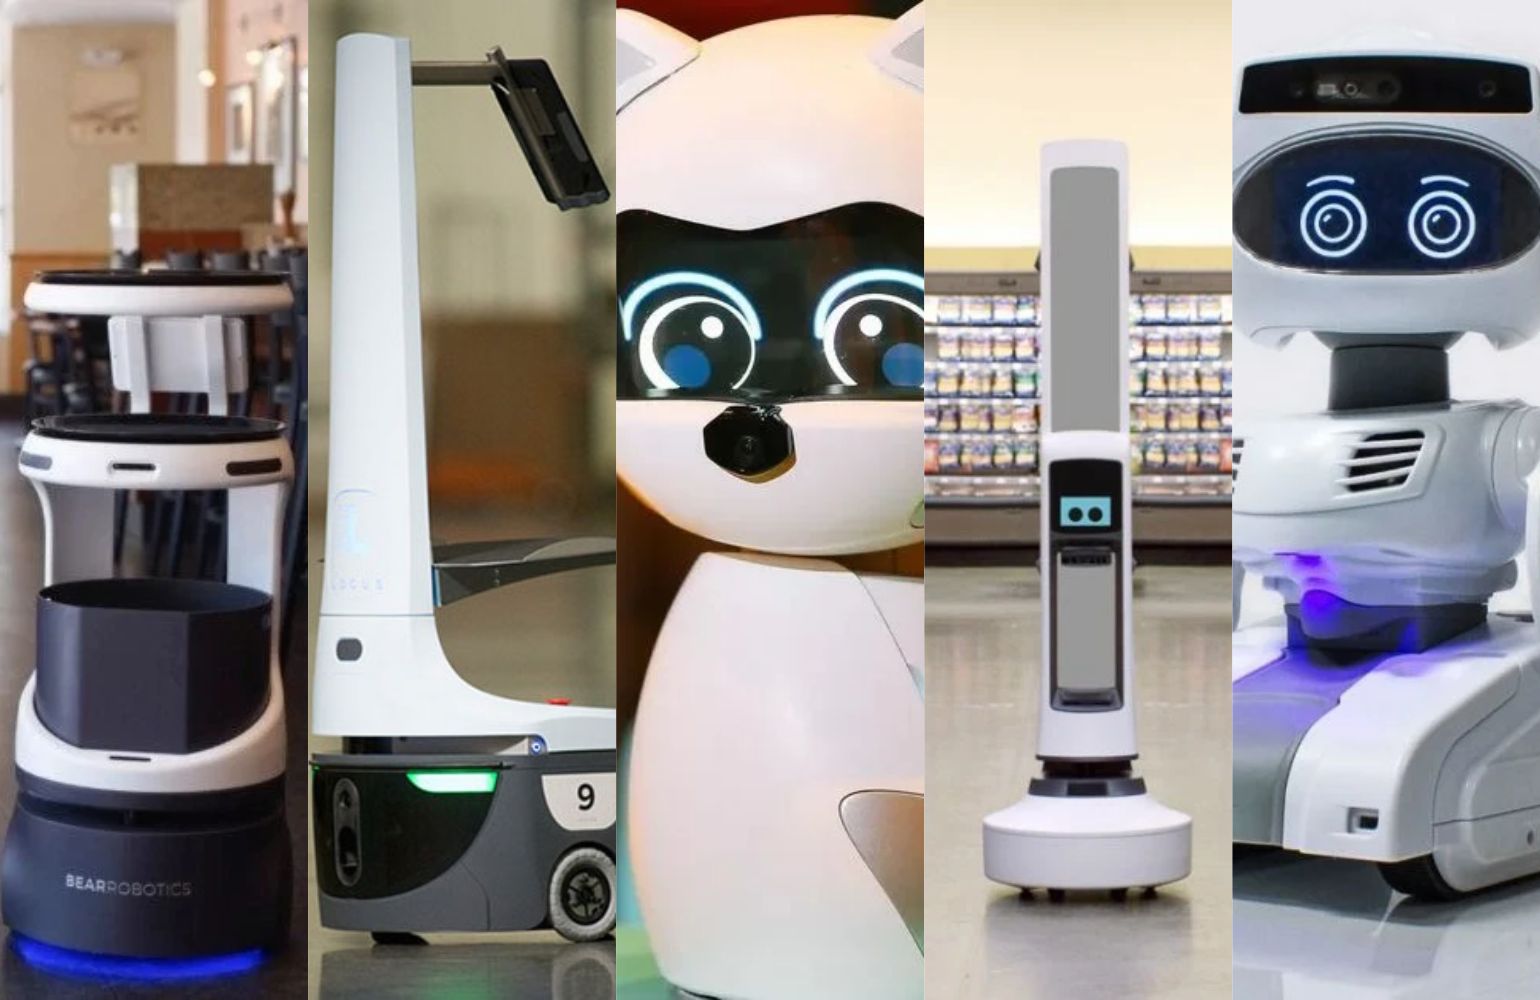
OLogic to share how robots can learn from human demonstrations at RoboBusiness
OLogic CEO Ted Larson will explore the foundations of egocentric robot learning and the technical challenges involved in building these systems. The post OLogic…
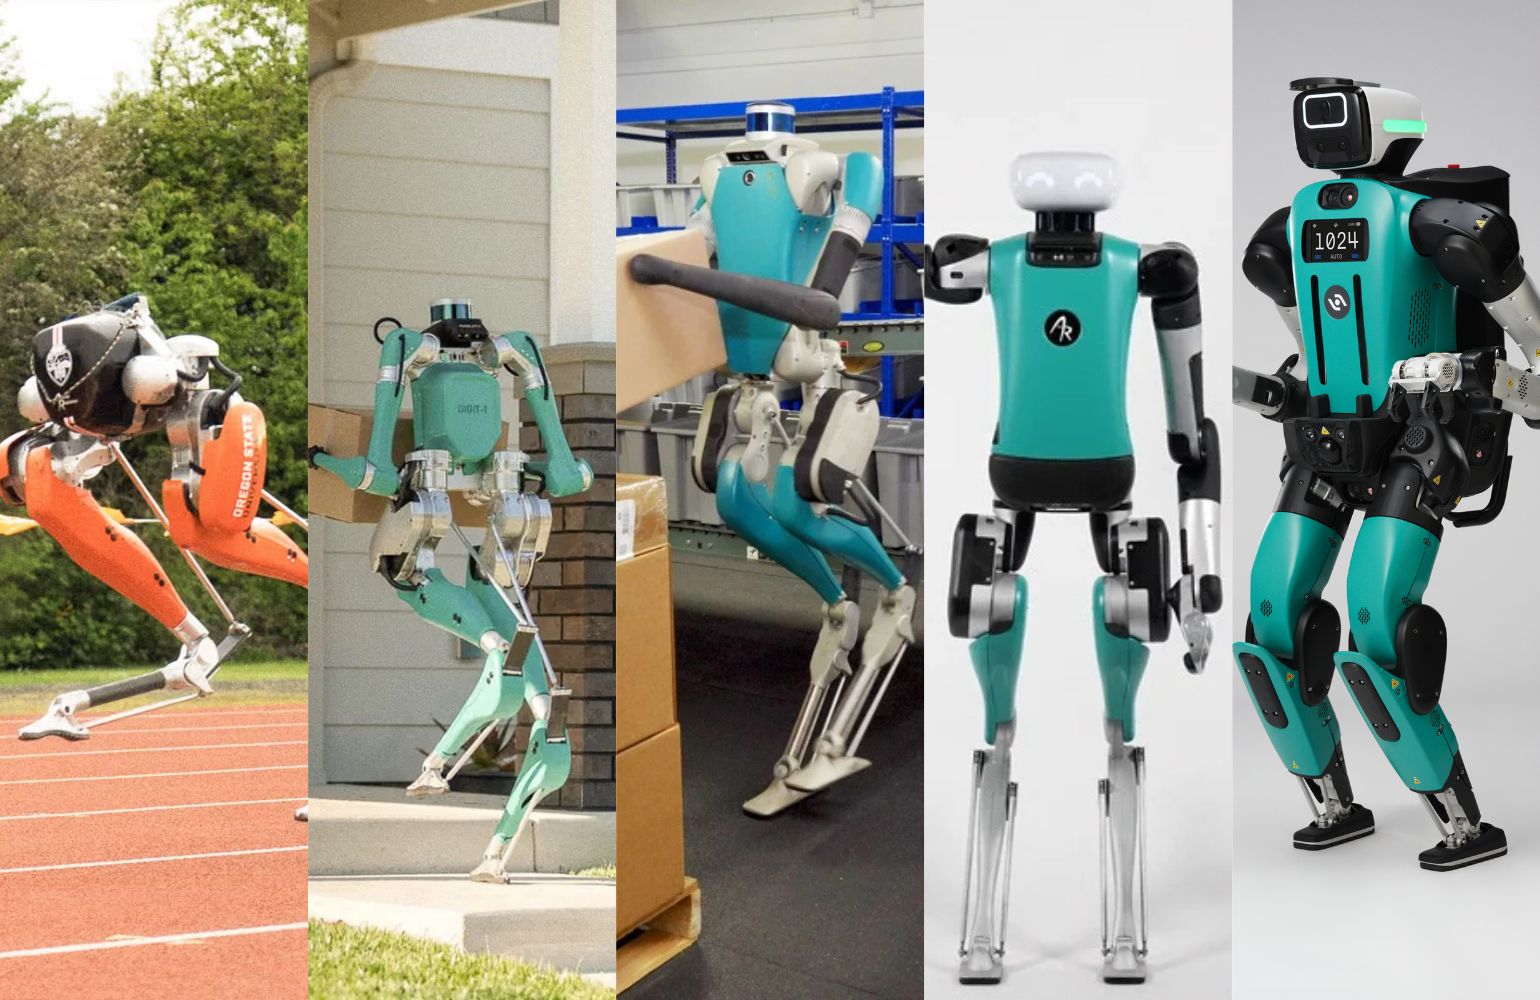
The evolution of Digit: Agility Robotics’ journey from Cassie to Digit 5
From Cassie, to five different versions of Digit, Agility Robotics has adapted its technology to fit industrial tasks. The post The evolution of Digit: Agility …
Geometry vs Structure: Graph-Based Diagnostics for LiDAR Point-Cloud Simulation Fidelity
arXiv:2609.16378v1 Announce Type: new Abstract: Digital twins provide a scalable and cost-effective complement to real-world testing for validating autonomous-d…
XRoboToolKit-T: Teleoperation with High Stability and Precision with Tactile Sensing for Contact-rich Manipulation
arXiv:2609.16437v1 Announce Type: new Abstract: Collecting high-quality robot data for contact-rich manipulation tasks is essential for enabling robots to acqui…
Dense to MoE Adaptation for Compact Vision Language Action Policies
arXiv:2609.16503v1 Announce Type: new Abstract: Vision language action (VLA) policies continue to grow in parameter count, making deployment on resource-constra…