News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4146 storiesHIL-UMI: Bringing Human-in-the-Loop Post-Training of Vision-Language-Action Models to Universal Manipulation Interface
arXiv:2609.20659v1 Announce Type: new Abstract: Large-scale vision-language-action (VLA) models provide powerful priors for robot manipulation, yet adapting the…
Custom PX4 firmware for autonomous hybrid aerial-marine missions
arXiv:2609.20691v1 Announce Type: new Abstract: Mapping and monitoring aquatic environments can benefit from hybrid aerial-amphibious drones able to combine fli…
MILER: Semantic Mid-Level Representation for Sim-to-Real Reinforcement Learning in Unstructured Autonomous Driving
arXiv:2609.20747v1 Announce Type: new Abstract: Reinforcement learning constitutes a promising approach owing to its potential for superhuman performance and se…
OPTED: On-Policy Fine-Tuning for End-to-End Driving using a Render-Free Teacher
arXiv:2609.20756v1 Announce Type: new Abstract: As scaling pre-training data alone yields diminishing returns, post-training is becoming increasingly important …
Agile-WAM: An Agile Tactile World Action Model for Contact-Rich Robot Control
arXiv:2609.20761v1 Announce Type: new Abstract: World Action Models (WAMs) advance beyond conventional visuomotor policies by jointly predicting future world st…
Workspace Models: Lightweight Robotic Memory via Saliency-Driven Supervision
arXiv:2609.20820v1 Announce Type: new Abstract: Complex robotic manipulation tasks frequently require a long-term memory of past events and actions. As conditio…
Coding Agents with an Obstacle-Aware Harness for Safe Robot Manipulation
arXiv:2609.20822v1 Announce Type: new Abstract: Coding agents have emerged as a promising paradigm for robot manipulation: a language model writes the robot con…
"Your Robot Was Trained on a Lie": Collision Mesh Poisoning Attacks on Robotic Manipulation
arXiv:2609.18122v1 Announce Type: cross Abstract: Learning-enabled robotic manipulation increasingly relies on robot simulators for policy training and evaluati…
Selective Cotton Boll Localization for Robotic Harvesting: Evaluation of Deep Learning Vision Models Under Field Conditions
arXiv:2609.19592v1 Announce Type: cross Abstract: This study developed and evaluated a deep-learning-based perception framework for selective robotic cotton pic…
JEPA-WAM: Connecting Generated Visual Instructions to World Action Models through JEPA Latent Representations
arXiv:2609.20277v1 Announce Type: cross Abstract: World Action Models (WAMs) have demonstrated strong robotic manipulation capabilities by augmenting pretrained…
AntiGrounding: Executable Robot Trajectories as Visual Prompts for VLM-Guided Manipulation
arXiv:2506.12374v3 Announce Type: replace Abstract: Natural-language manipulation instructions specify the task goal but leave the underlying robot trajectory u…
Modelling and Model-Checking a ROS2 Multi-Robot System using Timed Rebeca
arXiv:2511.15227v2 Announce Type: replace Abstract: Model-based development accelerates prototyping, enables earlier experimentation, and ensures rigorous valid…
Sim-and-Human Co-training for Data-Efficient and Scene-Generalizable Bimanual Manipulation
arXiv:2601.19406v2 Announce Type: replace Abstract: Real-robot demonstrations are prohibitively expensive, while simulation data and real-world human demonstrat…
StarVLA-$\alpha$: Reducing Complexity in Vision-Language-Action Systems
arXiv:2604.11757v2 Announce Type: replace Abstract: Vision-Language-Action (VLA) models have recently emerged as a promising paradigm for building general-purpo…
Fault-Tolerant, Rigidity-Preserving Control of Inflatable Truss Robots
arXiv:2605.20561v2 Announce Type: replace Abstract: Isoperimetric robotic trusses can adapt to different tasks and environments due to their high strength-to-we…
Emergent interactions lead to collective frustration in robotic matter
arXiv:2507.22148v3 Announce Type: replace-cross Abstract: Artificial intelligence and robotic systems are increasingly deployed as interacting collectives of le…
Robotic Video World Models: A Survey of Applications, Research Challenges, Future Directions
arXiv:2601.07823v2 Announce Type: replace-cross Abstract: Video world models have emerged as promising candidates for high-fidelity world models, offering the p…
Worst-Case Hidden-Vehicle Trajectory Search in Spatiotemporal Occlusion Regions
arXiv:2609.20480v1 Announce Type: new Abstract: Occlusion creates fundamental uncertainty in autonomous driving. Existing methods often propagate frame-wise hyp…
CoreSense: Traceable Failure Recall and Conflict-Aware Belief Gating for Auditable Robot Decisions
arXiv:2609.19512v1 Announce Type: new Abstract: Robots can recall prior failures without knowing whether recalled evidence remains valid, conflicts with current…
Semantic SLAM in Precision Agriculture using Bayesian Inference
arXiv:2609.20604v1 Announce Type: new Abstract: This paper presents a real-time semantic world modeling framework specialized for precision agriculture using au…
INSPECT: Learning Robot View Selection from Assistant Use
arXiv:2609.20615v1 Announce Type: new Abstract: Robots inspecting an assembly must determine which parts are present and whether they are correctly installed. D…
Underwater Visual Target Tracking with Target-Specific Depth Estimation and Adaptive Model-Fusion Predictive Control
arXiv:2609.20731v1 Announce Type: new Abstract: Vision-based underwater target tracking is challenged by unreliable depth measurements and unknown target motion…
RoboGPU: Accelerating GPU Collision Detection for Robotics
arXiv:2603.01517v2 Announce Type: replace-cross Abstract: Autonomous robots are anticipated to be deployed soon in domains ranging from transportation to health…
Boreas Road Trip: A Multi-Sensor Autonomous Driving Dataset on Challenging Roads
arXiv:2602.16870v2 Announce Type: replace Abstract: The Boreas Road Trip (Boreas-RT) dataset extends the multi-season Boreas dataset to new and diverse location…
StageGuard: Learning Stage Transitions for Long-Horizon Robot Tasks via Agentic Distillation
arXiv:2609.20791v1 Announce Type: new Abstract: Hierarchical planning frameworks combine skills from multiple robot control policies for long-horizon task execu…
MoWAM: Explicit Future Motion Prediction for Efficient World Action Models
arXiv:2609.20709v1 Announce Type: new Abstract: World Action Models (WAMs) improve robot policy learning by incorporating future dynamics, yet explicitly genera…
Time-Efficient Iterative Learning Planning for Safety-Critical Dynamic Obstacle Avoidance
arXiv:2609.20435v1 Announce Type: new Abstract: Autonomous mobile robots require timeefficient planning and safety-critical dynamic obstacle avoidance under con…
GAVEL: Graph World Models for Verified and Efficient Long-Horizon LLM Task Planning
arXiv:2609.19315v1 Announce Type: new Abstract: Large language models (LLMs) provide a flexible interface for long-horizon robot planning, but generated plans o…
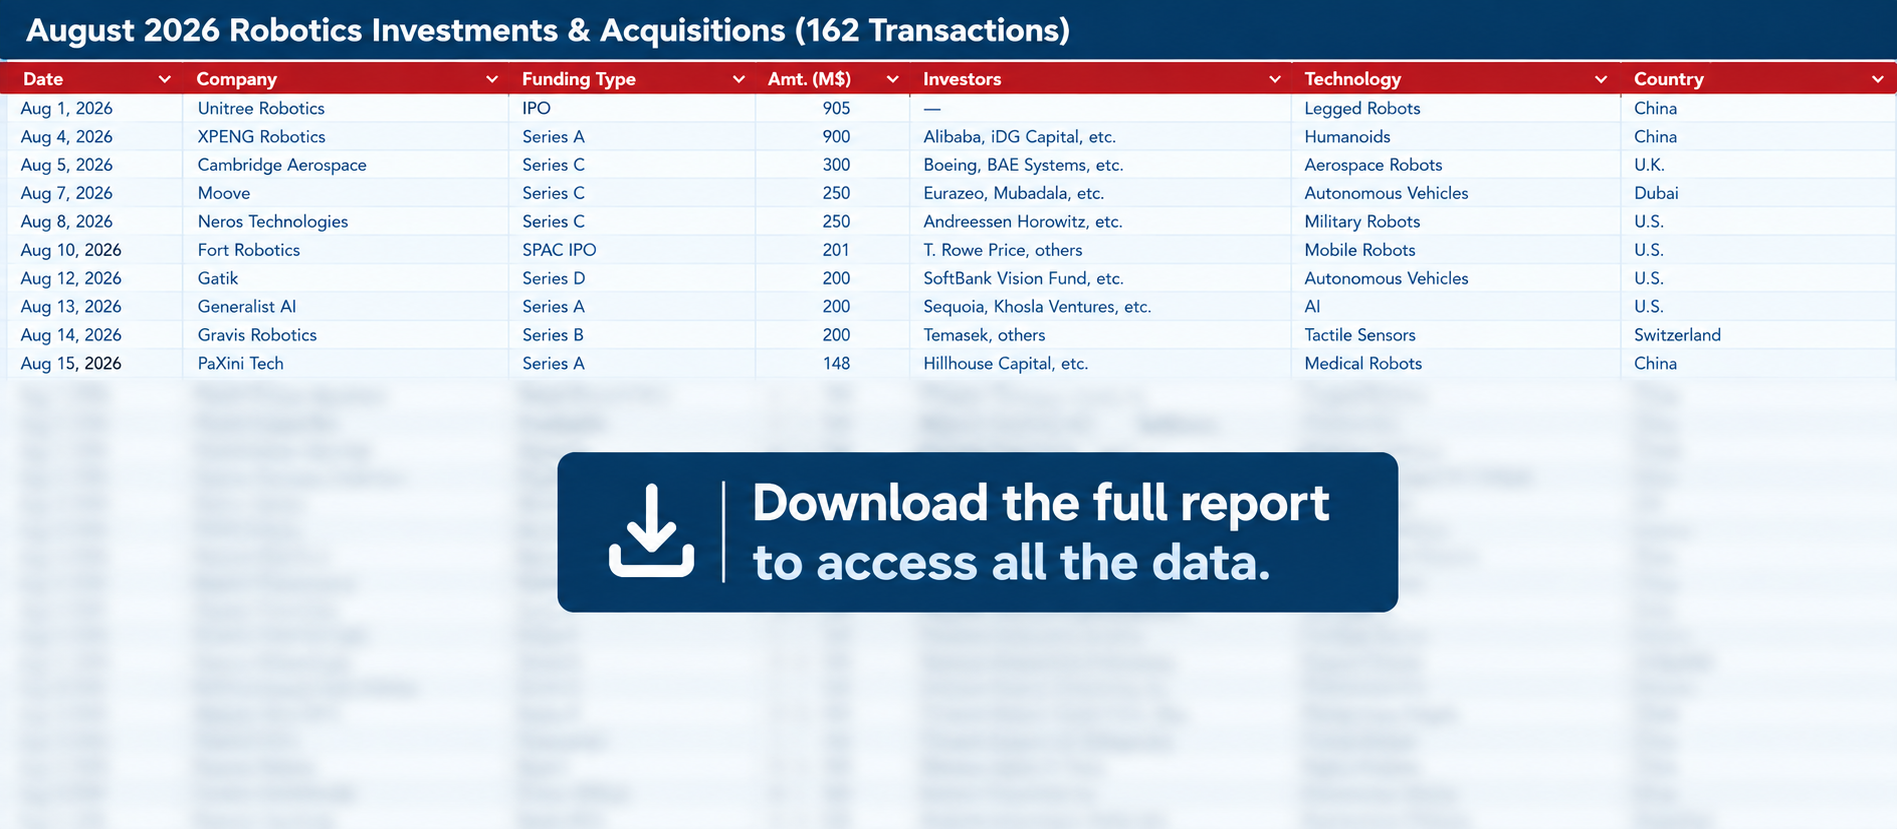
Robotics investments reach $4.9B in August 2026
The August 2026 Robotics Investments Report includes a table with all 162 investments rounds, complete with breakdowns by technology, country, funding stage, an…

Designing long-travel axes: When rack and pinion outperforms ball screws and linear motors
Sponsored by GAM. Pull a tape measure out a few inches and the blade is rigid. Keep pulling and at some point it starts to flex and wobble, then eventually buck…