News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4146 storiesRobotic Tele-Operation for Upper Aerodigestive Tract Microsurgery: System Design and Validation
arXiv:2601.06617v4 Announce Type: replace Abstract: Upper aerodigestive tract (UADT) treatments frequently employ transoral laser microsurgery (TLM) for procedu…
Multi-viewpoint Geo-localization with Event Cameras
arXiv:2609.21219v1 Announce Type: cross Abstract: Robot localization is an ongoing challenge that demands mapping and positioning systems that are tolerant to v…
Gripper-Aware Automatic Dense Packing of Irregular Objects
arXiv:2609.22062v1 Announce Type: new Abstract: Automatic dense packing is widely desired in warehouse operations but remains a fundamental challenge in robotic…
SkelWAM: A Skeleton-Guided World-Action Model for Zero-Shot Cross-Embodiment Manipulation
arXiv:2609.21983v1 Announce Type: new Abstract: Reusing manipulation experience across robot embodiments is important for scaling robot learning and reducing re…
GALA: Geometry-Aware Latent Action Modeling for Vision-Language-Action Model Pretraining across Embodiments
arXiv:2609.21948v1 Announce Type: new Abstract: Learning large-scale vision-language-action (VLA) models from multi-embodiment datasets remains challenging due …
Compact but Moving: Intervention-Relevant Geometry in Recurrent World Models
arXiv:2609.21787v1 Announce Type: new Abstract: Learned world models may have compact interventions even when their recurrent state is high-dimensional, but it …
Scaling Vision-Language Reward Learning for Robot Manipulation in Parallel Simulation
arXiv:2609.21767v1 Announce Type: new Abstract: Vision-language models (VLMs) can replace human annotators in preference-based reward learning, but sequential A…
PSR: Predictive Sensorimotor Representation Learning for Contact-Rich Manipulation
arXiv:2609.21753v1 Announce Type: new Abstract: Contact-rich manipulation requires policies to generate precise actions by reasoning over contact forces, robot …
Understanding Engagement and Intrusiveness in Assistive Human-Robot Interaction Using Individual Traits
arXiv:2609.21744v1 Announce Type: new Abstract: Robot assistance is particularly crucial in unfamiliar tasks, where users must understand task requirements whil…
ZeroTouch: Tactile-Supervised Visual Contact Estimation for Contact-Rich Manipulation
arXiv:2609.21726v1 Announce Type: new Abstract: Reliable robotic grasping benefits from estimating the evolving physical interaction and selecting a grasp-depen…
Potential-Field Action Representation for Reinforcement Learning in Contact-Rich Manipulation
arXiv:2609.21609v1 Announce Type: new Abstract: Model-free reinforcement learning can acquire contact-rich robotic manipulation skills through trial-and-error i…
DPed-VLN: A Benchmark for Socially Compliant Vision-and-Language Navigation in Dynamic Pedestrian Environments
arXiv:2609.21504v1 Announce Type: new Abstract: Vision-and-language navigation (VLN) has advanced rapidly in static indoor environments, but robots operating in…
Safe Real-Time Policy Steering via Noise-Space Trajectory Optimization for One-Step Generative Policies
arXiv:2609.21220v1 Announce Type: new Abstract: Generative robot policies can represent diverse, multimodal behaviors, but adapting pretrained policies to deplo…
OpenRoIS: A Community-Driven Open-Source Middleware Implementing the Robotic Interaction Service (RoIS) Framework for Physical Robots and Virtual Agents
arXiv:2609.21178v1 Announce Type: new Abstract: Service applications for human-robot interaction are commonly written against the hardware-specific interfaces o…
MA-LIPP: Cooperative Multi-Agent Load-Aware Informative Path Planning for Heterogeneous Robot Teams
arXiv:2609.21167v1 Announce Type: new Abstract: Field robotics missions often require physical samples to be returned to laboratories for analysis, making path …
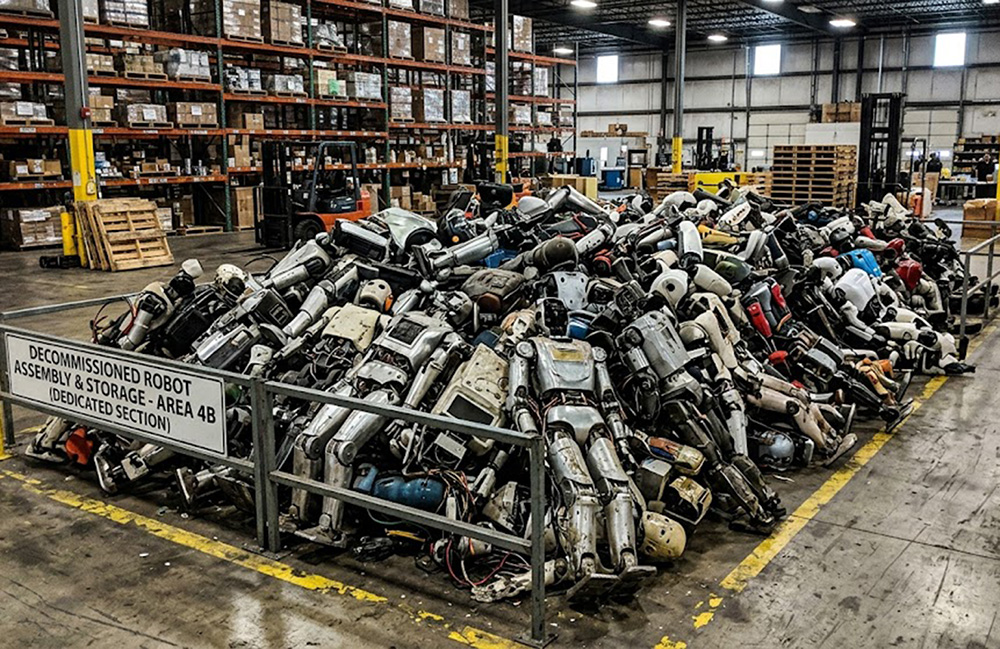
What do you do with a humanoid robot when it breaks down?
Decommissioning a humanoid robot is not a matter of traditional scrapping. It's a highly technical, high-stakes surgical endeavor. The post What do you do with …
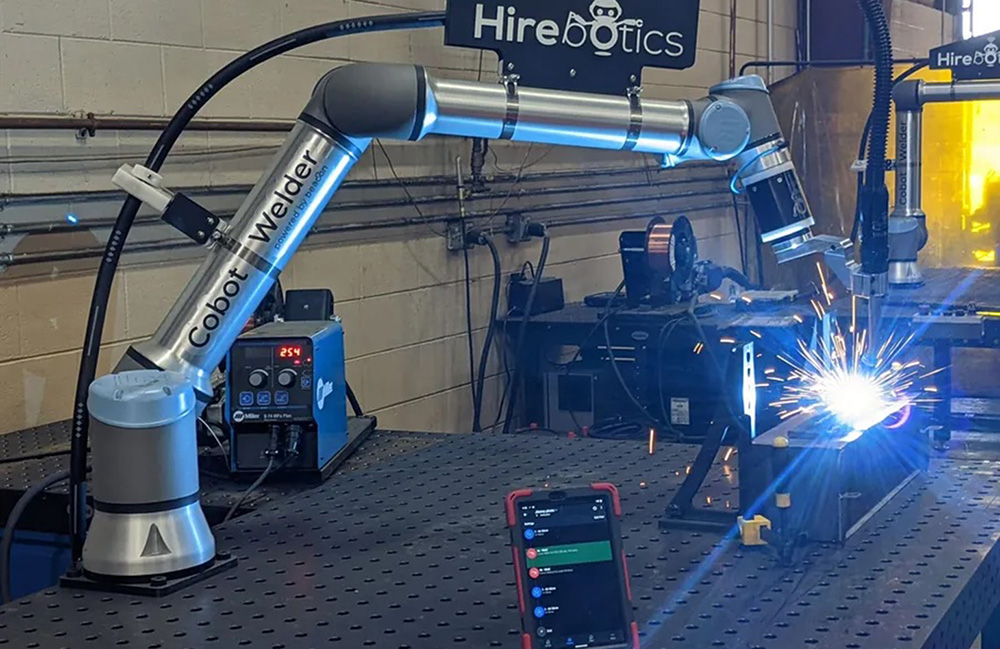
Hirebotics adds line tracking and linear rail capabilities to its cobots
Hirebotics said these new capabilities extend the working range of the cobots, giving manufacturers greater flexibility. The post Hirebotics adds line tracking …

SoftBank agrees to acquire Robotics and AI Institute
The deal has been rumored for a couple of months, but it is now being reviewed by the Committee on Foreign Investment in the United States. The post SoftBank ag…
The picks-and-shovels strategy behind the robotics boom
The real robotics opportunity isn’t a humanoid in every home—it’s packaging robots for the jobs businesses need done today. The post The picks-and-shovels strat…
F-Prime Capital to give insights on the state of robotics investments at RoboBusiness
Sanjay Aggarwal and Betsy Mulé of F-Prime Capital will unveil the firm's State of Robotics Investments report at RoboBusiness. The post F-Prime Capital to give …
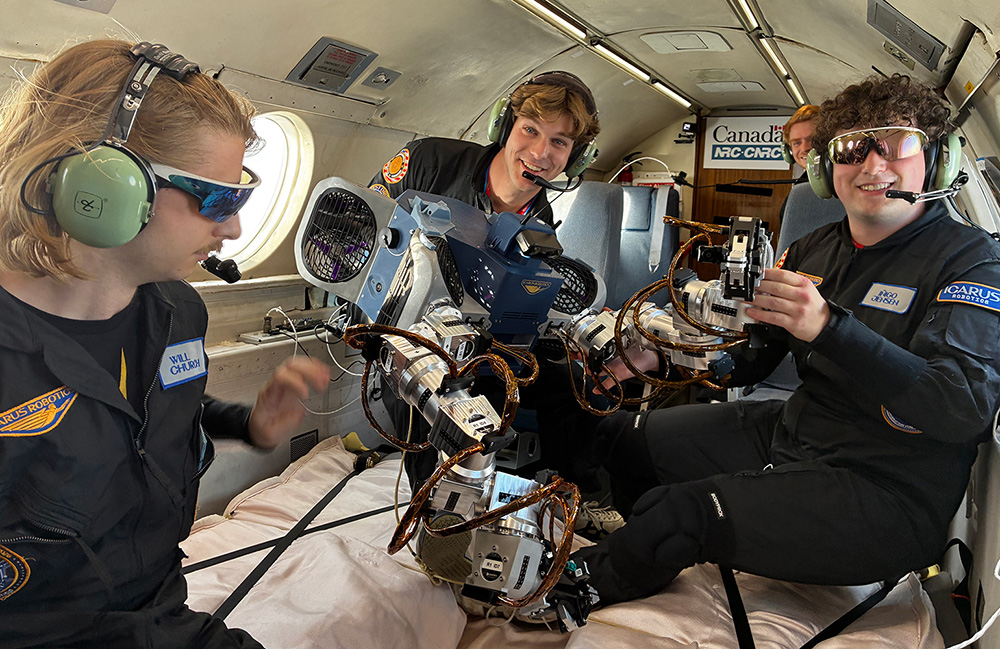
Icarus Robotics flies ISS-bound robot in microgravity for the first time
This is the last major test of the system before Icarus Robotics will be sending Joy the the ISS in early 2027. The post Icarus Robotics flies ISS-bound robot i…
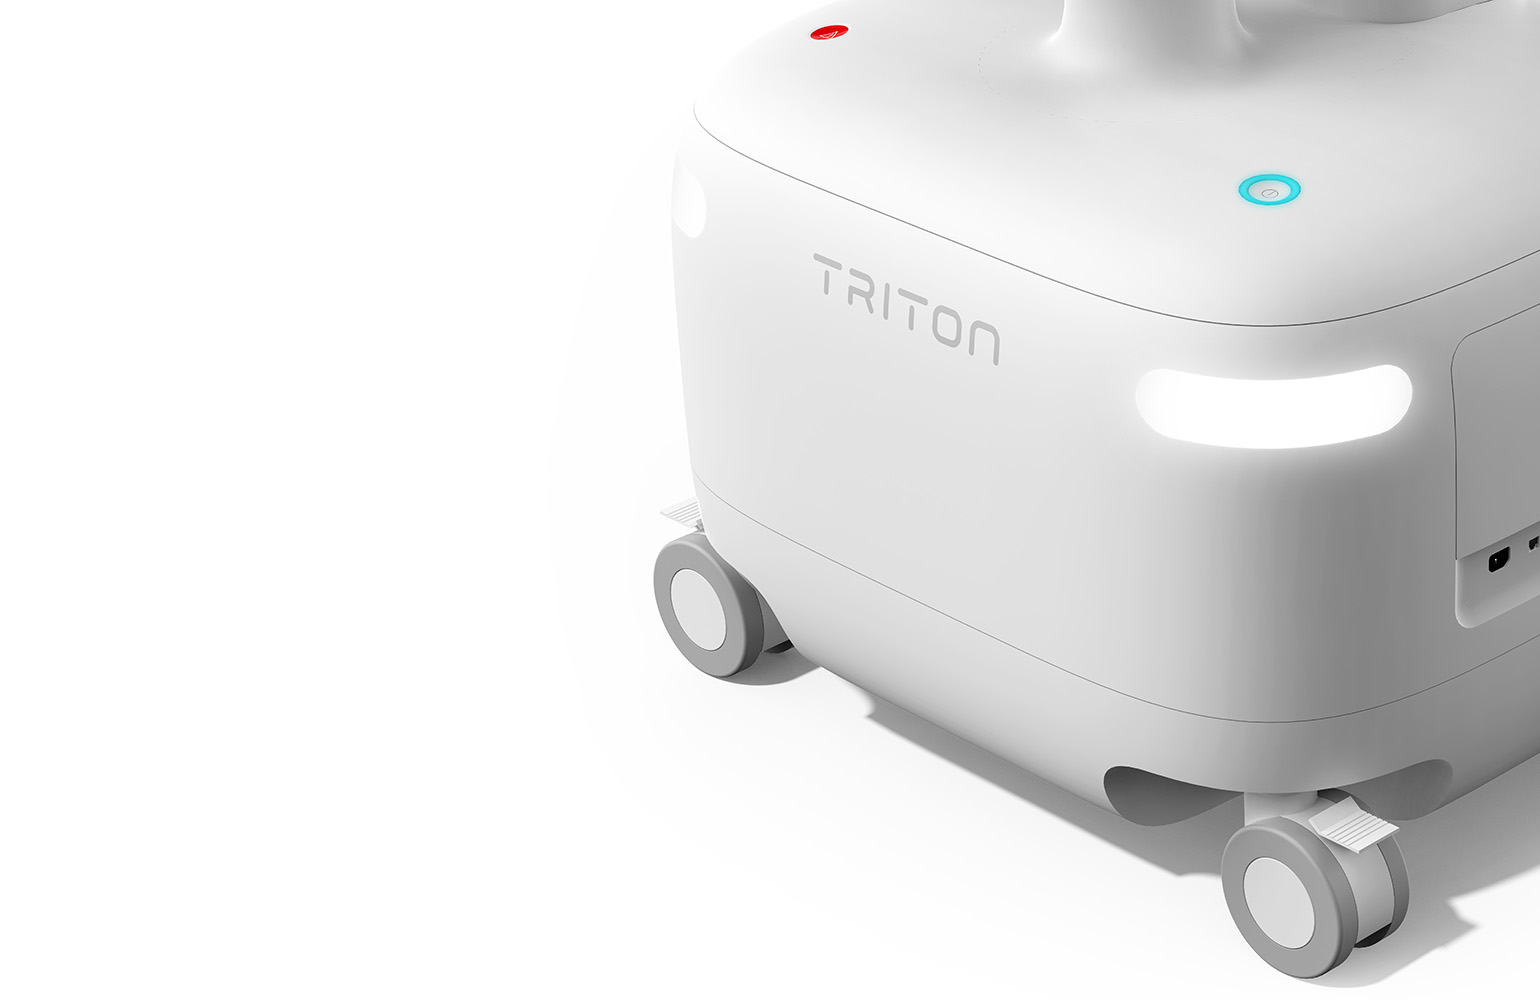
Neptune Medical earns FDA clearance for its Triton 1 robotic system
Neptune said Triton can elevate any endoscopist's capabilities for screening, surveillance, and diagnostic colonoscopies. The post Neptune Medical earns FDA cle…
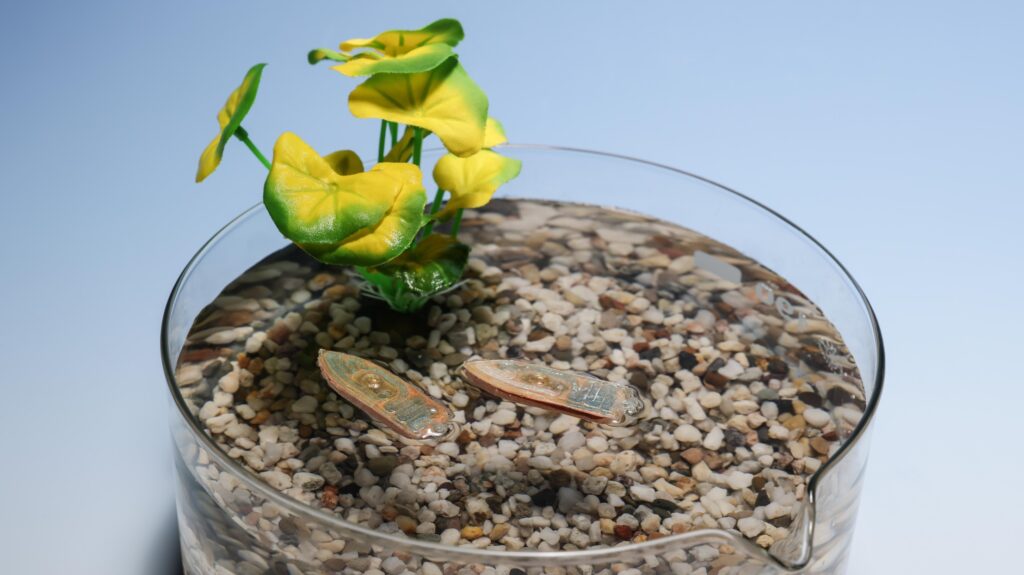
Reimagining robotics for sustainability
By Celia Luterbacher Imagine a robot designed to install solar panels with much greater speed and precision than a human. The robot is made from expensive mater…
AthenaZero: A low-inertia, bimanual robot for dynamic manipulation
arXiv:2609.19194v1 Announce Type: new Abstract: AthenaZero is a bimanual manipulator designed to minimize inertia without compromising control authority. By uti…
ULOHA: An Underwater Bimanual Robot System for Robot Learning
arXiv:2609.19200v1 Announce Type: new Abstract: Underwater visuomotor policy learning has focused primarily on single manipulators, while bimanual imitation lea…
REACT: A Fully Spiking State-Space Model for Real-Time Event-Driven Temporal Perception
arXiv:2609.19204v1 Announce Type: new Abstract: Robotic systems operating in dynamic environments require visual perception that evolves continuously with the i…
4D Radar Perception Algorithms for Autonomous Driving: A Review
arXiv:2609.19216v1 Announce Type: new Abstract: Research on 4D millimeter-wave radar perception algorithms has flourished in recent years, extending from signal…
Grasping by interconnection: robust closing motions from coarse object templates
arXiv:2609.19228v1 Announce Type: new Abstract: Dexterous robot hands must often grasp objects whose shape, size, and pose are known only approximately. Grasp p…
Learning Safe Humanoid Navigation from Reduced Order Models
arXiv:2609.19272v1 Announce Type: new Abstract: Research in humanoid robotics has achieved rapid progress in locomotion, and recent results have pushed the boun…
OHRID-Retail: An Open Multimodal Dataset of Human Activity in Retail Environments
arXiv:2609.19302v1 Announce Type: new Abstract: Open datasets describing human behavior in environments shared with mobile robots remain limited, particularly f…