News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4146 stories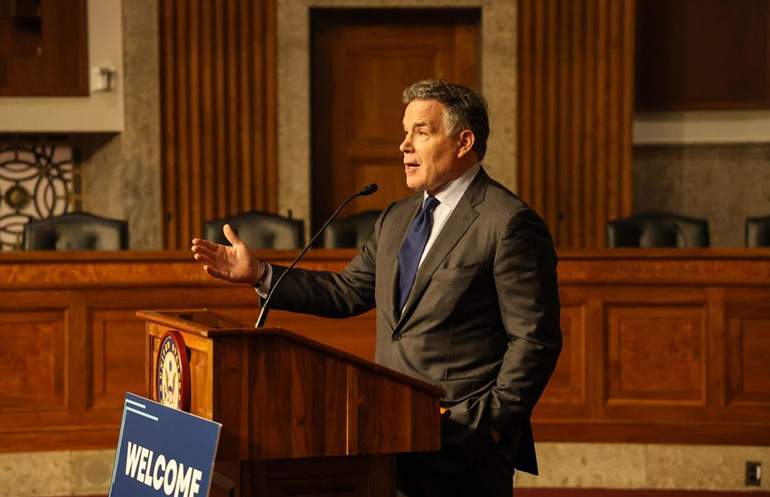
Effort to establish a National Commission on Robotics advances in Congress
As the proposed National Commission on Robotics advances, industry leaders continue to call for more unified U.S. policy. The post Effort to establish a Nationa…
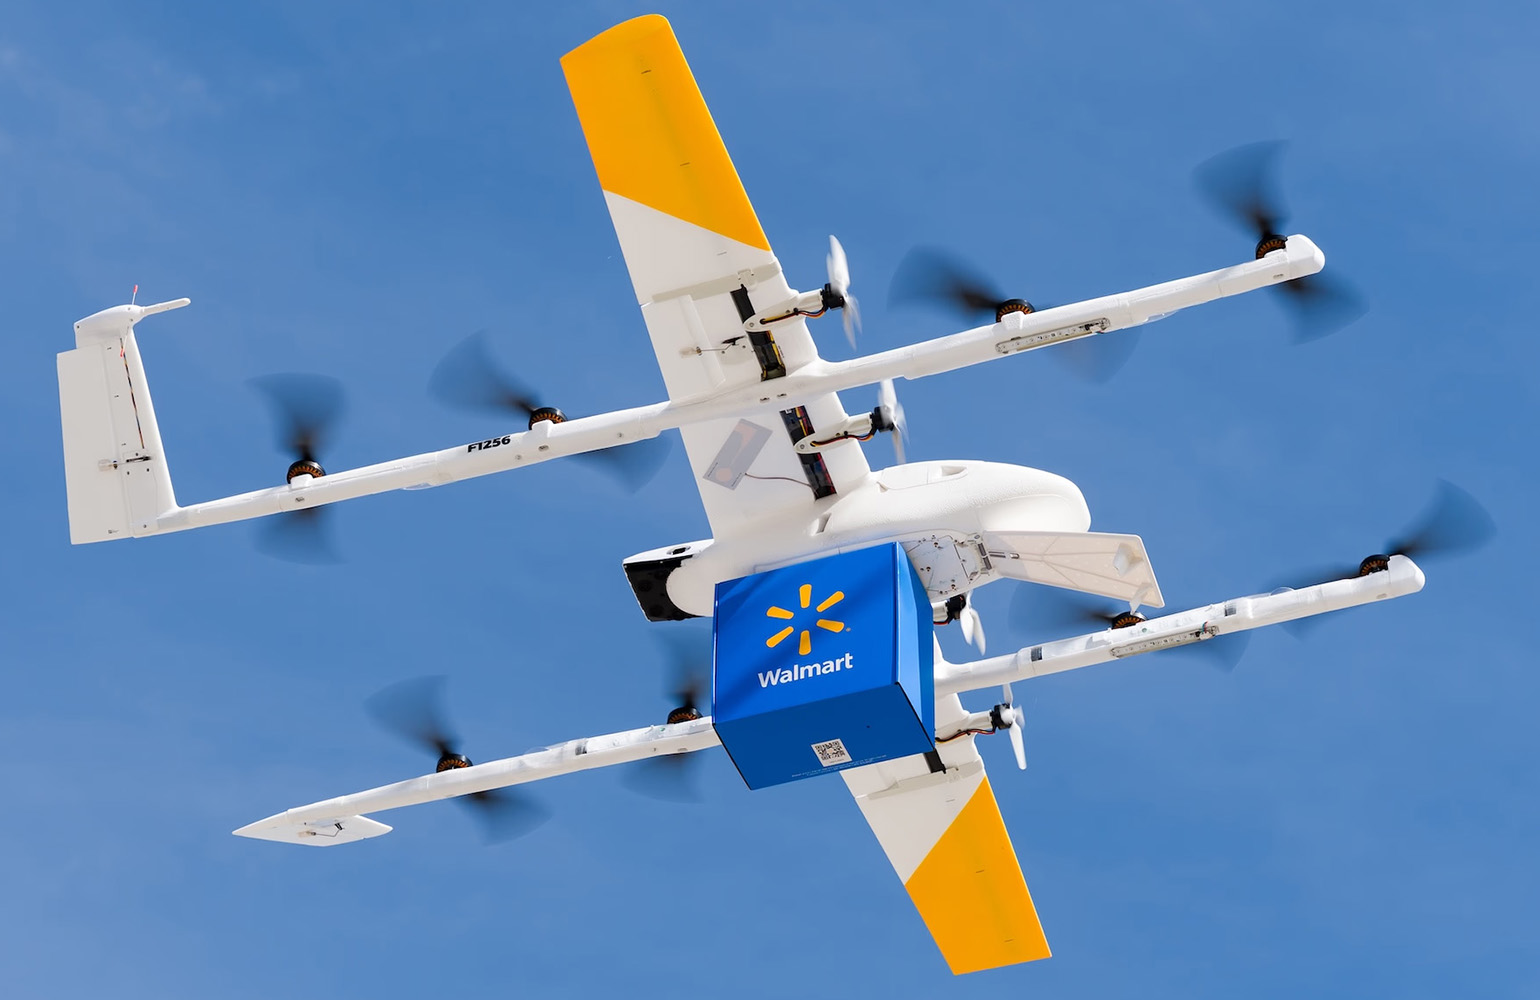
Walmart, Wing add 7 markets in drone delivery expansion
Wing plans to bring drone deliveries to Memphis, New Orleans, Philadelphia, Phoenix, San Diego, San Francisco, and Salt Lake City. The post Walmart, Wing add 7 …
CAST: Counterfactual Labels Improve Instruction Following in Vision-Language-Action Models
arXiv:2508.13446v2 Announce Type: replace Abstract: Generalist robots should be able to understand and follow user instructions. Despite providing a powerful ar…
A Survey of Robotic Navigation and Manipulation with Physics Simulators in the Era of Embodied AI
arXiv:2505.01458v2 Announce Type: replace Abstract: Navigation and manipulation are core capabilities in Embodied AI, but training agents to perform them direct…
Geometric Formulation of Unified Force-Impedance Control on SE(3) for Robotic Manipulators
arXiv:2504.17080v3 Announce Type: replace Abstract: In this paper, we present an impedance control framework on the SE(3) manifold, which enables force tracking…
Rod models in continuum and soft robot control: a review
arXiv:2407.05886v3 Announce Type: replace Abstract: Continuum and soft robots can transform automation tasks requiring compliant interaction in constrained or u…
Co-GLANCE: Uncertainty-Aware Active Perception for Heterogeneous Robot Teaming
arXiv:2606.09919v1 Announce Type: cross Abstract: Perceptual uncertainty is a central challenge for heterogeneous robot teams operating in unstructured outdoor …
Equanimity in HRI: Applying Calm Technology Principles to Human-Robot Interaction
arXiv:2606.09836v1 Announce Type: cross Abstract: This paper explores how {\textit{Calm Technology}} can be integrated into Human-Robot Interaction (HRI), with …
SAFE-Pruner: Semantic Attention-Guided Future-Aware Token Pruning for Efficient Vision-Language-Action Manipulation
arXiv:2605.29662v1 Announce Type: cross Abstract: Real-time inference of vision-language-action (VLA) models is essential for robotic control. While visual toke…
RoboNaldo: Accurate, Stable and Powerful Humanoid Soccer Shooting via Motion-Guided Curriculum Reinforcement Learning
arXiv:2606.11092v1 Announce Type: new Abstract: Elite humanoid soccer shooting requires whole-body stability, high-impulse whole-body interactions, and accuracy…
A Distributed Multi-UGV Exploration Framework With Loop-Aware Planning and Descriptor-Aided Localization in Resource-Limited Environments
arXiv:2606.11088v1 Announce Type: new Abstract: Robust and efficient cooperative exploration with multiple unmanned ground vehicles (UGVs) in unknown, GPSdenied…
Generation of Diverse and Functional Robot Designs using Superquadrics Parametrisation and Quality-Diversity
arXiv:2606.11037v1 Announce Type: new Abstract: Generative design of robots requires navigating a vast search-space, encompassing physical configurations and be…
A Spiking Neural Architecture for Coordinating Arm and Locomotor Control
arXiv:2606.11034v1 Announce Type: new Abstract: Spiking Neural Networks (SNNs) coupled with neuromorphic hardware offer energy-efficient solutions for humanoid …
Diffusion Forcing Planner: History-Annealed Planning with Time-Dependent Guidance for Autonomous Driving
arXiv:2606.11019v1 Announce Type: new Abstract: Learning-based motion planners, despite recent progress, often suffer from temporal inconsistency. Small perturb…
Language-Driven Cost Optimization for Autonomous Driving
arXiv:2606.10974v1 Announce Type: new Abstract: The driving behavior of autonomous vehicles is typically governed by the cost function of their motion planner, …
Resilient Navigation for Autonomous Farm Robots by Leveraging Jerk-Augmented Models with IMU-Only Disturbance Rejection
arXiv:2606.10971v1 Announce Type: new Abstract: Precise state estimation for navigation of autonomous agricultural robots is often compromised by sensor outages…
Task Robustness via Re-Labelling Vision-Action Robot Data
arXiv:2606.10918v1 Announce Type: new Abstract: The recent trend in scaling models for robot learning has resulted in impressive policies that can perform vario…
AgniNav: Configuration-Driven Cross-Embodiment Local Planning for Robot Navigation
arXiv:2606.10903v1 Announce Type: new Abstract: Monocular local navigation is attractive for lightweight robots, but existing vision-based policies often couple…
MV-Actor: Aligning Multi-View Semantics and Spatial Awareness for Bimanual Manipulation
arXiv:2606.10899v1 Announce Type: new Abstract: Robotic manipulation has been widely applied in industrial scenarios. Compared with single-arm manipulation, bim…
An Exposure-Time-Aligned Primary-Path Architecture for Autonomous-Driving ECUs
arXiv:2606.10856v1 Announce Type: new Abstract: While end-to-end (E2E) autonomous driving has become the dominant research direction, production vehicles contin…
IMPACT: Learning Internal-Model Predictive Control for Forceful Robotic Manipulation
arXiv:2606.10818v1 Announce Type: new Abstract: Real-world robotic manipulation tasks often involve forceful interactions with the environment, such as using to…
Bridging Semantics and Physical Execution: A Neuro-Symbolic Framework for Multi-Pair Robotic Assembly
arXiv:2606.10808v1 Announce Type: new Abstract: Multi-pair robotic assembly in unstructured environments faces spatial interference and contact uncertainties. E…
ros2probe: Non-intrusive, Kernel-selective Observability for Robot Operating System 2 Middleware
arXiv:2606.10746v1 Announce Type: new Abstract: Robot Operating System 2 (ROS 2), the de facto standard middleware framework for robots, runs each robot as a gr…
Hand-centric Human-to-Robot Trajectory Transfer from Video Demonstrations via Open-World Contact Localization
arXiv:2606.10743v1 Announce Type: new Abstract: Learning from human video demonstrations remains challenging due to noisy hand-object interactions, unseen objec…
Pushing the Performance Limits in Autonomous Racing: Continuous Stability-Aware Adaptive Velocity Planning in Formula Student Driverless
arXiv:2606.10733v1 Announce Type: new Abstract: In autonomous racing, especially in competitions such as Formula Student Driverless, precise planning of the tar…
Vehicle Prediction Model for Enhanced MPC Path Tracking in Formula Student Driverless
arXiv:2606.10732v1 Announce Type: new Abstract: Autonomous race cars, such as in Formula Student Driverless, operate close to their physical handling limits. Th…
Self-Supervised Relevance Modelling in Autonomous Driving via Counterfactual Analysis
arXiv:2606.10688v1 Announce Type: new Abstract: Autonomous driving relies on computationally intensive perception pipelines to continuously detect and track obj…
Planar-Sector LOS Guidance for Interception of Agile Targets with Lifting-Wing Quadcopters
arXiv:2606.10639v1 Announce Type: new Abstract: Autonomous visual interception of agile aerial targets is challenging due to unpredictable target motion, limite…
VeriSpace: Spatially Grounded Action Verification for Vision-Language-Action Models
arXiv:2606.10568v1 Announce Type: new Abstract: Vision-language-action (VLA) models have shown strong promise for robotic manipulation, but their reliability at…
Uncovering Vulnerability of Vision-Language-Action Models under Joint-Level Physical Faults
arXiv:2606.10501v1 Announce Type: new Abstract: Deploying Vision-Language-Action (VLA) models in real robotic systems requires robustness not only to semantic a…