News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4146 storiesRobot World Models Are Not Invariant to How the Actions Are Written
arXiv:2609.23252v1 Announce Type: new Abstract: A robot policy is trained with one of two action parameterizations: absolute joint targets, or deltas relative t…
Tip Manipulation in Soft Everting Robots via Wall Retraction and Deployable Fingers
arXiv:2609.23132v1 Announce Type: new Abstract: Soft everting robots can traverse long, confined paths by continuously growing, yet active interaction remains l…
DiagGen: Agentic Generation of Deformable Assets with Sim-based Diagnostics for Robotic Simulation
arXiv:2609.23103v1 Announce Type: new Abstract: While simulation-ready deformable assets are essential for in-silico robotic manipulation tasks, existing genera…
Connectivity-Aware Exploration of Robotic Grasp Spaces
arXiv:2609.22983v1 Announce Type: new Abstract: Robotic grasping is typically formulated as the problem of identifying successful actions from a space of candid…
Embodied Snap: Octopus-Inspired Distributed Reach-and-Attach with a Speed-Limited Soft Arm
arXiv:2609.22926v1 Announce Type: new Abstract: Reach-and-attach of soft robotic arms with passive suction requires accurate targeting and sufficient contact sp…
Barrier Certificate Synthesis for Non-Polynomial Robotic Dynamics via Polynomial Lifting
arXiv:2609.22885v1 Announce Type: new Abstract: Safe operation of robotic systems requires trajectories to remain within a prescribed safe set under admissible …
Physical-Touch Observability from Wrist Wrench in Granular Scooping
arXiv:2609.22852v1 Announce Type: new Abstract: Mining and earthmoving are important real-world deployment settings for embodied intelligence. Autonomous transp…
Commonsense-Grounded Path Planning from Abstract Instructions
arXiv:2609.22813v1 Announce Type: new Abstract: We present \emph{commonsense ranked search} (CoRS), a novel path planner that turns an abstract instruction into…
Expert-Play Contouring Control: Faster-than-Demonstration Planning from Slow Expert and Fast Play
arXiv:2609.22798v1 Announce Type: new Abstract: Expert demonstrations often specify what a robot should do, but not how fast it can do it. Imitation Learning (I…
Decentralized Multi-Robot Exploration with Probabilistic Peer Intent and Multi-hop Plan Propagation
arXiv:2609.22726v1 Announce Type: new Abstract: Efficient coordination under limited communication remains a key challenge in decentralized multi-robot explorat…
Density-Driven Area Coverage for Nonholonomic Multi-Robot Systems with Safety Guarantee
arXiv:2609.22668v1 Announce Type: new Abstract: Density-Driven Optimal Control (D2OC) provides a principled approach to distributing multi-robot teams over non-…
Simultaneous Forward and Inverse Human-in-the-Loop Optimization
arXiv:2609.22630v1 Announce Type: new Abstract: Subjective user experience is important to human-robot interaction, but the outcomes users value, and how those …
HIGenNTO: Scalable Humanoid Interaction Generation via Noise-Space Trajectory Optimization
arXiv:2609.22611v1 Announce Type: new Abstract: Humanoid robots can acquire complex skills by imitating kinematic humanoid motion references, yet reliable refer…
Becoming a Fruit Ninja: Real-Time Probabilistic Kinodynamic Planning for Manipulator Projectile Interception
arXiv:2609.22608v1 Announce Type: new Abstract: Projectile interception is a challenging dynamic manipulation problem. Intercepting a thrown object with a robot…
Characterizing Wildlife Response to Biomimetic and Conventional Underwater Vehicles
arXiv:2609.22594v1 Announce Type: new Abstract: Autonomous underwater vehicles (AUVs) are a promising alternative to divers for scalable collection of natural o…
Tracker-Free Robotic Ultrasound Calibration with a Spherical-Marker Phantom and Threshold-Free Center Localization
arXiv:2609.22483v1 Announce Type: new Abstract: Robotic ultrasound (US) calibration is essential for accurately relating US images to the robot coordinate syste…
AffordanceWAM: Affordance-Aware Joint World-Action Modeling for Robot Manipulation
arXiv:2609.22332v1 Announce Type: new Abstract: Generalizable robot manipulation requires predicting how a scene will evolve, identifying where interactions are…
Embedding Physics Priors in Robot Learning: A Survey
arXiv:2609.22319v1 Announce Type: new Abstract: The rapid progress of artificial intelligence is reshaping robotics and accelerating the adoption of learning-ba…
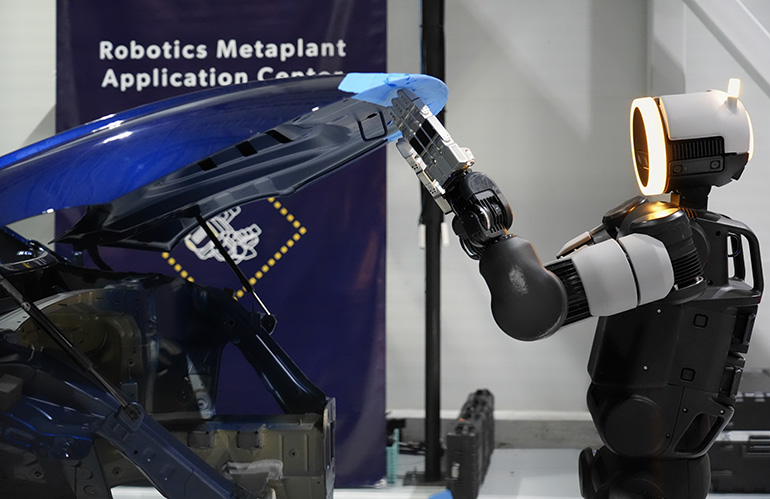
Boston Dynamics opens Metaplant Application Center to train Atlas humanoid robots
The new Robotics Metaplant Application Center is training humanoids as part of Hyundai's Metaplant America in Georgia. The post Boston Dynamics opens Metaplant …
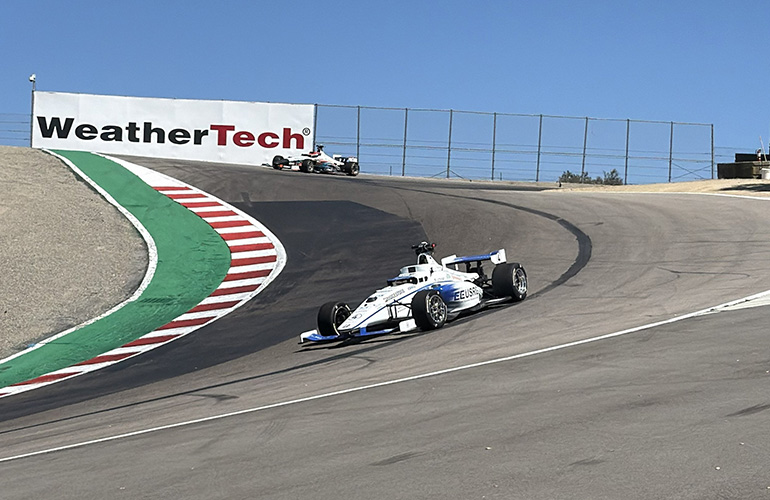
IAC completes autonomous racing event at Laguna Seca
At Laguna Seca, Unimore Racing won the Indy Autonomous Challenge, marking the IAC's first autonomous car overtakes on a road course. The post IAC completes auto…
ForeTac-VLA: A Forecasting-Based Tactile-Vision-Language-Action Model for Contact-Rich Robotic Manipulation
arXiv:2609.20980v1 Announce Type: new Abstract: Vision-language-action (VLA) models have demonstrated strong capabilities in robotic manipulation, yet their rel…
PIVOT: Physically Informed Vision-Language Off-Road Traversability for Field Robot Navigation
arXiv:2609.20983v1 Announce Type: new Abstract: Terrain assessment is a critical capability for off-road mobile robots, enabling safe and reliable navigation th…
Do Spinning Radar Doppler Velocity Measurements Improve Vehicle Detection and Tracking?
arXiv:2609.21000v1 Announce Type: new Abstract: Spinning frequency-modulated continuous-wave (FMCW) radars have been gaining popularity in autonomous vehicle pe…
Project SCOUT: Interceptor Drone for Perimeter Defense
arXiv:2609.21005v1 Announce Type: new Abstract: The rapid proliferation of unauthorized unmanned aerial vehicles (UAVs) has created a growing need for robust, j…
Towards Effective Visual-Inertial SLAM with Passive-Only Sensors for Low-Cost Autonomous Underwater Vehicles
arXiv:2609.21015v1 Announce Type: new Abstract: Improvements to Visual-Inertial Simultaneous Localization and Mapping (VI-SLAM) for low-cost autonomous underwat…
Catch Me If You Can: Real-Time Feedback Denoising for Responsive VLAs
arXiv:2609.21022v1 Announce Type: new Abstract: Vision-Language-Action (VLA) models have shown strong generalization in robotic manipulation by combining semant…
MAPLE-RF: Efficient Probabilistic RF Source Localization in Partially Explored Environments
arXiv:2609.21026v1 Announce Type: new Abstract: Localizing a radio-frequency (RF) transmitter from received signals often requires a model of the environment to…
DEXTERA: From a Single Image to Deployable Dexterous Manipulation via Real-to-Sim-to-Real
arXiv:2609.21045v1 Announce Type: new Abstract: Collecting real-world robot data for dexterous manipulation is costly and time-consuming. While high-fidelity ph…
Constraint-Unified MPC for Over-Actuated Surface Vehicles with Post-Detection Fault Reconfiguration
arXiv:2609.21046v1 Announce Type: new Abstract: Choreographed aquatic performances require small autonomous surface vehicles to track precise paths under per-th…
Dynamic Modeling and LQR Control of a Single Coaxial Drone with 2DOF Thrust Vectoring Mechanism
arXiv:2609.21099v1 Announce Type: new Abstract: Coaxial rotor drones have generated considerable interest because of energy efficiency and small size, but they …