News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4146 stories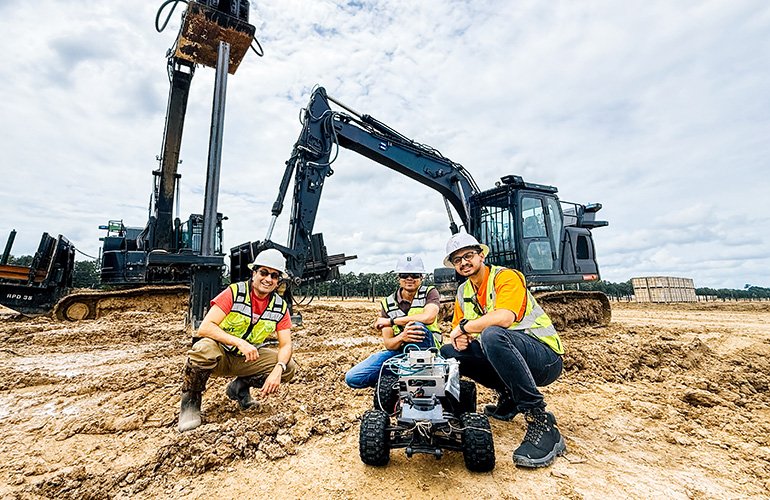
Built Robotics, Penn xLAB to develop physical AI for construction
xLAB and Built Robotics partner to capture additional data, advancing AI models to improve construction site safety. The post Built Robotics, Penn xLAB to devel…
Human Universal Grasping
arXiv:2606.17054v1 Announce Type: new Abstract: Humans can grasp objects effortlessly, whereas multi-fingered robots are far from this level of generality. We a…
Task-Error Residual Learning for Real-Robot Five-Ball Juggling
arXiv:2606.16978v1 Announce Type: new Abstract: For residual learning that refines existing behavior, sample efficiency depends on two things: how much informat…
Unified Motion-Action Modeling for Heterogeneous Robot Learning
arXiv:2606.16917v1 Announce Type: new Abstract: We present Unified Motion-Action (UMA) Model, an approach that uses 3D object motion trajectories as a shared in…
SGM-SLAM: Scene Graph Matching for Data-Efficient Distributed SLAM
arXiv:2606.16881v1 Announce Type: new Abstract: We introduce a data-efficient distributed Simultaneous Localization and Mapping (SLAM) framework designed for a …
Elastic ODYN: Differentiable Optimization for Infeasible Control and Learning in Robotics
arXiv:2606.16564v1 Announce Type: new Abstract: Robotic systems routinely encounter conflicting objectives, modeling errors, and degenerate contact conditions t…
HATS: A Human-Agent Teleoperation System for Multi-Arm Data Collection
arXiv:2606.16491v1 Announce Type: new Abstract: Many real-world manipulation scenarios, such as handling complex collaborative tasks and dealing with large work…
Agile Fall Recovery for Quadrotors with Bidirectional Thrust via Reinforcement Learning
arXiv:2606.16513v1 Announce Type: new Abstract: Autonomous fall recovery is a critical capability for quadrotors operating in real-world environments, where col…
Training and Evaluating Diffusion Policies with Long Context Lengths
arXiv:2606.16447v1 Announce Type: new Abstract: Imitation learning has enabled highly-dexterous robotic manipulation from RGB observations. Policies trained wit…
Is Your Trajectory Displacement Safe in Long-tail?
arXiv:2606.16313v1 Announce Type: new Abstract: Long-tail scenarios remain a major bottleneck for autonomous driving evaluation, even as datasets grow by orders…
ATHENA: Accelerated Multi-Task Heterogeneous Influence Functions for Robot Data Curation
arXiv:2606.16208v1 Announce Type: new Abstract: In robot imitation learning, influence functions provide a principled approach to quantify each demonstration's …
A Deployment Case Study in Robotic Apparel Automation: Digital Twin Integration, Interoperability, and Workforce Enablement
arXiv:2606.16078v1 Announce Type: new Abstract: Despite steady advances in flexible automation in sectors such as electronics and automotive manufacturing, appa…
Energy-Efficient Arm Reaching for a Humanoid Robot via Deep Reinforcement Learning with Identified Power Models
arXiv:2606.15918v1 Announce Type: new Abstract: Humanoid robots performing in-field manipulation tasks, such as robotic apple harvesting, face severe energy con…
GeoTLM: Geometry-aware Tactile-Language Models for Contact Motion Orientation Reasoning of Dynamic Objects
arXiv:2606.15909v1 Announce Type: new Abstract: Modern tactile-language models (TLMs) have shown potential for robot learning tasks, such as material and textur…
Can Causal Models Enhance Robot Navigation? Online Causal Adaptation for Real-Robot Navigation
arXiv:2606.15691v1 Announce Type: new Abstract: Causality in robotics aims to produce more interpretable and flexible robot behaviours by enabling robots to pre…
FD-SLAM: Fast Dense Radar-Inertial SLAM with Frequency-Domain Loop Closure and Pose Graph Optimization
arXiv:2606.15491v1 Announce Type: new Abstract: Radar SLAM is attractive for autonomous ground vehicles operating in visually degraded environments, however, sc…
Acting While Understanding: Asynchronous Semantic-Action Decoupling for Real-Time Vision-Language-Action Models
arXiv:2606.15285v1 Announce Type: new Abstract: Vision-Language-Action models (VLAs) have demonstrated strong task understanding and generalization in robotic m…
Co-Creating Buildable and Open Social Robot Study Companions with University Students
arXiv:2606.15239v1 Announce Type: new Abstract: Open-source social robots offer accessibility, repairability, and student empowerment, yet the build itself ofte…
Rethinking Implicit Spatial Representation in Visuomotor Policy Learning
arXiv:2606.15232v1 Announce Type: new Abstract: Generative model-based imitation learning has become a widely adopted paradigm for robotic manipulation, where p…
Task-Aware Environment Augmentation for Reliable Navigation via Shielded Conditional Diffusion
arXiv:2606.15154v1 Announce Type: new Abstract: Reliable trajectory planning under partial observability depends not only on computing a feasible geometric path…
MimicIK: Real-Time Generative Inverse Kinematics from Teleoperation with FK Consistency
arXiv:2606.15148v1 Announce Type: new Abstract: Inverse kinematics (IK) remains a critical bottleneck for real-time robot manipulation. Classical numerical solv…
Exact, Efficient, and Safe Occlusion-Aware Planning Using AH-Polyhedrons
arXiv:2606.15046v1 Announce Type: new Abstract: Safely handling occlusions is a fundamental challenge for autonomous mobile robots operating in dynamic environm…
DynaHMRC: Decentralized Heterogeneous Multi-Robot Collaboration for Dynamic Tasks with Large Language Models
arXiv:2606.14882v1 Announce Type: new Abstract: Large language models (LLMs) provide robots with richer task understanding and adaptability, making them promisi…
TacStyle: Personalizing Tactile Robot Policies using Structured Behavior Representations
arXiv:2606.14862v1 Announce Type: new Abstract: Robotic systems that assist humans should be capable of adapting their behaviors to individual user preferences.…
GenZ-LIO: Generalizable LiDAR-Inertial Odometry Beyond Confined--Open Boundaries
arXiv:2603.16273v2 Announce Type: replace Abstract: For field robotic missions such as inspection, search-and-rescue, and exploration, light detection and rangi…
Evidence of an Emergent "Self" in Continual Robot Learning
arXiv:2603.24350v3 Announce Type: replace Abstract: A key challenge to understanding self-awareness has been a principled way of quantifying whether an intellig…
An Ergonomic, Customizable Soft Robotic Glove toward Personalized Hand Rehabilitation
arXiv:2604.00768v2 Announce Type: replace Abstract: Hand impairment following neurological disorders substantially limits independence in activities of daily li…
Driving, Fast or Slow? Neuro-Symbolic Guidance for Motion Prediction in Multi-Modal Ground Mobility
arXiv:2606.15251v1 Announce Type: new Abstract: Accurate and interpretable motion prediction for heterogeneous traffic spaces, including pedestrians, bicycles, …
Seam-to-Graph Reconstruction for Garment Configuration Alignment
arXiv:2606.15171v1 Announce Type: new Abstract: Seams encode rich structural information about garments but are frequently partially observable in robotic manip…
DragMesh-2: Physically Plausible Dexterous Hand-Object Interaction with Articulated Objects
arXiv:2606.15133v1 Announce Type: new Abstract: Dexterous interaction with articulated objects is important for household, assistive, and humanoid manipulation,…