News
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Daily robotics industry news: humanoids, industrial automation, drones, autonomous systems and the companies building them.
Latest in News
4147 storiesOne Demo is Worth a Thousand Trajectories: Action-View Augmentation for Visuomotor Policies
arXiv:2606.19586v1 Announce Type: new Abstract: Visuomotor policies for manipulation have demonstrated remarkable potential in modeling complex robotic behavior…
DF-ExpEnse: Diffusion Filtered Exploration for Sample Efficient Finetuning
arXiv:2606.19656v1 Announce Type: new Abstract: A natural recipe for intelligent robotic decision-making is initializing from pretrained generative control poli…
Pose6DAug: Physically Plausible Multi-view Object Swapping for Robot Data Augmentation
arXiv:2606.20118v1 Announce Type: new Abstract: Vision-language-action (VLA) policies have shown strong potential for general-purpose manipulation, yet they oft…
SCAN-Planner: Spatial Collision-Aware Local Planning for Route-Guided Long-Range Quadruped Navigation
arXiv:2606.19555v1 Announce Type: new Abstract: Quadruped robots are increasingly expected to navigate through narrow passages, cluttered indoor scenes, and lar…
A Categorial and Sheaf-Theoretic Semantics for Autonomic Component Ensembles
arXiv:2606.19525v1 Announce Type: new Abstract: The proliferation of large-scale, decentralized systems of autonomous agents, such as swarms of robots and netwo…
SWAP: Symmetric Equivariant World-Model for Agile Robot Parkour
arXiv:2606.19928v1 Announce Type: new Abstract: While latent world models enable the proactive predictions required for extreme parkour, their purely data-drive…
World Engine: Towards the Era of Post-Training for Autonomous Driving
arXiv:2606.19836v1 Announce Type: new Abstract: Autonomous vehicles must operate safely in the real world, where errors can have severe consequences. Although m…
Proprioceptive Invariant State Estimation for Humanoid Robots on Non-Inertial Ground
arXiv:2606.19512v1 Announce Type: new Abstract: This paper presents an invariant extended Kalman filtering (InEKF) approach for real-time state estimation of hu…
Co-VLA: Coordination-Aware Structured Action Modeling for Dual-Arm Vision-Language-Action Systems
arXiv:2606.20285v1 Announce Type: new Abstract: Vision-language-action (VLA) models show strong capabilities in single and dual-arm robotic manipulation. Prior …
EquiVLA: A General Framework for Rotationally Equivariant Vision-Language-Action Models
arXiv:2606.19784v1 Announce Type: new Abstract: Vision-Language-Action (VLA) models have emerged as a powerful paradigm for generalist robot manipulation, yet t…
CoMo: Learning Continuous Latent Motion from Internet Videos for Scalable Robot Learning
arXiv:2505.17006v3 Announce Type: replace-cross Abstract: Unsupervised learning of latent motion from Internet videos is crucial for robot learning. Existing di…
Superhuman Safe and Agile Racing through Multi-Agent Reinforcement Learning
arXiv:2605.22748v2 Announce Type: replace Abstract: Autonomous systems have achieved superhuman performance in isolation or simulation, yet they remain brittle …
Humanoid Everyday: A Comprehensive Robotic Dataset for Open-World Humanoid Manipulation
arXiv:2510.08807v2 Announce Type: replace Abstract: From loco-motion to dextrous manipulation, humanoid robots have made remarkable strides in demonstrating com…
Robust Convex Model Predictive Control with collision avoidance guarantees for robot manipulators
arXiv:2508.21677v3 Announce Type: replace Abstract: Industrial manipulators typically operate in cluttered environments, where safe motion planning is critical.…
Evaluation of Augmented Reality-based Intuitive Interface for Robot-Assisted Transesophageal Echocardiography: A User Study
arXiv:2606.19971v1 Announce Type: new Abstract: TransEsophageal Echocardiography (TEE) is essential for diagnosing and guiding Structural Heart Disease (SHD) in…
Periodic robust robotic rock chop via virtual model control
arXiv:2508.02604v3 Announce Type: replace Abstract: Robotic cutting is a challenging, contact-rich manipulation task where the robot must simultaneously negotia…
Comparative Study on Agility, Efficiency, and Impact Absorption of Bipedal Robots with Active Toes
arXiv:2606.19699v1 Announce Type: new Abstract: Human legs exhibit high efficiency, agility, and impact absorption, with toes playing a crucial role in these ca…
Reinforcement Twinning for Hybrid Control of Flapping-Wing Drones
arXiv:2505.18201v2 Announce Type: replace Abstract: Controlling flapping-wing drones requires controllers that handle time-varying, nonlinear, underactuated dyn…
Fail-RAG : A Retrieval Augmented Generation Informed Framework for Robot Failure Identification
arXiv:2606.19598v1 Announce Type: new Abstract: Industry automation is witnessing an evolution in robotics driven by both technological breakthroughs and societ…
pdSTL: Probabilistic Differentiable Signal Temporal Logic for Stochastic Systems
arXiv:2606.19561v1 Announce Type: new Abstract: Autonomous robots operating in uncertain environments must satisfy complex temporal and safety specifications de…
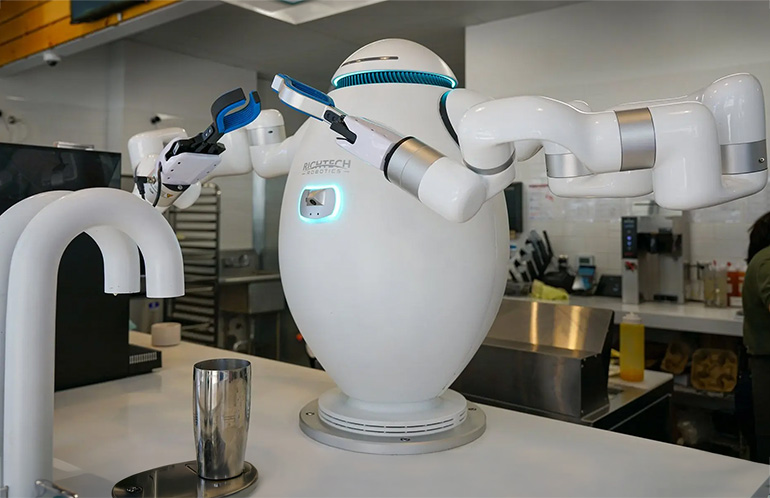
Richtech Robotics launches livestream for ADAM AI-powered humanoid
Online users will be able to engage with service robot ADAM, which uses NVIDIA technology, says Richtech Robotics. The post Richtech Robotics launches livestrea…
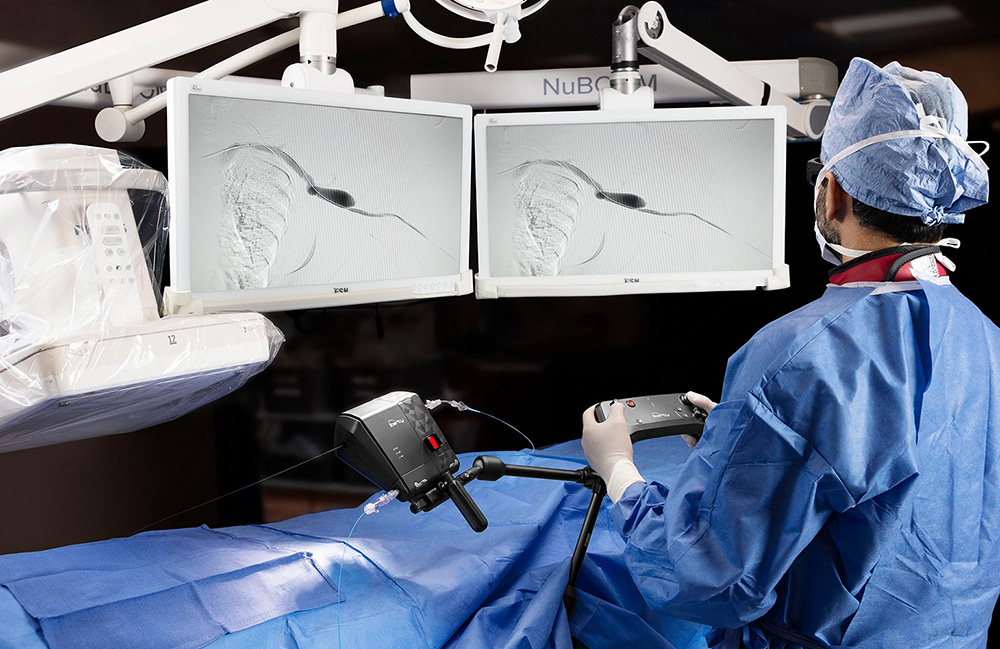
Microbot Medical to expand veteran access to robotic surgery with LIBERTY
Lovell Government Services will become Microbot's service-disabled veteran-owned small business vendor to supply federal programs. The post Microbot Medical to …
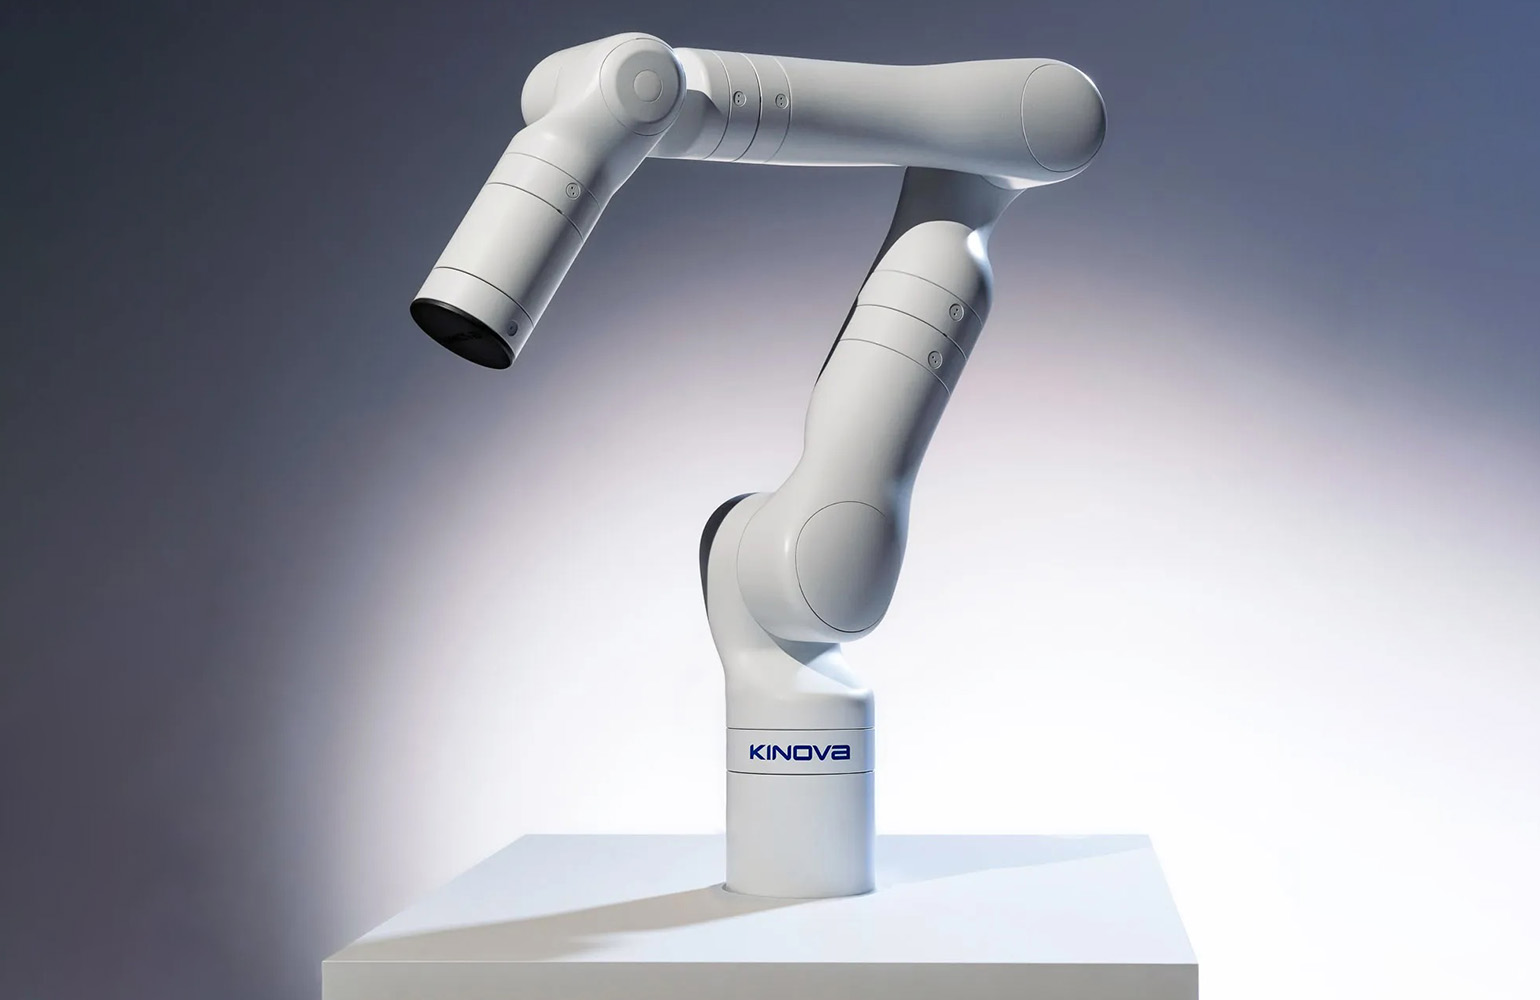
Kinova launches KIMA medical robotic arm
Instead of adapting the robot from industrial technology, Kinova said it designed KIMA from the ground up for clinical use. The post Kinova launches KIMA medica…
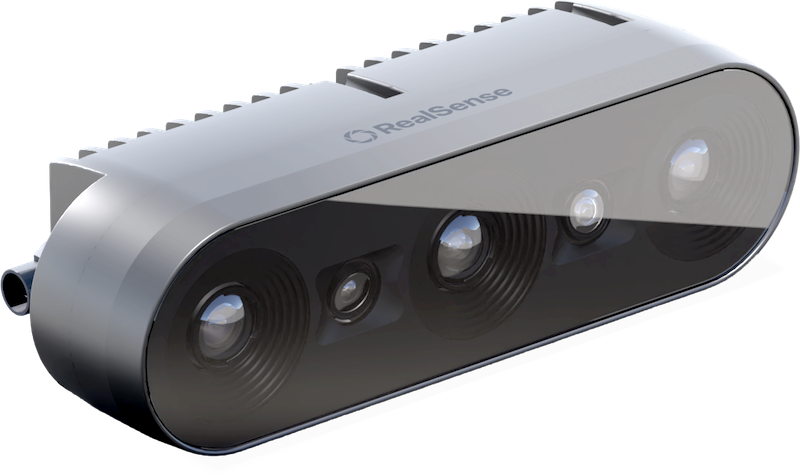
RealSense unveils AI-native D585 Pro depth camera for robots
The D585 Pro is powered by a proprietary Gen 5 system-on-chip and delivers more than 2x better depth quality than the previous generation of RealSense cameras. …
Mem-World: Memory-Augmented Action-Conditioned World Models for Persistent Robot Manipulation
arXiv:2606.18960v1 Announce Type: cross Abstract: Action-conditioned world models have emerged as a promising paradigm for robot learning, offering a scalable a…
Steering Flexible Linear Objects in Planar Environments by Two Robot Hands Using Euler's Elastica Solutions
arXiv:2501.02874v5 Announce Type: replace Abstract: The manipulation of flexible objects such as cables, wires and fresh food items by robot hands forms a speci…
R2BC: Multi-Agent Imitation Learning from Single-Agent Demonstrations
arXiv:2510.18085v2 Announce Type: replace Abstract: Imitation Learning (IL) is a natural way for humans to teach robots, particularly when high-quality demonstr…
Bench-Push: Benchmarking Pushing-based Navigation and Manipulation Tasks for Mobile Robots
arXiv:2512.11736v2 Announce Type: replace Abstract: Mobile robots are increasingly deployed in cluttered environments with movable objects, posing challenges fo…
Benchmarking Action Spaces in Reinforcement Learning for Vision-based Robotic Manipulation
arXiv:2606.18594v1 Announce Type: new Abstract: In real-world reinforcement learning (RL), the choice of action space can play a key role in shaping motion smoo…
SRL: Combining SLIP Model and Reinforcement Learning for Agile Robotic Jumping
arXiv:2606.18625v1 Announce Type: new Abstract: Robotic jumping is pivotal in applications such as search and rescue and logistics, where crossing obstacles and…