Research
Frontier robotics research: arXiv cs.RO papers, embodied AI, VLA models, manipulation, navigation and learning systems.
Frontier robotics research: arXiv cs.RO papers, embodied AI, VLA models, manipulation, navigation and learning systems.
Latest in Research
6273 storiesMistyPilot: Enabling Social-Robot Control through Multi-Agent LLM Skill Orchestration
arXiv:2608.15549v1 Announce Type: new Abstract: Programming small social robots from natural-language instructions requires more than invoking isolated APIs. In…
Temporal Logic Guided Universal Task Representations for Reinforcement Learning
arXiv:2608.15509v1 Announce Type: new Abstract: Task guided agents demonstrate strong performance in a wide range of complex tasks. However, most existing task …
Detachable Wire Drive : Reconfigurable Robot Architecture with Shared Actuators
arXiv:2608.15461v1 Announce Type: new Abstract: Reconfigurable robots offer significant potential for adapting to diverse tasks; however, conventional centraliz…
GUIDER: Evaluating Goal-Free Human Intent Inference for Teleoperated Manipulation on Real-Robot Data
arXiv:2608.15446v1 Announce Type: new Abstract: This paper presents an evaluation of a goal-free probabilistic framework for human intent inference during robot…
VTInstructor: Visual Trajectory Prompting for Navigation Instruction Generation in Continuous Environments
arXiv:2608.15284v1 Announce Type: new Abstract: Navigation instruction generation from ego-centric RGB video in continuous environments is an important yet chal…
Remember Smarter: Visual History Compressor and Hyperbolic Experience Space for Robotic Memory
arXiv:2608.15269v1 Announce Type: new Abstract: Long-horizon robot policies require compact access to recent observations and reusable experience without expand…
Low-Rank Dynamics-Effective Latent Carriers for Counterfactual Rollout in Learned World Models
arXiv:2608.15156v1 Announce Type: new Abstract: World models may predict the future without making clear which parts of their hidden state actually drive those …
StructRL: Structured Action-Space Exploration for Flow-Based VLAs
arXiv:2608.15139v1 Announce Type: new Abstract: Flow-based Vision-Language-Action (VLA) models are now widely used for continuous robotic manipulation, and onli…
From Continuous Design to Delay-Aware Discrete Synthesis: Guaranteed High-Bandwidth Joint Control for PMSM Drives
arXiv:2608.14937v1 Announce Type: new Abstract: The increasing dynamic demands of modern robotic joints require current controllers to achieve high bandwidth ov…
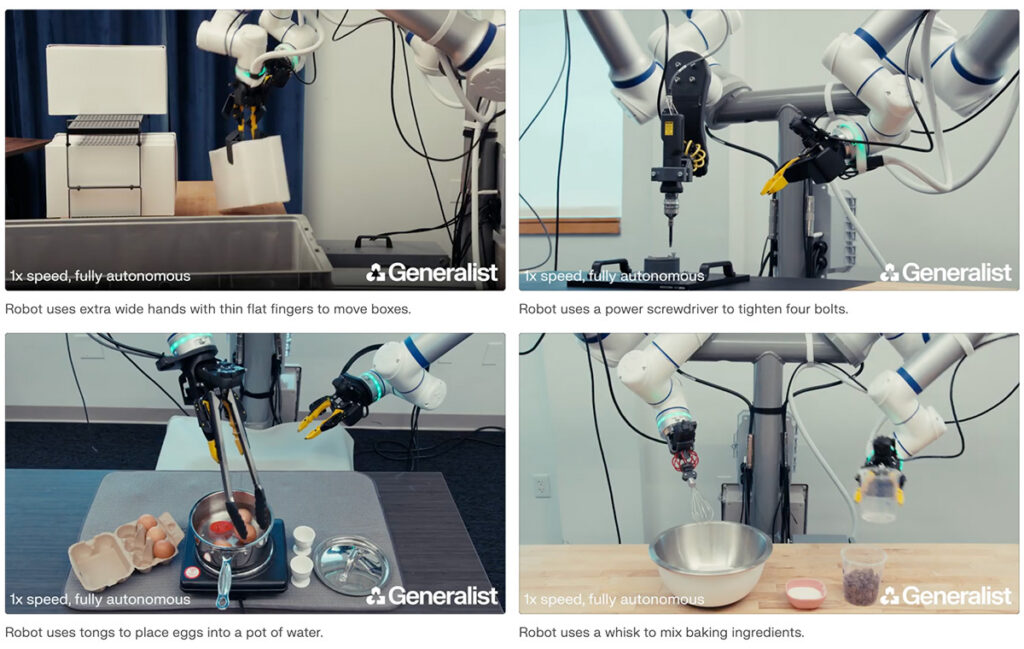
How Generalist uses human demonstration data for robot learning
Research around the Universal Manipulation Interface is enabling Generalist, Walden Robotics, and others to turn data into robot behaviors. The post How General…
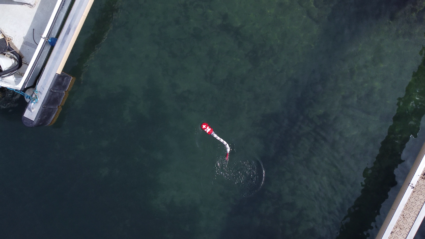
Intermittent swimming promotes the energy efficiency of fish-like robot movements
Image credits: Xiangxiao Liu, Francois A. Longchamp, and Louis GeverBiorobotics Laboratory, EPFL Improving energy performance can effectively extend the time a …
Coverage Aware Active Evaluation for Failure Discovery with Paired Systems
arXiv:2608.13719v1 Announce Type: cross Abstract: Autonomous systems can fail in rare and heterogeneous ways, making real-world failure discovery difficult unde…
Simulation-Aware In-Context Policy Improvement for LLM-Aided Analog Layout Refinement
arXiv:2608.13767v1 Announce Type: cross Abstract: Analog IC layout design remains a labor-intensive iterative process dominated by simulation-driven refinement.…
MorphIt: Flexible Spherical Approximation of Robot Morphology for Representation-driven Adaptation
arXiv:2507.14061v3 Announce Type: replace Abstract: What if a robot could rethink its own morphological representation to better meet the demands of diverse tas…
AtomBridge: Agentic VLA Inference Plugin for Long-Horizon Tasks in Scientific Experiments
arXiv:2602.09430v2 Announce Type: replace Abstract: Robotic laboratories play a critical role in autonomous scientific discovery by enabling scalable, continuou…
CoViLLM: An Adaptive Human-Robot Collaborative Assembly Framework Using Large Language Models
arXiv:2603.11461v3 Announce Type: replace Abstract: With increasing demand for mass customization, traditional manufacturing robots that rely on rule-based oper…
How to Relieve Distribution Shifts in Semantic Segmentation for Off-Road Environments
arXiv:2605.29599v2 Announce Type: replace Abstract: Semantic segmentation is crucial for autonomous navigation in off-road environments, enabling precise classi…
A Data-Driven Algorithm for Model-Free Control Synthesis
arXiv:2602.13157v2 Announce Type: replace-cross Abstract: Presented is an algorithm to synthesize the optimal infinite-horizon LQR feedback controller for conti…
HierDAMap: Towards Universal Domain Adaptive BEV Mapping via Hierarchical Perspective Priors
arXiv:2503.06821v2 Announce Type: replace-cross Abstract: The exploration of Bird's-Eye View (BEV) mapping technology has driven significant innovation in visua…
Versatile Exoskeleton Control Supports Elderly Joint Energetics During Hip-Intensive Tasks
arXiv:2603.22580v2 Announce Type: replace Abstract: Age-related mobility decline is frequently accompanied by a redistribution of joint kinetics, where older ad…
Effective Game-Theoretic Motion Planning via Nested Search
arXiv:2511.08001v3 Announce Type: replace Abstract: To facilitate effective, safe deployment in the real world, individual robots must reason about interactions…
Two-dimensional time-to-collision measures for articulated vehicles: predicting sideswipe and rear-end collisions
arXiv:2507.04184v3 Announce Type: replace Abstract: Time-to-collision is a commonly employed measure for rear-end collision prediction. However, its conventiona…
LLM-Advisor: An LLM Advisor for Cost-efficient Path Planning across Multiple Terrains
arXiv:2503.01236v3 Announce Type: replace Abstract: This paper addresses fixed-graph terrain-aware path refinement, in which a global planner is restricted to a…
Active Perception for Embodied Disambiguation
arXiv:2608.13605v1 Announce Type: cross Abstract: Natural language provides robots with a flexible task interface, but target ambiguity in embodied environments…
Ensuring Safe Physical AI in Urban Mobility via Hazard-Informed Synthesized Envelopes
arXiv:2608.14481v1 Announce Type: new Abstract: As heterogeneous robotic systems deploy across diverse urban zones, maintaining safety amid complex human-robot …
Effect of Twisted-Yarn Architecture on Pressure and Proximity Sensing Characteristics of Textile Capacitive Sensors for Robotic Skin
arXiv:2608.14406v1 Announce Type: new Abstract: Textile-integrated capacitive sensors offer flexible and conformable tactile sensing for wearable electronics an…
Reflex: Enabling Fast and Predictive Vision-Language-Action Models for Reaction-Critical Manipulation
arXiv:2608.14379v1 Announce Type: new Abstract: Vision-Language-Action (VLA) models have recently achieved promising performance in robotic manipulation. Howeve…
CORAL: Curriculum-Optimized Reward Adaptation for LiDAR-Based Goal-Directed Urban Driving
arXiv:2608.14332v1 Announce Type: new Abstract: Reinforcement learning is promising for autonomous urban driving, but long-horizon goal-directed navigation asks…
Vibration Suppression in Collaborative Flexible Payload Manipulation Using Passive Force Control
arXiv:2608.14244v1 Announce Type: new Abstract: In large and heavy structures, vibrations arise during motion, posing significant challenges for precise manipul…
Evolve Vision-Language-Action Model into an Agent with On-the-fly Tool-use
arXiv:2608.14047v1 Announce Type: new Abstract: This paper integrates end-to-end Visual-Language-Action (VLA) models with agentic tool-use to propose Agentic Ro…