Research
Frontier robotics research: arXiv cs.RO papers, embodied AI, VLA models, manipulation, navigation and learning systems.
Frontier robotics research: arXiv cs.RO papers, embodied AI, VLA models, manipulation, navigation and learning systems.
Latest in Research
6273 storiesJust Noticeable Difference Modeling for Token Compression in Vision-Language-Action Models
arXiv:2608.21247v1 Announce Type: cross Abstract: Token compression has become a key technique for reducing the inference cost of large foundation models, with …
Graph-Operator World Models for Morphology-Parameter Generalization in Continuous Control
arXiv:2608.20936v1 Announce Type: cross Abstract: World models for continuous control are commonly trained for a fixed physical system and can degrade when know…
A Safety-Driven Architectural Framework for Fail-Operational Drone Swarms in Critical Missions
arXiv:2608.20906v1 Announce Type: cross Abstract: The certification of Unmanned Aerial Vehicle (UAV) swarms for safety-critical operations requires verifiable d…
Multi-Modal Traffic Sign Detection with Semantic Attributes for Autonomous Driving
arXiv:2608.20874v1 Announce Type: cross Abstract: Reliable traffic sign detection is a prerequisite for the global deployment of autonomous driving systems, whe…
GhostTac: Manipulating Tactile Sensors without Physical Contact
arXiv:2608.20817v1 Announce Type: cross Abstract: Tactile sensors are integral to modern robotic systems, enabling robots to perceive and interact with the phys…
Learning-Based Measurement-Robust Control Barrier Functions for Obstacle Avoidance under State Estimation Error
arXiv:2608.20467v1 Announce Type: cross Abstract: Safety filters are an effective tool for enforcing constraints in safety-critical systems, but most existing m…
ViTacPhys: Physical Property-Aware Grasping from Human Visual-Tactile Demonstrations
arXiv:2608.21355v1 Announce Type: new Abstract: Recent vision-based action models have demonstrated strong capabilities in complex manipulation, but they rarely…
SRL-MPC: Shape-Aware Reinforcement Learned Model Predictive Control
arXiv:2608.21175v1 Announce Type: new Abstract: Safe and efficient shape-aware navigation in heterogeneous crowds and robot fleets remains challenging. Traditio…
FF-MPCC: High-speed Agile Formation Flight with Model Predictive Contouring Control
arXiv:2608.21056v1 Announce Type: new Abstract: Flying in a prescribed formation in an agile manner remains a challenging problem in the field of UAVs, particul…
TaPeR: Probabilistic Recovery of Sparse Task Precedence Graphs from a Handful of Demonstrations
arXiv:2608.21035v1 Announce Type: new Abstract: Long-horizon manipulation tasks are often only partially ordered. For example, when assembling an electronic dev…
Neural-Primitive: An Efficient End-to-end Local Planner with Primitive-based Imitation Learning for Autonomous Flight
arXiv:2608.20948v1 Announce Type: new Abstract: Autonomous flight in unknown cluttered environments is hindered by the computation-quality-memory trilemma of on…
Fast Coordinated Bimanual Motion Planning With Hard Constraints
arXiv:2608.20946v1 Announce Type: new Abstract: Bimanual manipulation enables complex tasks but introduces added complexity from the high number of degrees of f…
Hybrid Roller-Jamming Gripper for Object Acquisition and Retention Under Pose Uncertainty
arXiv:2608.20962v1 Announce Type: new Abstract: In household manipulation, pose uncertainty often results in off-centre or partial initial contact, making relia…
Scalable Distributed Simulation-Based Testing for Automated Driving Systems
arXiv:2608.20904v1 Announce Type: new Abstract: Virtual scenario-based testing is a key enabler for validating automated driving systems (ADS) and intelligent t…
Natural Sit-to-Stand Motion Synthesis For Humanoids via Guided Assistance Curricula and Staged Rewards
arXiv:2608.20823v1 Announce Type: new Abstract: A humanoid has infinitely many ways to stand up from sitting while maintaining balance, making sit-to-stand (STS…
Logic-VLA: A Temporal Logic Conditioned Vision-Language-Action Model
arXiv:2608.20556v1 Announce Type: new Abstract: Vision-language-action (VLA) models can follow natural-language (NL) task instructions, but such instructions ma…
Roadside-Cooperative Autonomous Driving: From Data Platform to Vision-Language End-to-End Reasoning
arXiv:2608.21032v1 Announce Type: new Abstract: Vehicle-to-Everything (V2X) cooperation enables beyond-line-of-sight perception, mitigating occlusions in single…
Teaching is a Process: The TOSS Framework for Modeling Human Teaching Decisions in Human-Interactive Robot Learning
arXiv:2608.21083v1 Announce Type: new Abstract: Successful Human-Robot Teaching assumes alignment between robot processing needs and human teaching intent. To b…
ForeTime-VLA: Causal Future-Token Distillation from a World Action Model for Conveyor-Belt Manipulation
arXiv:2608.20735v1 Announce Type: cross Abstract: Manipulating moving objects requires a policy to anticipate contact events, yet vision-language-action (VLA) p…
Rapid Manufacturing of Lightweight Drone Frames Using Single-Tow Architected Composites
arXiv:2509.09024v2 Announce Type: replace Abstract: The demand for lightweight and high-strength composite structures is rapidly growing in aerospace and roboti…
NeSAM: Neuro-Symbolic Kinodynamics with Soil Adaptation for Off-Road Mobility
arXiv:2608.21330v1 Announce Type: new Abstract: Accurate prediction of off-road vehicle motion over deformable terrain remains challenging because sinkage, slip…
The Coastline as a Structural Constraint: Harnessing Scene Geometry for Autonomous Surface Vessel Localization
arXiv:2608.21276v1 Announce Type: new Abstract: Coastal environments contain rich, largely unexploited geometric structure capable of providing globally referen…
PhysCaP: Grounding Code-as-Policy Agent with Physics-Informed Exploration
arXiv:2608.21031v1 Announce Type: new Abstract: We present PhysCaP, a Physics-Informed Code-as-Policy agent for active perception in robotic manipulation. While…
IMU-Free Body-Frame State Estimation with Sparse Scene Flow for Quadcopters
arXiv:2608.20891v1 Announce Type: new Abstract: We present a vision-only state estimation system for X-configuration quadcopters equipped with a canonical stere…
Rethinking Demonstration Unlearning in Imitation Learning for Robotics
arXiv:2608.20784v1 Announce Type: new Abstract: Imitation learning for robotics depends on human demonstrations, some of which people may later ask to remove. R…
Koala Gripper: Co-designing Robotic Grippers and Data-Capture Devices for Scaling Dexterous Manipulation Learning
arXiv:2608.20546v1 Announce Type: new Abstract: As the demand for larger manipulation datasets grows, handheld robotic gripper data collection and the associate…
Humanoid Musical Robots as Experimental Interfaces for Music-Evoked Emotion
arXiv:2608.20433v1 Announce Type: new Abstract: Advances in technology have led to increasingly sophisticated musical humanoid robots. However, their use has la…
A hidden “on switch” in human DNA has finally been decoded
Researchers have used AI to uncover the DNA signature of a key genetic “switch” involved in turning genes on. After analyzing about 500,000 DNA sequences, the m…
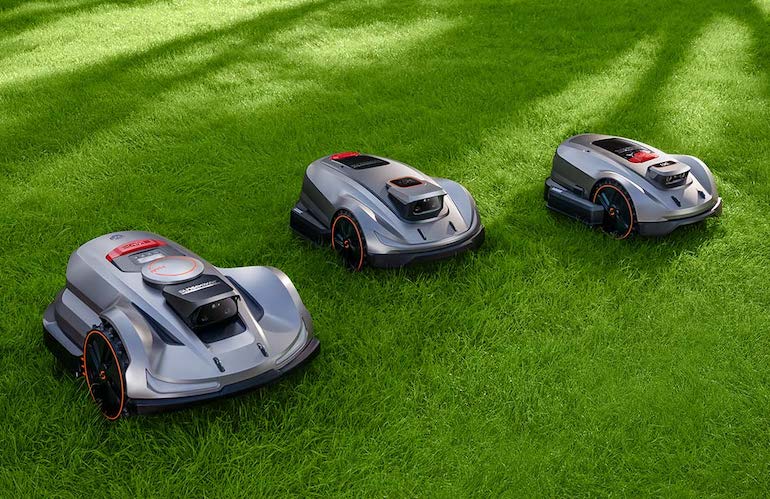
The technology that could bring robot mowers to one in two American lawns
Improvements in AI, satellite navigation, and machine vision are helping robotic lawn mowers spread in the U.S., writes Sunseeker's founder. The post The techno…
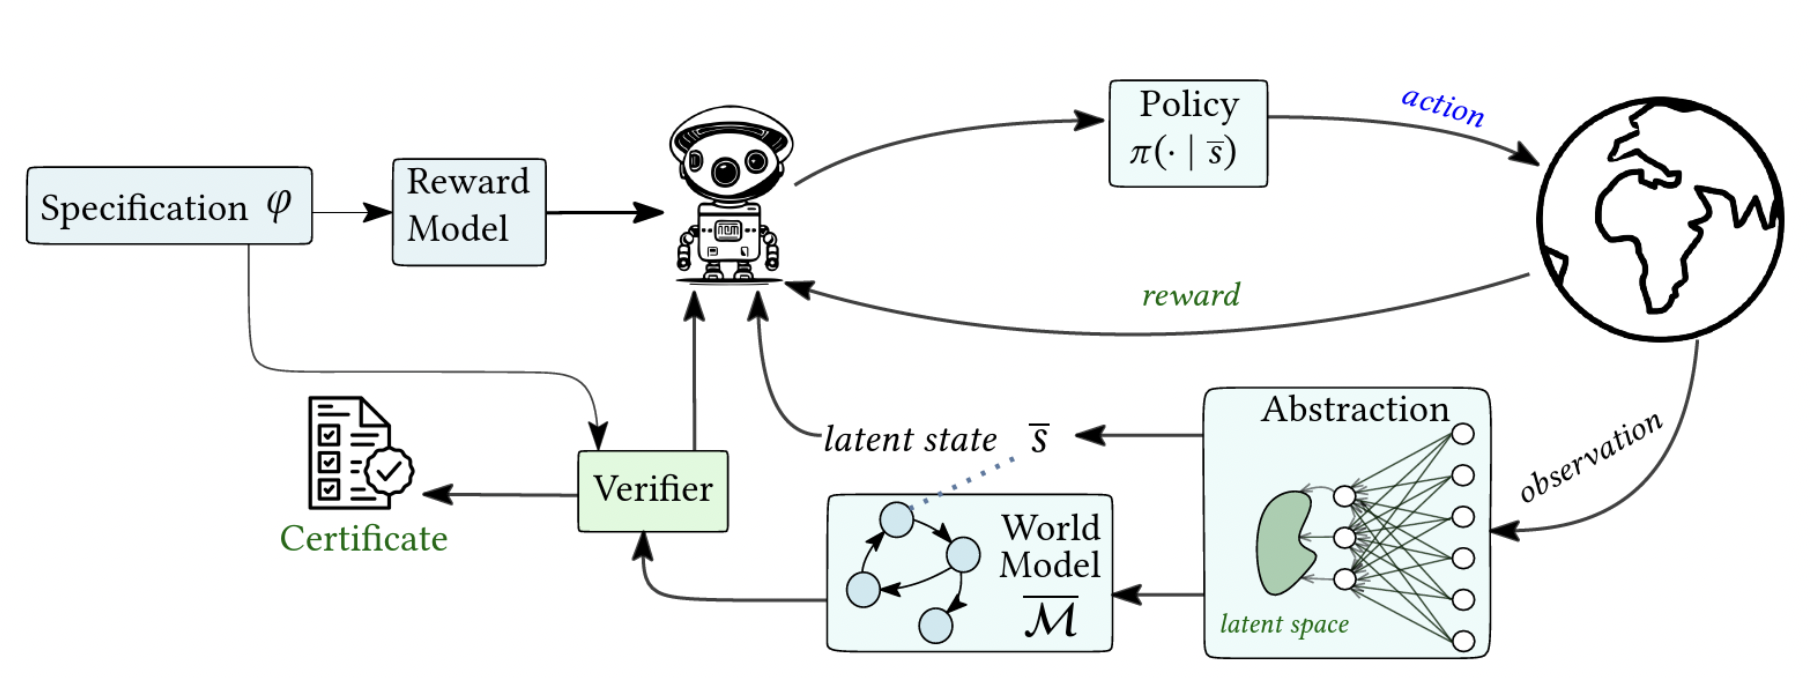
#AAMAS2026 blue sky award winner: Foundation world models for agents in changing environments
Florent Delgrange won the Best Blue Sky Paper Award at AAMAS 2026 for his work Foundation World Models for Agents that Learn, Verify, and Adapt Reliably Beyond …