Research
Frontier robotics research: arXiv cs.RO papers, embodied AI, VLA models, manipulation, navigation and learning systems.
Frontier robotics research: arXiv cs.RO papers, embodied AI, VLA models, manipulation, navigation and learning systems.
Latest in Research
6273 storiesReal-Time Shape Control of Multi-Segment Soft Robotic Arms Using Koopman Operators with Global and Local Observables
arXiv:2609.03175v1 Announce Type: new Abstract: Multi-segment soft robotic arms can continuously reconfigure their body shapes for safe interaction, but tip con…
R2S-Eval: Robot Evaluation with Real-to-Sim Calibration via Vision-Language Models
arXiv:2609.03276v1 Announce Type: new Abstract: Evaluating robot manipulation policies is becoming increasingly important as generalist models, particularly vis…
WISE: World-model-guided Imagination Scheduling for Efficient Post-training of Vision-Language-Action Models
arXiv:2609.03681v1 Announce Type: new Abstract: Post-training VLA policies typically rely on supervised fine-tuning with costly expert demonstrations or reinfor…
GIFT: Guided Intermediate Feature Training via Action-Oriented Structural Supervision for Robotic Manipulation
arXiv:2609.04193v1 Announce Type: new Abstract: Vision-language pre-training and predictive world modeling provide robot policies with rich semantic and dynamic…
One Demonstration, Many Objects: Generalizing Manipulation via Local Contact Geometry
arXiv:2609.01938v2 Announce Type: replace Abstract: Dexterous manipulation with multi-fingered robot hands promises human-level dexterity, but collecting large-…
Towards Lifelong Aerial Autonomy: Geometric Memory Management for Continual Visual Place Recognition in Dynamic Environments
arXiv:2604.09038v2 Announce Type: replace Abstract: Robust geo-localization under changing environmental and operational conditions is critical for long-term ae…
Highly Deformable Proprioceptive Membrane for Real-Time 3D Shape Reconstruction
arXiv:2601.13574v3 Announce Type: replace Abstract: Reconstructing the three-dimensional (3D) geometry of object surfaces is essential for robot perception, yet…
A Quantitative Comparison of Centralised and Distributed Reinforcement Learning-Based Control for Soft Robotic Arms
arXiv:2511.02192v3 Announce Type: replace Abstract: This paper presents a quantitative comparison between centralised and distributed multi-agent reinforcement …
Vision-Based Tactile Sensing for the Perception of the Object's Compliance and Hardness
arXiv:2510.12528v2 Announce Type: replace Abstract: Object compliance perception enables the identification of soft materials, supporting tasks such as fruit de…
LightEMMA: A Longitudinal Evaluation of Vision-Language Models for Autonomous Driving
arXiv:2505.00284v3 Announce Type: replace Abstract: Rapid advances in vision-language models (VLMs) have generated growing interest in their application to auto…
DogLegs: Robust Proprioceptive State Estimation for Legged Robots Using Multiple Leg-Mounted IMUs
arXiv:2503.04580v3 Announce Type: replace Abstract: Robust and accurate proprioceptive state estimation of the main body is crucial for legged robots to execute…
Dancing with REEM-C: A robot-to-human physical-social communication study
arXiv:2408.05301v3 Announce Type: replace Abstract: Humans often work closely together and relay a wealth of information through physical interaction. Robots, o…
Subspace Inference Enables Efficient Active Reward Learning from Preferences
arXiv:2609.04066v1 Announce Type: cross Abstract: Reinforcement learning from human feedback (RLHF) has emerged as a powerful yet sample-inefficient approach fo…
Rethinking World Models for Safety-Critical Embodied Systems
arXiv:2609.03774v1 Announce Type: cross Abstract: World models have progressed from compact latent dynamics to generative, controllable, and interactive simulat…
RoboTok: An Internet-Scale Data Engine for Human Demonstration Retrieval and Dexterous Manipulation Learning
arXiv:2609.03199v1 Announce Type: cross Abstract: Robot learning increasingly depends on broad and diverse demonstrations, yet collecting robot data remains exp…
SV-WAM: An Efficient Surround-View World-Action Model for End-to-End Autonomous Driving
arXiv:2609.03602v1 Announce Type: cross Abstract: World models (WMs) have demonstrated strong potential for end-to-end autonomous driving by learning predictive…
MulDP: Multimodal Diffusion Policy for Autonomous Quadruped Parkour Navigation across Complex Terrains
arXiv:2609.03984v1 Announce Type: new Abstract: Quadruped robots have demonstrated impressive agility in parkour locomotion across complex terrains. However, mo…
Automated Weld Seam Recognition and 3D Mapping for Robotic Post Processing Using Photogrammetry and Semantic Segmentation
arXiv:2609.03970v1 Announce Type: new Abstract: Accurate identification of weld seam geometries is essential for automated robotic post processing operations su…
Robot Aware Computational Design of Object Specific Passive Grippers for Additive Manufacturing
arXiv:2609.03761v1 Announce Type: new Abstract: This paper presents an end-to-end computational pipeline that converts a selected object mesh, a measured object…
Predictive Zonotope Reduction: Precise Runtime Monitoring under Uncertainty
arXiv:2609.03699v1 Announce Type: new Abstract: Robots operating in physical environments make control decisions based on uncertain sensor measurements, which c…
FailBench: How Reliable are VLMs at Judging Robot Task Success?
arXiv:2609.03611v1 Announce Type: new Abstract: Vision-Language Models (VLMs) are increasingly used to evaluate robot manipulation outcomes, but existing benchm…
Toward Physically Grounded JEPA World Models for Goal-Conditioned Robotic Planning
arXiv:2609.03565v1 Announce Type: new Abstract: Action-conditioned JEPA world models enable planning toward visually specified goals without reconstructing futu…
TRaIL-Odom: Tightly Coupled Continuous Time Radar-IMU-LiDAR Odometry with Adaptive Doppler Weighting
arXiv:2609.03561v1 Announce Type: new Abstract: Existing radar-LiDAR fusion methods rely on fixed residual weights, even though the informativeness of radar Dop…
ARTiS: An Adaptive Robotic Gripper for Enhanced Tool Manipulation in Disassembly Applications
arXiv:2609.03362v1 Announce Type: new Abstract: Grasping and holding tools while using them presents a considerable challenge not only for robots but also for h…
Following a Unique Path: A Fast Certifier Applied to Outlier-Robust Pose Registration
arXiv:2609.03222v1 Announce Type: new Abstract: Certifiable methods have arisen as a means to guarantee global optimality of solutions to non-convex problems us…
Seeing Less Is Not Seeing Safely: Privacy Leakage from Task-Scoped Robot Perception Exports
arXiv:2609.03055v1 Announce Type: new Abstract: Domestic robots rely on rich perception to operate in private homes, but privacy risk persists even when raw sen…
NVIDIA plans to acquire Hugging Face and keep AI development platform open
NVIDIA is already a major model contributor to Hugging Face, which recently surpassed 1 million datasets. The post NVIDIA plans to acquire Hugging Face and keep…
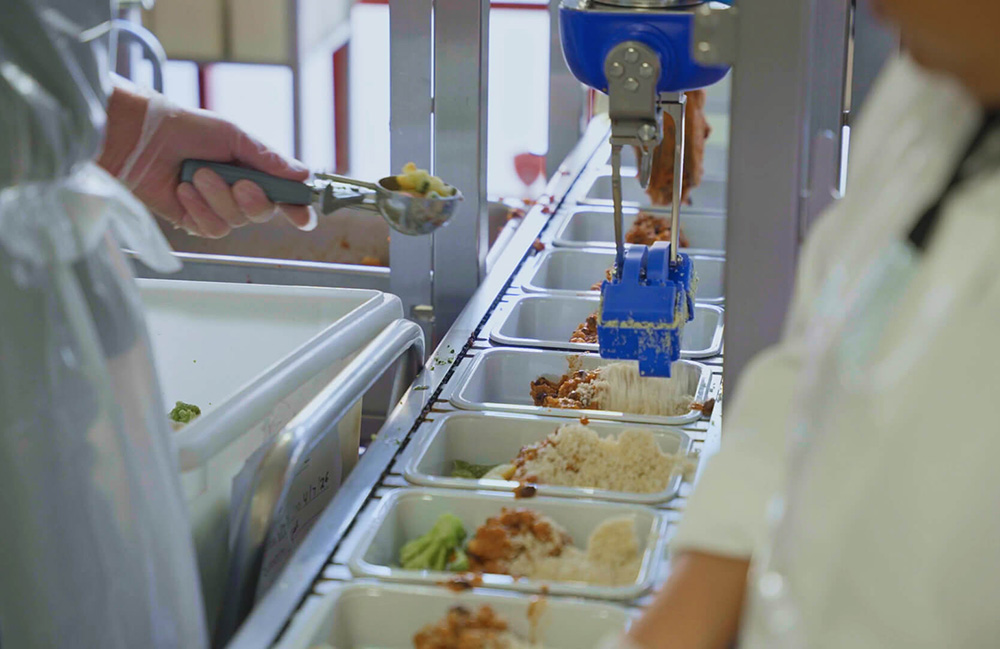
Learn why food is physical AI’s hardest problem at RoboBusiness
Rajat Bhageria, the founder and CEO of Chef Robotics, will explore what makes food such a demanding benchmark for physical AI. The post Learn why food is physic…
Surviving the paper deluge: Notes from an ICRA panel on publishing, LLMs, and the future of peer review
A recent ICRA panel titled “Surviving the Paper Deluge” brought together leading robotics researchers who have grappled with the overwhelming number of robotics…
Scene Graph-based Driving Scenario Extraction for Automotive Egocentric Datasets
arXiv:2609.00333v1 Announce Type: new Abstract: Extracting scenarios from unlabelled real-world sensor data streams is a critical but challenging task in the de…