Research
Frontier robotics research: arXiv cs.RO papers, embodied AI, VLA models, manipulation, navigation and learning systems.
Frontier robotics research: arXiv cs.RO papers, embodied AI, VLA models, manipulation, navigation and learning systems.
Latest in Research
6171 storiesUrban Deceleration Behavior Modes Under Scene Context: An Early-Kinematic Classifier from Argoverse 2 Multi-Agent Trajectories
arXiv:2607.00027v1 Announce Type: new Abstract: Urban deceleration is one of the most empirically studied yet least taxonomically organized behaviors in car-fol…
Learning Dexterous Manipulation Using Contact Wrench Guidance From Human Demonstration
arXiv:2607.00033v1 Announce Type: new Abstract: Dexterous robot manipulation can benefit from the abundance of human demonstrations, but transferring such demon…
ASPIRE: Agentic /Skills Discovery for Robotics
arXiv:2607.00272v1 Announce Type: new Abstract: Traditional robot programming is challenging: it requires orchestrating multimodal perception, managing physical…
Unleashing More Actions via Action Compositional Training for VLA Models
arXiv:2607.00351v1 Announce Type: new Abstract: Vision-Language-Action models excel at robotic manipulation, driven by the scale and diversity of demonstration …
GPU-Parallel Linearization Error Bounds for Real-Time Robust Optimal Control of Nonlinear and Neural Network Dynamics
arXiv:2607.01203v1 Announce Type: cross Abstract: This paper studies real-time robust optimal control for uncertain nonlinear systems, where linear time-varying…
Technical Report: Asynchronous Distributed Trajectory Estimation of Multi-Robot Systems
arXiv:2607.01106v1 Announce Type: new Abstract: Distributed trajectory estimation arises in many applications across robotics, but existing implementations typi…
Sensorless Four-Channel Control Architecture Using Inverse Dynamics Modeling for Human-Scale Bilateral Teleoperation
arXiv:2607.01201v1 Announce Type: new Abstract: The four-channel teleoperation architecture is a well-established framework for achieving transparency in bilate…
AD-MPCC: Adaptive Differentiable Model Predictive Contouring Control for Autonomous Racing
arXiv:2607.00141v1 Announce Type: new Abstract: This paper presents Adaptive Differentiable Model Predictive Contouring Control (AD-MPCC), a framework for auton…
E-TIDE: Fast, Structure-Preserving Motion Forecasting from Event Sequences
arXiv:2603.27757v2 Announce Type: replace-cross Abstract: Event-based cameras capture visual information as asynchronous streams of per-pixel brightness changes…
Joint Discovery of Object and Action Symbols through Effect Prediction for Robotic Manipulation Planning
arXiv:2607.00031v1 Announce Type: new Abstract: To perform complex manipulation planning, autonomous robots are required to abstract continuous, high-dimensiona…
REALM: An RGB- and Event-Aligned Latent Manifold for Cross-Modal Perception
arXiv:2605.00271v3 Announce Type: replace-cross Abstract: Event cameras provide several unique advantages over standard frame-based sensors, including high temp…
FAR: Failure-Aware Retry for Test-Time Recovery and Continual Policy Improvement
arXiv:2607.01111v1 Announce Type: new Abstract: Robot policies inevitably encounter failures when deployed in real environments. Naive retries often repeat the …
Invariant Stochastic Filtering on SE(3) for Inertial-Encoder State Estimation of Serial Rigid Manipulators
arXiv:2607.00026v1 Announce Type: new Abstract: An invariant extended Kalman filter (IEKF) is developed for state estimation of serial rigid manipulators with a…
Tendon-Actuated Robots with a Tapered, Flexible Polymer Backbone: Design, Fabrication, and Modeling
arXiv:2603.19124v3 Announce Type: replace Abstract: This paper presents the design, modeling, and fabrication of 3D-printed, tendon-actuated continuum robots fe…
A Unified Benchmark for RCM-Constrained Visual Servoing: Modeling-Controller Interaction and Robustness Analysis in Laparoscopic Robots
arXiv:2607.00030v1 Announce Type: new Abstract: In robot-assisted laparoscopic minimally invasive surgery (MIS), accurate enforcement of the remote center of mo…
From Technical Metrics to User Perception: A User Study of a Multimodal Human-Robot Interaction System for Object Detection and Grasping
arXiv:2607.00530v1 Announce Type: new Abstract: Improvements in the technical performance of human--robot interaction (HRI) systems do not automatically transla…
Iterated Invariant EKF for 3D Landmark-Aided Inertial Navigation
arXiv:2607.00145v1 Announce Type: new Abstract: Inertial navigation systems aided by three-dimensional landmark measurements constitute a fundamental problem in…
PhyPush: One Push is All You Need for Sensorless Physical Property Estimation with Physics-Guided Transformers
arXiv:2605.26284v2 Announce Type: replace Abstract: Accurately estimating object mass and friction is fundamental to reliable robotic manipulation. While intera…
Optimal any-angle path planning in static and dynamic environments
arXiv:2607.00065v1 Announce Type: new Abstract: Any-angle path planning extends traditional graph-based path planning by allowing movement between any pair of v…
HydraCollab: Adaptive Collaborative-Perception for Distributed Autonomous Systems
arXiv:2607.00191v1 Announce Type: new Abstract: Collaborative-perception enables multi-robot systems to enhance situational awareness by sharing perceptual info…
Wake up for Touch! Mask-isolated Tactile Alignment Learning in MLLMs
arXiv:2607.00302v1 Announce Type: cross Abstract: Touch supplies the physical grounding needed to perceive intrinsic material properties, such as friction and c…
From Prior to Pro: Efficient Skill Mastery via Distribution Contractive RL Finetuning
arXiv:2603.10263v2 Announce Type: replace Abstract: We introduce Distribution Contractive Reinforcement Learning (DICE-RL), a framework that uses reinforcement …
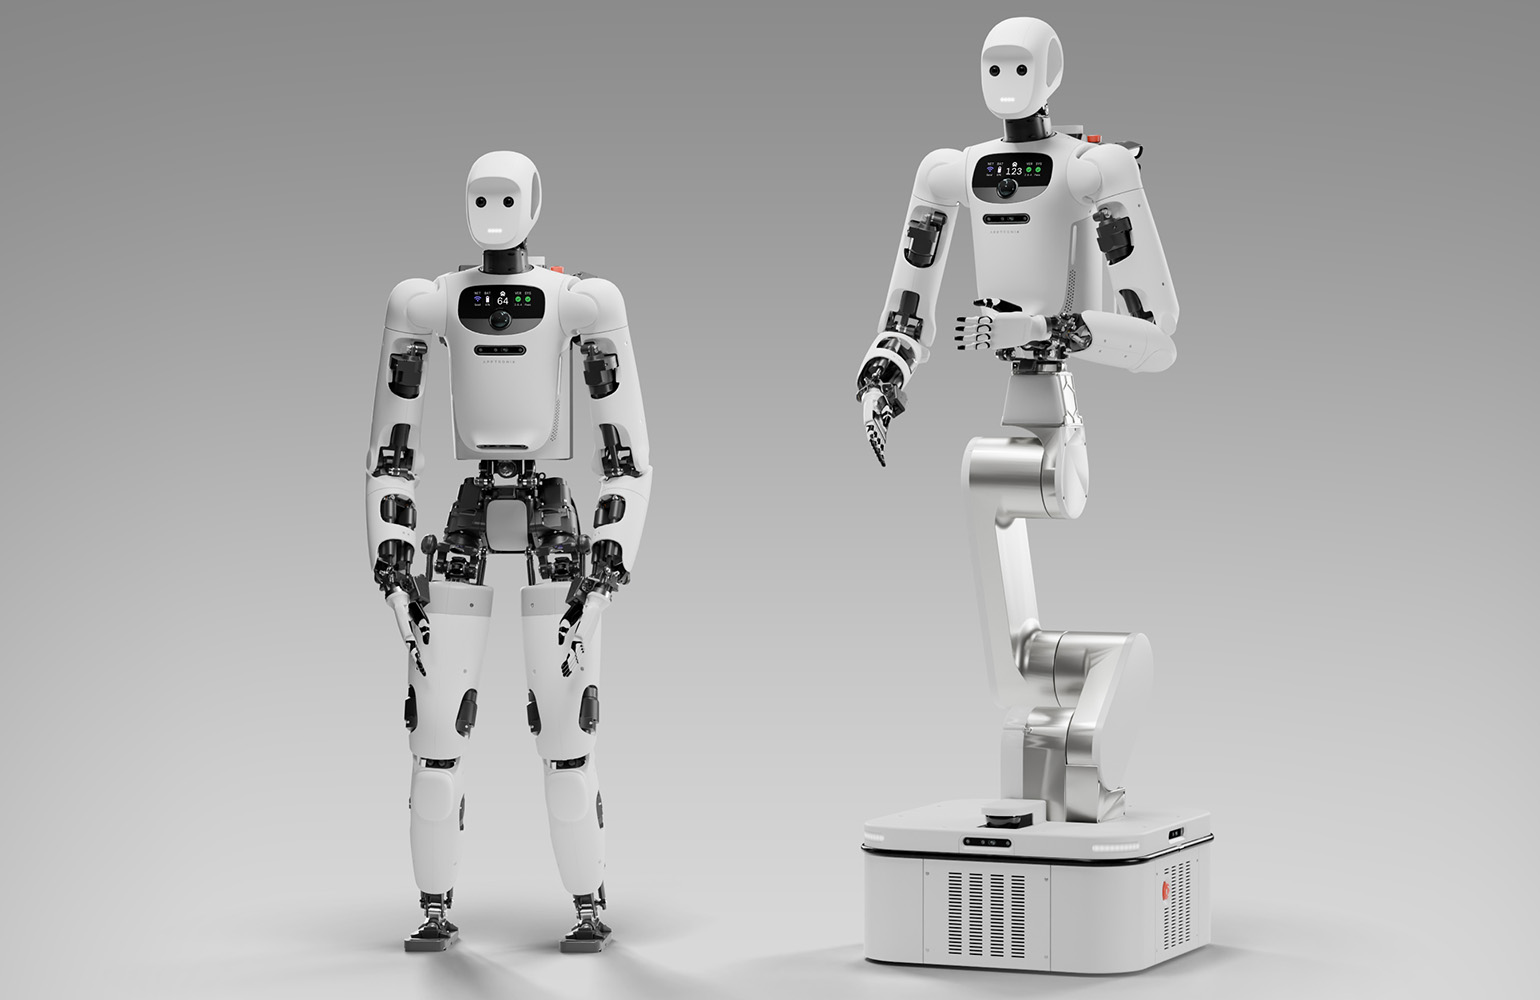
Apptronik unveils Apollo 2 and a flagship data collection and training facility
Built as a data collection and training platform, Apollo 2 enables continuous learning through deployment, Apptronik said. The post Apptronik unveils Apollo 2 a…
OopsieVerse: A Safety Benchmark with Damage-Aware Simulation for Robot Manipulation
arXiv:2606.31993v1 Announce Type: new Abstract: While robotic manipulation capabilities have advanced rapidly, physical safety remains a major barrier to deploy…
Multi-Robot Coordination for Planning under Context Uncertainty
arXiv:2603.13748v3 Announce Type: replace Abstract: Real-world robots often operate in settings where objective priorities depend on the underlying context of o…
Hierarchical 3D Scene Graph Construction and Belief-based Planning for Semantic Navigation
arXiv:2606.31071v1 Announce Type: cross Abstract: Semantic navigation is a fundamental task for embodied agents operating in unseen environments, requiring both…
LDHP: Library-Driven Hierarchical Planning for Non-prehensile Dexterous Manipulation
arXiv:2603.13844v2 Announce Type: replace Abstract: Non-prehensile manipulation is essential for handling thin, large, or otherwise ungraspable objects in unstr…
Safe Online Learning via Smooth Safety-Structured Policy Composition
arXiv:2606.31320v1 Announce Type: cross Abstract: Safe online reinforcement learning requires policies to respect safety constraints while maintaining smooth op…
HABIT: Human-Aware Behavior and Interaction Training Dataset for Robot Manipulation
arXiv:2606.31682v1 Announce Type: new Abstract: Large-scale demonstration datasets have been central to recent progress in general-purpose robot policies. Howev…
Stabilization Learning: A Paradigm Transition Bridging Control Theory and Machine Learning
arXiv:2606.31562v1 Announce Type: new Abstract: Stabilization learning is an interdisciplinary paradigm that bridges control theory and machine learning. Its co…